What Actually Stays the Same When You Move Shapes Around
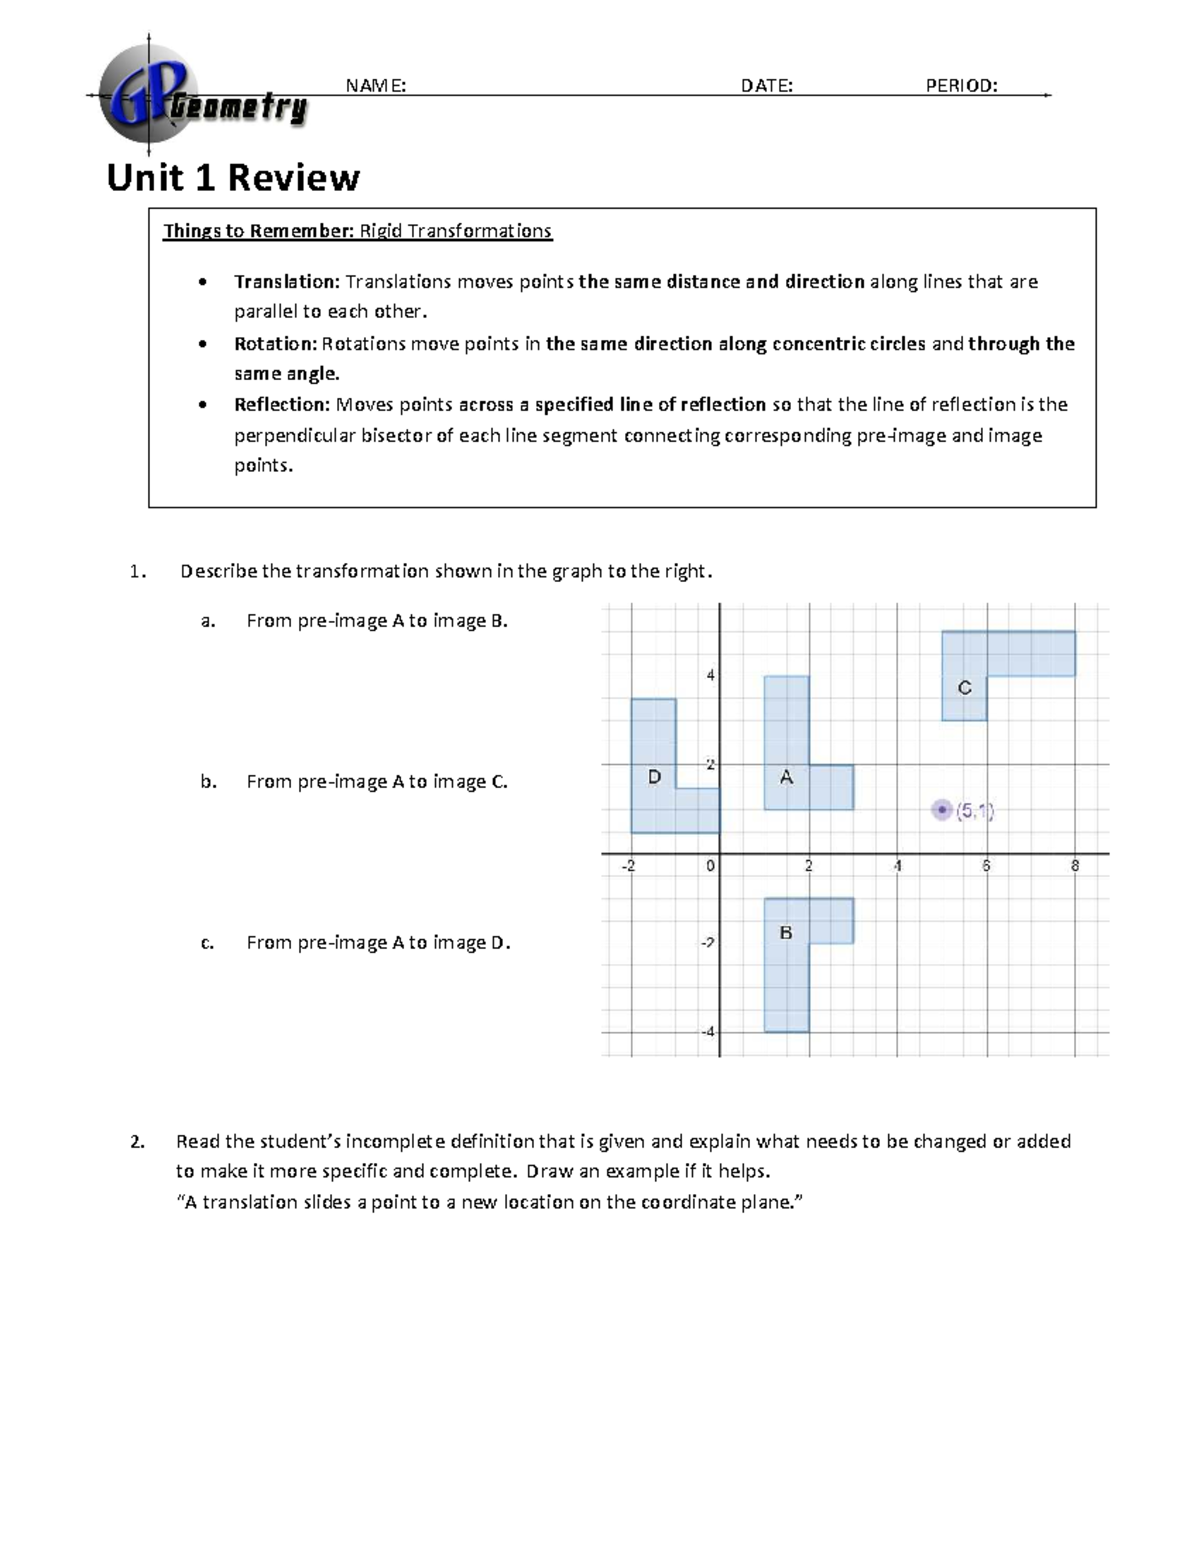
Rigid transformations are translations, rotations, and reflections. That is it. Every point moves, but distances between points do not change. Angles do not change. Area and perimeter stay identical. The shape and size are preserved exactly. Only position or orientation in space changes. I used to grade geometry quizzes on this topic, and roughly 30 percent of students still get the reflection part wrong even two weeks after the unit starts. They think a reflected triangle ends up the same size as the original when it has been flipped across a line. The size is the same. It just looks wrong on paper because they are drawing it mirrored. Orientation flips. Nothing else does.
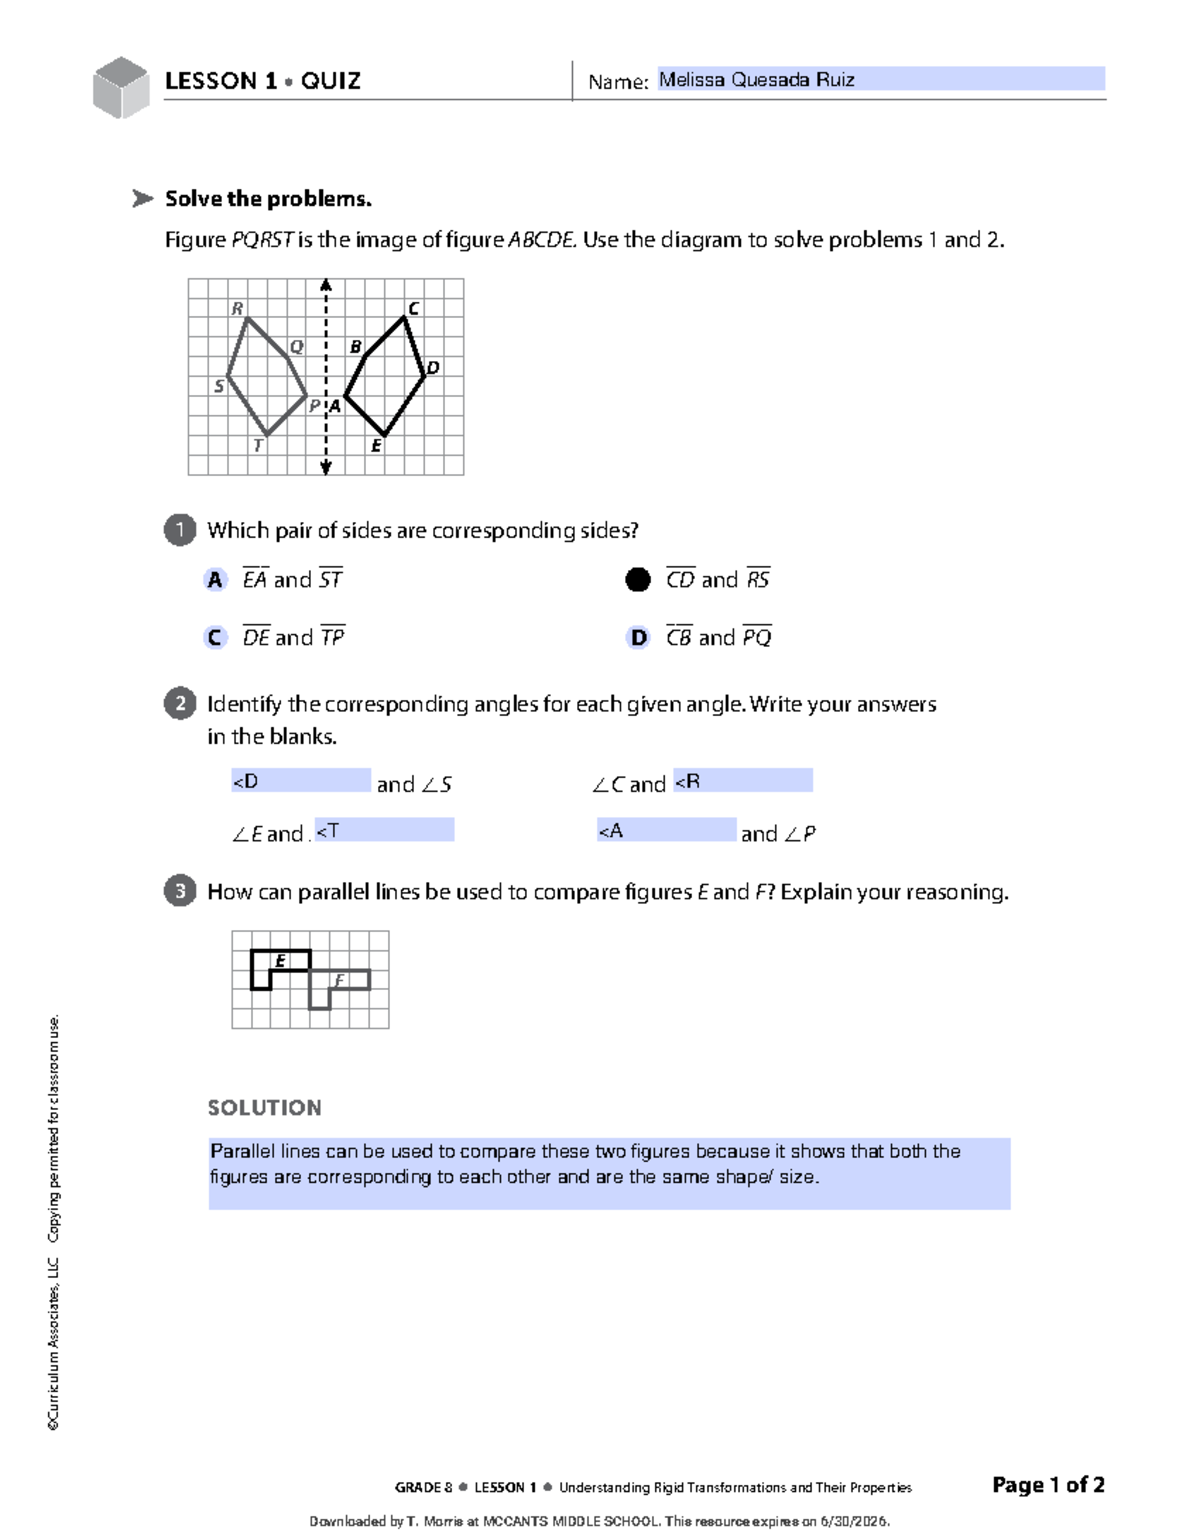
1 Understand Rigid Transformations And Their Properties Answer Key
Here is what a solid answer key needs to reflect. A translation moves every point by the same vector. If you write a rule like T(x, y) = (x + 4, y - 2), every point shifts right 4 and down 2. Nothing rotates. Nothing flips. Distance between any two original points equals distance between their images. That is the definition you test against. A rotation turns a figure around a fixed center point by a given angle. The center itself does not move. Everything else traces a circular arc. Clockwise or counterclockwise direction matters in every standardized test. Most wrong answers come from swapping the direction sign when the problem gives you a negative angle. A reflection flips a figure across a line of symmetry. The line itself is the perpendicular bisector of the segment connecting every original point to its image. That means the line sits exactly halfway between a point and its reflection. If you draw those segments and measure, the math works out clean. Students usually skip the proof step and just guess the answer.
I ran into a specific problem last year that nobody had prepared for. A worksheet asked students to classify a transformation where the image was congruent to the pre-image, oriented the same way, and shared no fixed points. The obvious answer was a translation, but one student had drawn a rotation of 360 degrees. Technically correct, but practically useless. I accepted it anyway because the math was sound. If you need a workaround for ambiguous answer keys like that, check whether the transformation includes any non-identity movement of individual points. A 360-degree rotation is an identity transformation in disguise. It moves nothing in the final result. If the answer key marks it wrong, flag the ambiguity. It happens more often than you would expect.
Get the Full Details
Properties You Need to Memorize Without Actually Memorizing
Distance is preserved. This is the big one. Segment AB equals segment A'B' after any rigid transformation. The property holds for every type. Angle measure is preserved. Triangle angles stay the same. A 90-degree angle does not become 85 degrees because you rotated it. Collinearity is preserved. If three points sat on a line before, they sit on a line after. The line might be in a different place, but the points remain collinear.
Midpoints are preserved. The midpoint of a segment maps to the midpoint of the image segment. I see this tested constantly in coordinate geometry problems where students are asked to find the image of a midpoint instead of both endpoints separately. Doing it the second way saves about four steps per problem. Oriention is preserved under translation and rotation. It is reversed under reflection. This detail separates people who understand the topic from people who just memorized definitions. If a question asks whether a single rigid transformation can map a left-facing arrow onto a right-facing arrow pointing the same direction, the answer is no. Reflections flip orientation. Translations and rotations do not. You would need an odd number of reflections to accomplish that, which means it is not a single rigid transformation in the strict sense.
How to Actually Solve These Problems
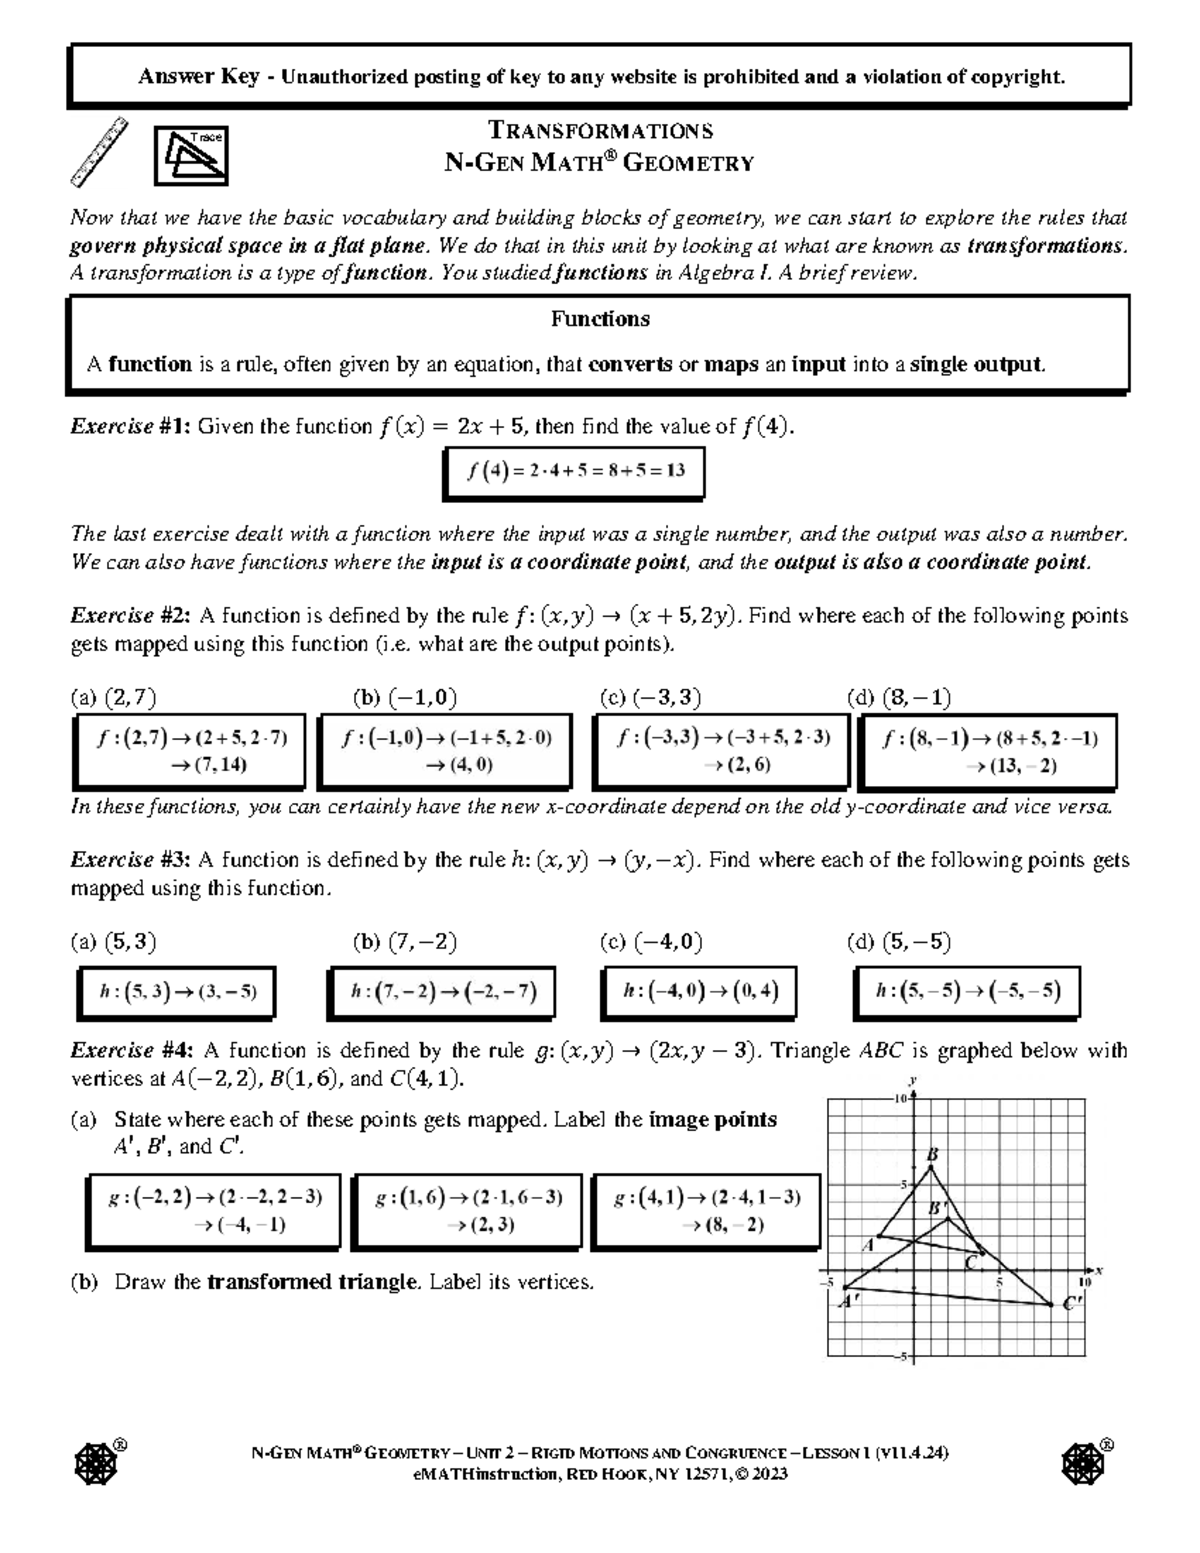
Start by identifying the transformation type. Look at the pre-image and image. Did the figure slide? Translation. Did it turn? Rotation. Did it flip? Reflection. Once you know the type, apply the rule. For translations, add or subtract from x and y coordinates directly. T(x, y) = (x + a, y + b) where a and b are horizontal and vertical shifts. Positive a moves right. Positive b moves up. This is coordinate geometry at its simplest. For rotations around the origin, use the standard rules. A 90-degree counterclockwise rotation maps (x, y) to (-y, x). A 180-degree rotation maps (x, y) to (-x, -y). A 270-degree counterclockwise rotation maps (x, y) to (y, -x). These rules assume standard position with counterclockwise as positive. If your class uses clockwise as positive, the signs flip. Check your textbook convention before you commit to an answer.

For reflections, identify the line first. Reflection over the x-axis maps (x, y) to (x, -y). Reflection over the y-axis maps (x, y) to (-x, y). Reflection over y = x maps (x, y) to (y, x). Reflection over y = -x maps (x, y) to (-y, -x). I cannot stress enough how often students swap the y = x and y = -x rules. Write them on a scrap of paper during the test if you have to. Composite transformations mean applying more than one. The order matters. This is where most mistakes happen. Reflecting then rotating gives a different result than rotating then reflecting. Always apply transformations from the inside out, the same way you would with function composition. The transformation written closest to the figure happens first.
Common Pitfalls That Cost Points
Assuming similarity means congruence. A dilation changes size. It is not a rigid transformation. If a problem shows a smaller version of a triangle, that is a dilation, not a rigid motion. Students conflate these constantly because both preserve angles. Only rigid transformations preserve side lengths too. Forgetting that the center of rotation does not move. If a problem specifies a center other than the origin, you cannot use the origin-based rules. You must translate the center to the origin, rotate, then translate back. This adds three steps and is the most common source of calculation errors in rotation problems. Misidentifying lines of reflection. Students will write x = 3 when the reflection line is actually horizontal. Read the problem carefully. A vertical line has the form x = c. A horizontal line has the form y = c. Diagonal lines require more work.
Not checking your answer. Plug a point into your transformation rule and verify the image lands where you expect. This takes ten seconds and catches 90 percent of silly errors. I recommend doing it even when you are confident. Confidence is not a substitute for verification.
When This Approach Fails Completely
Rigid transformations assume Euclidean geometry. If you are working on a curved surface like a sphere, distances change in non-obvious ways. Parallel lines converge. Triangle angle sums exceed 180 degrees. The entire framework breaks down. This rarely comes up in high school classes, but it is worth knowing if you ever encounter advanced geometry or physics applications. Another limitation: rigid transformations cannot map a figure onto a non-congruent one. If a problem asks whether a square can be rigidly transformed into a rectangle that is not a square, the answer is no. No amount of translation, rotation, or reflection will change side length ratios. You need a non-rigid transformation for that, such as a stretch or shear. Do not waste time trying to find a rigid transformation that does not exist. When composite transformations create a result that looks like a single transformation, you must determine whether it actually is one. Two reflections across parallel lines produce a translation. Two reflections across intersecting lines produce a rotation. Recognizing this composition pattern saves time on tests, but only if you know the theorems behind them. Memorizing without understanding leads to wrong answers on unfamiliar problem types.
Quick Reference Rules
Translation by vector (a, b): (x, y) -> (x + a, y + b) Rotation 90° CCW about origin: (x, y) -> (-y, x) Rotation 180° about origin: (x, y) -> (-x, -y)
Rotation 270° CCW about origin: (x, y) -> (y, -x) Reflection over x-axis: (x, y) -> (x, -y) Reflection over y-axis: (x, y) -> (-x, y)
Reflection over y = x: (x, y) -> (y, x) Reflection over y = -x: (x, y) -> (-y, -x) Keep this list somewhere visible while you practice. Not because you need to memorize it long-term, but because using it during practice builds the muscle memory for when you need to derive the rules from scratch. Deriving them once from first principles, by plotting points and seeing the pattern, makes them stick better than any amount of rote repetition. I have seen this work with students who could not recall a single rule on the first quiz and then scored above 90 percent on the final after going through the derivation process themselves. Time investment is roughly 20 minutes per transformation type. Well worth it.

