
Understanding 6-Lead Motor Configurations
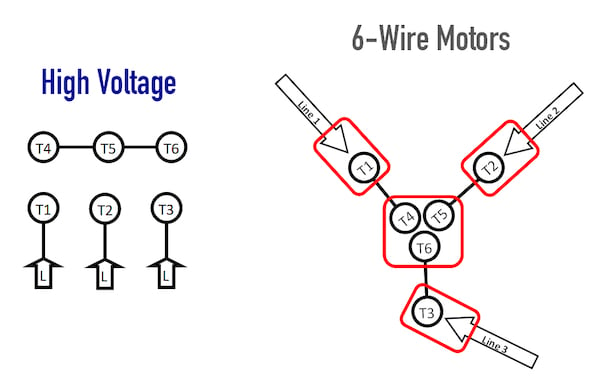
Most three-phase motors you'll run into in a facility have either four leads or six leads coming out of the terminal box. The four-lead version is a fixed delta or wye motor that does one thing. The six-lead version is different. It gives you the option to wire for low voltage or high voltage operation, and depending on how you connect those leads, you can also switch between delta and wye configurations. That flexibility is why a 3 Phase 6 Lead Motor Wiring Diagram exists in the first place.The terminal block on a six-lead motor typically has six studs arranged in two rows of three. The leads are labeled T1 through T6 according to the NEMA standard. T1, T2, and T3 are the line-side terminals on one end of the windings. T4, T5, and T6 are the corresponding ends on the other side. When you look at the nameplate, you'll see something like 230/460V or 460/575V with a wiring diagram reference. That reference tells you exactly which leads to join together for each voltage and configuration. The nameplate diagram usually shows two separate wiring arrangements side by side. One arrangement is for low voltage, the other for high voltage. The low-voltage setup typically uses a parallel wye or parallel delta connection where three leads get tied together with a jumper bar and the remaining three connect to the incoming power lines. The high-voltage setup wires the coils in series, so the line voltage divides across each winding instead of being applied to one coil at a time. Here's how this actually goes when you're standing at a motor with a terminal cover off and a multimeter in your pocket.
Step one: Confirm the motor is de-energized and locked out. I cannot stress this enough because the last thing you need is to be wrestling with live bus bars in a motor control center. Pull a verification reading between each pair of line terminals on the contactor side and between each motor lead and ground. If the motor has been sitting for a while, expect some leakage resistance readings that look concerning until you wipe the terminal studs clean. Step two: Identify the leads. Even though NEMA labeling is standardized, some older motors or replacement rewind jobs have someone who didn't follow the convention. Use your multimeter on the ohms range. Measure resistance between pairs. T1 should show continuity to T4 because they are the same winding. T2 pairs with T5, and T3 pairs with T6. The resistance between each matched pair should be nearly identical. If one pair reads significantly different, you've got a bad connection inside the terminal box or a winding problem that predates whatever wiring you're about to do. Step three: Set up the jumper bars according to your voltage requirement. For low-voltage delta on a 230-volt system, you'd join T1-T6-T5 together, T2-T4-T3 together, and then bring power to the remaining three points. For high-voltage delta on 460 volts, T1 connects to T6, T2 to T4, and T3 to T5, with line power applied to T1, T2, and T3. The exact pattern depends on whether you're doing delta or wye, and the nameplate will specify which.
A Real Problem I Faced With This Setup
I was commissioning a 75-horsepower, 230/460-volt six-lead motor on a 460-volt system about four years ago. The contractor had pre-wired the terminal block for low-voltage delta using copper bus bars and then just capped off the unused studs. Everything looked correct on the surface. We closed the upstream breaker and the motor tried to start, drew about nine hundred amps on each leg during the brief lock-rotor event, and tripped the overload within two seconds. Something was clearly wrong with the configuration. I pulled the multimeter and checked the actual resistance path through the terminal block with the power off. The bus bars had been installed as if it were a low-voltage connection, but the incoming supply was 460 volts. On low-voltage wiring, each coil sees the full line voltage. On 460 volts with that same configuration, each coil was seeing double what it was designed for magnetically, and the impedance couldn't limit the current properly. I rewired it for high-voltage series delta, verified the resistance again, and the motor ran within normal full-load amperage from there. Took about twenty minutes to diagnose once I stopped second-guessing the visual inspection.
Get the Full Details
Common Mistakes That Cause Problems
Leaving a lead ungrounded and dangling in the terminal box is more common than it should be. An unconnected lead in a six-lead motor is usually fine as long as it is properly insulated and not touching anything, but I've seen people strip the insulation too short and create a flash path between adjacent studs when the motor vibrates. Always use proper terminal caps or tape individual leads after verifying which ones are unused for your configuration. Another issue is mixing up the winding pairs during identification. If T1 and T4 aren't correctly paired and you jumper the wrong leads together, you'll create a dead short across a winding when power is applied. That short is immediate and destructive. Double-check every pair before you install bus bars or solder lugs. Using the wrong size bus bar or copper link for the current rating is a quiet failure mode. The manufacturer supplies or specifies the link size for a reason. A 100-amp motor wired with links rated for 60 amps will overheat at the connection point even if the motor itself runs fine. Check the nameplate FLA and make sure your terminal hardware matches it.
When Six Leads Aren't Worth the Trouble
Six-lead motors are useful when you need voltage flexibility, like a motor that might get moved between a 230-volt and a 460-volt system in its lifetime. But there are downsides. The terminal block takes up more space in the junction box. There are more connection points that can fail. Maintenance technicians who aren't familiar with the wiring can make mistakes during replacements. If your application only ever runs at one voltage, a four-lead motor is simpler and less prone to wiring errors. The trade-off is real and worth considering before specifying a six-lead unit. The diagram you need is almost always printed directly on the motor nameplate. It shows the exact jumper arrangement for each voltage and configuration option. Some manufacturers also publish it in the installation manual. If the nameplate diagram is missing or illegible, you can reference the NEMA MG 1 standard which covers the standard wiring patterns for six-lead three-phase induction motors. The patterns are universal as long as the leads are properly labeled. Once you have the configuration dialed in and all connections torqued to the manufacturer's specification, close the terminal cover, recheck your phase-to-phase resistance across the incoming power leads to make sure nothing shifted during reassembly, and run the motor. Monitor the current on all three phases for the first few minutes. If one phase reads noticeably higher than the others, you probably have a bad connection on that leg or a winding issue that wasn't apparent during the initial testing.
This is a straightforward process once you know what you're looking at, but the margin for error is narrow enough that rushing through the lead identification step is the fastest way to cause real damage.


