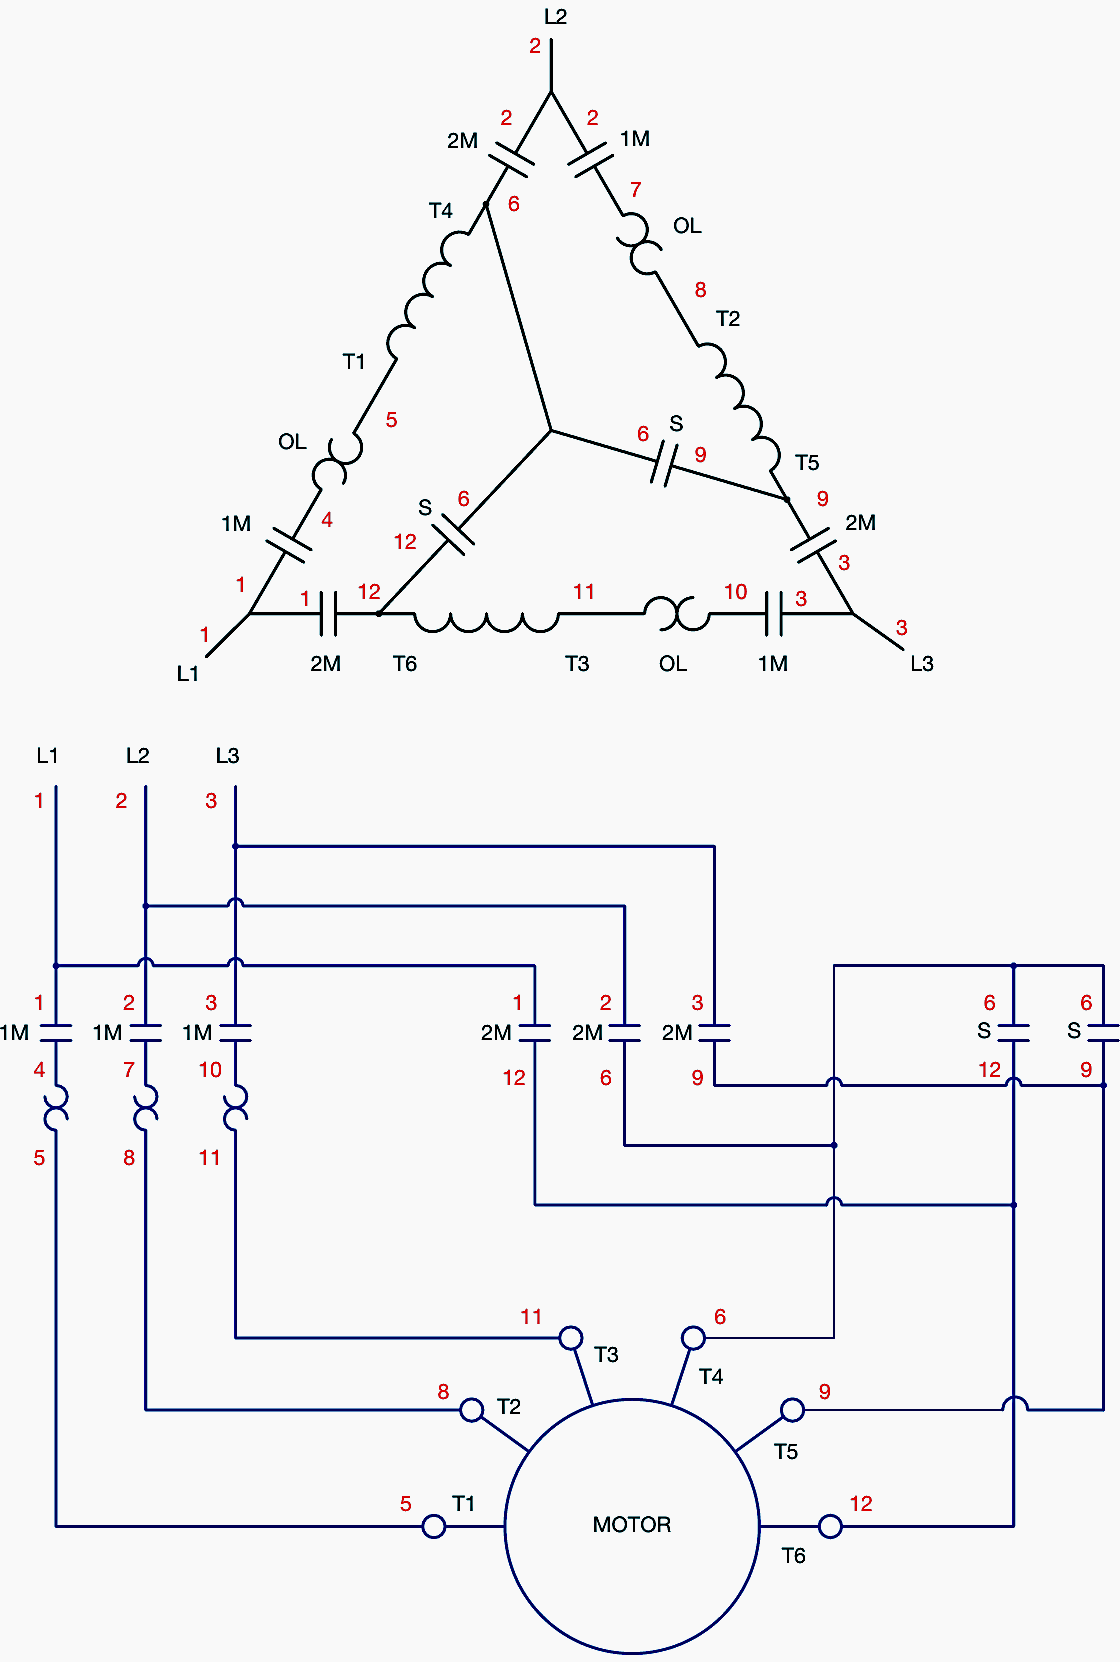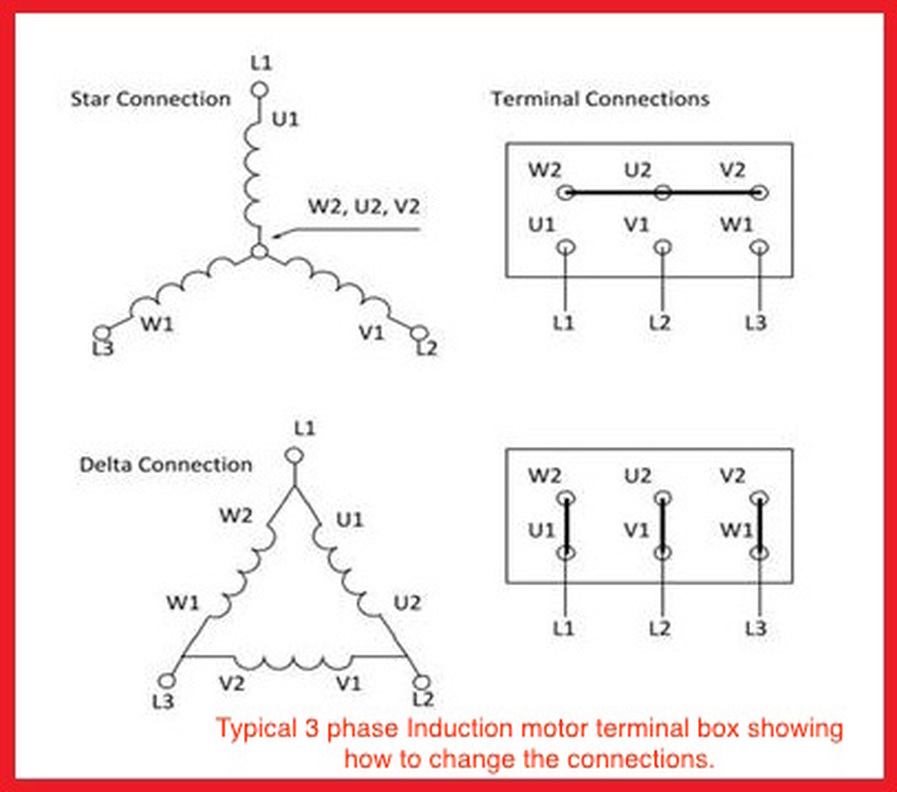
The connection diagram is simpler than most people make it.
You have a motor, a supply, and a bunch of terminals. That is the whole problem. The confusion comes from variations in how manufacturers label things, and from people who have never actually looked at a terminal board up close trying to explain it from memory. I have been wiring these things since before smart breakers existed, and I still pull out the tag plate first every single time. A standard induction motor like the ones you find on lathes, compressors, and pump skids has six leads coming out of the stator. They are arranged in three windings. Each winding has two ends. You connect those ends together in either a star pattern or a delta pattern depending on what voltage you are feeding it and what the motor is designed for. The terminal block usually has six studs arranged in two rows of three. L1, L2, L3 go to your supply. The jumpers between studs determine the configuration. For a delta connection on a 400V supply, you put vertical jumpers on all three studs in the top row and wire the three phases across the bottom row. For star, you bridge the top row completely with a single ring connector and feed the phases into the bottom row. That is the basic method.
Before you touch anything, verify the nameplate voltage and the supply voltage match. This sounds obvious, but I have seen it wrong more times than I care to count. A motor marked 230/400V delta/star gets wired for delta and fed 230 volts, and it pulls twice the current it should. The thermal overload trips within minutes, or doesn't trip at all if it is sized incorrectly. The motor runs hot and degrades insulation faster than it should.
What happens when the labels don't match the terminals
This is where things get interesting. You open up a random used motor and the lead tags are gone or illegible. The manufacturer marked them U1, V1, U2, V2, W1, W2 but the terminal block has no markings at all. Now you need to figure out which lead belongs to which winding end. The quick way is a multimeter in resistance mode. Find the three pairs that show continuity. Each pair is one winding. Once you know the pairs, you need polarity. That means figuring out which end of each winding is the start and which is the finish. You can do this with a bench power supply or even a variac at very low voltage, but there is a simpler trick that a lot of people don't know about. Take a 9-volt battery and connect it to one winding. Hook your multimeter up to a second winding and watch the needle kick when you break the battery circuit. If it kicks one direction on make and the opposite direction on break, the probes are on the same relative ends. If they kick the same direction on both make and break, one probe is on a different relative end. It takes about five minutes to map all six leads this way. You don't need any special equipment.
Get the Full Details

Star-delta starting and why it matters
When you first connect a motor, it draws a lot of current. Direct-on-line starting can pull six to eight times the rated current. That is hard on contactors and hard on the supply. Star-delta starters solve this by initially connecting the windings in star, which reduces the voltage across each winding to about 58 percent of line voltage. The current drops to roughly a third of what it would be on direct delta. After the motor reaches speed, you switch to delta for full torque. The timer on a star-delta starter is usually set between four and eight seconds depending on the load inertia. A fan comes up fast. A conveyor with a heavy belt tension takes longer. If you switch too early, the motor stutters and the current spike defeats the purpose. If you switch too late, the windings stay under-volted and overheat. I once wired a star-delta starter for a 15-kilowatt grinding motor and the timer was set for five seconds by the previous electrician. The motor never made it to full speed in that window. It ran sluggish in star mode, drew 32 amps instead of the expected 14, and the overload kept tripping. The fix was replacing the mechanical timer with an adjustable one and setting it to nine seconds after measuring the ramp-up time with a clamp meter. That process took me about twenty minutes total including the troubleshooting.
Common mistakes that cost time and money
The most frequent error I see is incorrect phase sequence. If you connect L1, L2, L3 to the motor and it runs backwards, nothing explodes but your equipment might. A pump will move water in the wrong direction. A screw conveyor will push material backward. You need to swap any two supply leads to reverse rotation. There is no setting on the motor itself that controls direction except the internal winding connections, and those are fixed at the factory. Another mistake is leaving the ground connection off. Motors vibrate. Vibration loosens terminal screws. Without a proper earth ground, you are relying entirely on the insulation between windings and the frame, and if that fails you have a live chassis and a potentially lethal shock hazard. Use a green-yellow insulated conductor sized at least as large as the phase conductors. Connect it to the grounding stud on the terminal cover, not just dangling nearby. Under-sizing the cable is the third big one. People look at the full load current on the nameplate and buy cable that is barely above that. But during star-delta transition, during voltage dips, during startup, the current goes higher. I usually specify cable with a current rating of at least 125 percent of the motor's full load amperes. It costs more upfront but it prevents nuisance tripping and voltage drop issues that show up months later when the installation is already enclosed and inaccessible.
When to use soft starters instead
Star-delta works well for motors above about 5 horsepower running on relatively stiff supply systems. Below that, the reduced starting torque in star mode causes problems. Above that on weak supplies, the current step during transition from star to delta can still be significant. Soft starters handle both scenarios by using thyristors to ramp the voltage smoothly over a programmed time, typically between two and ten seconds. The inrush current stays at two to three times full load instead of six to eight, and torque builds gradually without any sudden transitions. The downside is cost and heat. A soft starter for a 30-kilowatt motor might cost three times as much as a star-delta contactor assembly, and the thyristors generate real heat that requires ventilation. But for large pumps and fans where mechanical stress matters, the soft starter usually pays for itself in reduced maintenance on bearings, couplings, and belts.

The practical checklist
Before closing the terminal cover, verify these items. Check every terminal screw for proper torque. Loose connections create resistance and heat. Check phase-to-phase and phase-to-ground insulation resistance with a megger. Anything below 1 megohm at operating temperature warrants investigation. Verify the rotation matches the equipment nameplate by momentarily jog the motor. Run it under load and check the current on all three phases. They should be balanced within 10 percent. If one phase reads significantly higher, check for single-phasing conditions, poor connections, or winding degradation. The best practice I have found is to photograph the final wiring before closing everything up. Not because you expect to need it tomorrow, but because six months from now when someone asks why the motor keeps overheating on a specific shift, having the original configuration documented saves hours of guesswork. It takes ten seconds and prevents three days of diagnosis.
A specific edge case that caught me once
I was commissioning a new compressor installation with a 22-kilowatt motor wired for delta at 400 volts. The motor ran fine for about two weeks, then the thermal overload began tripping intermittently during peak hours. The wiring was correct, the connections were tight, and the supply voltage measured properly at the terminal block. I spent two days troubleshooting before I noticed something odd. The motor terminal box had a small ventilation hole that was nearly blocked by a stray piece of wire insulation that had fallen in during the initial wiring. The motor was self-ventilated, and that tiny obstruction was reducing cooling airflow enough to cause gradual overheating under sustained load. The fix was removing the debris and adding a slightly larger breather hole with a mesh screen to prevent future contamination. The current draw never changed. The problem was purely thermal. It is the kind of thing that is easy to miss because everyone focuses on the electrical connections and forgets that cooling matters just as much.
When the motor won't start at all
If you apply power and the motor does nothing, check for voltage at the terminals first. If you have voltage and it still won't turn, the issue is usually mechanical binding or a single-phased supply. Remove the coupling and try to turn the shaft by hand. If it binds, the bearings or the driven equipment is the problem. If it turns freely, check voltage between each pair of terminals. If one pair shows significantly lower voltage than the others, you have an open phase somewhere in the supply path. This could be a blown fuse, a bad contactor pole, or a broken conductor. Single-phasing under load is particularly dangerous because the remaining two phases carry increased current trying to produce the same torque. The motor will hum and vibrate and gradually overheat. The overload may eventually protect it, but not quickly enough to prevent winding damage in some cases. Always verify all three phases are present and within 5 percent of each other before assuming the motor is the problem.

Summary of what actually works
Read the nameplate. Confirm the supply matches. Identify the winding pairs with resistance. Determine polarity with the battery method if labels are missing. Choose the correct connection for your voltage and starting method. Torque all terminals to specification. Verify rotation. Balance the currents. Document everything. Check ventilation. Then run it and monitor for a full load cycle before signing off. The process is straightforward when you understand what each step is actually doing rather than following instructions blindly. The motor will tell you what it needs through its current draw, its temperature, and its sound. Pay attention to those signals and you will catch most problems before they become failures.