Converting Roller Linear Acceleration to Angular Acceleration
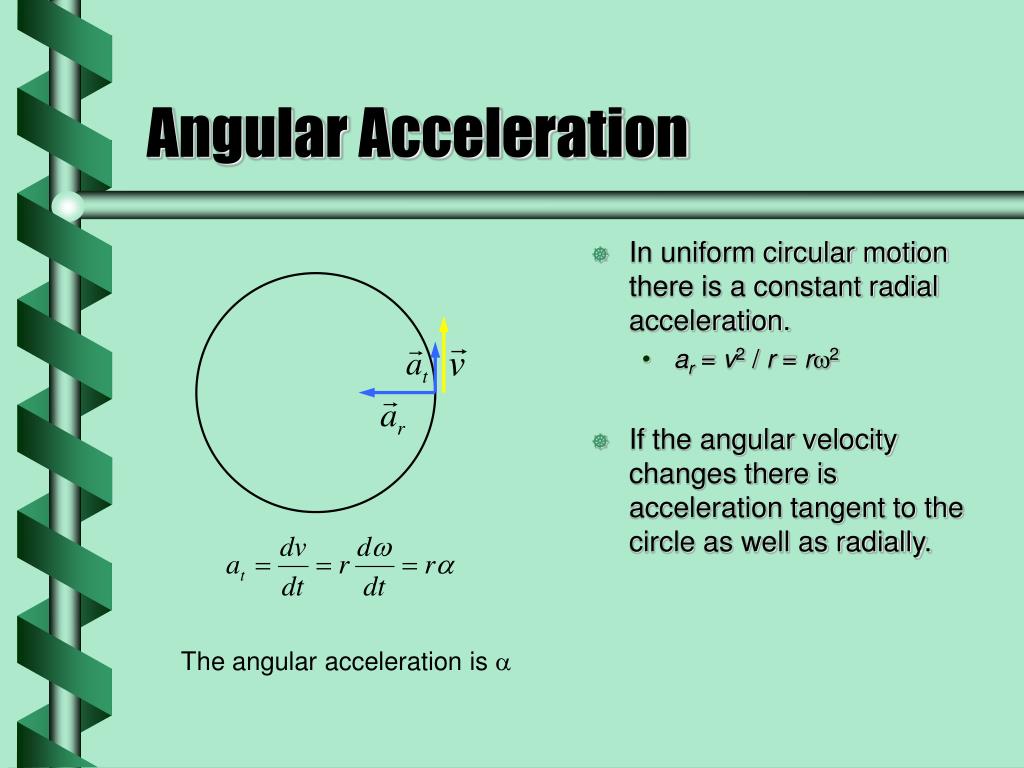
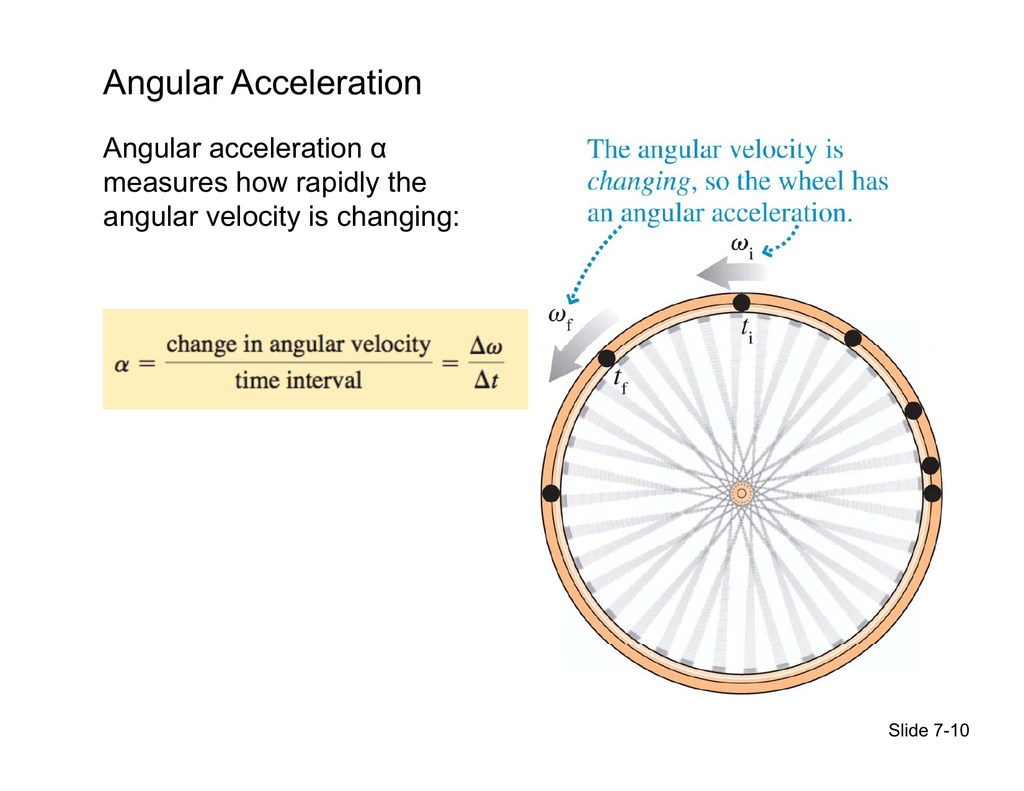
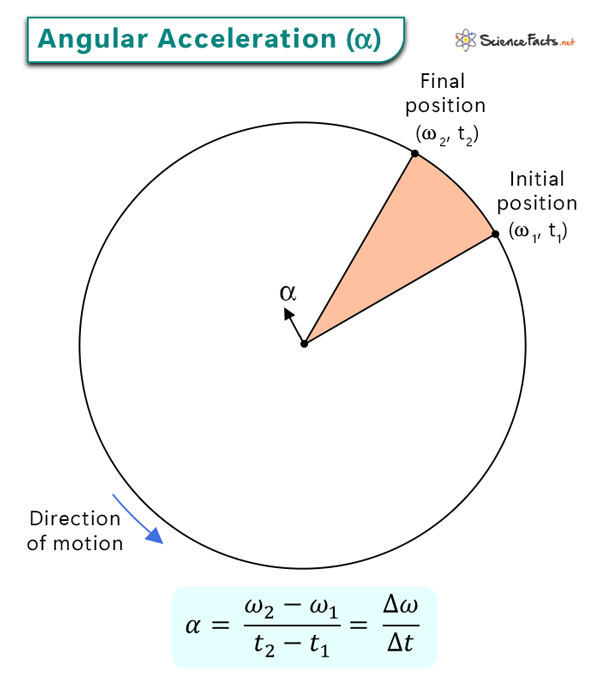
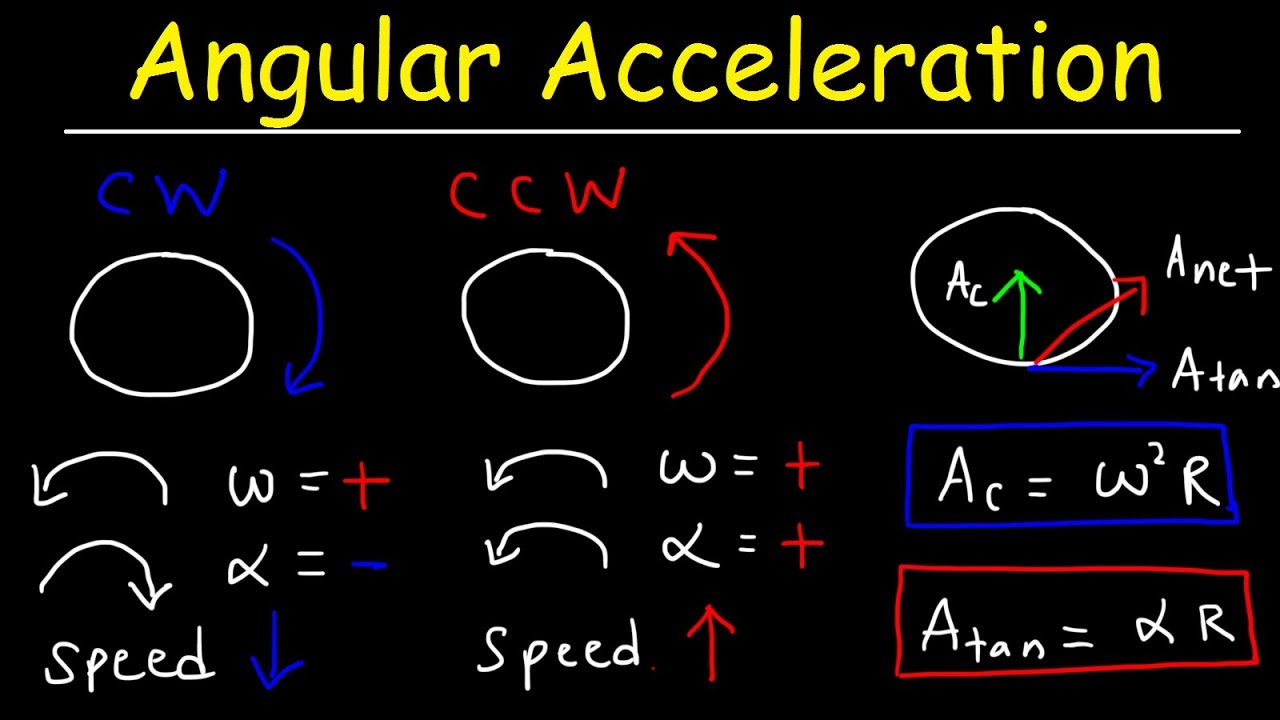
The relationship between linear acceleration of a roller and its angular acceleration is straightforward if you're working on paper, but real installations expose a lot of assumptions that fall apart in practice. The basic formula is alpha = a / r, where alpha is angular acceleration in rad/s², a is the tangential acceleration of the roller surface, and r is the effective radius. That's it. Everything after that point depends on what you actually mean by "acceleration" and how the roller is driven. The conversion itself assumes pure rolling without slip, which is a nice theoretical state and rarely the actual state. When a belt or conveyor drives a roller, there's almost always some micro-slip, especially during acceleration transients. I learned this the hard way on a packaging line where we were spec'ing servo-driven rollers for a high-speed fill station. The calculation said we needed 1200 rpm/s of angular acceleration to hit our cycle time targets. We put it in, ran the sequence, and the product was sliding around on the roller surface because the friction coefficient wasn't high enough at those rates. The math was right. The physics around the math was wrong. The real issue isn't the formula, it's what you treat as "a." If you're measuring the linear acceleration of a product moving across the roller surface, that's different from the linear acceleration at the roller rim. If the roller is driving the product directly through friction, they're the same assuming no slip. If there's a belt or chain involved, or if the roller is idling and the product is being pushed past it, they diverge quickly. I make it a habit to explicitly define which acceleration I'm referring to in every calculation document, because three months later when someone asks why the numbers don't match the test run, that distinction is usually the answer.
Another thing that catches people is the effective radius. The nominal radius of the roller doesn't always equal the effective radius where the force is actually transmitted. Rubber-covered rollers under load compress slightly, which changes the contact patch and the effective radius. In my experience, a 50mm rubber-covered roller under typical conveyor loads can have an effective radius shift of about 0.5 to 1.5mm depending on the cover durometer and the wrap angle. That sounds negligible, but when you're calculating angular acceleration for a system that's already running close to its torque limits, a 2% error in radius becomes a 2% error in your required motor torque, and margins disappear fast.
Practical Calculation Steps
Start with what you know. Usually that's the desired linear acceleration of the material or the belt, and the roller diameter. Convert diameter to radius in meters, then divide the linear acceleration in m/s² by the radius to get angular acceleration in rad/s². If you need it in rpm/s, multiply by 60 and divide by 2. From there, work backward to torque. The total torque the motor needs to provide is the sum of the torque to accelerate the roller's own inertia and the torque to accelerate the load. T = (I_roller + I_load_reflected) × alpha. The reflected load inertia depends on how the load couples to the roller. For a direct friction drive, the reflected inertia is m × r², where m is the mass of the load being accelerated. For a belt drive, it's more complicated because you have to account for the belt tension differential and the pulley ratios if you're using a gearbox. I keep a spreadsheet template that handles these calculations automatically, and I've found that the most common mistake people make is forgetting to convert units consistently. Input acceleration in mm/s² but radius in meters, and your answer will be off by a factor of 1000. It sounds obvious, but I've seen it in engineering documents from companies that should know better. I make the spreadsheet force all inputs through explicit unit labels so you can't accidentally mix them.
Get the Full Details

When The Simple Formula Breaks Down
The alpha = a/r relationship assumes the roller is a rigid body with a fixed radius and no slip. Multiple scenarios violate these assumptions. Elastic deformation of the roller under load changes the effective radius dynamically during acceleration. This is especially noticeable with polyurethane or rubber rollers at high accelerations. The surface stretches, the effective diameter changes slightly, and your angular acceleration calculation is now based on a moving target. We dealt with this on a roller table that was accelerating cartons at 3 m/s². The spec called for a certain motor, the motor couldn't maintain the acceleration profile because the slip increased as the cover heated up, and we ended up switching to a harder durometer cover and accepting a lower max acceleration. The formula would have predicted success. Real materials didn't. Belt-driven systems introduce another layer of complexity. If the roller is driven through a belt from a motor pulley, the angular acceleration of the roller depends on the pulley ratio, but also on belt elasticity. A timing belt will behave differently than a flat belt. A V-belt will slip under high loads. I once specified a V-belt drive for a roller system and didn't account for the creep that happens in V-belts under acceleration transients. The roller was always 3 to 5 percent behind where the calculation said it should be. Not enough to matter for steady-state operation, but enough to cause timing issues in a synchronized multi-roller line. Switching to a toothed belt fixed it immediately. There's also the issue of multiple rollers in a line. If you're accelerating ten rollers that are all independently driven, each one adds inertia to the system and the motor sizing compounds. If they're idler rollers being driven by the product, you need to check that the friction available is sufficient to prevent slip at the calculated angular acceleration. The friction requirement is mu × m × g, where mu is the coefficient of friction between the product and the roller surface, m is the product mass, and g is gravity. If your calculated tangential force exceeds this, the product slips and your angular acceleration assumption is invalid.
Measurement And Verification
Calculations are one thing. Verifying them on the actual equipment is another. I always recommend measuring the actual angular acceleration with an encoder or a tachometer, not just trusting the motor controller's reported values. Motor controllers can report commanded acceleration, which is not the same as actual acceleration if there's load variation or slip. We found a case where the encoder on the motor shaft showed the expected acceleration, but the encoder on the roller shaft showed 15 percent less. There was a coupling slip in the shaft connection that the calculations didn't account for. A loose set screw on a polymer coupling. Cheap part, big problem. If you're designing a system from scratch and want to avoid these issues, the most practical approach is to calculate using the simple formula, then apply a safety factor of at least 1.5 on the torque requirement and 0.8 on the friction coefficient. That covers most of the real-world deviations without over-engineering the system. If you're working with unusual materials or extreme acceleration rates, run a physical test before finalizing the design. A half-day test on a single roller setup will save you weeks of troubleshooting on a full production line. The core concept stays the same regardless of how complex the application gets. Linear acceleration divided by radius gives you angular acceleration. The details around slip, deformation, and inertia are what separate a calculation that works on paper from one that works in the plant.