Understanding Acceleration V Time Graph
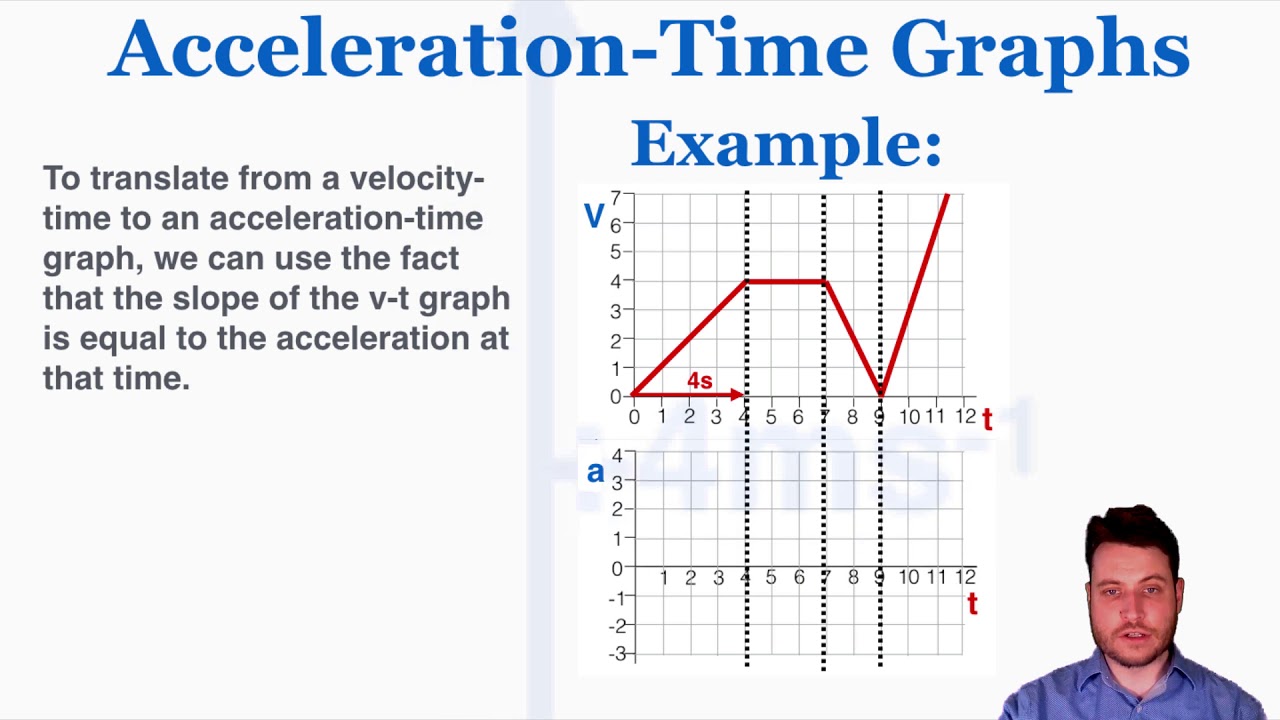
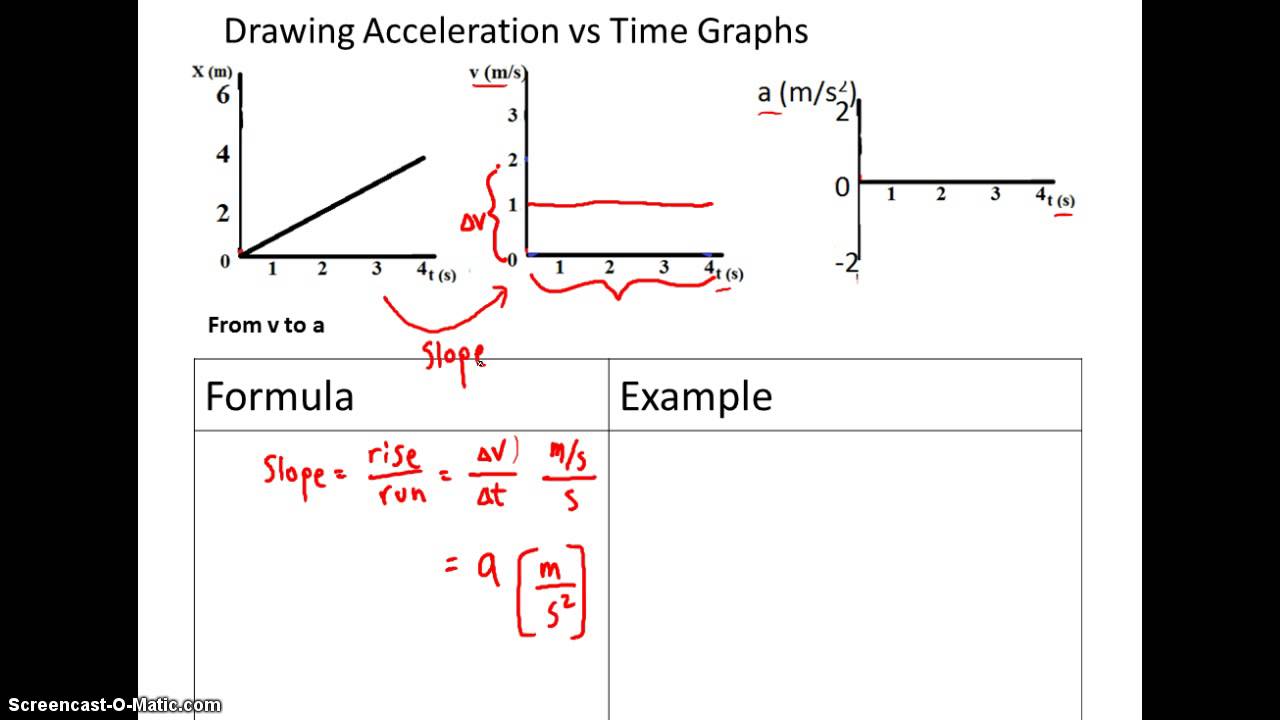
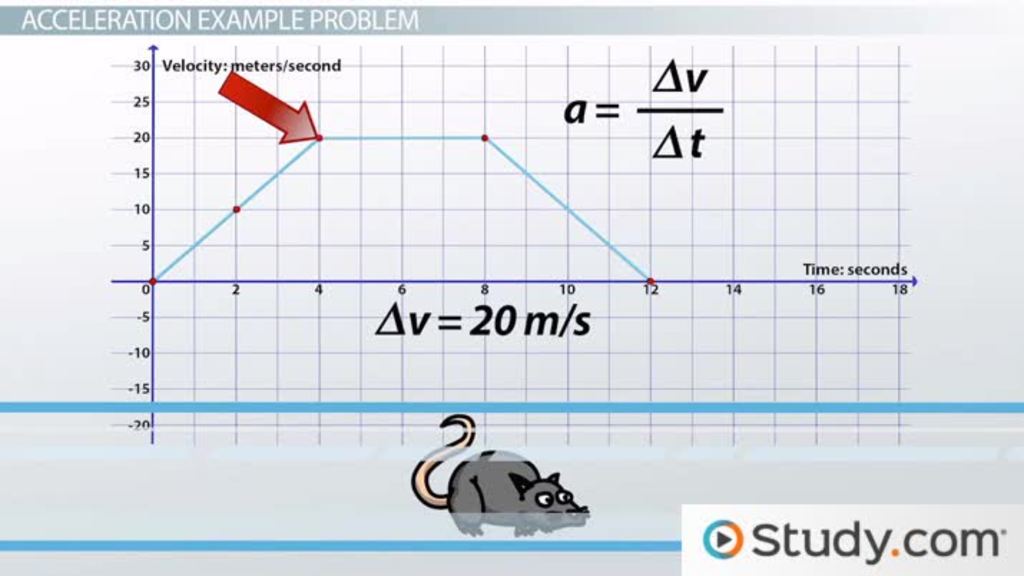
An acceleration versus time graph plots how an object's acceleration changes as time passes. The vertical axis is acceleration in meters per second squared, and the horizontal axis is time in seconds. Reading it is straightforward once you stop overcomplicating things: the value at any point tells you the acceleration at that exact moment, and the area under the curve tells you the change in velocity. That second part is what trips people up most of the time. The area-under-the-curve rule works because acceleration is the derivative of velocity, so integrating acceleration over a time interval gives you delta-v. This means if you have a flat line at 5 m/s² from t=0 to t=4 seconds, the area is 20, and the velocity increased by 20 m/s. If the line dips below the axis, that area subtracts from your velocity. Negative acceleration doesn't automatically mean slowing down — it means the acceleration vector points opposite to your positive direction. I see this confusion constantly in first-year physics labs. Here is a practical workflow I actually use when working with real data rather than textbook problems. First, make sure your sensor or dataset is sampling at a rate that can actually resolve the acceleration changes you care about. If you're measuring something like a car's launch and sampling at 1 Hz, you will miss transient spikes entirely. A 100 Hz sample rate is more realistic for automotive testing. Once your data is captured, plot it directly — don't try to derive acceleration from a position-vs-time curve by fitting polynomials. Differentiation amplifies noise, and you will end up with garbage that looks convincing on paper.
I spent two days last year debugging an oddly smooth acceleration trace from a CAN bus log before realizing the ECU was low-pass filtering the signal at 5 Hz internally. The graph looked clean, almost too clean. I confirmed it by comparing against an accelerometer that logged raw data at 500 Hz, and the high-frequency content that had been filtered out was actually significant for my analysis. The lesson: trust the raw sensor, not the processed stream, whenever possible. A couple of things beginners routinely get wrong that I want to flag. First, confusing the slope of an acceleration-time graph with anything meaningful physically. The slope is jerk — the rate of change of acceleration — and while jerk matters in some engineering contexts like ride comfort calculations, it rarely matters for basic kinematics problems. Most students try to read slope as force or energy and go off the rails. Second, assuming constant acceleration when the graph clearly isn't flat. If the line curves, you cannot use the standard SUVAT equations. You have to integrate numerically or find an analytical function for the curve. When the graph is piecewise linear — which is common in textbook problems and also in real-world event data like crash pulses — the integration is just sums of trapezoids and rectangles. A trapezoid with bases a and a over a time width t gives an area of (a + a)/2 × t. Do this segment by segment and you get an exact delta-v without needing calculus software. I built a small spreadsheet macro that does this automatically for piecewise data, and it reduced what used to take me 40 minutes of manual calculation to under three minutes.
The method breaks down in a few specific scenarios. If your acceleration data has gaps — missed samples due to communication errors or sensor dropout — the area calculation will silently undercount velocity change unless you explicitly interpolate or flag those regions. I have seen teams produce reports with missing data simply averaged to zero, which introduces systematic bias into the result. Always verify data continuity before computing area. Another failure mode is aliasing: if your sampling interval is too coarse relative to the signal's highest frequency content, the graph will show false patterns that look legitimate but are artifacts of undersampling. Nyquist's rule applies here just as it does in any signal processing context — sample at least twice the highest frequency you care about. For downloading or generating acceleration versus time graphs from raw data, most data acquisition tools can export directly. National Instruments LabVIEW, Siglent's oscilloscope software, and even basic Python with numpy and matplotlib will produce publication-quality plots if you feed them clean data. I stick with a Python script using pandas for preprocessing and matplotlib for plotting — it takes about ten minutes to set up once and then saves me roughly an hour per project compared to manually exporting and charting in spreadsheet software. The script handles unit conversion, gap detection, and numerical integration in one pass. If you need an immediate starting point rather than building your own pipeline, the open-source tool SciLab has built-in functions for plotting and integrating acceleration data, and the Python package SciPy offers trapz for trapezoidal numerical integration. Neither requires a license. The key is feeding them properly sampled, gap-free data — no tool will salvage undersampled or corrupted input.
Get the Full Details