What actually happens when you turn on the laser
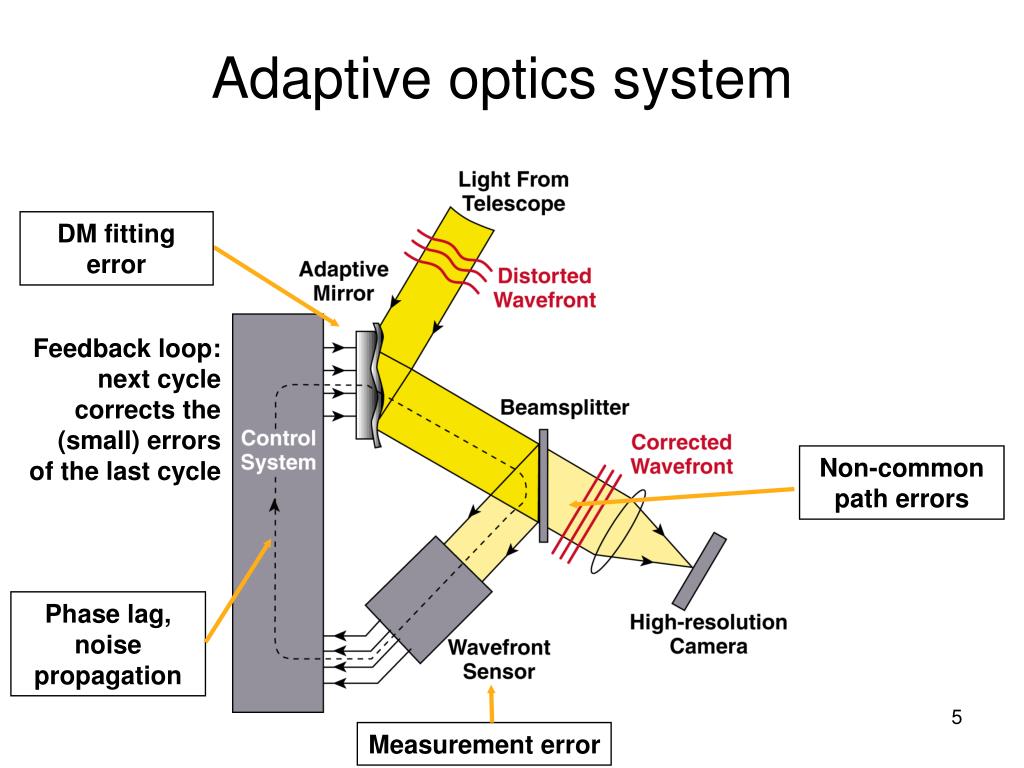
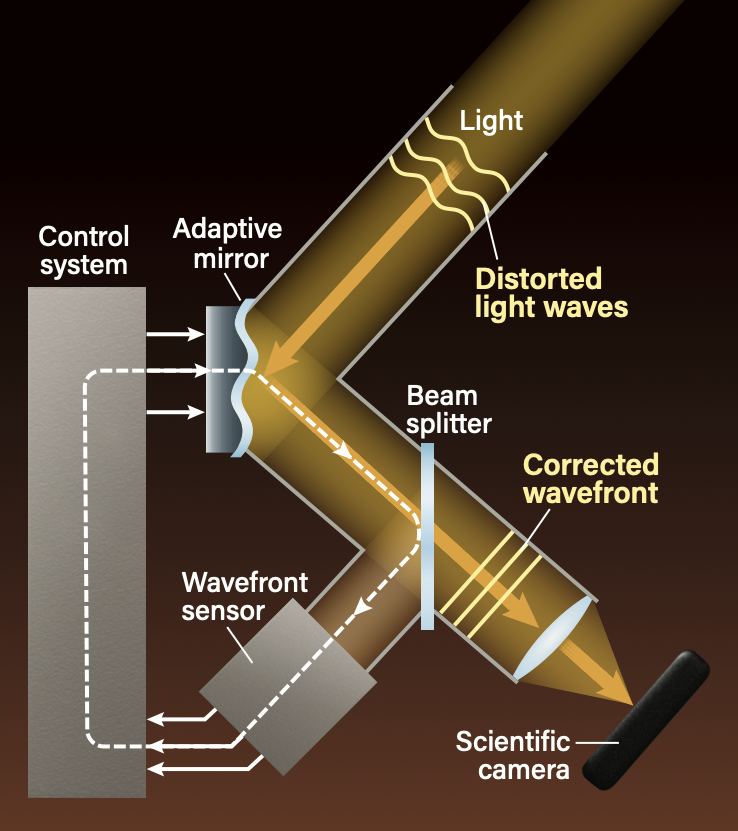
Most people think adaptive optics just blinks a mirror fast enough to cancel out atmospheric distortion. It's more complicated than that, and the difference matters if you're actually trying to get useful data instead of watching the system fail in front of you. The basic idea behind Adaptive Optics For Astronomical Telescopes is straightforward: you measure how much the atmosphere is warping incoming wavefronts, then command a deformable mirror to make the opposite correction in real time. A wavefront sensor looks at a bright reference star—ideally one right next to whatever you're trying to observe—and uses that to figure out what the turbulence is doing. The deformable mirror has actuators you can move thousands of times per second to flatten things back out. That's the textbook version. Real systems are nowhere near that clean.
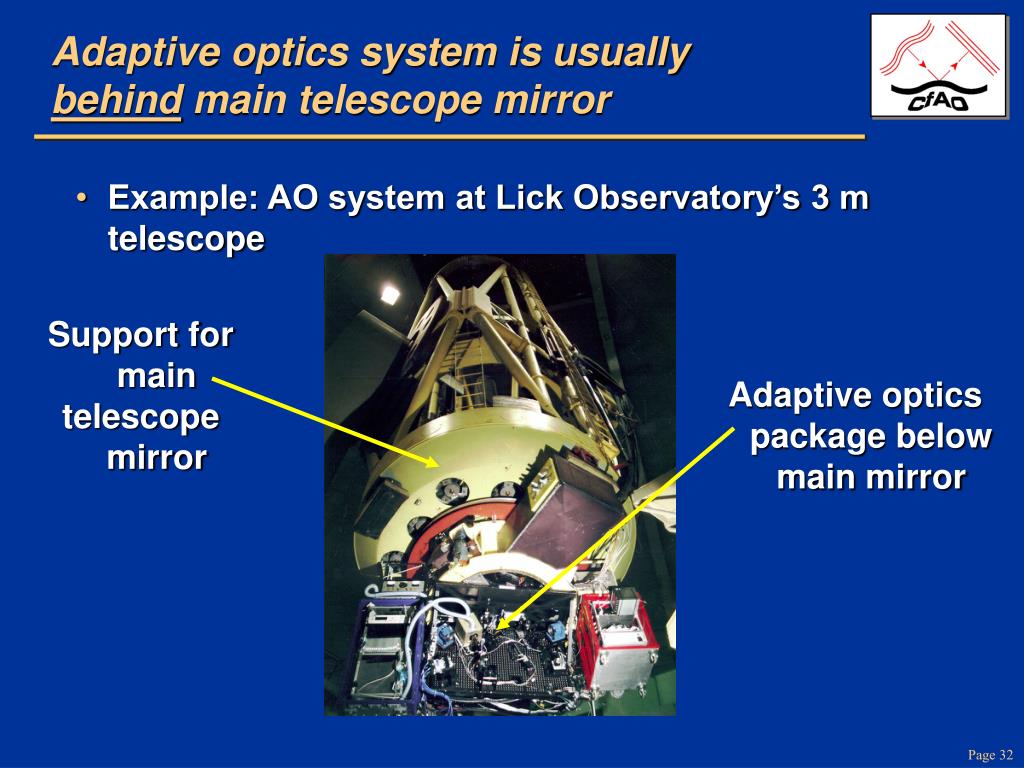
The biggest practical problem I ran into was with the sodium laser guide star on a 10-meter-class telescope. The laser excites sodium atoms in the mesosphere at about 90 kilometers altitude to create an artificial star for the wavefront sensor. You'd think this solves the guide star availability problem, and it does, until you actually try to use the data. The sodium layer isn't a uniform sheet—it fluctuates in density and altitude depending on seasonal patterns, solar activity, and even time of night. When the layer gets thin or moves, the laser guide star brightness changes dramatically, and the wavefront sensor starts reading noise instead of signal. The correction goes to garbage almost instantly. My workaround was relatively simple but not obvious if you haven't lived through it. We started monitoring the sodium layer intensity in real time using a separate photometer aimed at the laser spot. When the layer dropped below a certain threshold, the system would automatically switch to a different mode where it relaxed the correction bandwidth and relied more heavily on the natural guide star we had available. This wasn't ideal—resolution degraded noticeably—but it kept the system from producing completely bogus results that would waste observation time. The tradeoff cost us about 0.3 to 0.5 arcseconds in final image quality compared to perfect conditions, but it was the difference between getting a usable exposure and discarding it entirely.
Adaptive Optics For Astronomical Telescopes: the parts that matter
Let me walk through the actual components and why each one is a potential failure point. Deformable mirrors come in a few flavors. Piezoelectric stack actuators are common in older systems and can handle large stroke but tend to creep over time. Magnetostrictive actuators are faster but introduce magnetic interference that can mess with your wavefront sensor if you're not shielding properly. Electrostatic membranes are used in some modern designs and have low hysteresis but limited stroke. The actuator count matters enormously—more actuators means you can correct higher-order aberrations, but the control system has to keep up with the math. A 500-actuator mirror updating at 1 kilohertz means your real-time controller is doing roughly half a million matrix operations per second. If your computer lags even a millisecond, you're already behind the turbulence. Wavefront sensors are typically Shack-Hartmann types. A microlens array breaks the incoming light into sub-apertures, and each sub-aperture forms a spot on a camera. The spot displacement tells you the local wavefront slope. The catch is that every sub-aperture needs enough photons to make a meaningful measurement. In bright light this is trivial. When you're looking at a magnitude 18 galaxy with no bright star nearby, you're counting individual photons and the signal-to-noise ratio becomes your dominant limitation. This is why extreme AO systems on the largest telescopes sometimes use extreme-wavefront-sensor architectures that sacrifice spatial resolution for massive photon collection efficiency.
Get the Full Details
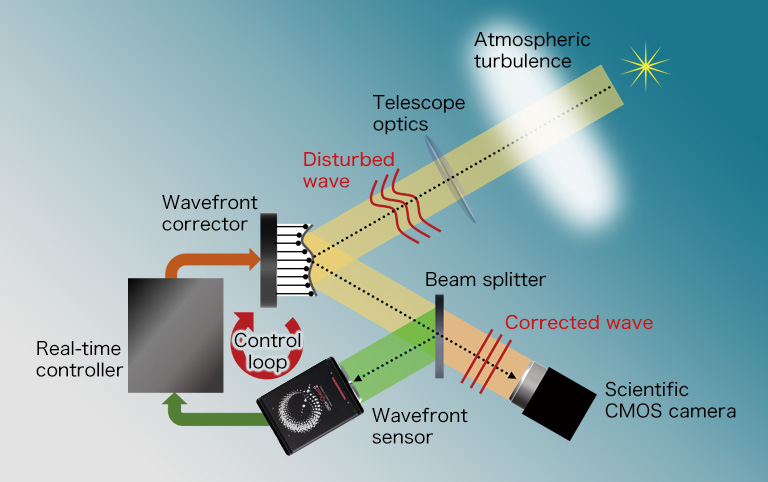
Control systems are where most people underestimate the engineering challenge. The reconstruction matrix maps wavefront sensor measurements to deformable mirror commands. Building this matrix requires knowing the coupling between every actuator and every sensor sub-aperture, which you measure by sending calibration patterns into the system. The matrix is huge—thousands by thousands—and you need to invert or pseudo-invert it on every control cycle. Modern systems use GPU acceleration for this, but even GPUs can choke if the turbulence is particularly fast or if you're doing multi-conjugate AO where you're reconstructing multiple turbulent layers simultaneously. Here's something that trips up a lot of people: tip-tilt correction usually can't use the laser guide star at all. The sodium layer sits so high that its apparent motion due to atmospheric tilting is essentially zero from your perspective—you can't measure tip-tilt from it. You need a real bright star close to your target for that part. If your target is in a faint galaxy cluster with no suitable tip-tilt star, you're stuck. This is called the isoplanatic angle problem, and it's the single biggest constraint on how far from a guide star you can observe with useful correction. Another thing beginners miss: temporal lag error. The atmosphere changes continuously, and there's always a delay between when you measure the wavefront and when the mirror applies the correction. During that delay, the turbulence has evolved. At good seeing sites with fast winds, this lag can eat up 20 to 30 percent of your correction budget even with a well-designed control loop. The standard fix is predictive control algorithms that forecast the turbulence ahead of time using past measurements. These work reasonably well for steady wind conditions but break down when the wind direction or speed changes rapidly, which happens more often than you'd think at high-altitude observatory sites.
I've also seen systems suffer from voltage ramp saturation on deformable mirror actuators. When the correction keeps pushing in one direction—say, because there's a persistent low-order aberration in the telescope optics rather than the atmosphere—the piezo elements slowly drift toward their mechanical limits. The system appears to be working fine, but after an hour or two the actuators run out of stroke and the correction quality deteriorates without any obvious warning. The fix is a regular nulling routine where you command the mirror to a neutral position and recalibrate, but doing this during an observation run costs you observing time and can disrupt tracking if you're not careful.
When adaptive optics doesn't help and what to do instead
AO is not a magic solution. It fails in several predictable ways. Very wide fields are the first place it breaks down. The correction quality degrades as you move away from the guide star because the atmosphere you're correcting for changes. This is anisoplanatism, and the degradation follows an approximate power law with angular separation. For visible-light AO, the isoplanatic angle is typically 10 to 30 arcseconds. For near-infrared systems it's larger—maybe 30 to 60 arcseconds—because longer wavelengths are less affected by the same amount of turbulence. If you need to correct a field larger than that, you're looking at multi-conjugate adaptive optics, which uses multiple deformable mirrors at different altitudes and multiple guide stars to build a three-dimensional turbulence map. This is dramatically more complex and expensive, and the gain field is still usually only a couple of arcminutes across at best. Faint targets without bright neighbors are the second failure mode. If your science target is intrinsically dim and there's no star bright enough for the wavefront sensor within the isoplanatic patch, standard AO simply cannot function. You might be able to use a laser guide star to solve the photon starvation problem for the wavefront sensor, but then you're back to the tip-tilt limitation I mentioned earlier. Some newer systems are developing tomographic AO techniques that combine multiple guide stars to reconstruct the full 3D turbulence profile, which helps but doesn't eliminate the fundamental constraint that you need sufficient guide star brightness and density.
Extremely high-order correction runs into actuator count limits. A 10-meter telescope with a 500-actuator mirror can correct maybe the first 20 or so Zernike modes significantly. Higher-order aberrations—things like small-scale wrinkles in the wavefront caused by localized turbulence pockets—simply aren't measurable or correctable with that hardware. This is a hard physical limit, not an engineering oversight. You either get a bigger mirror with more actuators or you accept that some residual error will always remain. When AO won't work for your observation, lucky imaging is a reasonable alternative for smaller telescopes. You take thousands of short-exposure frames and select only the ones where the instantaneous seeing was good enough. This can approach diffraction-limited performance on apertures up to about 40 centimeters, which is surprisingly effective for amateur and small-student-telescope work. For professional applications where AO is impossible due to guide star scarcity, speckle interferometry or shift-and-add techniques can recover some resolution from short exposures, though the recovery is partial and wavelength-dependent.
Practical calibration notes
If you're setting up or operating an AO system, here are the calibration steps that actually matter in practice. First, measure the closed-loop transfer function with the system looking at a known point source. This tells you the actual bandwidth and correction quality you're achieving, which is almost always worse than the design specification. I've seen systems report 90 percent correction efficiency on paper and deliver 40 percent in operation because the calibration didn't account for detector read noise, mirror response nonlinearity, or control loop timing jitter. Second, characterize the residual wavefront error in both spatial and temporal domains. The spatial spectrum tells you which modes are poorly corrected—usually the highest order terms and the piston term across sub-apertures. The temporal spectrum reveals whether your control loop is underdamped (oscillating) or overdamped (too slow). Both show up as excess noise in your final images but in different ways. Underdamped systems produce ringing artifacts around bright sources. Overdamped systems leave low-frequency atmospheric speckles that look like genuine structure.
Third, track the wavefront sensor dark current and bias stability over time. A drifting bias level looks like a slow wavefront curvature change, which the control system interprets as atmospheric tip-tilt or defocus and tries to correct by moving the mirror. This creates a slow drift in the correction that can push the mirror toward its mechanical limits—the same voltage ramp saturation problem I described earlier. Most systems have a self-test mode that measures the wavefront sensor bias with the shutter closed, but running this manually before and after an observation block catches drifts that the automated system might miss. For the deformable mirror itself, map the hysteresis curve if you're using piezoelectric actuators. Go through a full range of command values and record the actual mirror displacement. The hysteresis loop is usually narrow but asymmetric, and this asymmetry introduces a systematic error that shows up as a low-order aberration in your corrected image. Compensating for it in the reconstruction matrix is possible but requires a good calibration measurement first. Finally, and this is something I learned the hard way: don't trust the Strehl ratio number the system reports without checking your own images. The reported Strehl is computed from the wavefront sensor data under idealized assumptions. It doesn't account for anisoplanatism if you're observing off-axis, it doesn't include the effects of guide star brightness on measurement noise, and it rarely factors in the telescope's own static aberrations that the AO system can't correct because they're aliased or outside the control band. Your actual image Strehl can be significantly lower than what the system claims, especially for extended or off-axis targets. Always verify with an actual point spread function measurement from a known star.
The bottom line is that adaptive optics works well when the conditions are right and the system is properly calibrated. Most of the time spent operating these systems is not in the observing itself but in the calibration, diagnostics, and troubleshooting that happens before and after. Understanding where the system fails is more useful than knowing where it succeeds, because the failures are what determine whether your observation is usable or not.