Computing the Angle Between Two Vectors Without Overcomplicating It
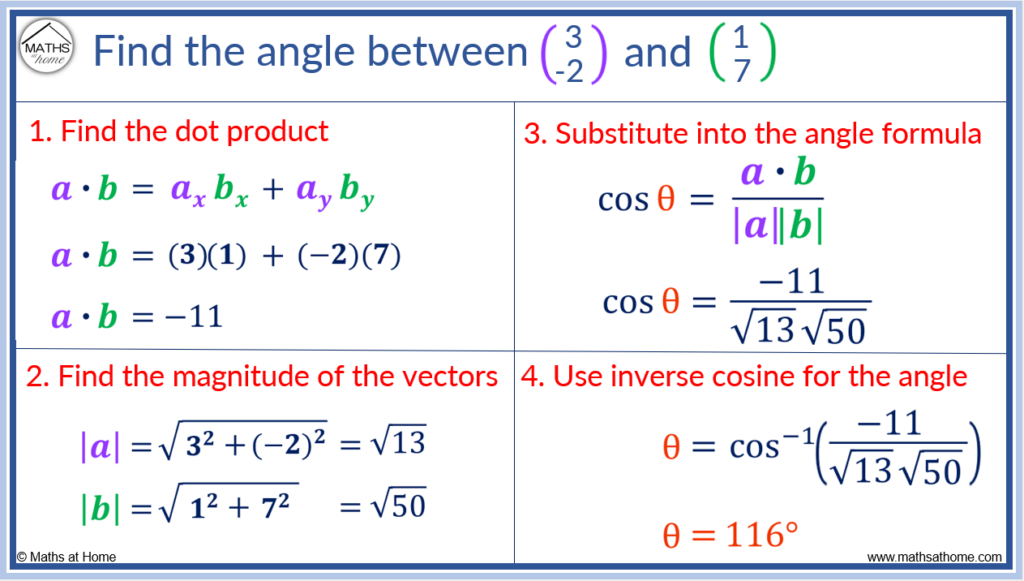
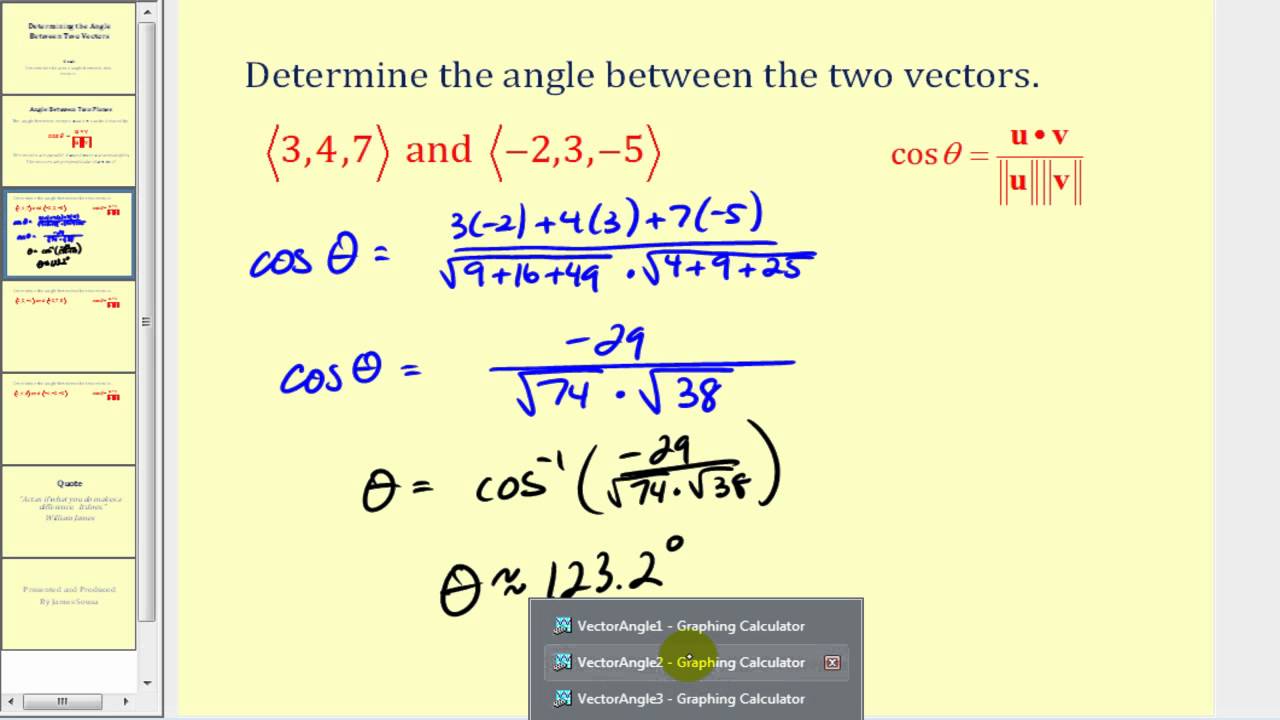
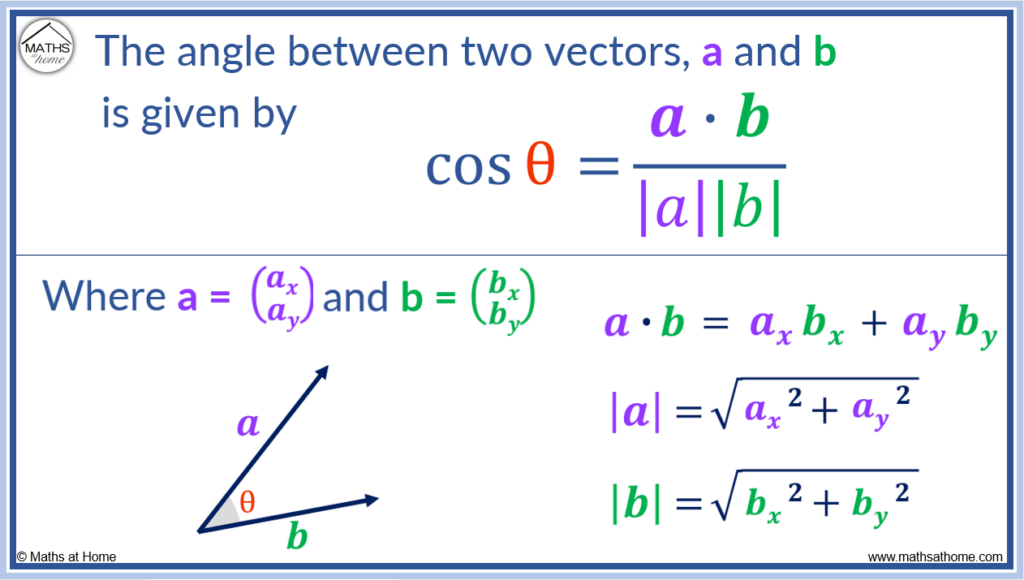
The dot product formula is where this starts. If you have vectors a and b, the angle between them is found by taking the arccosine of (a · b) divided by the product of their magnitudes. That's it. The derivation comes straight from the definition of the dot product itself, where a · b equals |a||b|cos(). Rearrange and you get = arccos((a · b) / (|a||b|)). I ran into a real problem last year working with some particle trajectory data where two velocity vectors were nearly parallel but pointing in slightly different directions. One was (1.0000001, 0.0000003) and the other was (1.0, 0.0). The computed angle came out as zero because the floating-point precision in standard double format couldn't distinguish the tiny difference after the normalization step ate the precision. What I ended up doing was switching to the atan2-based approach instead, computing the angle as atan2(|a × b|, a · b). This gives you the angle directly without the arccos boundary sensitivity near 0 and 180 degrees. It also preserves the sign if you're working in 2D and need to know which direction the rotation goes.
Why the Angle Between Two Vectors Matters More in Practice Than in Theory
The most common mistake people make is forgetting to normalize before or assuming the raw dot product gives you the angle. It doesn't. The dot product alone encodes both directional similarity and magnitude scaling. If you skip the magnitude division, you're not getting an angle — you're getting a scalar that happens to relate to one under specific conditions. Another thing that trips people up: arccos is only defined for inputs between -1 and 1. In floating point, due to rounding errors, your computed value of (a · b) / (|a||b|) can sometimes come out as 1.0000000000000002 or -1.0000000000000002. When that happens, arccos returns NaN. A simple clamp operation before passing the value into arccos fixes this — just snap the ratio to the range [-1, 1] before calling the inverse cosine function. The cross product method I mentioned above isn't universally better. In three dimensions, computing the cross product introduces more arithmetic operations and therefore more accumulated rounding error than a simple dot product and two square roots. If your vectors are well-scaled and not nearly parallel, the standard arccos approach is actually more numerically stable. The atan2 cross-dot method shines specifically in those edge cases where the angle is extremely close to 0 or , which is exactly when arccos becomes unreliable.
In 2D, there's an even simpler shortcut. You can compute the signed angle from vector a to vector b using atan2(a_x * b_y - a_y * b_x, a_x * b_x + a_y * b_y). The numerator is the 2D analog of the cross product magnitude and the denominator is the dot product. This single atan2 call gives you a signed angle in the range (-, ], which tells you both the magnitude of the angle and which way to rotate from a to b. I use this in graphics code all the time instead of branching between sin and cos approaches. One practical note about units. Make sure whatever system you're working in is consistent. If you're comparing vectors in a physics engine that uses degrees for everything else, convert the radian result from arccos or atan2 accordingly. Mixing radians and degrees mid-calculation is an inexpensive mistake but a frustrating one to debug when your simulation behaves erratically. For higher-dimensional work beyond three dimensions, the cross product method disappears entirely since cross products don't generalize to arbitrary dimensions. You're stuck with the dot product approach, which means you need to be more aggressive about that clamping step to avoid NaN issues. The fundamental formula stays the same regardless of dimension — it's just that your numerical safeguards need to scale with the complexity of the input data.
Get the Full Details