Getting Actually Useful Out of Angular Momentum Work
Most people treat angular momentum problems like they're completely different from linear momentum problems, and they kind of are, but the confusion usually comes from picking the wrong conservation law for the situation. I've spent years watching students and junior engineers struggle with this same set of topics, and the pattern is always the same. They memorize L = r × p and = dL/dt and then plug numbers into the wrong equation because they didn't check whether angular momentum was even conserved in their setup. Let me walk through how I actually approach these problems, because the textbook order doesn't match the mental order you need when you're solving them under time pressure.
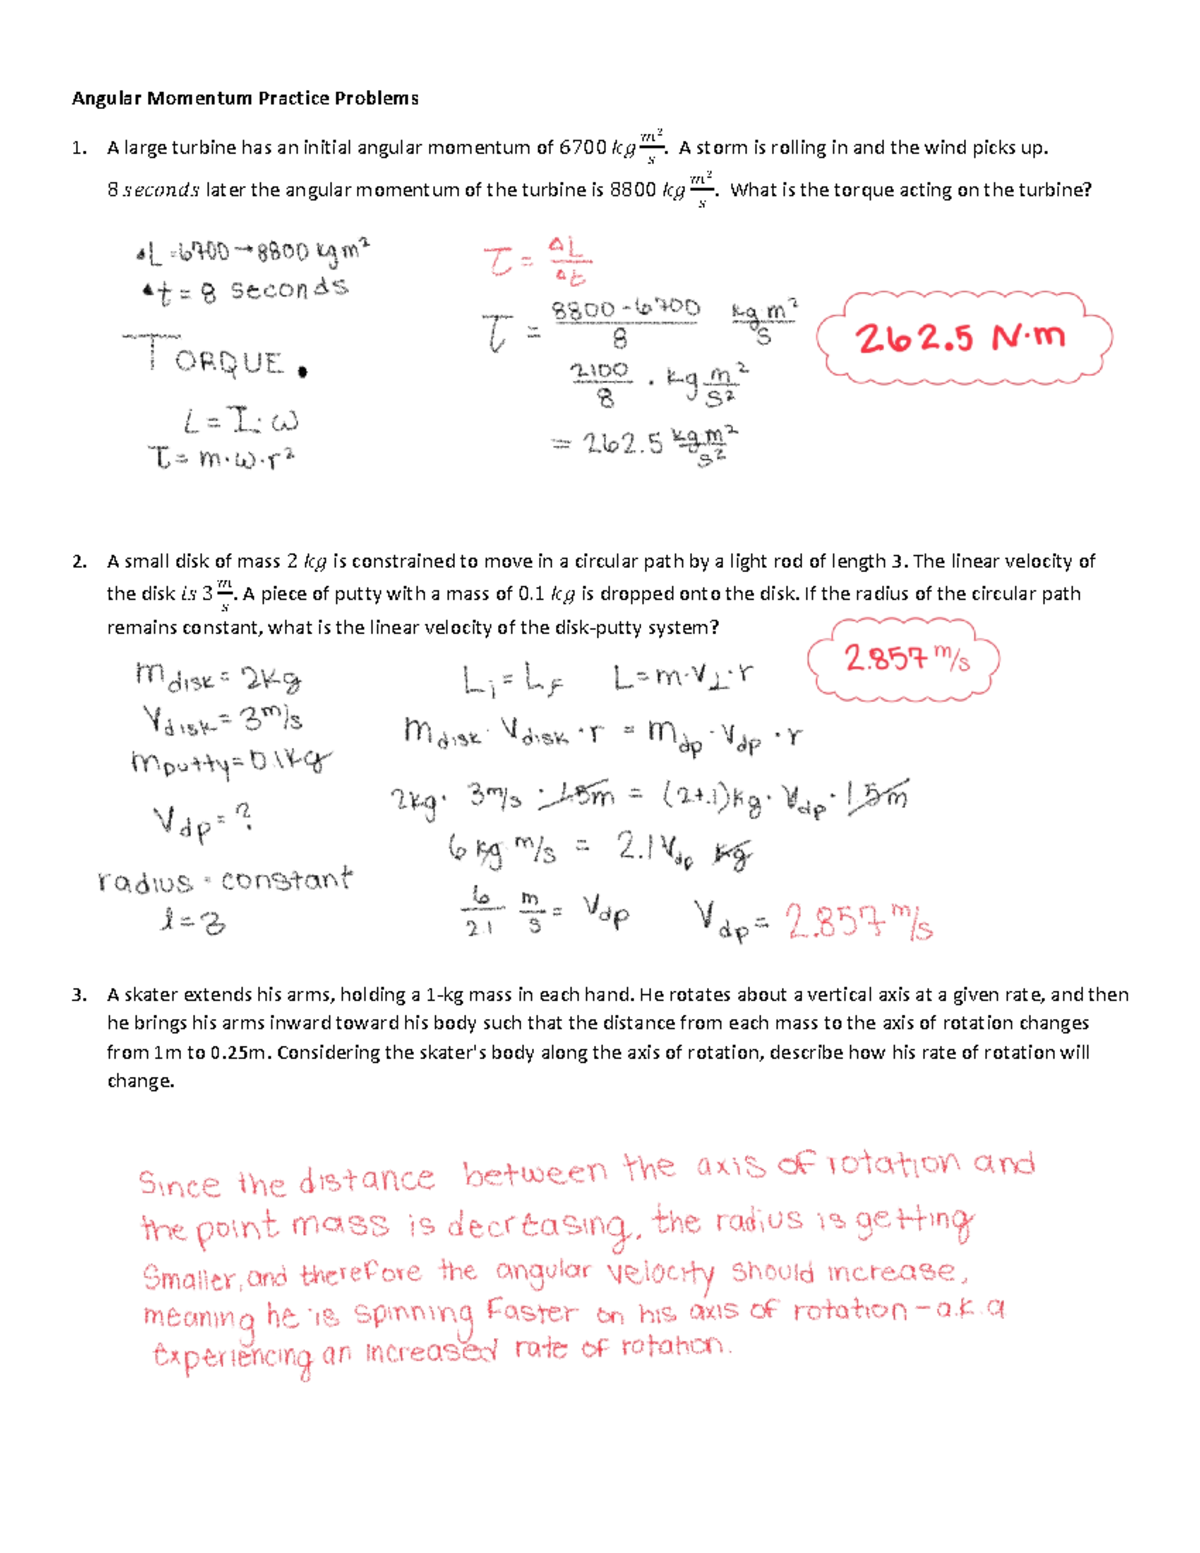
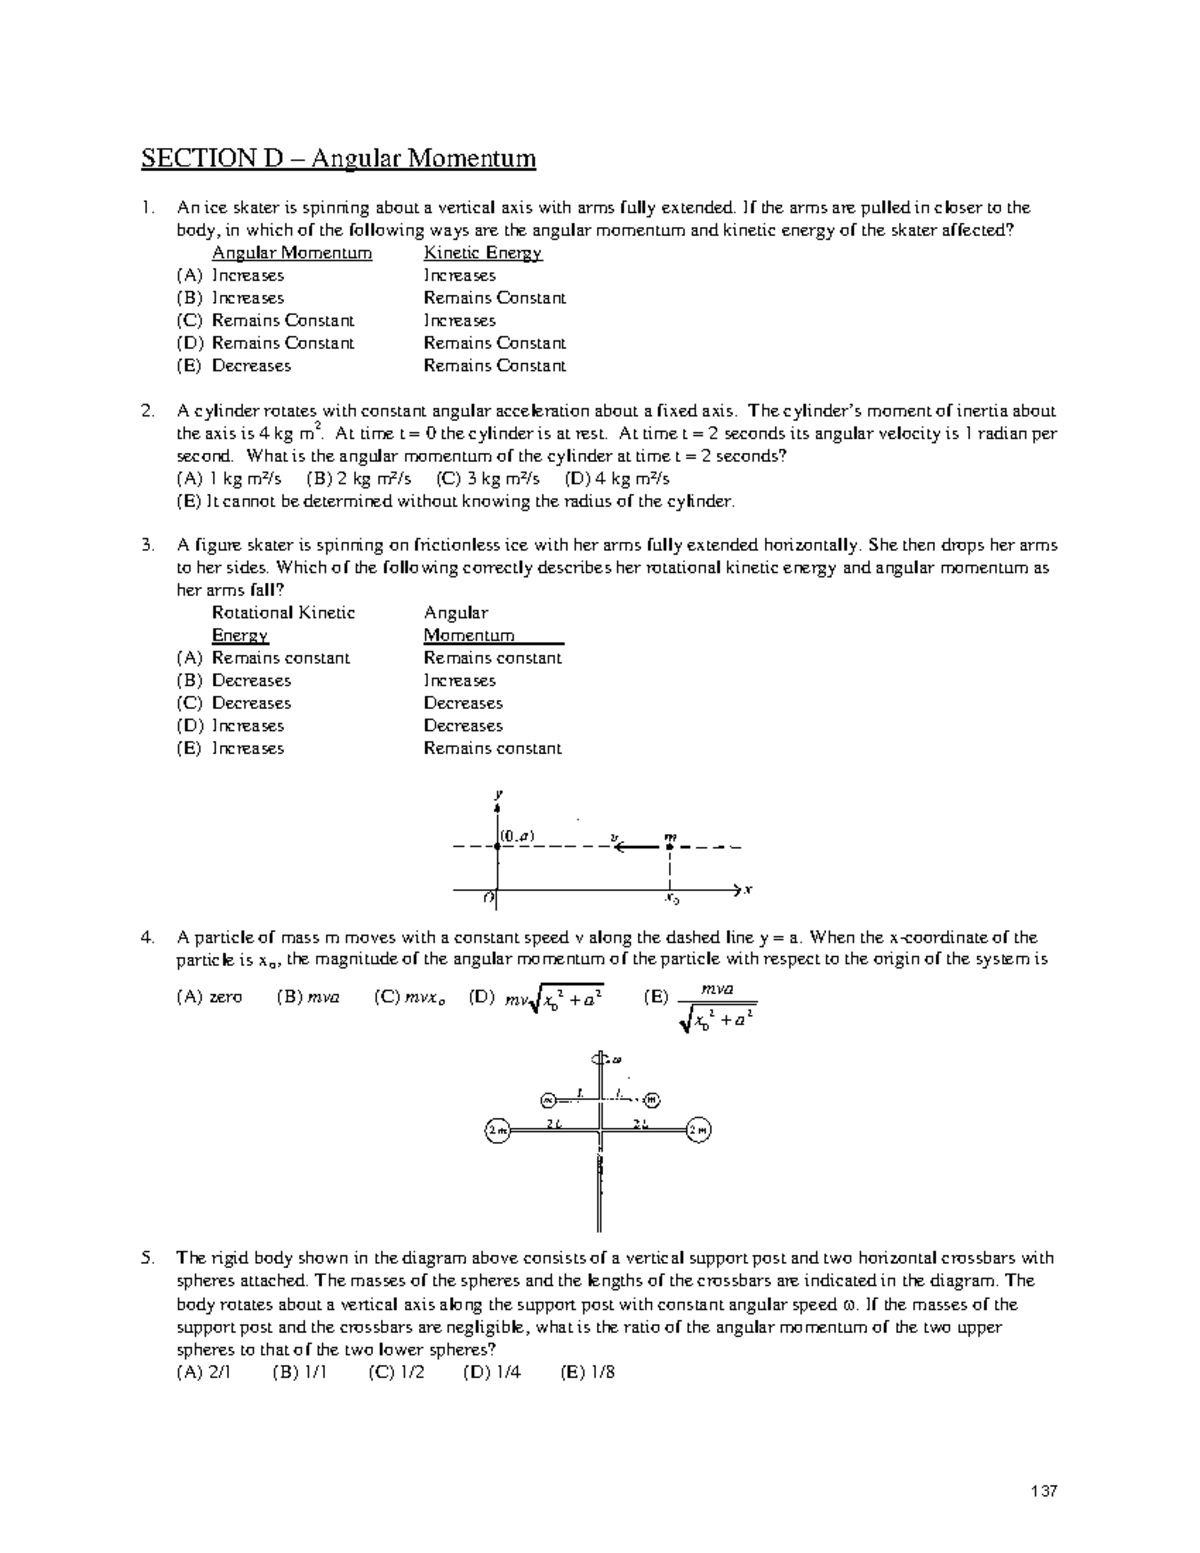
Angular Momentum Practice Problems
Here's the thing that nobody tells you early enough: angular momentum conservation only applies if the net external torque about your chosen origin is zero. Not about some point on the page. About the specific origin you're calculating from. This single fact ruins more solutions than any formula misunderstanding. I remember working through a problem where a block sliding on a frictionless table hit a pivoted rod, and every solution manual I checked used conservation of angular momentum about the pivot without questioning whether external forces at the pivot introduced a torque. They didn't, because the force acts at the origin, but a student who blindly applied L_i = L_f without checking would have gotten the right answer for the wrong reason, which means they'd fail when the pivot force had a tangential component. I started requiring everyone to write out the torque equation about their chosen origin before touching the angular momentum equation. It adds about thirty seconds per problem and prevents catastrophic errors later. The fundamental relationship is _net = dL/dt. When _net = 0 about a point, L is constant about that point. Period. The moment of inertia changes don't matter. Nothing matters except the torque condition.
For rotating rigid bodies, you'll use L = I, but I is not a single number you look up blindly. It depends on the axis of rotation, and switching axes without adjusting I is how people lose half their grade on exams. The parallel axis theorem, I = I_cm + Md², comes up constantly in practice problems, and it's almost always the step people skip or apply backward. Here's a problem type that causes consistent trouble: a spinning disk dropping onto another spinning disk. Two disks, different moments of inertia, different initial angular velocities, they press together and friction equalizes their rotation. The instinct is to use energy conservation. Don't. Energy is lost to friction during the slip phase. Use angular momentum conservation about the common axis, since the friction forces between the disks are internal to the system and produce no external torque. You get I + I = (I + I)_f, solve for the final common angular velocity, and then calculate the energy loss separately as the difference between initial and final kinetic energy. That energy loss is real and significant, usually around twenty to forty percent depending on the inertia ratio. Another scenario that shows up constantly: a particle hitting and sticking to a rotating object. Ballistic pendulum variations, mass striking a rod at an angle, things like that. The collision phase is where you conserve angular momentum, not linear momentum, because there's an external force at the pivot that makes linear momentum non-conserved. But the pivot force creates no torque about the pivot point itself, so angular momentum about that point is conserved during the instantaneous collision. After the collision, when the combined object swings up, you switch to energy conservation because the pivot force does no work (it's perpendicular to the motion) and gravity is conservative. Two separate conservation laws applied to two separate phases. Students who try to string it all together with one equation end up with garbage results.
Get the Full Details

Let me be blunt about where angular momentum methods fail completely. They don't help you with problems involving changing reference frames, like a rotating platform where the observer is also rotating. The fictitious torques from the Coriolis and centrifugal effects mean you need to be very careful about which frame you're working in. I've seen this come up in upper-level mechanics and engineering dynamics, and the fix is to either transform everything into an inertial frame first or explicitly include the fictitious torques in your torque equation. Neither option is straightforward, and sometimes the problem is better attacked with Lagrangian mechanics instead, which handles rotating coordinates more cleanly. There's also the issue of systems where mass is entering or leaving, like a rain-filled railroad car or a falling chain. The standard L = I formulation assumes constant mass distribution, and once mass starts changing, you need to fall back to the full = dL/dt in its differential form and account for the angular momentum carried by the incoming or outgoing mass. Most introductory practice problems avoid this, but it shows up in intermediate courses and it's a common source of confusion when people apply the simple conservation equation outside its valid range. When you're doing Angular Momentum Practice Problems, the most efficient workflow I've found is to sketch the system, label every external force, pick your origin, calculate the net external torque about that origin, and only then decide which conservation law applies. If the torque is zero, conserve L. If it's not zero but you know how the torque varies with time, you integrate dt to get the angular impulse, which equals the change in L. If the torque is unknown, you're probably looking at an energy problem instead, assuming only conservative forces are doing work.
I also recommend keeping a small reference sheet of common moments of inertia rather than deriving them each time. Solid sphere about center: 2/5 MR². Hollow sphere: 2/3 MR². Solid cylinder about central axis: 1/2 MR². Thin rod about center: 1/12 ML². Thin rod about end: 1/3 ML². Ring about center: MR². These come up in roughly eighty percent of practice problems, and spending two minutes deriving them during an exam is a waste you can't afford. The vector cross product in L = r × p is another place where people lose points unnecessarily. The magnitude is rp sin(), where is the angle between r and p. If the particle is moving directly toward or away from your origin, is zero or degrees, sin() is zero, and the angular momentum is zero regardless of how fast the particle is moving or how far away it is. This shows up in orbital mechanics problems constantly. A comet moving radially inward toward the sun has zero angular momentum only if you're calculating about the sun and the comet's velocity vector points exactly at the sun. Any slight offset and you have non-zero L, and that offset is what determines the orbit's shape. If you want to build fluency, start with problems where the axis is fixed and the moment of inertia is given, then move to problems where you have to compute I yourself, then to problems with multiple bodies interacting, and finally to problems where you have to choose the optimal origin to make the torque zero. The last category is the one that separates people who can solve these problems from people who can solve them efficiently.