Working With Angles in Standard Position
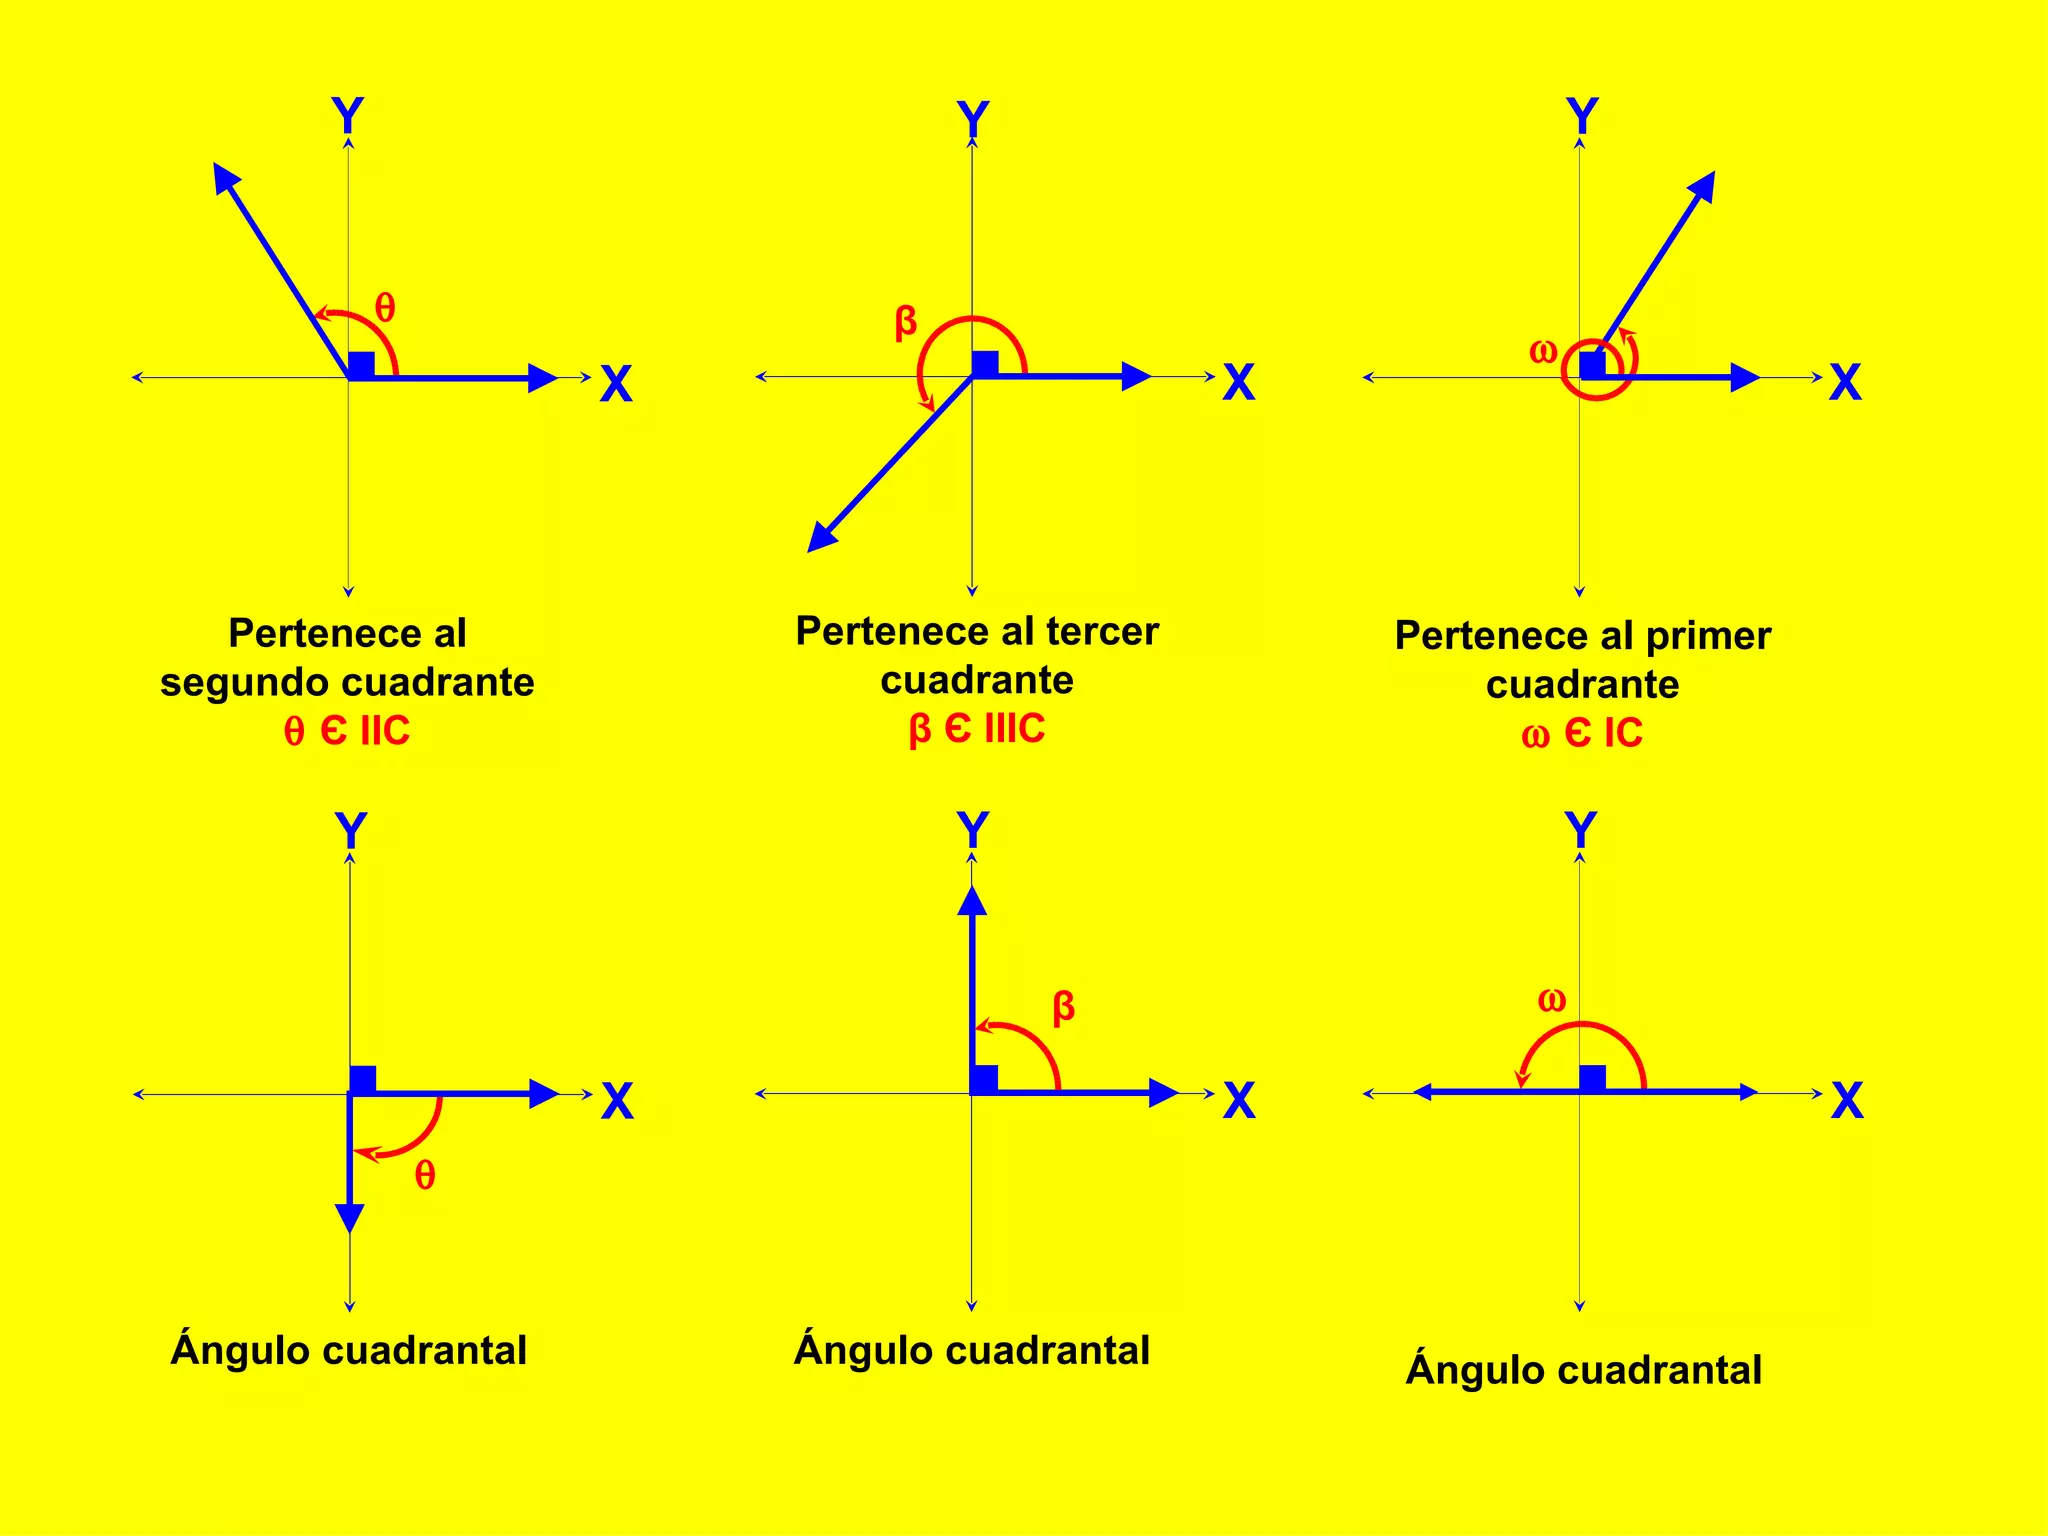
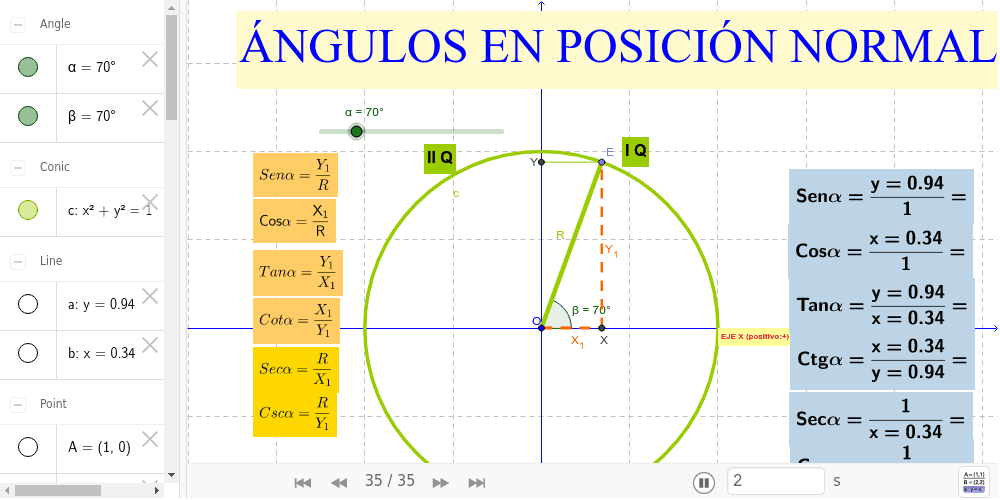
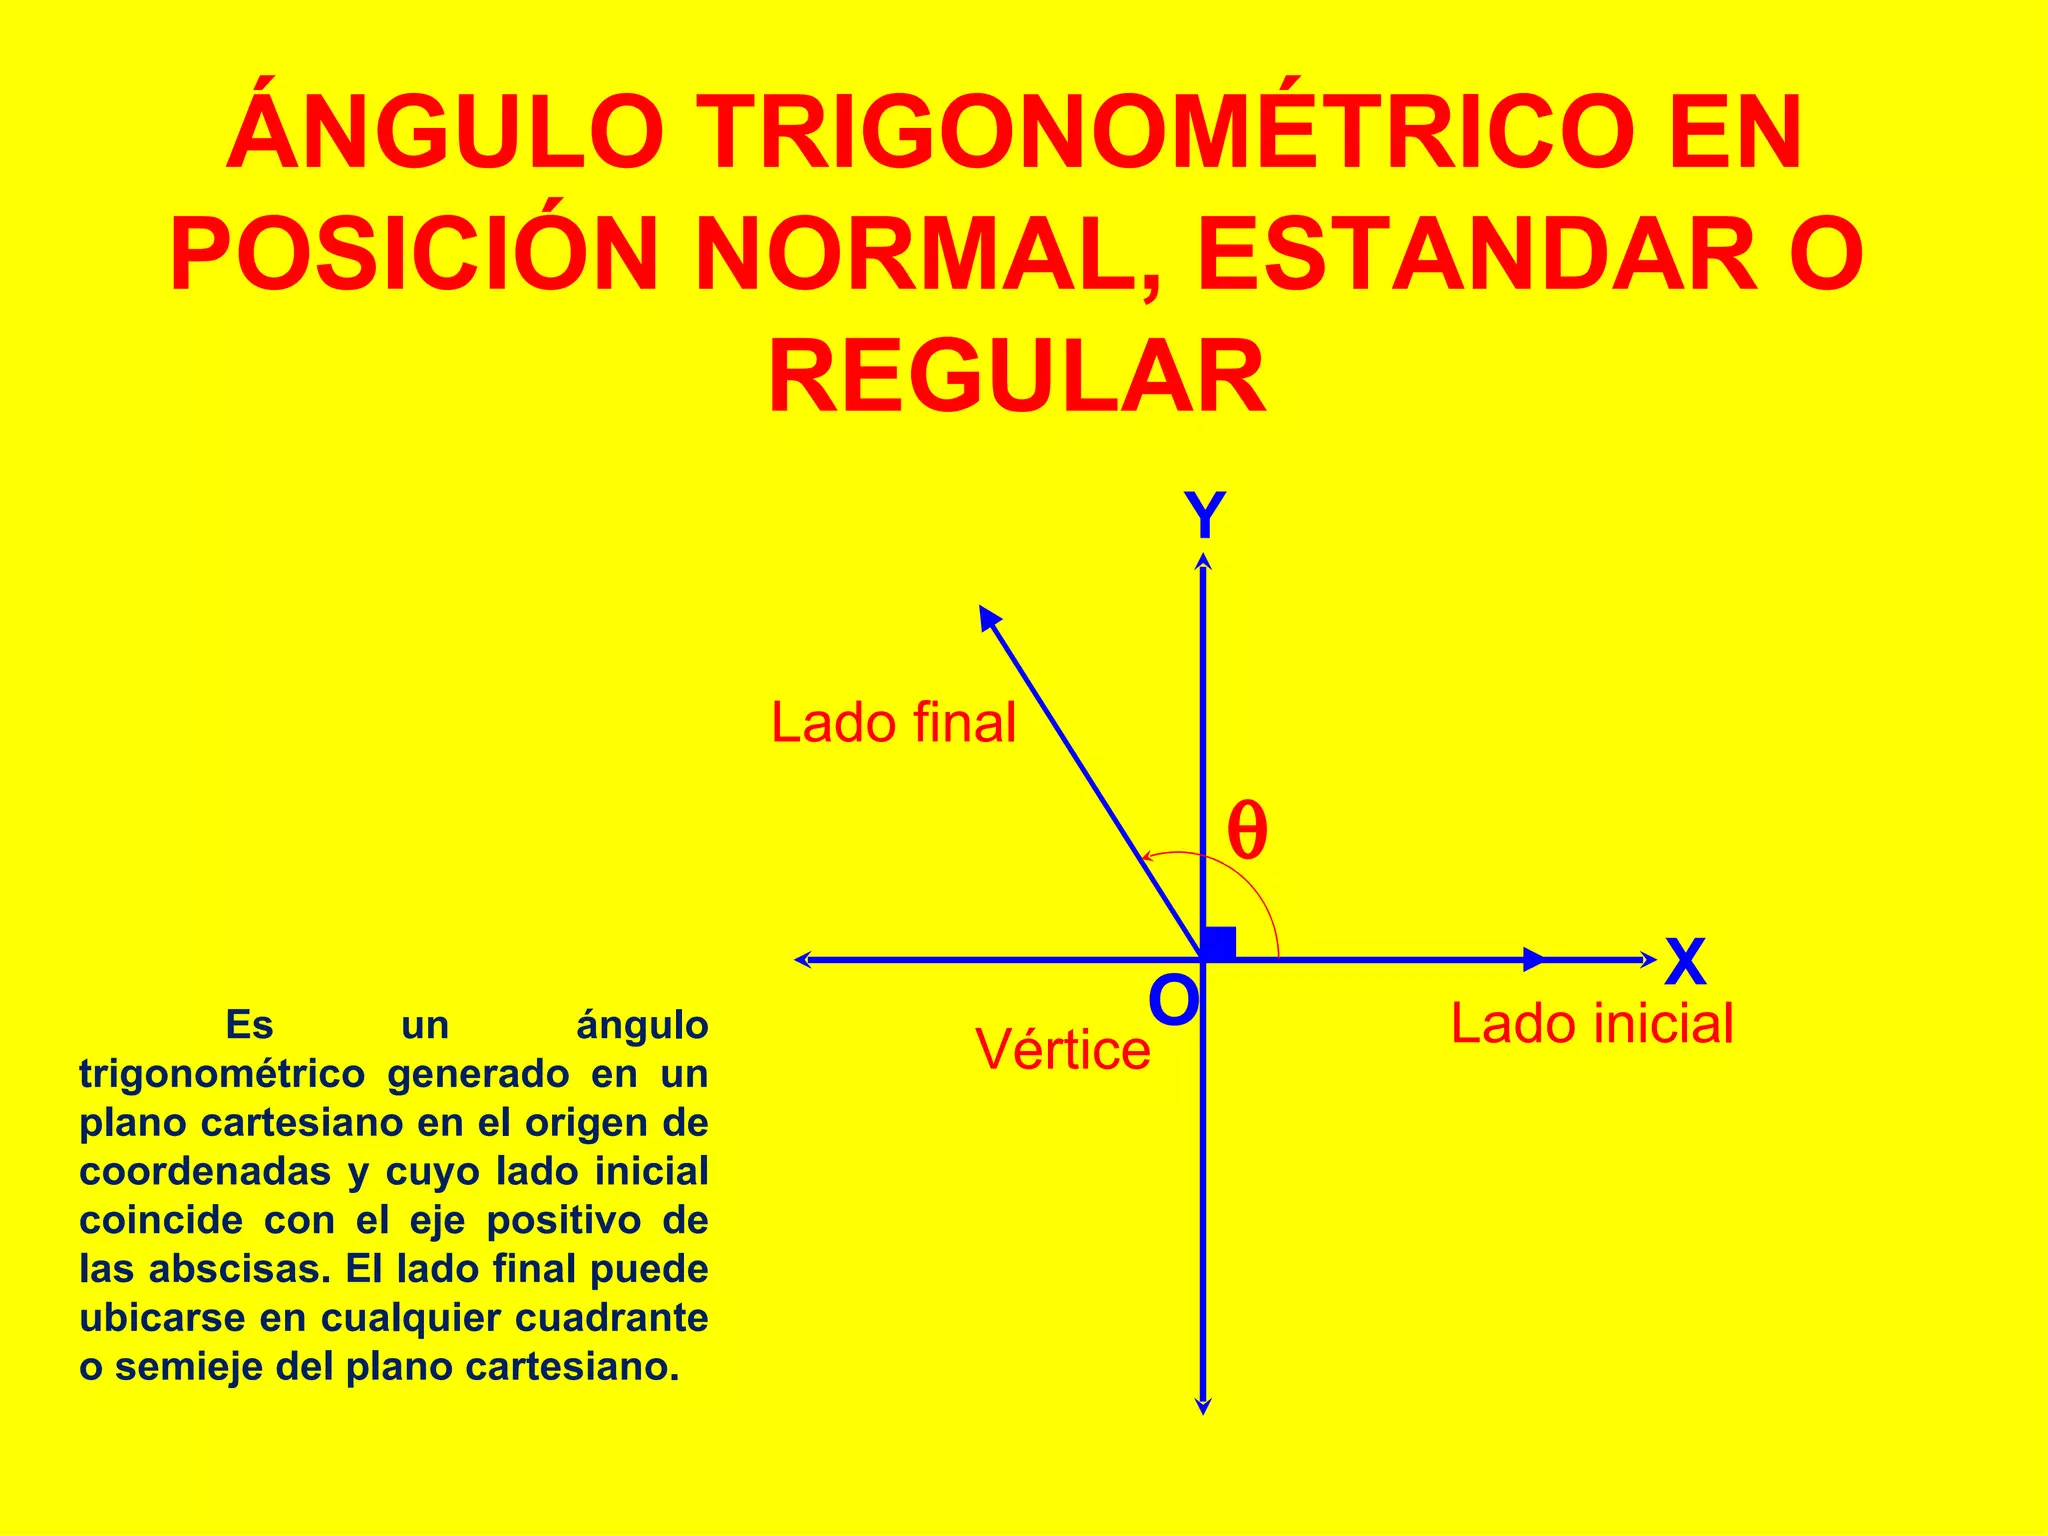
Most people first encounter Angulos En Posicion Normal in a high school trig class and think they have it figured out. The definition is simple enough — an angle sits in standard position when its vertex is at the origin and its initial side lies along the positive x-axis. From there, you just rotate the terminal side counterclockwise for positive angles and clockwise for negative ones. That is the textbook version. What actually happens when you try to use this in practice is a lot messier. When I say an angle like 150 degrees is in standard position, I mean exactly what the math says: vertex at (0,0), initial ray pointing right, terminal ray somewhere in the second quadrant. The unit circle comes into play immediately because that is where Angulos En Posicion Normal becomes useful rather than abstract. Any point on the unit circle at angle has coordinates (cos , sin ). Once you internalize that mapping, you stop treating trig functions as separate rules and start seeing them as coordinates on a circle. Reference angles are where most students stall out. A reference angle is the acute angle between the terminal side and the x-axis. For 150 degrees, the reference angle is 30 degrees. For 210 degrees, it is 30 degrees as well. For 315 degrees, it is 45 degrees. The sign of the trig function depends entirely on which quadrant the terminal side lands in, not on the reference angle itself. Quadrant one gives you positive values for everything. Quadrant two makes only sine and cosecant positive. Quadrant three flips tangent and cotangent positive. Quadrant four leaves cosine and secant positive. Remember SOH CAH TOA, but more importantly, remember the ASTC pattern for signs because that is what saves you when you are working through problems without a calculator.
Coterminal angles and why they matter
Two angles are coterminal when they share the same terminal side even though their measures differ by full rotations. You get coterminal angles by adding or subtracting multiples of 360 degrees or 2 radians. So 30 degrees, 390 degrees, and -330 degrees all sit in the exact same spot on the unit circle. In practice, this means you can always reduce any angle to an equivalent one between 0 and 360 degrees before looking up values or evaluating functions by hand. It also means that when you are solving trig equations, you frequently have to list all coterminal solutions within a given interval instead of settling on a single answer. I ran into a concrete issue with this a few years ago while working on a robotics calibration problem. The angle sensor on one of the joints was reporting values in the range of -720 to +720 degrees because the arm had multiple full rotations during a test cycle. When I tried to feed those raw readings directly into a kinematics equation that expected standard position angles, everything came out wrong. The workaround was straightforward but easy to miss if you are not paying attention: I reduced every reading modulo 360 first, then checked the sign convention against the mechanical zero point of the robot. That single step of normalization — converting Angulos En Posicion Normal back into their principal range — cleaned up the entire dataset and cut debugging time from about three days down to roughly an afternoon.
Converting between degrees and radians in standard position
You will work in both systems and you need to be comfortable switching without second-guessing yourself. To convert degrees to radians, multiply by /180. To convert radians to degrees, multiply by 180/. The angles you will see repeatedly are 30, 45, and 60 degrees, which correspond to /6, /4, and /3 radians respectively. If you can memorize the unit circle values for these three angles plus their quadrant reflections, you can evaluate almost every standard problem without reaching for a table. The counter-intuitive part that nobody emphasizes enough is that standard position angles do not care about the length of the terminal side. Whether the terminal ray passes through the point (3, 4) or (300, 400), the angle measure is identical. What changes is the distance from the origin, not the direction. This is why similar triangles show up everywhere in trig and why the ratios stay constant regardless of scale. It also means that when you are given a point on the terminal side and asked to find all six trig functions, you need to compute the radius r first using the Pythagorean theorem, then plug into the definitions: sine is y/r, cosine is x/r, tangent is y/x, and so on.
Get the Full Details
Common pitfalls and what actually goes wrong
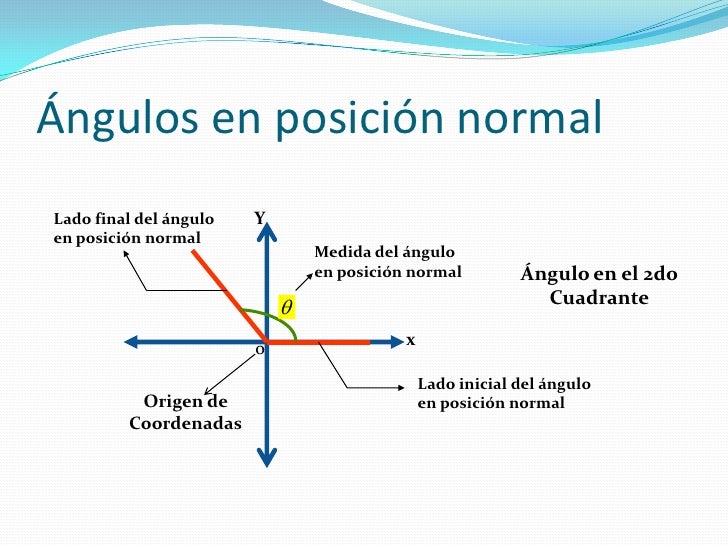
The most frequent mistake I see is mixing up the initial side with the terminal side when sketching angles. People draw the terminal side along the x-axis and the initial side rotating, which is backwards. The initial side is always fixed along the positive x-axis in standard position. The rotation happens to the terminal side. Getting this wrong throws off every quadrant and sign judgment that follows. Another issue is assuming that an angle like -45 degrees is the same as 45 degrees in terms of trig values. They are not. Negative angles rotate clockwise, so -45 degrees lands in the fourth quadrant while positive 45 degrees lands in the first. The cosine values happen to match because cosine is even, but the sine values are negatives of each other. Students who skip the quadrant check end up with sign errors that propagate through the entire problem set. There is also a limitation worth noting upfront. Standard position angles work beautifully for planar geometry and two-dimensional vector problems. They break down quickly when you move into three-dimensional space, spherical coordinates, or rotational dynamics where you need Euler angles or quaternions. In those contexts, the simple idea of rotating a ray around an origin becomes inadequate and you need a different framework. If your work stays in two dimensions, Angulos En Posicion Normal is all you need. If it expands beyond that plane, you will hit the ceiling of this approach and need to switch tools.
A practical workflow for solving problems
When I work through a problem involving angles in standard position, I follow a routine that avoids most of the traps. First, I identify whether the angle is given in degrees or radians and convert it to the system I am working in. Second, I reduce it to its principal range if it is outside 0 to 360 degrees or 0 to 2 radians. Third, I determine the quadrant and the reference angle. Fourth, I evaluate the trig functions using the reference angle values and apply the correct signs based on the quadrant. Fifth, I double-check my answer by estimating whether the magnitude makes sense — for example, a sine value larger than 1 or smaller than -1 is an immediate red flag. This process usually takes me about two minutes for a standard problem and about five minutes when the angle is unusual or the problem involves solving an equation rather than just evaluating a function. The time savings come from not second-guessing the quadrant or the sign, which is where most of the wasted effort goes. If you want a quick reference sheet or a printable unit circle chart, there are plenty of free resources online. Search for "unit circle standard position angles pdf" and you will find sheets that list degree-radian equivalents alongside the exact trig values. I use one myself and keep it open whenever I am working through problems that involve non-standard angles like 75 degrees or 105 degrees, where you need to apply sum and difference identities rather than memorized values.