Getting real control out of a robot isn't about writing good code. It's about the chip sitting under your feet.
I spent three years debugging why a pick-and-place arm would randomly drop its last 0.3 millimeters during the closing phase. Turns out the stepper driver was sharing a ground trace with the ultrasonic range finder on the same PCB layer. When the distance sensor pulsed, the voltage dip on the ground rail caused the motor controller to skip a microstep. The fix was a star-ground layout with separate analog and digital planes, plus a ferrite bead between them. Cost me about two weeks of my life. This is what embedded systems in robotics actually look like. Not the fancy demos you see at conferences. The boring electrical engineering that keeps the machine from doing something unpredictable when the factory floor gets hot or the power supply sags.
Where Applications Of Embedded Systems In Robotics Actually Matter
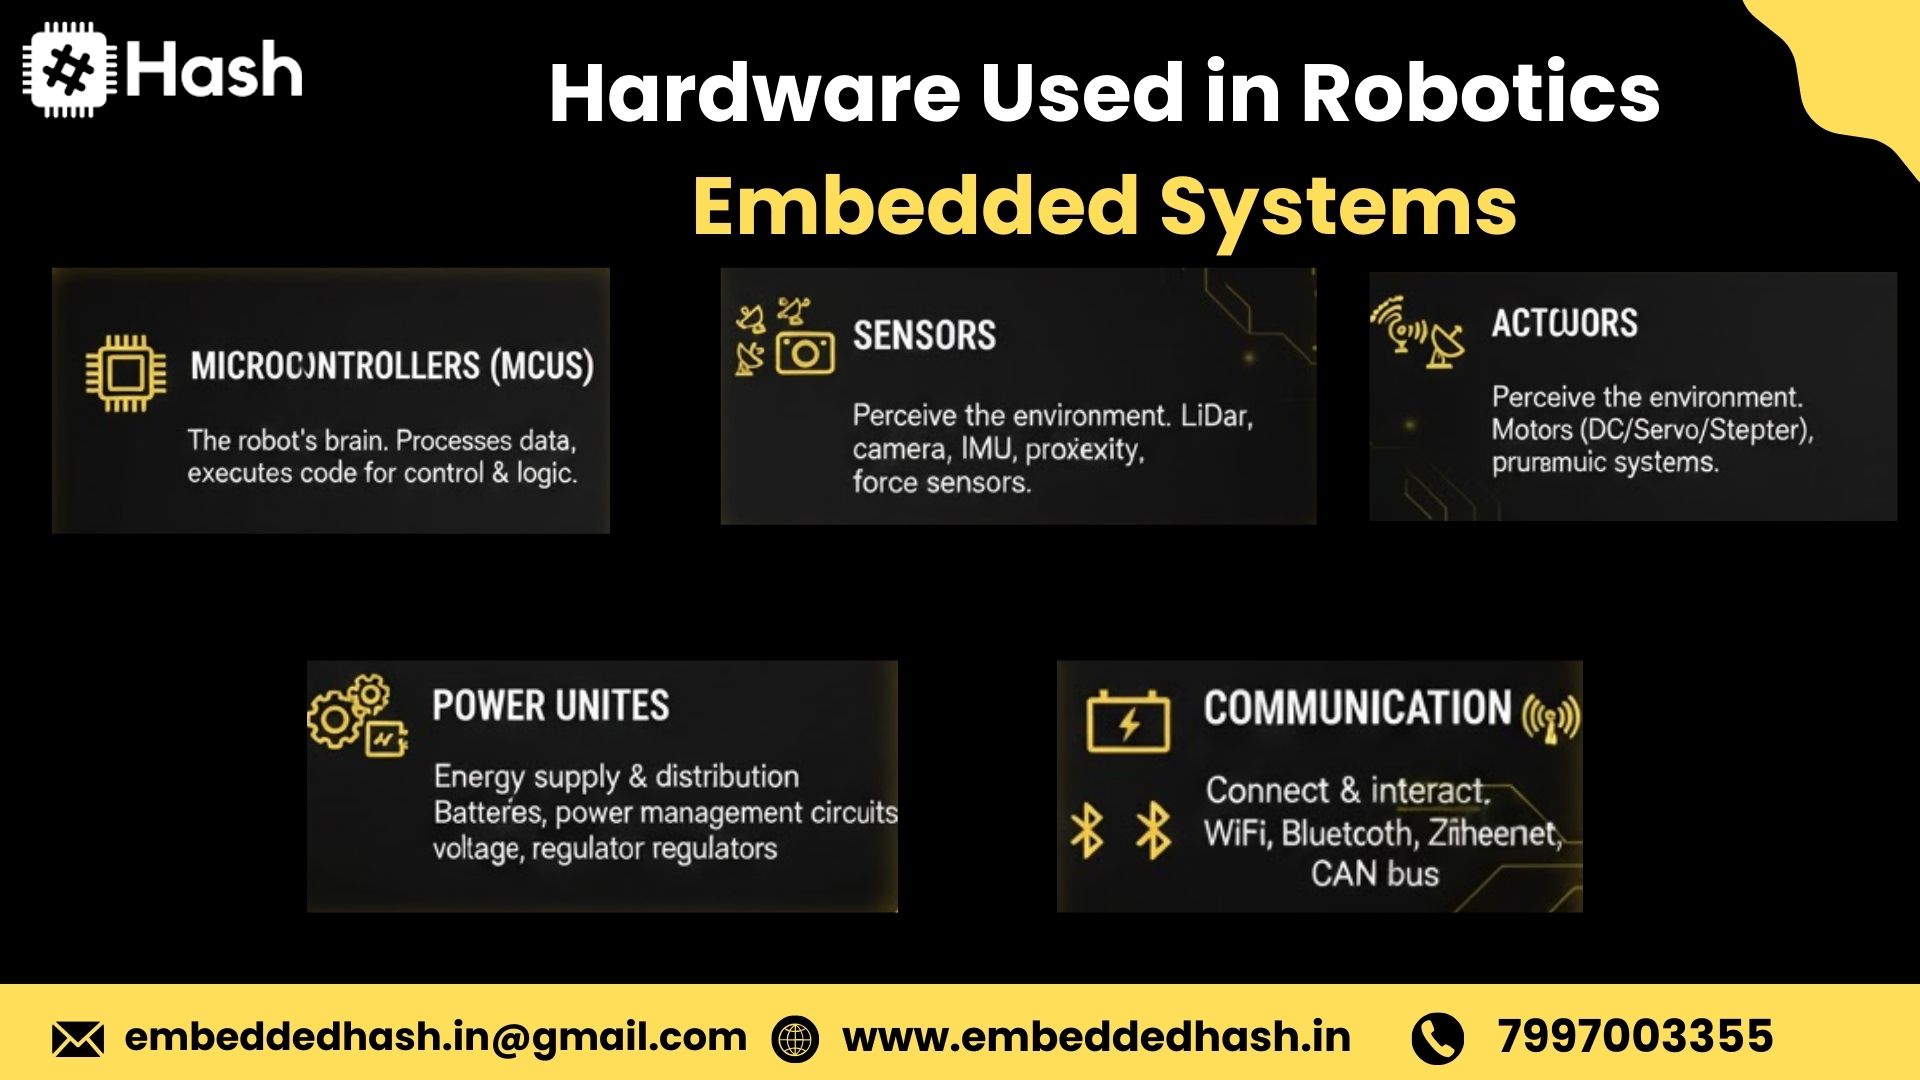
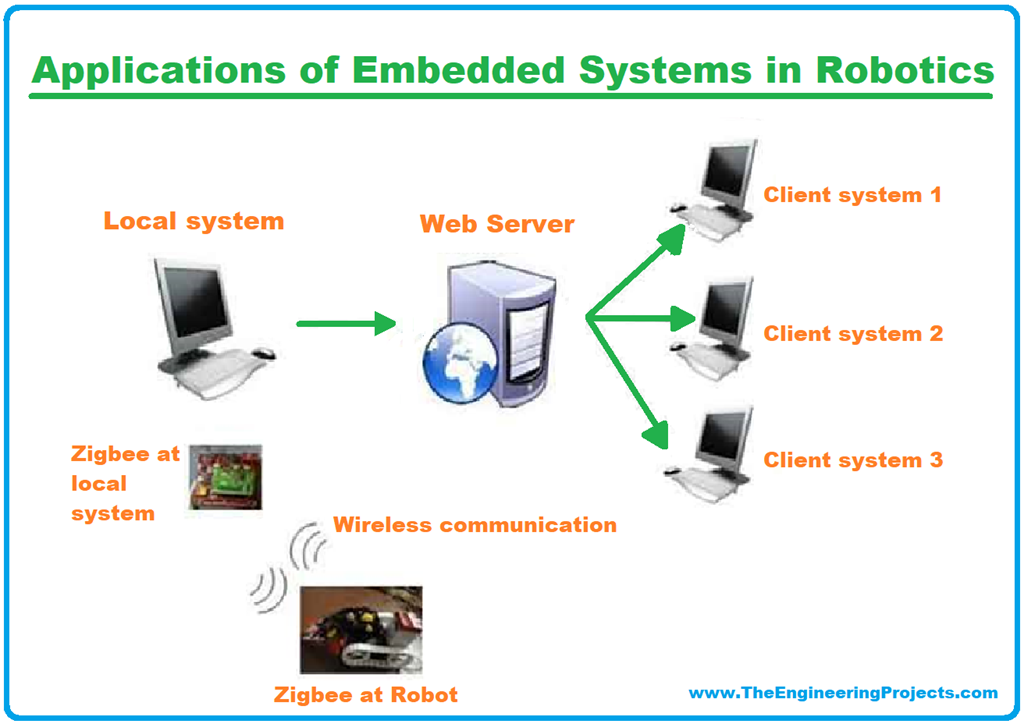
Robotic platforms range from $50 hobbyist kits to $2 million industrial arms. The embedded architecture changes dramatically across that spectrum, but the core problem stays the same: you need deterministic timing, low latency, and hardware that won't restart because someone bumped the ethernet cable. The most common deployment I've seen is a dual-controller setup. A real-time microcontroller handles motion control, safety interlocks, and sensor polling at 1 kilohertz or faster. A general-purpose computer runs perception, planning, and communication. They talk over CAN bus or EtherCAT. This separation matters because Linux isn't real-time. Period. No amount of PREEMPT_RT patching will give you sub-millisecond jitter on a standard x86 system under network load. Microcontroller choices depend on the application. For simple agvs or wheeled platforms, an STM32 or ESP32 handles everything. For high-payload industrial robots, you'll see Xilinx FPGAs alongside ARM cores. The FPGA manages the servo loops and safety watchdogs while the processor runs higher-level logic. I've worked on systems where the safety circuit was entirely hardware-based—a separate MCU monitoring the main controller's heartbeat, with physical relay outputs that cut motor power in under 10 milliseconds if the software goes weird.
The sensor fusion problem nobody warns you about
Here's something beginners miss: sensor data arriving "in sync" doesn't mean it's temporally aligned. An IMU at 1 kilohertz, a LiDAR at 10 hertz, and a camera at 30 frames per second all have different latencies and clock drift. If you naively merge them without accounting for the robot's motion between samples, your state estimate will lag behind reality. The workaround is hardware timestamping. Every sensor driver should tag measurements with a timestamp from a common clock source, not the host CPU time. On a Raspberry Pi, that means using the GPIO hardware timestamp registers. On embedded Linux with a custom board, you route sensor interrupts through a common FPGA block that stamps them. I had a situation where a mobile manipulator's end-effector position drifted by 5 centimeters over 30 seconds because the wheel encoders and IMU were using different clock domains with unaccounted drift. The fix was a simple extended Kalman filter with proper process noise modeling, but getting it right required understanding that wheel slip and IMU bias are correlated through the robot's dynamics, not independent disturbances.
Get the Full Details
Power management in autonomous robots
People think about processing power first. They shouldn't. Power delivery determines what sensors you can run, how long the robot operates, and whether the whole system crashes when a motor draws a current spike. A typical mobile robot with LiDAR, cameras, and a gripper draws 50 to 200 watts under normal operation. Motors can spike to 500 watts or more for brief periods. Your power budget needs to handle those transients without brownouts. I've seen robots restart mid-task because someone used a power supply rated exactly at the average current draw, forgetting about inrush and motor stall currents. The solution is a bulk capacitance stage plus a dedicated motor power rail. A 10,000 microfarad capacitor bank at the battery terminals absorbs transients. Separate the motor and logic grounds, tie them at a single point near the battery. Use a DC-DC converter with good transient response for the sensitive electronics, not a linear regulator that wastes power as heat.
For battery management, cell balancing matters more than capacity ratings. A 50 amp-hour pack where one cell is weaker than the others effectively becomes a 30 amp-hour pack. Active balancing circuits extend pack life, but even simple passive resistor balancing beats doing nothing. I replaced a robot's $800 battery pack with a rebuilt unit using matched cells and got 40 percent more runtime because the original pack was being limited by its weakest cell.
Safety systems and why they need to be simple
Functional safety standards like ISO 13849 and IEC 61508 exist for a reason. Robotics embedded systems that interact with humans need proven safety architectures. The counter-intuitive part: the safest systems often use the simplest controllers for safety functions. A dedicated safety PLC or a microcontroller running a bare-metal safety loop is more reliable than a Linux system with a safety layer. Why? Because the safety system shouldn't depend on an operating system, a driver stack, or a network protocol. Hardwired emergency stop circuits, physical limit switches, and a safety monitor that checks position bounds independently of the main controller—that's the pattern that works. I designed a safety system for a collaborative assembly robot where the main arm controller could command positions, but a separate safety unit monitored actual position from encoders and would cut power if the arm exceeded expected bounds. The safety unit ran on a separate power supply with its own fuse. It had no network connection to the main controller. Simple, isolated, and effective.
Common embedded pitfalls in robotic systems
Thermal management often gets ignored until something fails. A processor running thermal throttling loses deterministic performance. I've seen pick-and-place robots slow down during summer because the CPU hit its thermal limit and throttled, causing cycle time variations that broke downstream quality checks. Heat sinks and forced air cooling on processors and motor drivers aren't optional for production systems. Vibration isolation matters for sensor mounts. An IMU bolted directly to a motor mounting bracket picks up structural resonance that looks like robot motion. The fix is rubber isolation mounts and filtering the vibration frequencies out of the sensor data. I spent a week diagnosing what I thought was a controller tuning problem before realizing the accelerometer was measuring table vibration, not robot acceleration. Cable management and connector selection affect reliability more than software bugs. Industrial robots move cables thousands of times. Standard ribbon cables and hobbyist connectors fail under flex cycling. Use strain relief, tuck cables into carrier chains, and specify connectors rated for the expected mating cycles. I replaced 20 failed USB connections on a mobile robot's camera mount—USB isn't designed for dynamic applications, and nobody tells you that until it breaks.
Debugging embedded robotic systems
The hardest part of working with embedded robotics isn't making it work. It's figuring out why it worked sometimes and not others. Race conditions, memory corruption, and timing issues are nearly impossible to reproduce in a lab but show up constantly in the field. Logging is essential, but log volume creates problems. I use structured logging with timestamps synced to hardware clocks, writing to an SD card or solid-state storage, not a mechanical drive. Ring buffers that don't overwrite recent data are critical—if the system crashes, you need the last ten seconds of state, not data from an hour ago. Hardware-in-the-loop testing saves time. Building a test rig where you can inject sensor failures, command impossible trajectories, and observe the embedded system's response without risking actual equipment. I built a simple rig using an Arduino to simulate encoder feedback and a programmable power supply to create voltage sag conditions. Found three failure modes in a week that would have taken months to discover in the field.
Version control for embedded systems applies to more than source code. Pin hardware revisions, bootloader versions, and sensor firmware alongside application code. A "works on my machine" problem often traces back to a sensor driver update that changed timing characteristics. Document what version of everything is running on each deployed robot.
Getting started with embedded robotics
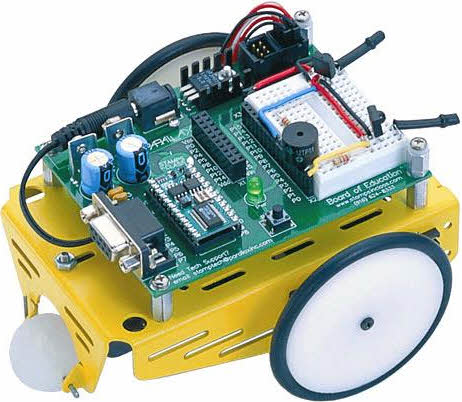
Start with something simple. A line-following robot or a basic articulated arm teaches the fundamentals without overwhelming complexity. Use an Arduino or similar platform to understand real-time control before moving to Linux-based systems. Learn to read datasheets. The manufacturer's documentation contains timing specifications, electrical characteristics, and application notes that aren't in tutorials. When I specify a microcontroller for a new project, I spend more time reviewing electrical specifications and recommended operating conditions than reading example code. Understand the difference between polling and interrupt-driven designs. Simple projects often use polling, but as complexity increases, interrupts and DMA become necessary to meet timing requirements. A well-designed interrupt service routine takes microseconds and returns quickly. One that runs for milliseconds creates the very jitter it was supposed to avoid.
Build a basic communication link between a microcontroller and a host computer. CAN bus is widely used in robotics for good reason—it's robust, deterministic, and supports multiple nodes on a single pair of wires. I've also used RS-485 for longer distances and Ethernet for high-bandwidth applications. Each has tradeoffs in cost, complexity, and performance.
The state of the art isn't what matters most
New embedded processors and development boards release constantly. The ones that matter are the ones you can source reliably, that have stable toolchains, and that your team knows well. I've seen projects delayed by months because a new microcontroller was announced, the team wanted to use it, and then supply chain issues made procurement impossible. Older platforms like the AVR family, older STM32 parts, and even some legacy ARM processors remain relevant because they work. They're documented. They're available. Switching to a newer part rarely provides enough benefit to justify the risk. Open-source toolchains and hardware designs have improved significantly. PlatformIO, STM32CubeIDE, and similar tools provide professional-grade development environments at no cost. Hardware designs from companies like ST, NXP, and Microchip are well-supported and freely available. You don't need expensive proprietary tools to build production-quality robotic embedded systems.
The field moves fast, but the fundamentals don't change. Deterministic timing, proper power design, robust communication, and simple safety systems. Master those and the specific platform choices become less important than understanding what problem you're solving.