Partial Differential Equations Are Just Your Baseline
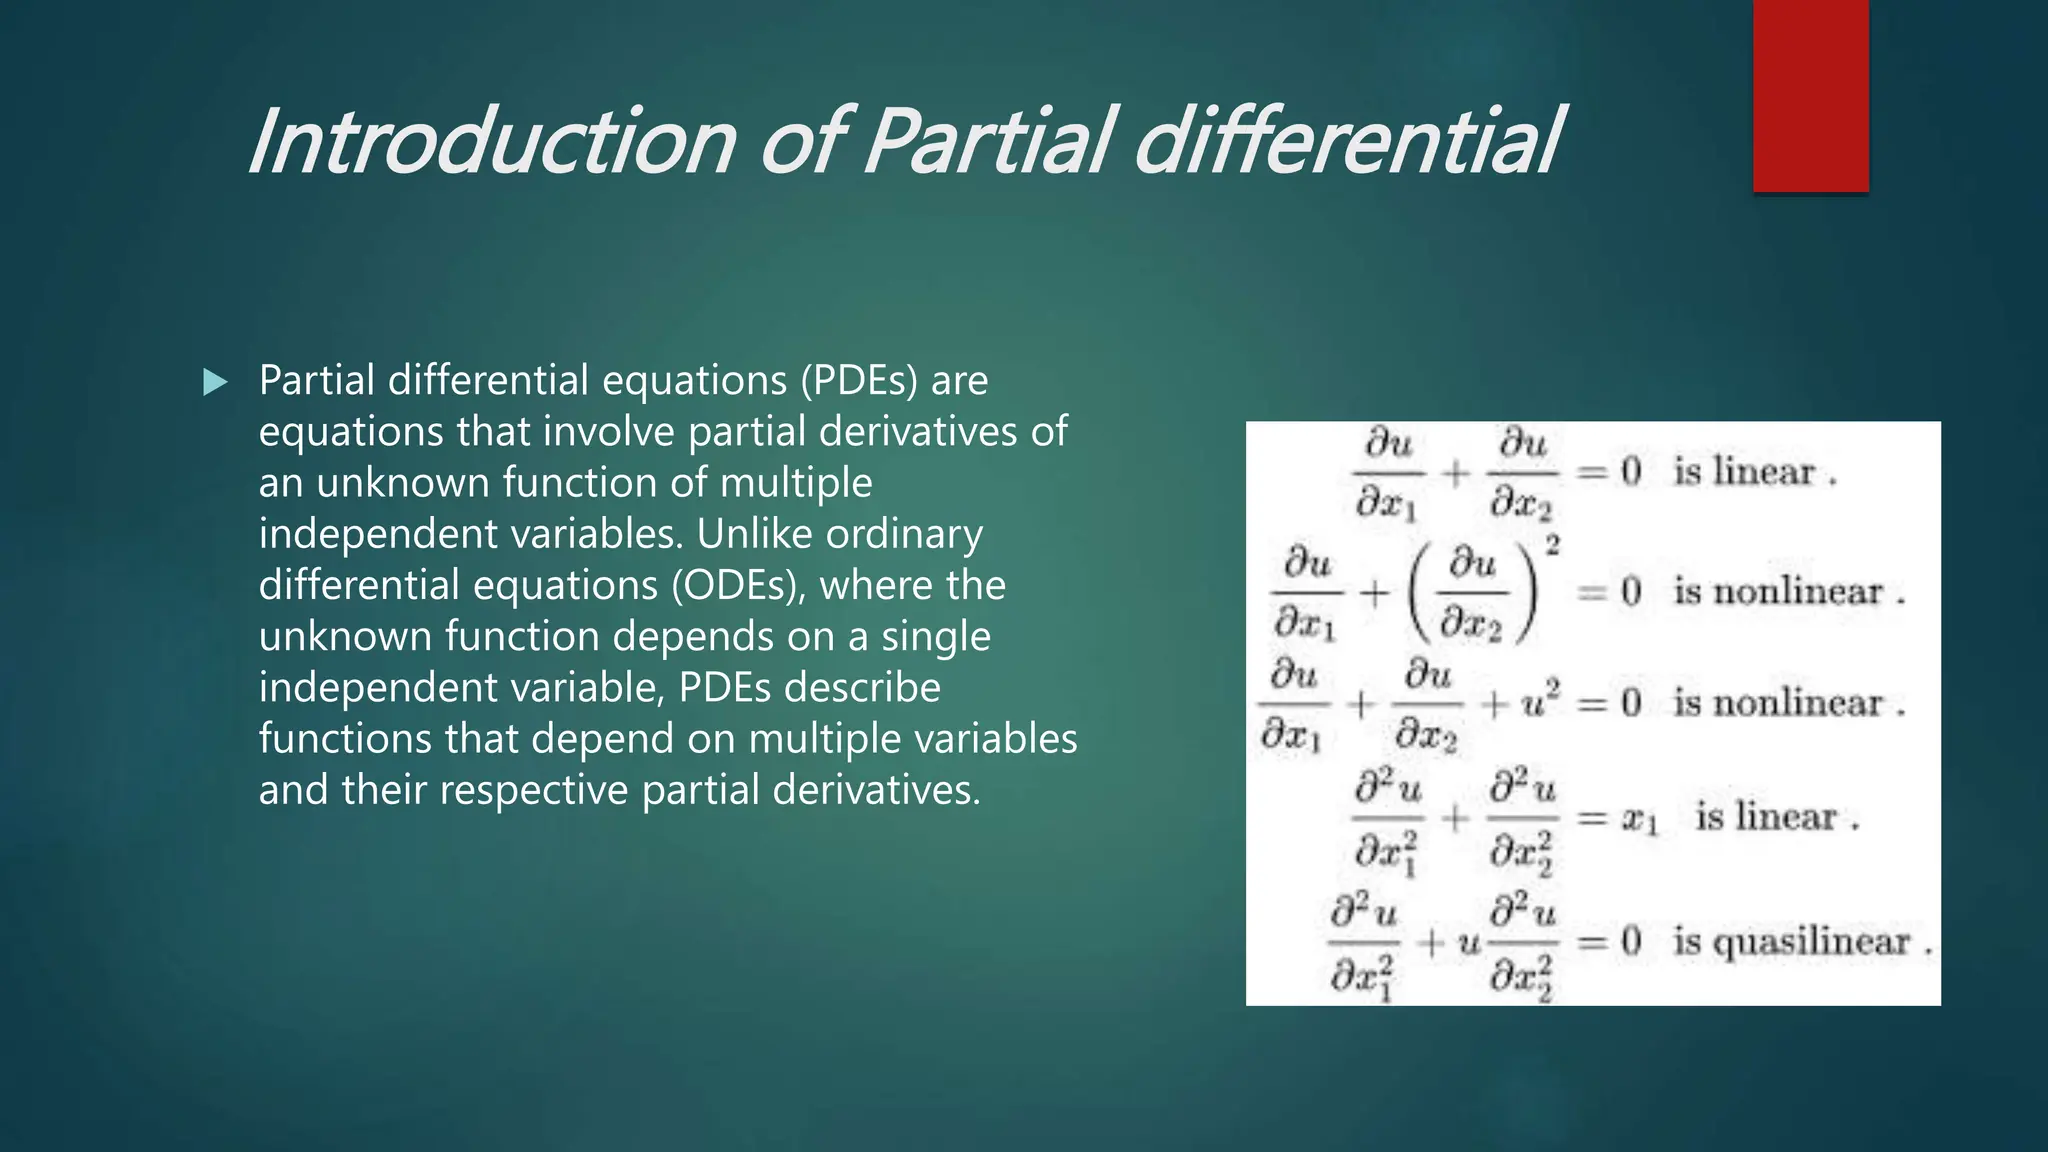
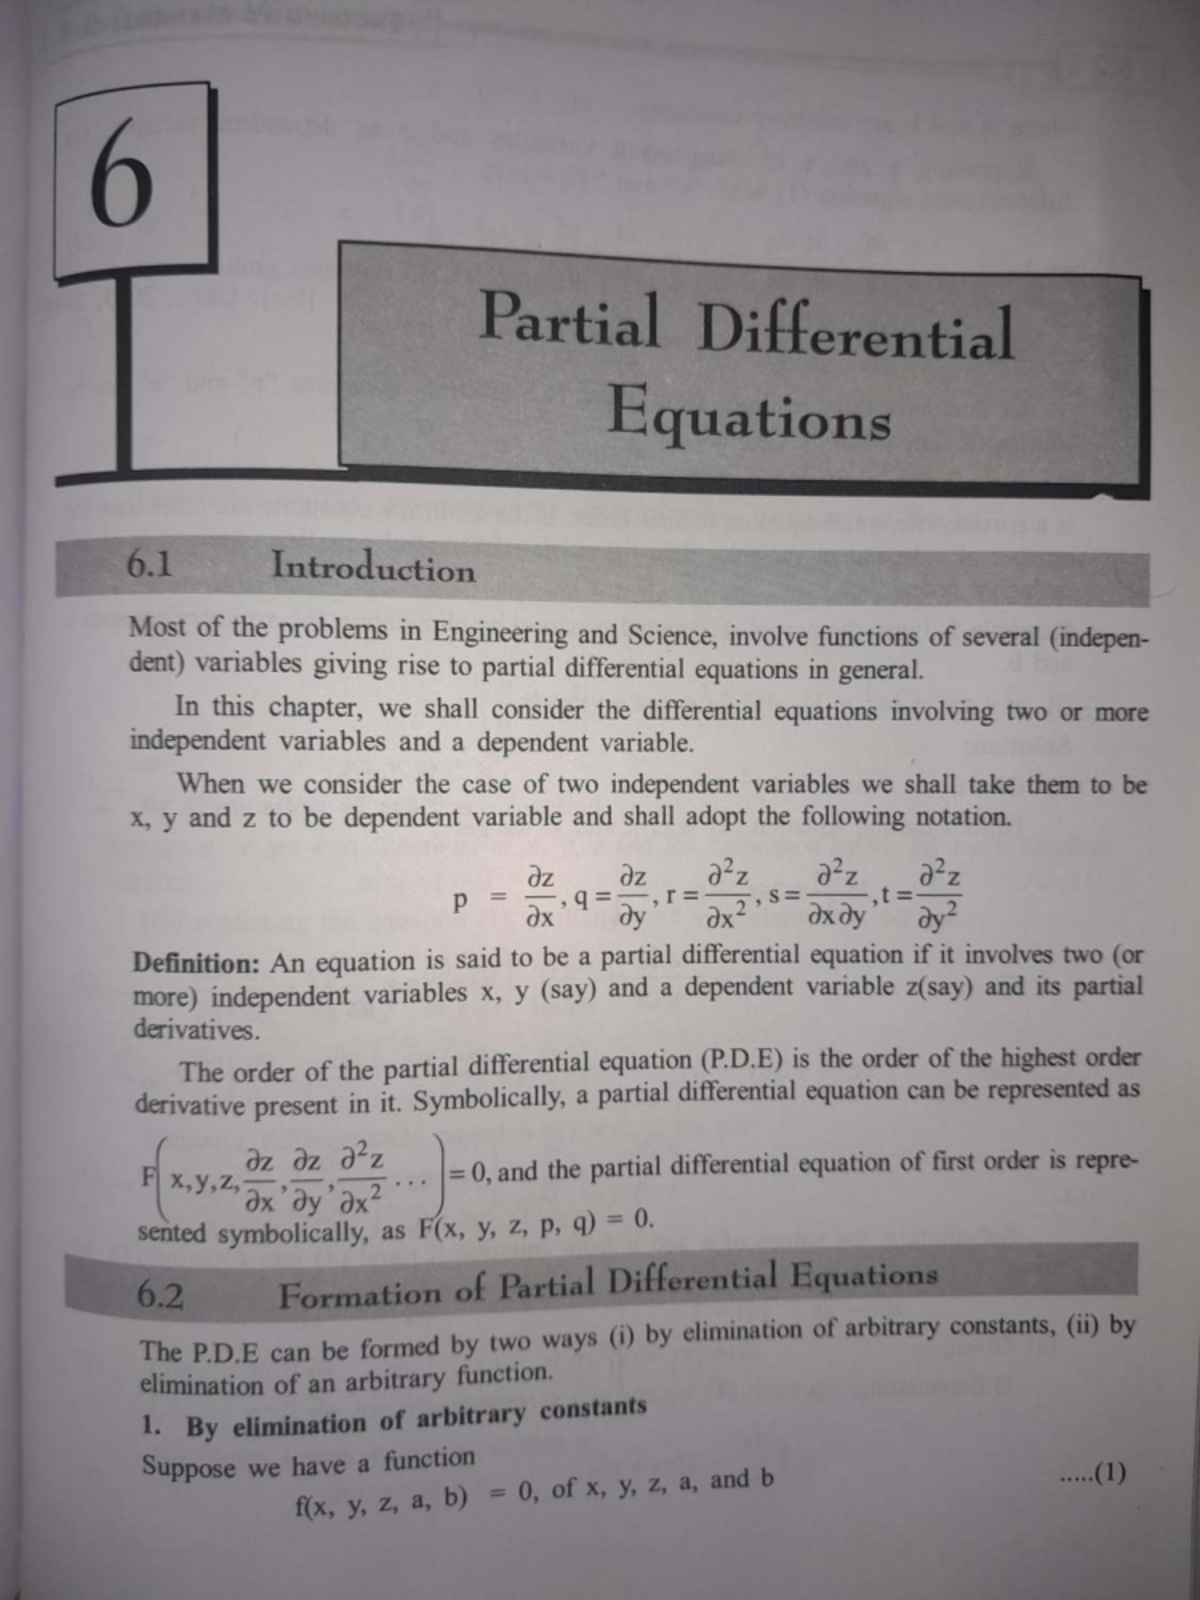
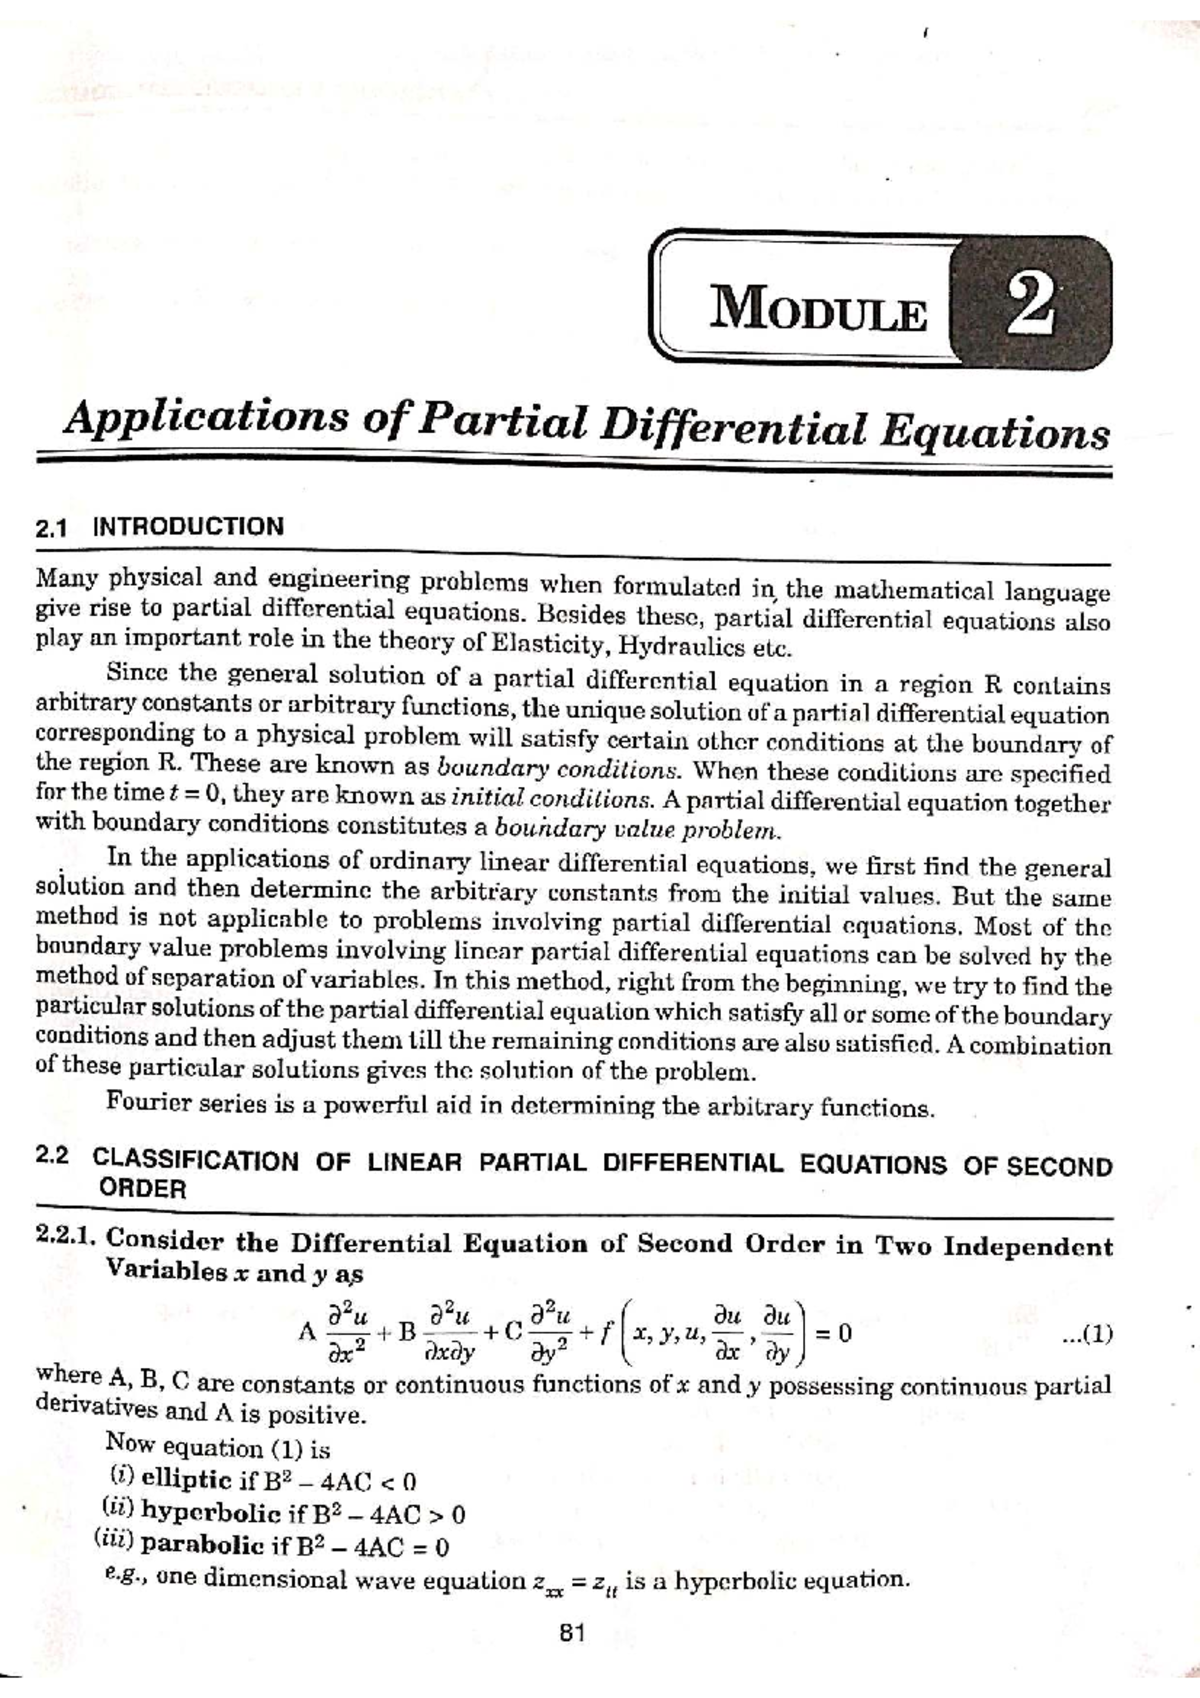
Most engineering students learn PDEs as an abstract math course before they ever see one used in anger. The reality is that applications of partial differential equations in engineering show up constantly, usually when something changes across space and time simultaneously. Heat moves through a weld joint. Stress propagates through a beam during vibration. Fluid moves through a pipe network. Each of these is a PDE problem, even if your simulation software hides the math behind a clickable button. The most common PDEs you will encounter are the heat equation, the wave equation, and Laplace's or Poisson's equation. The heat equation, ut = ²u, describes temperature distribution over time. It is parabolic. The wave equation,utt = c²²u, describes vibration and acoustic propagation. It is hyperbolic. Laplace's equation, ²u = 0, is elliptic and shows up in steady-state problems like electrostatic fields or incompressible potential flow. Knowing which category a problem falls into matters more than most people realize because it determines which numerical method will actually work for you. I spent years working on thermal analysis for electronic packaging, and one problem stands out. We were simulating heat dissipation through a multi-layer PCB with vias and copper pours. The textbook approach would be to use finite element method with a structured mesh and run a transient thermal simulation. That worked fine until we started seeing non-convergence at thermal interface material boundaries where the conductivity changed by a factor of fifty across a two-millimeter gap. The solver would oscillate and blow up. What I ended up doing was switching to a finite volume formulation with harmonic averaging of the conductivity at cell faces instead of arithmetic averaging. The harmonic mean respects the physics of series thermal resistance across discontinuous materials. It cut our solve time from about four hours per iteration down to roughly twenty minutes on the same hardware, and the temperature predictions matched our thermocouple measurements within two degrees Celsius.
Choosing The Right Discretization Method
There are three main numerical approaches for solving PDEs in engineering practice: finite difference, finite element, and finite volume. Each has its trade-offs and I have used all three extensively enough to have strong opinions about when each one fails. Finite difference is the simplest to implement and easiest to understand. You approximate derivatives using Taylor series expansions on a structured grid. It works well for regular geometries and straightforward boundary conditions. The moment your geometry gets complex, finite difference becomes painful because you need coordinate transformations or body-fitted grids, and those introduce their own errors. I have seen people try to use finite difference on irregular turbine blade geometries and end up with solutions that looked right but were numerically unstable near the curved boundaries. It took three days of debugging to realize the grid quality was the issue, not the code. Finite element method is the most widely used in structural and multiphysics simulations. It works by dividing the domain into elements and approximating the solution with basis functions within each element. The weak form formulation handles complex geometries and boundary conditions naturally. The downside is that it requires assembling large sparse matrix systems, and the conditioning of those systems can be terrible if your mesh quality is poor. Elements with high aspect ratios or inverted elements will destroy your solver convergence. I once had a linear static structural simulation fail to converge because a single tetrahedral element in a mesh of two million had a negative Jacobian. Finding it required writing a script to check element quality metrics across the entire mesh, which took about six hours to run on a decent workstation.
Finite volume method conserves quantities locally by integrating the PDE over each control volume. This makes it especially popular in computational fluid dynamics where conservation of mass, momentum, and energy is non-negotiable. The method is robust for hyperbolic systems and handles discontinuities like shocks reasonably well. The trade-off is that second-order accuracy requires reconstruction schemes, and if you pick the wrong limiter you will get either excessive numerical diffusion or spurious oscillations near steep gradients. MUSCL reconstruction with a minmod limiter is a safe default, but it adds computational cost compared to first-order upwinding. In practice, the extra accuracy usually pays for itself within a couple of iterations.
Get the Full Details

Boundary Conditions Are Where Things Break
People obsess over mesh quality and solver settings, but the single most common source of incorrect results is poor boundary condition specification. A PDE without proper boundary conditions is underspecified. You need as many boundary conditions as the highest order derivative in the spatial direction. For the heat equation, which is second order in space, you need exactly one boundary condition at each boundary, whether that is a Dirichlet condition specifying temperature, a Neumann condition specifying heat flux, or a Robin condition combining both. In practice, engineers often apply boundary conditions that look reasonable on the surface but violate the underlying physics. I worked on a project modeling fluid flow through a porous media filter. The inlet boundary condition was specified as a uniform velocity profile across the entire inlet face. The simulation ran, converged, and produced results that looked convincing. When we compared the pressure drop across the filter to experimental measurements, the simulated pressure drop was thirty percent too low. The issue was that the uniform velocity inlet did not account for the entrance region development. Once we extended the inlet domain and applied a fully developed flow profile using a logarithmic law, the pressure drop prediction matched experiments within five percent. The solver settings had been fine the whole time. The boundary condition was the problem. Another common mistake is mixing boundary conditions across different physics in multiphysics simulations. Thermal-structural coupling is a typical example. If you apply a fixed temperature boundary condition on one face and a fixed displacement constraint on the same face, the simulation may run without errors but the results will be physically meaningless because the thermal expansion is constrained in a way that does not match reality. Always verify that your boundary conditions represent the actual physical constraints of the system you are modeling.
Solver Selection And Computational Cost
The choice of solver depends heavily on the type of PDE and the size of the problem. For elliptic problems like steady-state heat transfer or potential flow, iterative solvers such as conjugate gradient or multigrid methods are usually efficient. Multigrid can reduce the computational complexity from O(n log n) to nearly O(n) for certain problems, which is significant when you are solving systems with tens of millions of unknowns. Direct solvers like Gaussian elimination or LU decomposition are only practical for small to medium problems because their memory requirements scale as O(n²) and their computational cost scales as O(n³). For transient problems, implicit time integration is generally preferred for stiff systems because it is unconditionally stable, allowing larger time steps. The trade-off is that each time step requires solving a system of equations, which is computationally expensive. Explicit time integration is cheaper per step but requires very small time steps to maintain stability, often constrained by the Courant-Friedrichs-Lewy condition. In my experience, explicit methods are useful for wave propagation problems where the physics is inherently dynamic and fast, while implicit methods are better suited for diffusion-dominated problems where the time scale is longer and stability is the primary concern. Parallel computing is now standard for large-scale PDE simulations. Domain decomposition methods split the computational domain across multiple processors, and the communication overhead between subdomains is usually the limiting factor. If you are running simulations on a cluster, make sure your mesh partitioning is balanced. An uneven distribution where one processor holds twice as many elements as another will create a bottleneck that nullifies the benefit of adding more processors. I once ran a simulation on thirty-two cores that performed worse than a single core because the mesh partitioning was completely unbalanced, and the inter-processor communication dominated the runtime.
Validation And Verification Are Not Optional
A simulation result is only as useful as the confidence you have in it. Verification answers the question are we solving the equations correctly? Validation answers the question are we solving the correct equations? Both are essential, and most engineering teams skip one or the other and then wonder why their designs fail in the field. For verification, use method of manufactured solutions when analytical solutions are not available. You impose a known solution into the PDE, compute the corresponding source term, and then run the simulation to see if it recovers the manufactured solution within the expected order of accuracy. This is a standard practice in code validation but many practicing engineers are not familiar with it. For validation, compare your results against experimental data or established benchmark problems. The Driven Cavity flow problem is a classic benchmark for CFD codes, and the heat equation on a square domain with prescribed boundary temperatures is a standard test case for thermal codes. I have seen projects where the simulation predicted a component would survive a thermal cycle with a safety margin of ten percent, but the physical prototype failed after the first cycle. The root cause was that the simulation did not include the effect of contact resistance at the interface between two mating surfaces. The contact resistance varied with clamping force and surface roughness, and the nominal value used in the simulation was based on a single measurement from a polished sample. The actual assemblies had rougher surfaces and lower clamping forces, resulting in contact resistance values that were three times higher than modeled. Once we incorporated a range of contact resistance values into the simulation, the thermal predictions aligned with the test data. The PDE formulation was correct. The input parameters were wrong.
Software Tools And Practical Implementation
Commercial finite element software like ANSYS, Abaqus, and COMSOL are the workhorses of engineering analysis. They handle mesh generation, solver selection, and post-processing in a integrated environment. The learning curve is manageable for standard problems, but advanced features like user-defined elements, custom material models, and multiphysics coupling often require scripting or programming. Python is increasingly common for automation and customization, and most commercial packages support Python interfaces. Open-source alternatives like FEniCS, deal.II, and OpenFOAM provide more flexibility and lower cost but require more upfront effort to set up and validate. FEniX is particularly notable for its symbolic approach to finite element computation, allowing you to specify variational forms in a high-level syntax. OpenFOAM dominates in computational fluid dynamics and has a steep learning curve but is extremely powerful for custom flow simulations. I have used both FEniCS and OpenFOAM in research contexts where commercial software was either too expensive or too restrictive for the problem at hand. The initial investment in learning the tools is real, but the long-term payoff in terms of flexibility and cost savings is significant. If you are getting started with PDE-based simulations, I recommend beginning with a simple problem that has a known analytical solution. Solve it using your chosen tool and verify that you recover the analytical result within acceptable tolerance. Then gradually increase the complexity. Add nonlinearity, change the geometry, introduce multiphysics coupling. This incremental approach builds intuition about how different parameters affect the solution, which is something no textbook can teach you as effectively as hands-on experience.
Where PDE-Based Simulation Falls Short
PDE-based simulation is not a universal solution. There are cases where it is the wrong tool, and recognizing those cases early saves a lot of wasted time and computational resources. One limitation is the treatment of uncertainty. Deterministic PDE solvers produce a single solution for a given set of inputs and boundary conditions. They do not quantify the uncertainty in that solution arising from parameter variability, model form error, or numerical approximation. If you need probabilistic predictions, you need to couple your PDE solver with uncertainty quantification methods like Monte Carlo sampling, polynomial chaos expansion, or stochastic collocation, which multiply the computational cost by orders of magnitude. Another limitation is the handling of multiscale phenomena. Many engineering problems involve physics at widely separated scales, from nanometer-scale material microstructure to meter-scale component behavior. Resolving all scales in a single PDE simulation is computationally infeasible for most practical problems. Homogenization methods and multiscale modeling techniques can bridge the gap, but they introduce additional assumptions and approximations that need to be validated. I worked on a project modeling crack propagation in a composite material where the fiber spacing was on the order of micrometers and the component size was on the order of centimeters. A direct simulation would have required billions of elements, which was impossible at the time. We used a homogenized continuum model calibrated against microscale simulations, which reduced the element count by several orders of magnitude while still capturing the macroscopic crack growth behavior with reasonable accuracy. A third limitation is the assumption of continuum mechanics. At very small scales, such as in micro-electromechanical systems or nanofluidic devices, the continuum assumption breaks down and molecular dynamics or other atomistic methods are more appropriate. The transition between continuum and atomistic regimes is not sharp, and there is ongoing research into concurrent coupling methods, but these are still largely research-level tools and not production-ready for most engineering applications.
Learning Path For Practical Competence
If you want to become proficient in applying PDEs to engineering problems, the theoretical foundation matters, but so does practical implementation. Start with a solid understanding of the mathematics: separation of variables, Green's functions, Fourier transforms, and functional analysis basics. Then move to numerical methods: finite difference, finite element, and finite volume discretization, stability analysis, and convergence theory. Finally, gain hands-on experience with simulation software and programming. Programming in Python or MATLAB is essential for developing your own solvers and automating workflows. Even if you primarily use commercial software, having programming skills allows you to customize solutions, process large datasets, and integrate simulation results into design optimization loops. I learned to program while working on my first PDE simulation project, and the ability to write custom scripts has been one of the most valuable skills in my career. It separates engineers who can run existing tools from engineers who can develop new solutions to novel problems. There are good textbooks and online resources available. For finite element methods, the book by Reddy is a standard reference that balances theory and practice. For computational fluid dynamics, the book by Versteeg and Malalasekera is accessible and practical. For a broader perspective that covers multiple PDE types and applications, the book by LeVeque is excellent, particularly for finite volume methods. Online courses from MIT OpenCourseWare and similar platforms provide lecture videos and problem sets that can supplement your learning.

The field is evolving rapidly. Machine learning approaches to PDE solving are emerging, with neural networks being used to approximate solutions to high-dimensional PDEs that are intractable for traditional methods. Physics-informed neural networks embed the PDE constraints directly into the loss function, allowing them to learn solutions from sparse data. These methods are promising but not yet reliable enough to replace traditional numerical methods for most engineering applications. They are worth watching, but I would not bet your project schedule on them at this point.