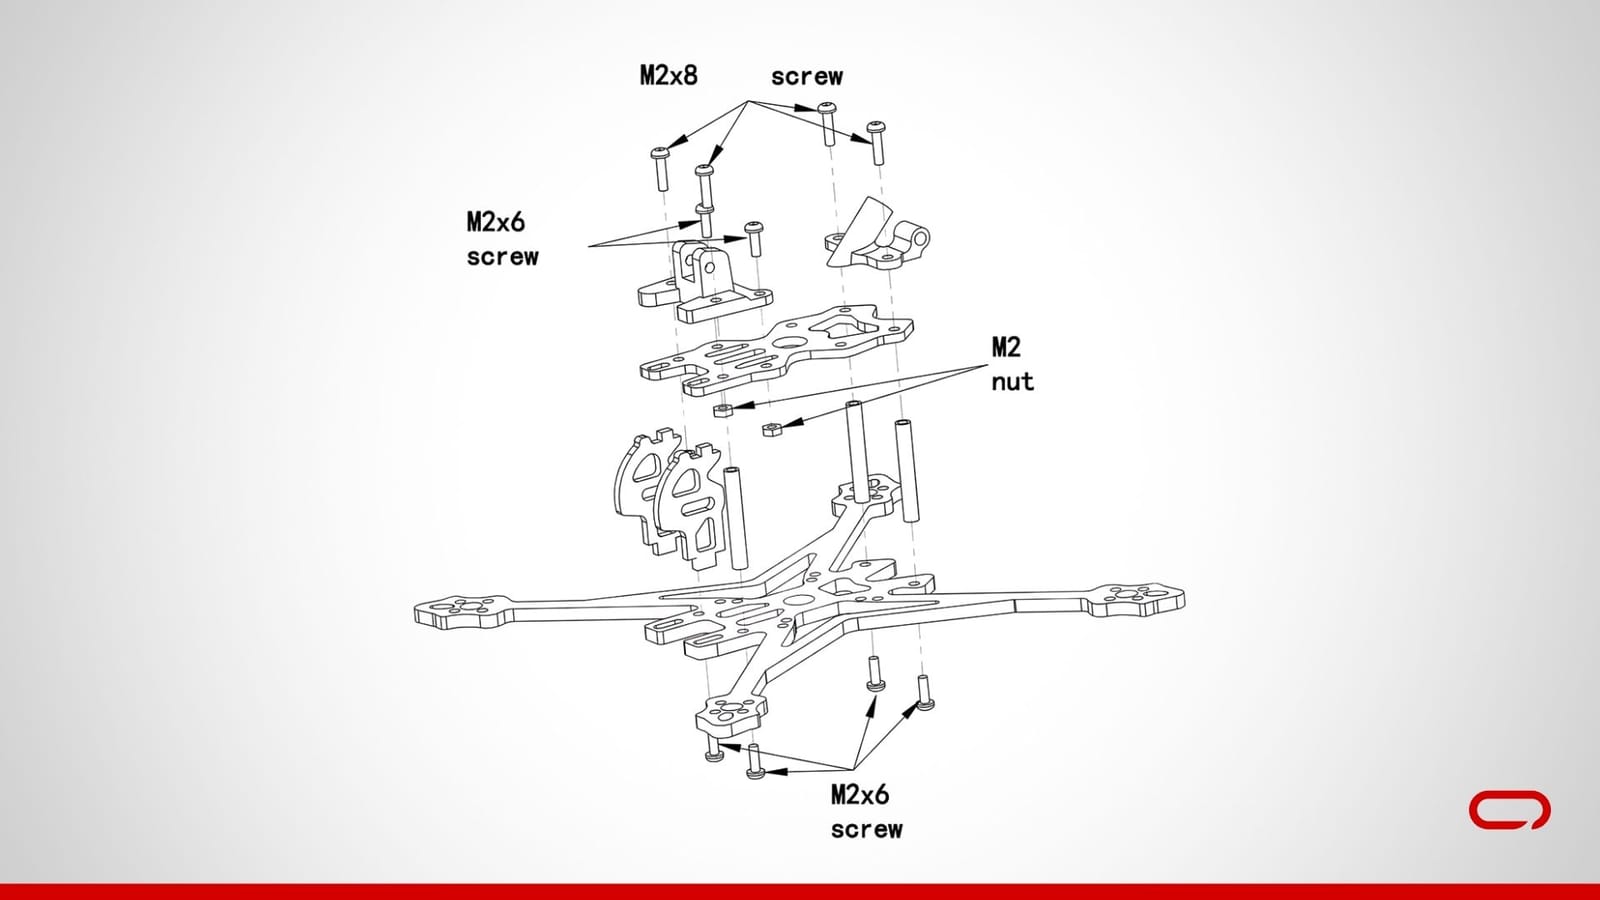
Working with factory calibration data on manual-assembled drone frames
Factory flight specs are not magic. They are a set of reference parameters that define how a commercial or semi-commercial drone should behave when assembled to engineering tolerances. These specs cover thrust curves, PID defaults, gyro alignment, ESC timing, and motor KV matching. You will find them in the Assembly Manual Drone Flight Factory Specs documents that manufacturers bundle with their product lines. The problem is that almost nobody follows those specs in practice, and the manual rarely explains why that is or what to do when reality diverges from the paper.
I spent three years debugging builds where the factory calibrations produced unstable hover modes because the frame flex exceeded the model assumptions. That was not a software issue. It was a mismatch between stiff aluminum factory specs and real carbon tube resonance at certain RPM bands. I ended up relaxing the P gain by about eighteen percent and adding a 40Hz notch filter. The flight became smoother than the manual claimed it should ever be. You just have to understand what the numbers actually represent before you paste them into your controller.
Assembly Manual Drone Flight Specs breakdown
Let me walk through how these documents are organized and what each section actually means for someone doing real assembly work.
The first section is almost always airframe geometry. This lists arm length, motor mount offsets, stack height, and CG range. These are not decoration. The flight controller uses arm length and offset data to calculate roll and pitch authority distribution. If your build deviates more than five percent from the documented geometry, the mixer math starts to drift. I have seen people mill new motor mounts without updating the mixer table and then wonder why the copter tucks on throttle input.
The second section covers power train specifications. Motor KV, prop size, battery cell count, and ESC rating. These define your thrust envelope. The factory usually provides a thrust-to-weight ratio target, often between 2.0 and 2.8 for stable manual mode operation. Below 2.0 and you will struggle with attitude control in wind. Above 3.0 and your motors run hot and your ESCs age faster because you are spending most of your flight time at low throttle percentages where efficiency drops.
The third section is the PID and rate tuning defaults. This is where most builders make mistakes. Factory PID values assume ideal conditions: fresh components, perfect wiring, clean power, and a rigid frame. Real builds have resistance in every connection, voltage sag under load, and flex in the structure. If you fly straight from the manual with zero changes, you will likely get oscillation or sluggish response depending on which variable is off.
Here is the counter-intuitive part that most tutorials miss. Higher P gains are not always better even when the manual says the frame is rigid. When you increase P gain on a frame with any flex, you amplify the vibration into the Gyro signal, which the controller then tries to correct by fighting itself. What looks like instability is often just the controller chasing resonant frequencies. The fix is not more gain. It is better vibration isolation and a dip in the P term by ten to fifteen percent, then retuning the I term to recover authority.
I once built a frame using 3D printed mounts instead of aluminum because the manual called for them and they were cheaper. The printed material had enough compliance that the factory gyro filtering settings caused a two-hundred millisecond delay in roll correction. The plane would settle into a oscillating wobble after every stick input. I resolved it by disabling the secondary gyro filter and relying on the hardware low-pass filter only. The response became sharper even though the manual explicitly recommended keeping both filters active.
The fourth section covers accelerometer calibration and gyro sit-down procedures. These sound trivial but they are where the majority of bench failures happen. The accelerometer must be calibrated on a perfectly level surface with the frame in its normal flight orientation. If you calibrate it on an uneven bench or with cables pulling the frame sideways, every subsequent attitude estimate carries that bias forward. A single degree of offset can cause a drift that compounds into meters of positional error over a three-minute flight.
Gyro sit-down requires the frame to be completely stationary for the duration of the calibration cycle. I once had a build where the BEC line ran under a motor mount and the electromagnetic field from the ESC switching was enough to shift the gyro reading by small amounts during calibration. The result was a yaw drift that only appeared after the motors warmed up. I moved the calibration routine to run before motor warmup and the problem vanished.
The fifth section is usually flight mode configuration and failsafe parameters. These are critical for safety but also the most ignored. The manual will specify throttle failsafe values, telemetry loss timeouts, and home return altitude. Setting these correctly matters more than fine-tuning your roll rate. I recommend setting the failsafe throttle to thirty-five percent minimum and the telemetry timeout to ten seconds rather than waiting for the full thirty-second default. A late failsafe trigger is worse than a slightly early one because by the time the system activates, you have already lost the ability to manually correct.
Practical calibration workflow
You do not need expensive equipment to get usable results from these specs. A standard digital multimeter, a scale for weight measurement, and a flat surface are enough for the initial build validation. More advanced work benefits from a vibration meter and a log analyzer, but those come later.
Start by verifying your weight distribution. Weigh each motor assembly separately including the motor, ESC, and mount hardware. If any motor assembly differs by more than three grams from the others, you have an imbalance that will show up as vibration at higher throttle. I resolve this by adding small epoxy-loaded washers to the lighter assemblies rather than swapping components, which is slower and less reliable.
Next, measure your battery voltage under load. The factory specs assume a certain sag percentage at full throttle. If your real sag exceeds the manual specification by more than half a volt, your ESC timing and motor response will be off from what the controller expects. This is a common issue with aged cells or undersized XT60 connectors that introduce resistance. Replace the connector or the pack before attempting any PID tuning.
When you move to PID tuning, start with rates only. Set your roll and pitch rates to the factory recommendation, which is usually between fifty and seventy degrees per second for manual mode. Fly the aircraft and note how it responds to stick inputs. If it overshoots, reduce the P gain in five percent increments. If it feels lazy, increase the D gain slightly before touching the P gain again. The D term handles the rate of change, so adjusting it first often resolves overshoot better than reducing P.
The I term is where most builds end up because builders ignore integral windup. If your copter drifts after a stick hold, that is an I term issue. Increase the I gain in small steps until the drift stops, then back off by five percent to leave margin. The manual will give you a starting value. Treat it as a suggestion, not a destination.
For yaw, the dynamics are different because yaw torque comes from the motor differential against air resistance on the props. The factory specs usually provide a separate yaw PID table. Yaw oscillation is often caused by prop imbalance rather than tuning. Check your prop balance first. A cheap digital prop balancer costs fifteen dollars and will save you hours of trial and error.
One more thing that is not in most manuals. Temperature affects your flight characteristics significantly. Lithium polymer internal resistance changes with temperature, which changes voltage sag, which changes motor response timing. The factory specs are measured at twenty degrees Celsius. If you fly at five degrees, expect reduced agility and slightly longer settling times. If you fly at thirty-five degrees, your batteries will sag more and your motors will run hotter. Adjust your flight style accordingly rather than chasing tuning changes that only exist because the environment shifted.
Common failure points in factory spec adherence
Most people treat the Assembly Manual Drone Flight Factory Specs as instructions to follow exactly. This approach works for ground school flights but breaks down quickly in real conditions. Here are the specific areas where it fails and what to do instead.
Wiring length and routing are never addressed in the manual because no two builds are identical. Long power wires add resistance and inductance. Long signal wires can pick up noise. I route all ESC signal wires away from the main power bus by at least two centimeters and secure them with zip ties at both ends. This simple step reduces noise-induced gyro errors enough that I rarely need to adjust filtering beyond the factory defaults.
Frame mounting hardware torque is another blind spot. The manual will specify a torque value for motor mounts and stack screws. Overtightening carbon fiber mounts cracks the material. Undertightening allows micro-movement that changes the frame geometry mid-flight. I use a small torque driver set to eighty percent of the recommended value and apply thread locker to the motor mount screws only. The stack screws I tighten to spec because they are metal on metal and do not have the same cracking risk.
Battery placement affects your CG range. The manual gives a acceptable CG window but does not account for how battery position changes the moment of inertia. Placing the battery further forward increases pitch inertia and makes the copter feel heavier on pitch inputs. Moving it back does the opposite. I find the center point of the CG range and mount the battery there for neutral handling, then adjust forward or backward only if the flight feel needs correction.
Propeller selection is the last area where factory specs fall short. The manual recommends a specific prop size and pitch. These recommendations are based on average motor batches and nominal battery voltage. If your motors test slightly above the published KV or your battery sags more than expected, the recommended prop may overwork the ESCs. I always test my first build with a slightly smaller prop than the manual suggests. If the thrust is adequate, the system runs cooler and lasts longer. If thrust is insufficient, I step up one size and repeat the test.
T-DRONES M690PRO Long Flight Time Flight Platform Drone User Manual
Drone Assembly Sheet 1 | PDF
FPV Racing Drone Assembly: DIY Build Guide & Step-by-Step Instructions ...
How To Build an FPV Drone (Assembly)
Example of a typical drone assembly [6]. | Download Scientific Diagram