Why Your Drone Won't Fly (And The Wiring Diagram You Should Have Read)
You build the frame. You mount the ESCs. You solder everything perfectly. Then you power it up and nothing happens. The flight controller blinks once and goes dark, or the motors spin in random directions, or the receiver refuses to bind. This happens constantly. I have spent more evenings than I can count debugging connections that looked correct on the surface but were wrong in practice. The Assembly Manual Drone Wiring Diagram is the document most people skip because they think they already know how to connect a flight controller. They do not. Not really. There is a difference between understanding the concept of a wiring diagram and being able to follow one when you are staring at a pile of colored wires at 11pm with a heat gun in your hand.
How to Actually Read an Assembly Manual Drone Flight Wiring Diagram
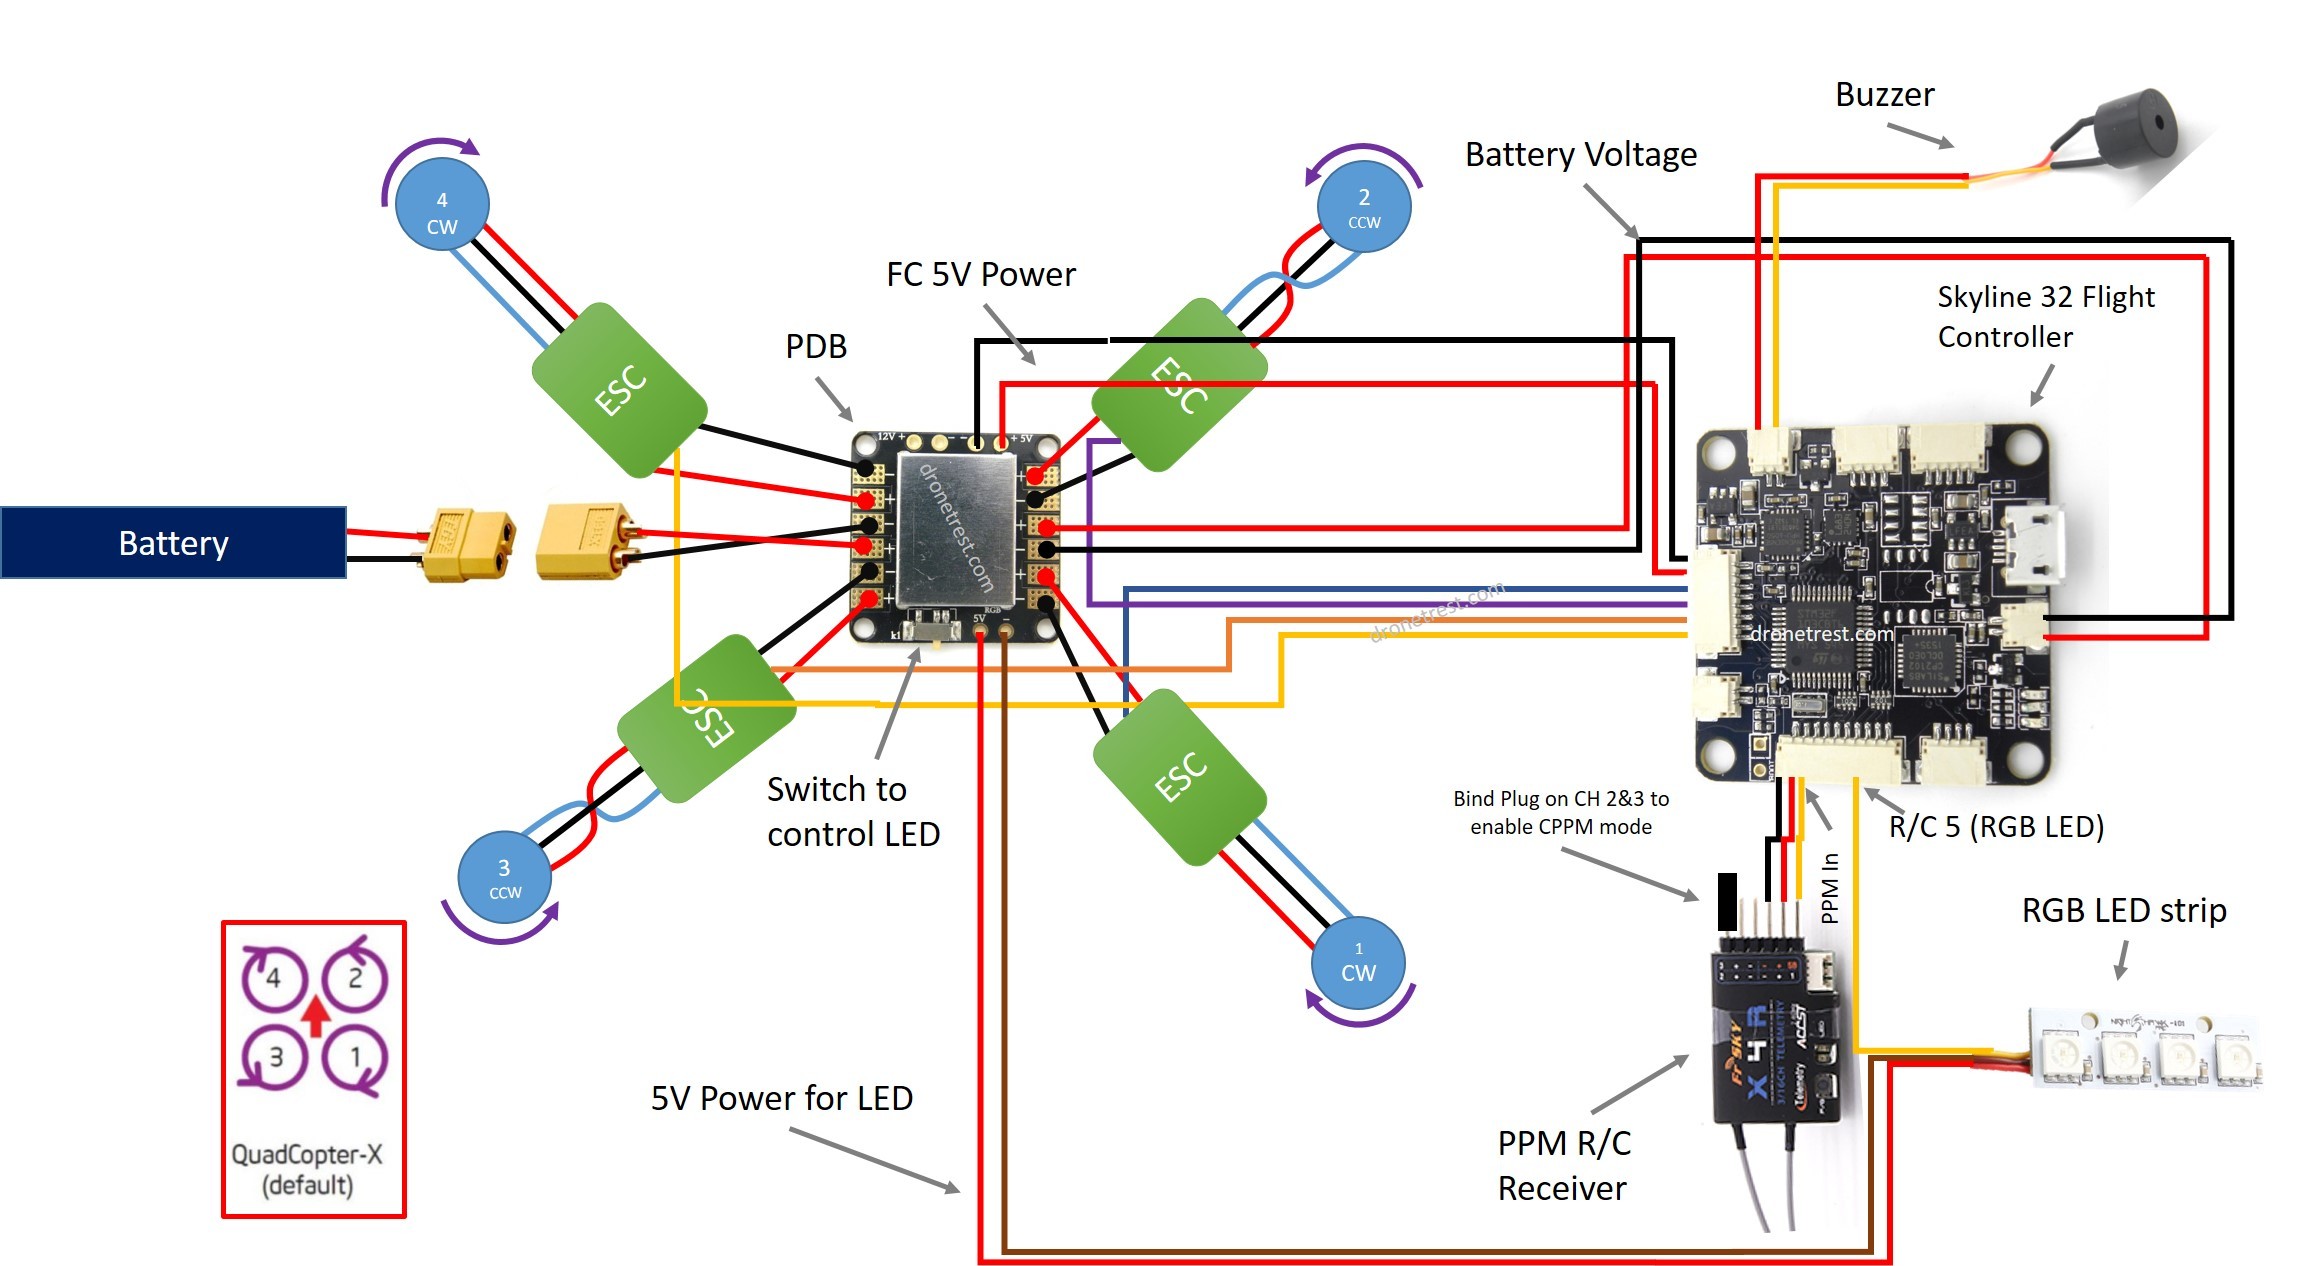
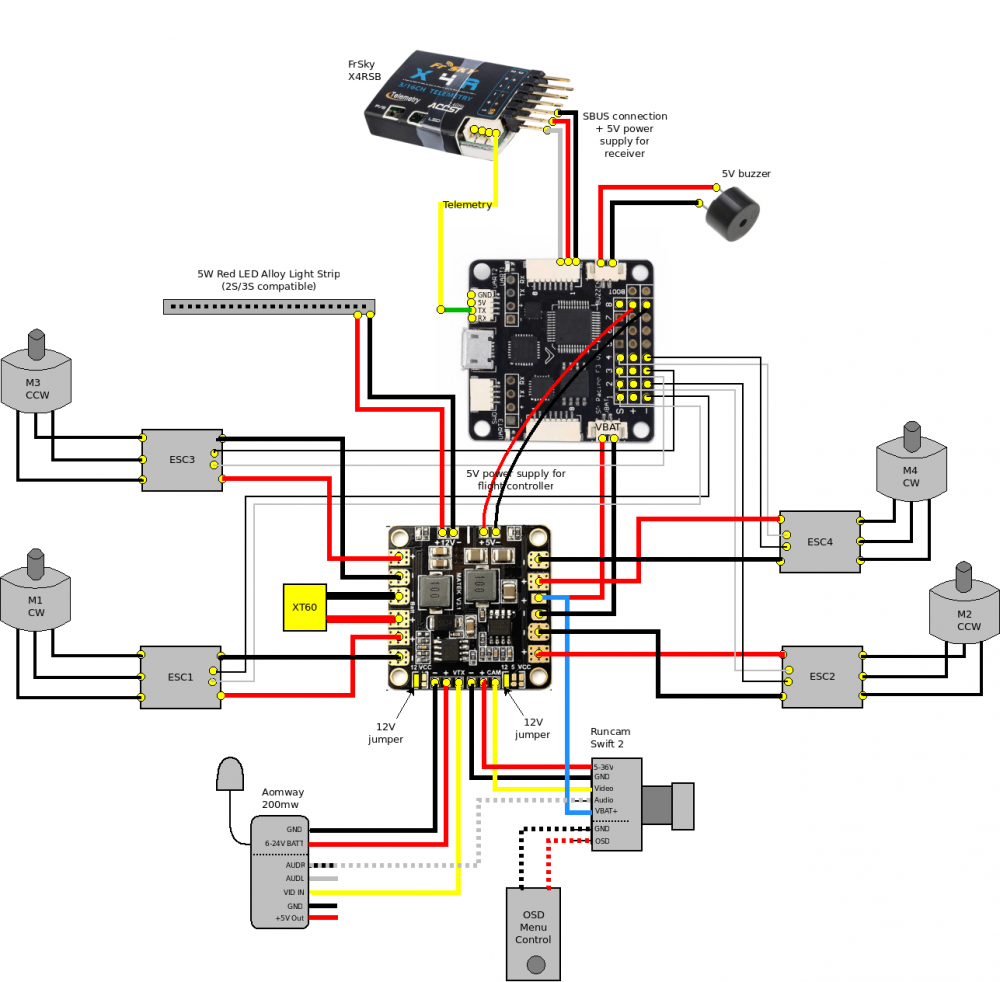
Start with the power distribution board. This is where most people make the first mistake. The PDB diagram will show a big "+5V" or "+6V" rail coming from the battery, split into multiple outputs for different components. Your flight controller, your receiver, and sometimes your video transmitter all draw from this rail. Do not assume every PDB supplies the same voltage. A few boards have a regulated 5V output and an unregulated raw rail side by side. Connecting your FC to the raw rail without checking will cook it instantly. Next, look at the ESC to FC connection. This is the signal wire only. The thick red and black wires from each ESC go to the PDB. The thin orange or yellow signal wire from each ESC goes to a numbered pin on the FC. Pin 1 is motor 1. Pin 2 is motor 2. The order matters for the motor direction mapping in your software, but the physical connection order does not change the motor position. Motor 1 on the FC should drive whichever motor is physically in position 1 according to your frame manufacturer. Most people get this wrong and then spend two hours swapping motor directions in Betaflight instead of just moving one wire. The receiver connection is usually the simplest part but also the most ignored. You need to confirm whether your FC uses UART serial or a PWM input for the receiver. Modern FCs have multiple UART ports labeled UART1, UART2, and so on. Check the diagram to see which port has telemetry and which does not. If you plug your receiver into a UART that is already assigned to a different peripheral in your flight controller software, the receiver will not respond and you will pull your hair out trying to figure out why. I once spent a full day troubleshooting a dead receiver only to discover I had it plugged into UART3, which was enabled for GPS telemetry in the config tab. Moving it to UART1 fixed it in thirty seconds.
The gyroscope and IMU orientation diagram is another section people gloss over. If your FC has a built-in accelerometer, you need to align the board correctly on the frame. The diagram will show an arrow indicating the front of the FC matching the front of the quad. Mount it backwards and your drone will think it is flying upside down. This sounds obvious until you have done it three times in a row on different builds and start doubting your software configuration instead of your physical hardware.
Get the Full Details

Advanced Pitfalls That Are Not Covered in Any Manual
Ground loops are the most frustrating issue in drone wiring and almost nobody warns about them. When you run power wires and signal wires in parallel along the same cable route, you create electromagnetic interference that causes erratic sensor readings. The flight controller will report false acceleration and your drone will drift on its own during hover. The fix is simple: route your power cables on one side of the frame and your signal cables on the other. Keep them separated by at least an inch whenever possible. This is not a suggestion. It is a hard requirement for stable flight. Vibration isolation is equally important but often misunderstood. The diagram will show you where the FC mounts, but it will not tell you whether your frame is vibrating enough to cause problems. Carbon fiber frames conduct vibration differently than aluminum or glass fiber. A good test is to power the drone on the ground, open your flight controller software, and look at the gyro raw values. If they are fluctuating by more than two or three points without the frame moving, you have a vibration problem. Rubber grommets or silicone FC mounts will usually fix this, but you need to identify the source first. Loose motor mounts, unbalanced props, and cheap ESCs are the three most common causes. Battery voltage sensing is another feature that trips people up. Some FCs have a dedicated VBat pin that reads the main battery voltage through a resistor divider. The wiring diagram will show this pin connected to the battery positive through a high-value resistor network. If you skip this connection, your telemetry will read zero or garbage values. If you connect it directly without the resistors, you will destroy the ADC pin on your flight controller. Always check the diagram for the VBat circuit and verify the resistor values match your battery configuration. A 3S LiPo needs a different divider ratio than a 6S LiPo.
Common Mistakes I See Even From Experienced Builders
The first mistake is assuming that color coding means anything universal. There is no standard for ESC signal wire colors. One brand uses orange. Another uses yellow. A third uses white. The diagram is the only thing that matters. Trust the diagram, not the wire color. I have rebuilt drone motors twice because I assumed the orange wire on one ESC matched the orange wire on another ESC from a different manufacturer. They did not. The diagram showed the correct pinout and I should have followed it instead of relying on color intuition. The second mistake is leaving solder joints exposed. Heat shrink tubing is not optional. A loose strand of wire touching the wrong contact point can short your ESCs, your FC, or both. I have seen complete flight controllers fail because a stray bit of tin from a solder joint bridged two adjacent pins. Always heat shrink every connection and secure wires with zip ties so they cannot move during vibration. A well-secured harness of wires looks boring. An unsecured mess looks like a project in progress and tends to cause failures mid-flight. The third mistake is ignoring the firmware configuration step. The wiring diagram gets you hardware connected. It does not configure the software. After every build, you need to verify motor direction in your flight controller software, set the correct battery type and cell count, calibrate the accelerometer, and configure your receiver protocol. Skipping any of these steps because the wiring was correct is a guaranteed way to get a non-flying drone sitting on your workbench.
What The Diagrams Leave Out
Most assembly manuals assume you have basic electronics knowledge. They will show you where the wires go but not why they go there. They will not explain what happens if you accidentally swap the positive and negative leads on your power input. They will not warn you about reverse polarity protection or the lack of it on certain boards. Budget flight controllers often have no reverse polarity protection at all. Plug the battery in backwards and the smell of burning components will tell you immediately. Expensive boards may have protection circuits, but even those can fail under high current loads. Another gap is connector compatibility. The diagram might show a JST-XH connector for your receiver but your receiver might use a JST-GH connector with the same pin spacing but a different housing. Forcing the wrong connector can damage the pins inside the housing. Always verify connector types before purchasing your receiver and servo wires. A roll of dupont-style jumper wires will fit most FCs but the pins are brittle and can bend or break if you plug and unplug them frequently. Barrel-style connectors are more durable for permanent installations. Telemetry wiring is a third area where diagrams fall short. Most people only connect the receive wire from their telemetry module and ignore the transmit wire. Your telemetry module needs both a receive and a transmit connection to communicate properly with the ground station. Check whether your FC supports SmartPort, CRSF, or MAVLink telemetry and wire accordingly. Different protocols use different voltage levels and pin configurations. Connecting a 9V CRSF telemetry module to a 3.3V UART pin without a voltage divider will damage the FC output. This is a real failure mode and it happens regularly.

If you are building your first drone, do not rush the wiring phase. Take photographs of every connection as you make it. This gives you a visual reference if something goes wrong later and you need to trace back where each wire actually went. A well-documented build saves hours of debugging compared to a build where you hoped you remembered everything.