Getting Your Baumer Encoder Working Without Losing Your Mind
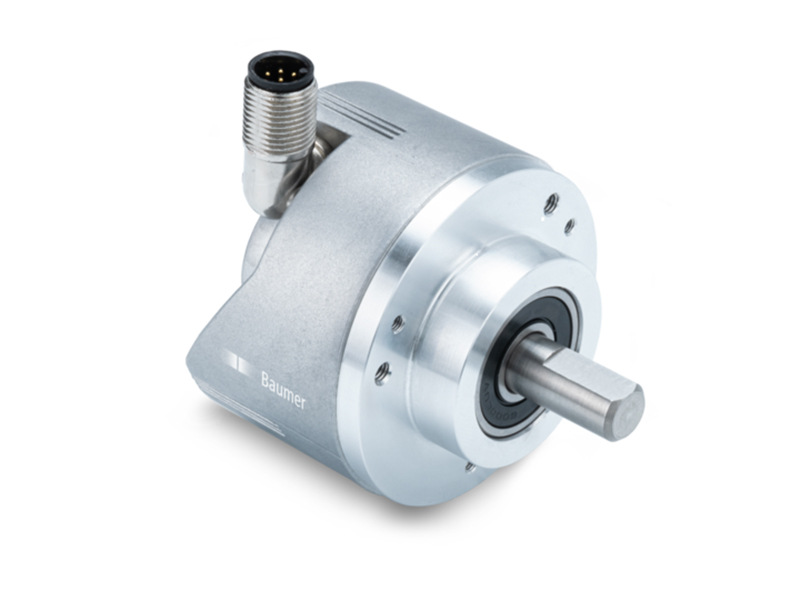
The Baumer Amg 11 Ss 25 Z0 is a magnetic absolute encoder that shows up in a lot of industrial automation setups, usually where you need position feedback but don't want to deal with optical components collecting dust. I've installed maybe two dozen of these over the years across conveyor systems and robotic joints, and they're generally straightforward if you approach them correctly from the start. It's a single-turn magnetic encoder with 12-bit resolution output through various interface options. The "Amg" prefix in Baumer's naming convention indicates it's their magnetic absolute positioning line, designed to work with a diametrically magnetized ring magnet rather than a code disk. The "11" in the part number refers to the housing size, and the Ss 25 Z0 suffix typically denotes the shaft and connector configuration for your particular application. One thing people miss about these encoders: the magnetic sensing principle means they don't care about contamination the way optical encoders do. You can run one in a sawmill environment where wood chips are everywhere and it'll keep working while a comparable optical unit would choke within a week. That said, magnetic encoders have their own failure modes worth understanding.
Installation Procedure
Mounting this encoder requires attention to air gap specification. The datasheet calls for 0.5 to 1.0 mm gap between the sensor face and the magnet surface. I learned the hard way that when you're tight on space and push the sensor closer to improve signal margin, you can actually degrade performance if the magnet runs off-center or introduces axial runout into your measurement. The mount itself needs to secure the encoder body without transferring shaft load to the connector. These units typically use a set screw or flange mounting arrangement depending on your shaft configuration. I recommend using thread locker on the mounting fasteners, especially in vibration-heavy applications. My first installation without thread locker needed adjustment after three weeks because the set screw had backed out enough to change the air gap. Wiring follows the standard Baumer color code convention, but verify your specific cable marking against the encoder label. The power supply should be 10 to 30 Vdc typically, and I'd suggest adding a decoupling capacitor close to the encoder terminals if you're running it on a long cable run. I've seen interference issues manifest as position jumps on the output when the encoder was fed from a noisy VFD-powered bus with no filtering.
Commissioning and Adjustment
Most Baumer encoders of this type require some form of learning or synchronization procedure after initial installation. Check whether your specific model needs a factory reset position set, a reference mark capture, or if it outputs absolute position immediately upon power-up. The Amg 11 series typically provides true absolute position without homing, which is one of the reasons to choose magnetic over incremental systems. The magnet itself must be mounted properly. If you're machining your own mounting arrangement, ensure the magnet surface is perpendicular to the encoder axis within 0.1 mm over the magnet face. A misaligned magnet causes the magnetic field vector to vary across the sensor as the shaft rotates, producing position errors that repeat every revolution but shift magnitude with mechanical variation. I encountered a particularly annoying issue once where a Baumer Amg 11 Ss 25 Z0 was giving intermittent position corruption on a servo drive. The encoder output looked clean on the oscilloscope, but every time the machine hit a certain speed, the position would jump. It turned out the magnet was mounted on a splined shaft, and the spline interaction was causing the magnet to shift axially by a few hundred microns at higher RPM due to centrifugal effects. We solved it by switching to a shrink-fit magnet mount instead of relying on the spline connection alone.
Get the Full Details

Troubleshooting Common Issues
If your encoder shows position resetting or outputting invalid data on power-up, check the supply voltage first. These units can tolerate a drop to about 9 Vdc for short periods, but sustained low voltage causes the internal comparator thresholds to shift and produce erratic readings. A marginal power supply or undersized cable is a more common culprit than people realize. Signal integrity problems often trace back to grounding. Use a shielded cable and terminate the shield at one end only, preferably at the controller side. Running the shield at both ends creates ground loops that inject noise into the differential signal lines, particularly problematic when your encoder and PLC share a ground but have different potential due to stray currents in the machine frame. Another frequent issue involves the output format mismatch. Make sure you're using the correct interface for your application. The Amg 11 series supports TTL, HTL, and various fieldbus protocols depending on your configuration. I've seen engineers try to connect an HTL output encoder directly to a TTL input without level conversion, which either produces garbage readings or damages the input circuitry over time.
Performance Expectations
The 12-bit resolution gives you 4096 positions per revolution, which works well for most position control applications but may be insufficient for high-precision positioning tasks. If you need finer resolution, consider whether you need a higher bit count encoder or whether you can use interpolation in your motion controller. The magnetic sensing principle inherently has less resolution potential than optical encoders, but for most industrial applications the difference is irrelevant. Absolute position retention without battery backup is a key advantage of this design. The magnetic field doesn't fade, so position information is preserved indefinitely through power cycles. This eliminates the battery replacement maintenance that plagues many absolute encoder installations. I've seen optical absolute encoders fail because the backup battery died during a scheduled maintenance window where nobody checked, causing hours of machine reconfiguration. Operating temperature range typically spans from -40 to +105°C for these units, which covers most industrial environments. However, keep in mind that magnetic properties of the ring magnet can degrade at sustained high temperatures, potentially affecting accuracy over extended periods in hot applications. If you're running near the upper temperature limit, verify the magnet grade specifications match your application demands.
When This Encoder Isn't the Right Choice
Magnetic encoders like the Baumer Amg 11 Ss 25 Z0 struggle in environments with strong external magnetic fields. If your application involves welding equipment, large motors, or magnetic lifting systems nearby, the stray fields can overwhelm the sensor and cause position errors that don't show up in bench testing. I had one installation near a resistance welder where the position would corrupt whenever the weld cycle fired, despite proper shielding attempts. High-vibration environments can also cause problems, not because of the sensing principle but due to mechanical coupling. If the magnet shifts relative to the sensor during operation, you get position errors that vary with vibration amplitude. In those cases, consider whether a mechanical coupling or flexible mount between the magnet and shaft would help, or whether you should switch to a different encoder technology entirely. For applications requiring multi-turn position tracking, this single-turn unit won't suffice without an external mechanism. Baumer offers multi-turn versions, but they introduce additional complexity and cost that may not be justified for your application. Evaluate whether you actually need multi-turn capability before committing to a more expensive solution.