Understanding the Beta Mig 250 Setup and Operation
The Beta Mig 250 is a digital programmable power supply unit used primarily in industrial automation and precision motion control applications. It handles multi-axis servo drive management, real-time interpolation, and communication with host PLCs via EtherCAT or Profibus. Getting it configured correctly is one thing. Getting it to run reliably in a production environment is another, and most problems come from treating it like a plug-and-play device when it isn't. I spent about three weeks last year debugging a line where these units were fighting each other on the bus. One axis would jump randomly, then go into alarm. Turned out the grounding scheme was wrong — each unit needed a dedicated earth ground, not daisy-chained through the DIN rail. The manual mentions this in section 4.2, but it reads like an afterthought. That section alone saved me from pulling my hair out for another month.
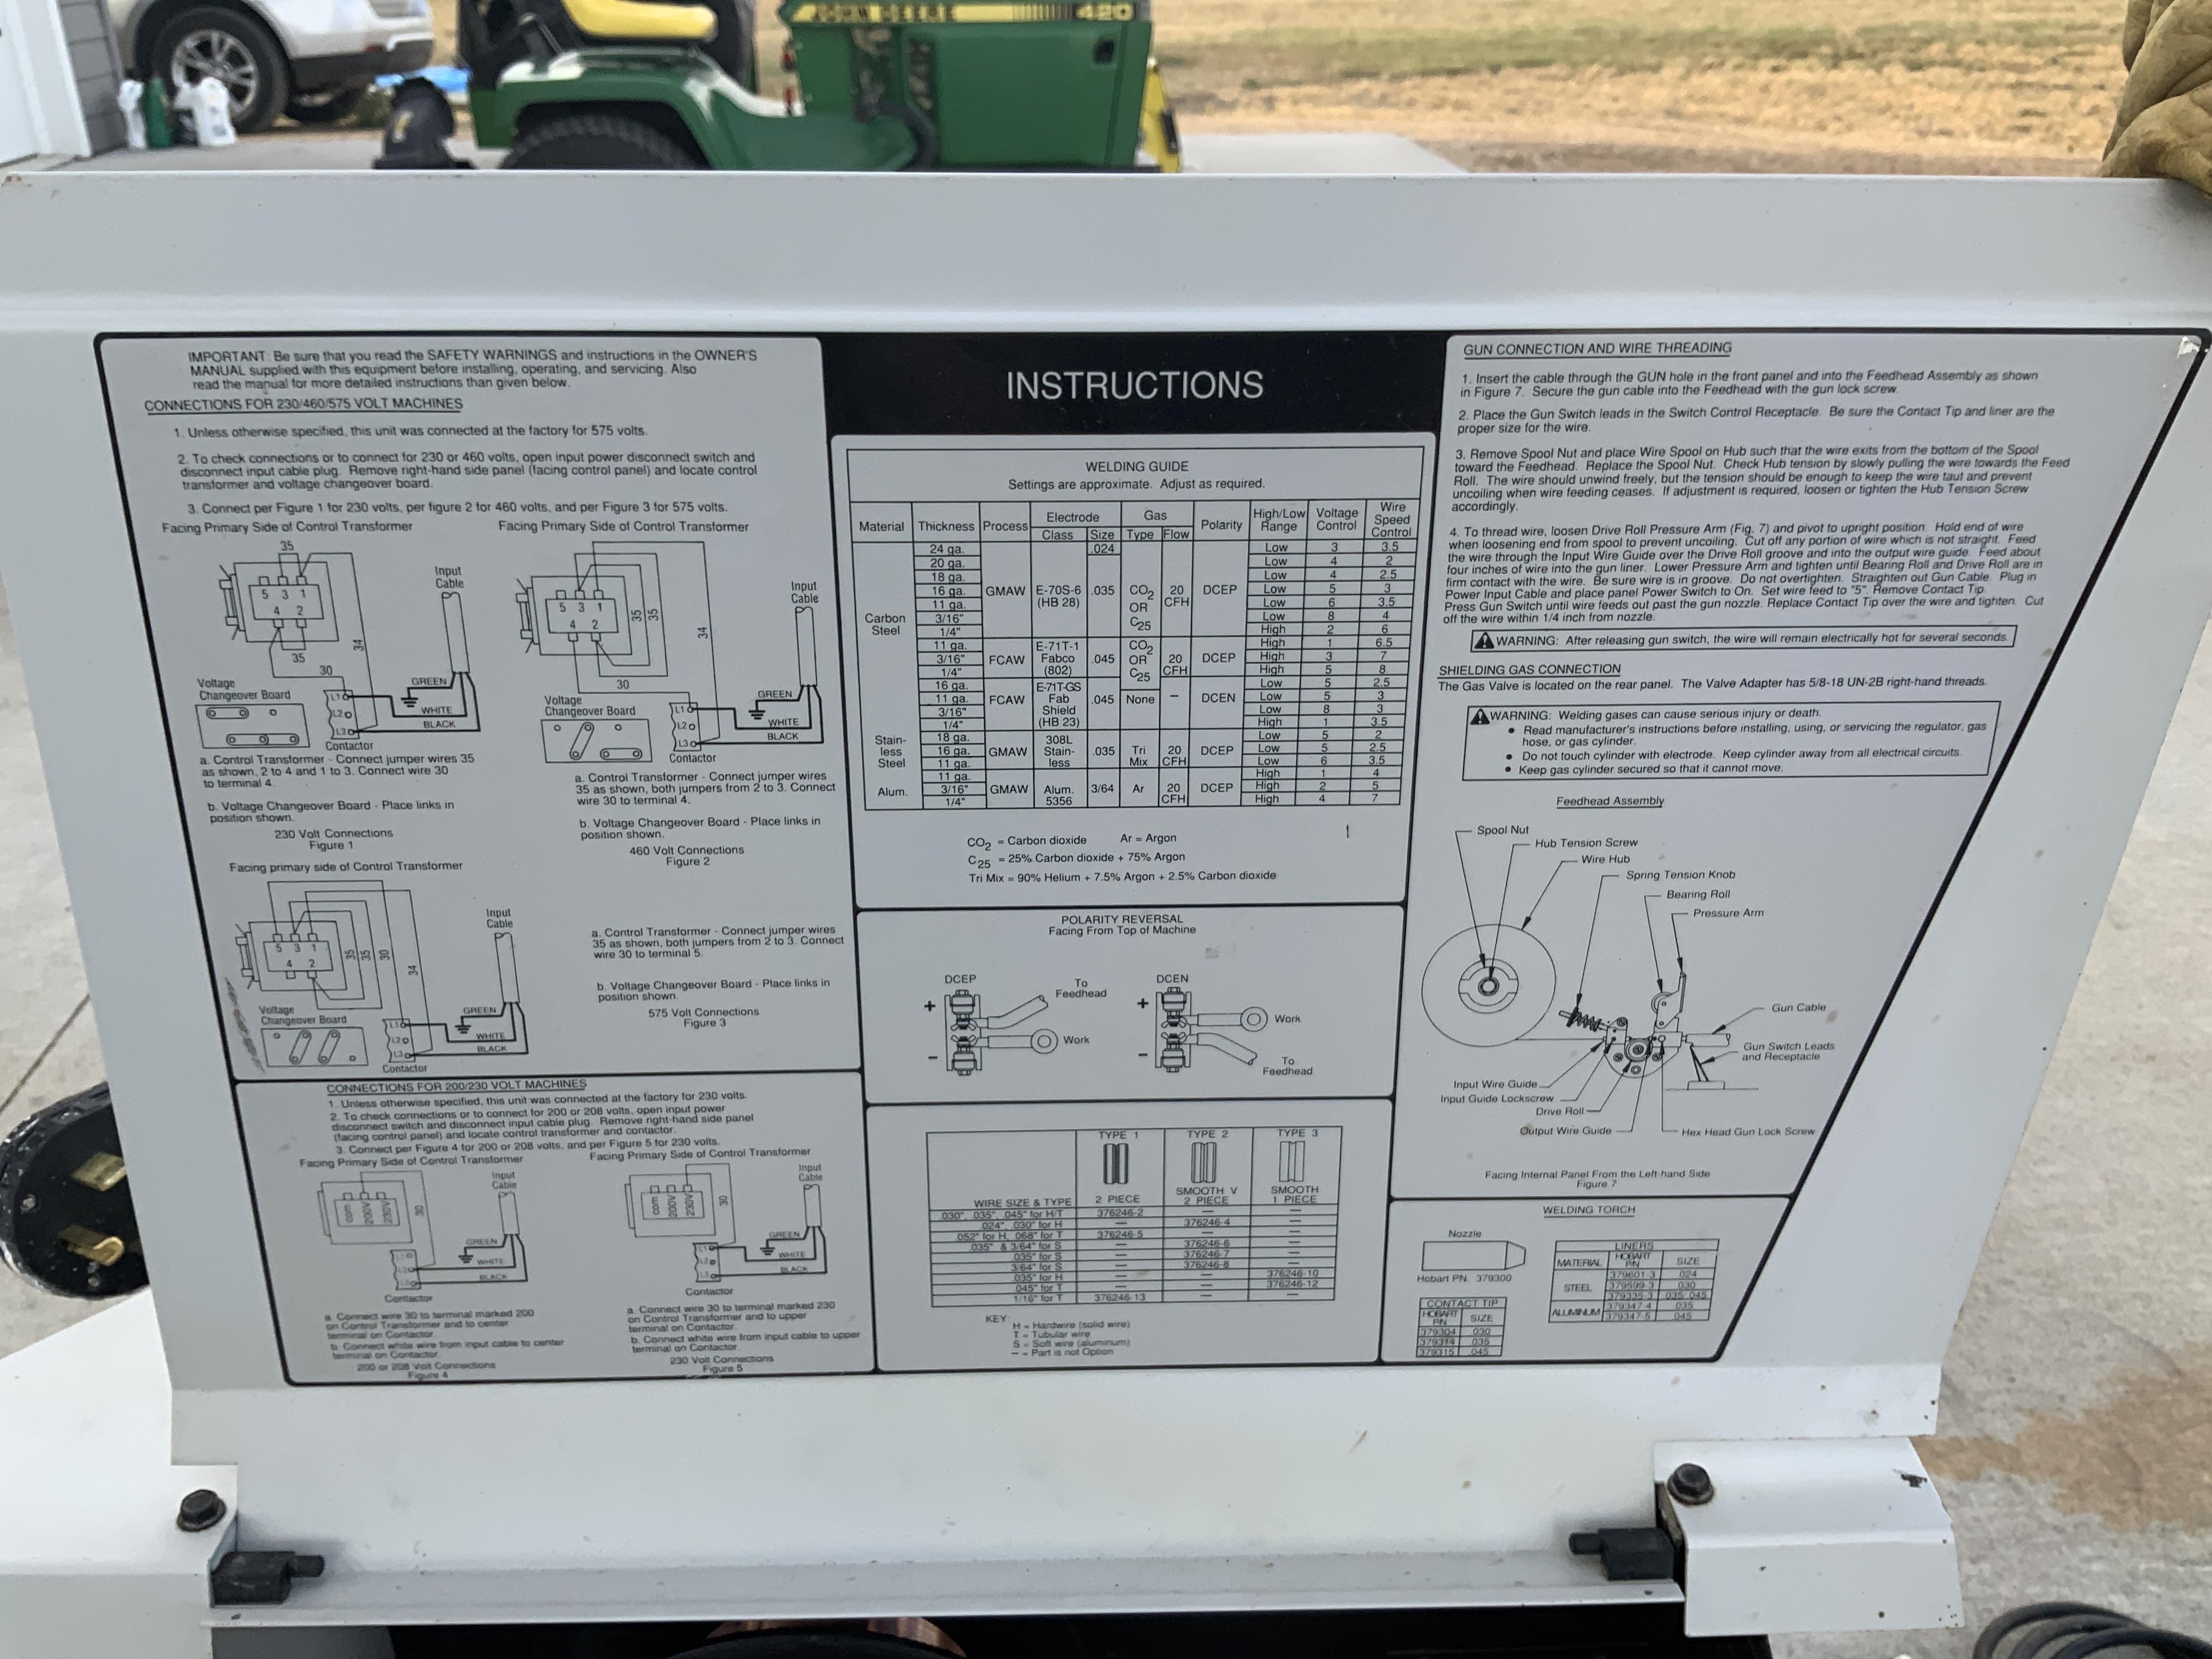
Beta Mig 250 Manual Key Sections Explained
The Beta Mig 250 Manual is roughly 140 pages when you count the appendices and error code tables. The first 30 pages cover mechanical mounting, terminal block wiring, and power input specifications. Pages 31 to 80 are where the real configuration lives — parameters, servo tuning, and communication setup. The error code appendix at the end is genuinely useful and should be the first thing you bookmark on page one because you will need it. One thing the manual doesn't make clear early enough: the firmware update process is not backward compatible with older parameter files. If you're running units from 2021 or earlier and flash the latest firmware, your saved profiles from the Beta Configuration Tool will not load. You have to map every parameter manually. There is no migration wizard. I learned this the hard way on a Saturday night. The parameter tree is hierarchical but not intuitive. Parameters are grouped by function rather than by physical layout. So axis gain, feedforward, and notch filter settings are scattered across different sections even though they're on the same hardware module. The manual has a cross-reference table on page 89 that maps physical terminal locations to parameter numbers, but it's easy to miss if you're reading straight through.
Configuration Process Step by Step
Start with the Beta Configuration Tool software installed on a Windows machine. USB communication works but is unreliable above firmware version 4.2. Use an Ethernet connection with a static IP on the management port. Set the PC to 192.168.1.10, set the unit to 192.168.1.11, subnet 255.255.255.0. This eliminates about half the connection issues people report. After establishing communication, run the auto-tuning routine before touching anything manually. The unit will generate a step response and calculate optimal gain values based on your load inertia. This typically takes 45 seconds per axis. The manual recommends skipping this and tuning by hand, but that advice seems aimed at people who already understand their mechanical systems well enough to predict resonance points. Most shop floor engineers don't. Once auto-tuning completes, verify the results by running a position profile at 25 percent of maximum speed. Watch the tracking error register — it should stay below 0.02 mm under normal load. If it's higher, check the mechanical coupling for backlash. A lot of "tuning problems" are actually loose set screws or worn couplings that the software cannot fix regardless of parameter changes.
Get the Full Details
Communication setup is where things get tricky if you're integrating with a Siemens or Allen-Bradley PLC. The EtherCAT master configuration file must match the unit's firmware revision exactly. Mismatched versions cause periodic bus errors that manifest as random position drops every 30 to 90 seconds. The manual calls this a "known synchronization variance" and suggests increasing the watchdog timer. That's a bandage, not a fix. The actual solution is ensuring both the PLC GSDML file and the Beta firmware are from the same release batch.
Common Issues and Practical Workarounds
The most frequent problem I see is overcurrent alarms during deceleration. The regenerative braking circuit in the Mig 250 can handle about 150 watts of without an external brake resistor. If your application involves frequent stops with loaded axes, you'll need to add the optional BR-150 resistor module. The manual lists this as optional but it's effectively mandatory for any duty cycle above 40 percent. Without it, you'll get alarms roughly every two hours of runtime. Another issue is thermal throttling. The unit derates output current at ambient temperatures above 45°C. If your control cabinet runs hot and you haven't added forced airflow, the manual says the unit will reduce maximum torque by 20 percent. It doesn't tell you how to monitor this in real time. Use parameter group 7, register 12 — it outputs the internal temperature directly to your HMI. Most people never find this register. I had a case once where the unit would fault with error code E-047 during initial commissioning but run fine afterward. The manual defines E-047 as "encoder initialization failure." The workaround was adding a 100ms delay between power-on and the first position command. The encoder needs a full reset cycle that the default startup sequence skips. This isn't documented anywhere in the main text — it's in a supplementary bulletin on the manufacturer's website that wasn't linked from the manual itself.
When the Beta Mig 250 Is Not the Right Choice
These units excel at multi-axis synchronized motion with tight tolerance requirements. They are not suitable for simple single-axis positioning where a basic stepper driver would do the job at a fraction of the cost. They also require consistent maintenance — firmware updates, cable inspection, and parameter backups every six months. If your environment is dusty or vibration-heavy, plan for more frequent connector checks. The plug-in terminal blocks are reliable but not sealed. For applications requiring only basic on-off control or simple ramp-and-decel profiles, consider a dedicated motion controller instead. The Mig 250's complexity becomes a liability when you don't need its capability. You'll spend more time troubleshooting configuration issues than gaining performance benefits.

Recommended Resources Beyond the Manual
The official manual covers fundamentals well but has gaps in advanced troubleshooting. The manufacturer publishes application notes on their technical portal — specifically AN-203 on EtherCAT integration and AN-217 on regenerative energy management. These are free but require account registration. There is also a community forum where field engineers share parameter sets for common applications like CNC routing, pick-and-place, and linear indexing tables. The quality varies, but the data is generally reliable if you verify it against your own test runs. Keep a parameter backup of every unit on a network share. Label it with the date, firmware version, and mechanical configuration. When something goes wrong six months from now, you'll be glad you did. The auto-save feature exists but defaults to the unit's internal memory, which wipes on a hard fault under certain firmware versions. Don't rely on it. If you're working with these units regularly, invest in a second-hand oscilloscope with decoder support for EtherCAT frames. Debugging communication issues with just the LED indicators and error codes is possible but slow. A scope cuts average troubleshooting time from several hours down to under thirty minutes for most common bus-related faults.
Beta Mig 250 Manual — Where to Find It and What to Watch For
The manual is available as a PDF from the manufacturer's support site. Make sure you download the version matching your firmware revision — there have been significant layout changes between version 3.x and version 4.x documentation. The version 3.x manual has a useful quick-start flowchart on page 12 that was removed in later editions. If you're working with older units, track down a copy before they discontinue access. The downloadable manual includes a supplementary CD-ROM image with the configuration software, GSD files, and example projects. Some download links on third-party sites omit these extras. If you need the software, verify the download includes the full package. The configuration tool alone is worth having even if you don't use it immediately, because version mismatches between the tool and the unit firmware are a common source of commissioning delays.