Why Your Truth Tables Keep Getting Wrong and How to Actually Fix Them
I spent three days debugging a sequential circuit last year because I made a classic mistake during minimization. The logic was functionally correct on paper but produced a race condition in hardware. That's the thing nobody tells you about Boolean Algebra And Minimization Of Boolean Functions: getting the minimal expression is not the same as getting a working design. You can minimize perfectly and still have a circuit that glitches, oscillates, or just plain fails when you implement it. Here's how the actual process works when you're doing it by hand before you even think about throwing it at a tool.
The Quine-McCluskey Method Is Brutal But Reliable
For anything beyond five variables, Karnaugh maps become visually unmanageable. I've tried keeping a 6-variable K-map on paper. It looks like a child's drawing after two hours. The Quine-McCluskey algorithm is the mechanical alternative that doesn't care about your sanity. It works by grouping minterms that differ by exactly one bit, then iteratively combining those groups until no more combinations are possible. The result is the set of all prime implicants. From there you build an essential prime implicant chart and select the minimal cover. The downside is that it's exponential in complexity. Seven variables is already a pain. Ten variables will make your spreadsheet freeze or your manual work take an entire afternoon. I've hit this wall multiple times and had to switch strategies.
Karnaugh Maps Still Have Their Place
Up to about six variables, I still reach for K-maps because they give you visual intuition about adjacency and don't require algorithmic rigor. The trick most people miss is that the map isn't just about finding groups of ones. You also need to map the zeros if the complement of your function gives a simpler expression. This is especially relevant when your function has far fewer ones than zeros, which happens more often in real digital design work than textbook problems suggest. There's also the concept of don't care conditions. These aren't optional extras you throw in to make the minimization easier. In practice, certain input combinations will never occur in your system, and treating them as don't cares can reduce gate count significantly. But you have to be careful. If you assign a don't care incorrectly, you might end up with a hazard. A static hazard occurs when a single input variable changes and the output momentarily glitches to the wrong value before settling. I learned about this the hard way when a motor controller kept resetting under certain transition conditions. The fix was to add a consensus term to the minimized expression, which increased gate count by one AND gate but eliminated the hazard entirely.
Get the Full Details

Boolean Algebra And Minimization Of Boolean Functions In Practice
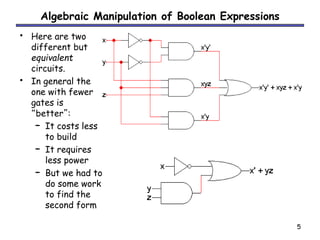
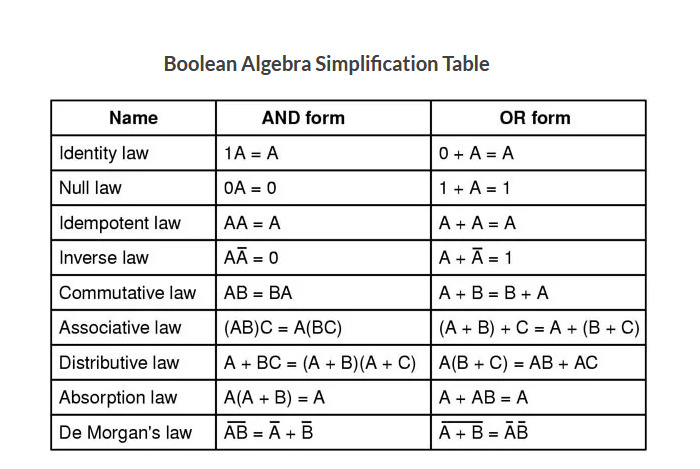
Boolean algebra itself is straightforward. You have the basic postulates: identity, null, idempotent, complement, commutative, associative, distributive, De Morgan's laws, and absorption. These are the tools you use when the algorithmic approaches aren't feasible or when you need to manipulate an expression by hand for a specific reason. The distributive law in particular gets used far more than people expect. Taking it in reverse, the factored form, is what you need when you're trying to share logic between multiple outputs in a multi-function gate implementation. Two-level minimization gives you a sum-of-products or product-of-sums form. Real circuits often benefit from multi-level optimization where you factor out common terms across multiple output functions. Here's a concrete example. Say you have a four-variable function f(A,B,C,D) = (0,1,2,5,8,9,10,14) with don't cares at d(A,B,C,D) = (3,7,11,15). Using a K-map, you'd group the ones. The minterms 0,1,2,3 and 8,9,10,11 form two rectangles of four. Minterm 14 needs to be covered, and with don't care 15 it forms a pair. The minimal SOP expression comes out to B'D' + B'C + ACD. But if you look at the POS form by grouping zeros instead, you get (B'+D')(A'+C')(A'+B). Neither form is universally better. The SOP uses three gates with a total of eight inputs. The POS uses three OR gates feeding a single AND, which on many FPGA architectures maps more efficiently to the available LUT structure.
Common Pitfalls I See Repeatedly
Beginners always forget to check for static hazards after minimization. A minimal SOP expression might not cover all transitions between adjacent minterms, leaving a gap where a hazard can occur. The fix is straightforward: add consensus terms for any pair of prime implicants that are adjacent but not overlapping. This increases the expression but guarantees hazard-free operation for single-input changes. Another mistake is assuming that the fewest number of product terms is always the optimal solution. Gate count, propagation delay, and power consumption matter more in production. A slightly larger expression with shared literals might use fewer transistors in CMOS than the theoretically minimal form. I've seen engineers optimize for minimum literals and then wonder why their ASIC synthesis report showed worse timing than a colleague's suboptimal-looking expression. The third pitfall is misusing don't cares. If a don't care condition actually can occur in your system, treating it as flexible during minimization and then fixing it afterward leads to incorrect behavior. Always verify your don't care set against the actual operational specification of the circuit. I had a project where the don't care was supposed to be unreachable because a particular state combination required two flip-flops to change simultaneously. In simulation it never happened. On silicon, setup time violations made that state reachable under thermal stress. The minimization was wrong for real conditions even though it was correct on paper.
When to Use What
For two to four variables, Karnaugh maps. Five to six variables, either K-maps with the extended folding technique or Quine-McCluskey by hand if you enjoy suffering. More than six variables, use a tool. Espresso is the standard heuristic minimizer used in logic synthesis. It's not guaranteed to find the global optimum, but it finds a good solution fast enough that you rarely need the exact answer. Industrial synthesis tools like Yosys, Synplify, or Design Compiler handle this automatically during the logic optimization stage. If you're working withProgrammable Logic Arrays or Field Programmable Gate Arrays, the minimization problem changes again. You're constrained by the available architecture, and the toolchain handles the mapping. Your job is to write correct, well-structured Boolean expressions and let the synthesis tool do the heavy lifting. Fighting the tool with hand-minimized expressions usually backfires because the tool's internal optimization pass will often undo your work anyway. The core principle is that minimization is a means to an end, not the end itself. Get the expression minimal enough that it meets your area and timing constraints, verify it for hazards and corner cases, and move on. Spending hours hand-minimizing a ten-variable function that a synthesis tool will optimize in thirty seconds is a poor use of engineering time.