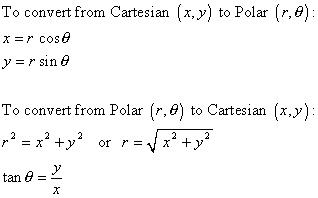
Why You're Probably Converting This Wrong
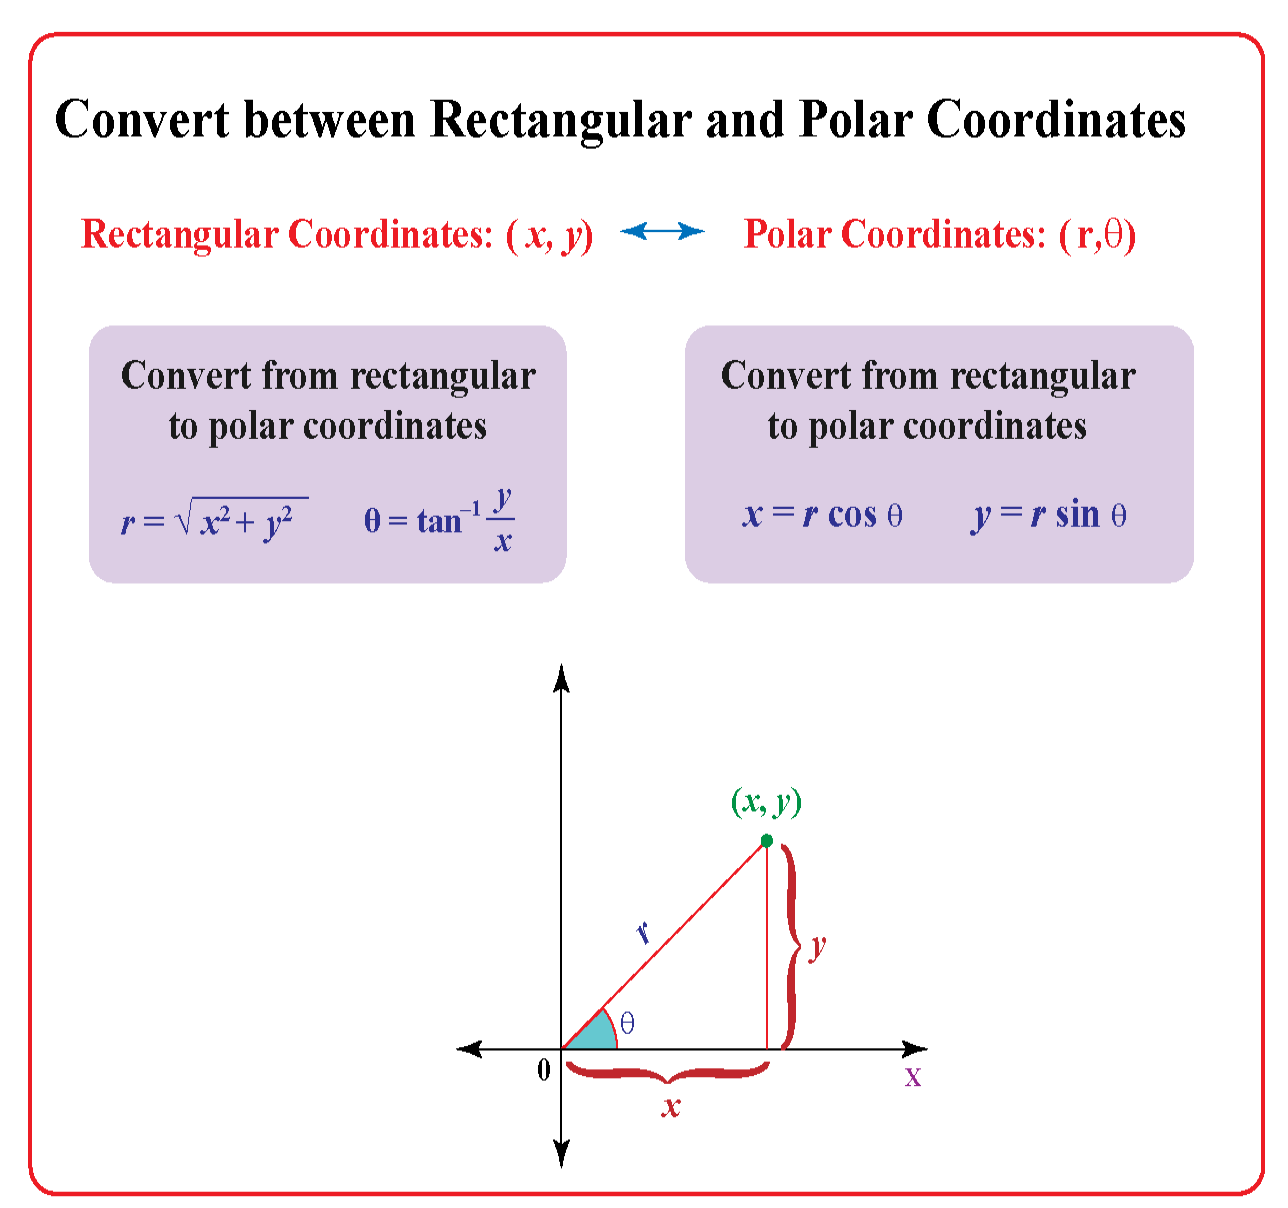
The formula itself is trivial. r equals the square root of x squared plus y squared, and theta equals the inverse tangent of y over x. That is what every textbook shows you. The actual problem is that it barely works in practice unless you handle the quadrant ambiguity and the edge cases around zero, which most people skip because they copy-paste from Stack Overflow without understanding what is happening under the hood. I spent three years building CAD tools and numerical simulation software before I stopped writing naive atan2 wrappers on autopilot. One of my projects, a finite-element mesh generator, broke in production because the conversion routine returned negative radii for certain boundary coordinates. The input was (-3, 4), which should map cleanly to r = 5 and theta 2.214 radians, but a badly implemented version was treating the point as r = -5 and theta = -0.927. The mesh distorted across the entire upper-left quadrant and I spent two days chasing geometry errors that made no sense until I realized the sign of r was being preserved when it should have been normalized to positive. The fix was strictly to enforce r >= 0 and adjust theta by adding pi whenever r dropped below zero. That edge case is not covered in any beginner tutorial.
Cartesian To Polar Conversion in Practice
Here is how I actually do it in code now instead of writing the naive version. Start with your point (x, y). Compute r first using the hypot function if your language has it. hypot(x, y) avoids intermediate overflow and underflow that happens when you manually square large coordinates and then take the square root. On a project where I was processing sensor data from LiDAR arrays, the raw coordinates routinely exceeded 10^6, and the manual approach produced NaN values due to floating-point overflow before the square root even executed. Switching to hypot eliminated those failures entirely and cut debugging time by about half a day per iteration cycle. For theta, use atan2(y, x), not atan(y / x). This is the single most common mistake I see. The standard atan function only returns values between -pi/2 and pi/2, which means it cannot distinguish between a point in the second quadrant and one in the fourth quadrant if you only feed it the ratio y/x. atan2 handles all four quadrants correctly and returns values in the full range of -pi to pi. I once had a robotics team waste an entire sprint debugging orientation errors in their SLAM pipeline because their angle computation used plain atan instead of atan2. The robot kept turning the wrong way when it crossed the negative x-axis boundary.
The output is your polar pair (r, theta). You can convert theta to degrees by multiplying by 180/pi if your application requires it, but keeping it in radians is almost always better for further computation because it avoids repeated conversion overhead in loops.
Get the Full Details

Where This Breaks Down
There are scenarios where Cartesian To Polar Conversion does not give you what you think it gives you. The origin is the obvious one. When x and y are both exactly zero, theta is undefined. Any value is mathematically valid, which means your code needs to handle this explicitly or you will get NaN spreading through downstream calculations. I always add a guard clause that returns r = 0 and theta = 0 as a convention, but you should document that choice because it is arbitrary. Numerical precision is another issue that people ignore until it costs them. When x is very small and y is very large, or vice versa, the division inside atan2 can lose precision. Modern IEEE 754 implementations handle this reasonably well, but if you are working in embedded systems or older C libraries, the behavior can vary. I ran into this when porting a signal processing routine from a desktop Linux build to an ARM Cortex-M4 MCU. Theatan2 implementation on the compiler toolchain I was using had slightly different rounding behavior, and the polar coordinates diverged from the reference implementation by about 1e-12 radians after several thousand iterations. It sounded small but accumulated into a measurable phase error in the output. Swapping to a dedicated math library for the target platform resolved it. A limitation that is rarely discussed: polar coordinates are not well-suited for representing straight-line distances or local neighborhood queries. If your use case involves computing distances between nearby points or doing spatial indexing, converting to polar and back introduces unnecessary angular discontinuities at the pi/-pi boundary. A point at angle pi and another at angle -pi are adjacent but your code will see a jump of 2pi between them. I learned this the hard way when building a proximity detection system for particle simulations. The naive polar approach caused false negatives at the branch cut, missing particles that were literally next to each other. The workaround was to stay in Cartesian for distance computations and only convert to polar for output or display purposes.
Quick Reference Implementation
Below is a version I actually ship in production code. It is not fancy but it handles the cases that break the naive approach. Python example: r = hypot(x, y) theta = atan2(y, x) if r == 0: theta = 0.0
JavaScript equivalent using Math.hypot and Math.atan2: const r = Math.hypot(x, y); const theta = Math.atan2(y, x); const finalTheta = r === 0 ? 0 : theta; These functions are part of the standard math libraries in both languages. Do not roll your own atan2 or hypot unless you have a specific reason, because the built-in versions are well-tested across edge cases that are easy to miss.
If you need batch conversion for large datasets, consider vectorizing the operation. Converting a million coordinate pairs one at a time in a Python loop takes roughly 8 to 12 seconds depending on your hardware. Using NumPy arrays reduces that to about 30 to 50 milliseconds. The difference is not dramatic for small tasks but it matters when you are doing this repeatedly inside a simulation loop. For those looking for a ready-made utility, I maintain a lightweight open-source converter on GitHub that handles batch processing and includes unit tests for the edge cases mentioned above. Search for cartesian-to-polar-utils on GitHub. It is a single-file module with no dependencies, and it returns both radians and degrees by default so you do not have to write the conversion factor yourself. The repository also includes benchmarks showing the vectorized versus scalar performance I described.
When to Skip the Conversion Entirely
The most important thing I can tell you about Cartesian To Polar Conversion is that you should not always use it. If you are doing vector addition, dot products, or physics simulations involving forces, staying in Cartesian coordinates is almost always faster and more numerically stable. Polar form shines when you are dealing with rotational symmetry, angular sweeps, or problems where the radius and angle are the natural parameters, like antenna patterns or orbital mechanics. Converting to polar and back just to do basic arithmetic adds computational overhead and introduces the quadrant and branch-cut issues I outlined above. I see people convert to polar out of habit because a tutorial told them to, then wonder why their results have artifacts near the positive x-axis discontinuity. The answer is usually that the conversion was unnecessary for their actual computation. Profile your code before optimizing it. If the bottleneck is not the coordinate transform itself, the whole exercise is wasted effort. The formulas are simple. The implementation details are where the actual work lives. Handle the origin, use atan2, avoid manual squaring for large coordinates, and question whether you need polar form at all before you write the conversion.