The Reality of Running a CNC Router Off an Arduino
Most people building a CNC router with an Arduino hit the same wall about three weeks into the project. They have the stepper drivers wired up, the limit switches connected, and a vague idea that they need "software" to make it work. What they actually need is a chain of three separate programs that talk to each other, and nobody explains how that chain works until you're staring at a half-cut piece of MDF that went nowhere because the G-code was feeding at the wrong feed rate. The pipeline is simple in theory and messy in practice. You start with a CAD program to draw what you want. Then you feed that drawing into CAM software that converts the geometry into G-code, which is just a text file of coordinate movement instructions. Then you use something like Universal Gcode Sender or a dedicated controller board firmware to push that G-code to the Arduino running GRBL or TinyG firmware.
Cnc Router Software For Arduino
When people search for Cnc Router Software For Arduino, they're usually looking for one of two things, and confusing the two is the most common mistake I see. The first is the CAD/CAM layer — the software where you design and generate toolpaths. The second is the controller layer — the firmware on the Arduino and the host program that sends commands to it. Most tutorials blur these together like they're the same thing. They aren't. They serve completely different purposes and have completely different failure modes. For the CAM side, Fusion 360 is the standard recommendation and for good reason. It's free for hobbyist use, handles 2.5D milling well, and generates clean G-code that GRBL actually understands. FreeCAD works too but the post-processing step feels like it was designed by someone who enjoys friction. For simple stuff, you can even draw directly in a text editor and write G-code by hand if you want to understand what's happening under the hood. On the controller side, you're looking at GRBL as the default firmware. It runs on an Arduino Uno or Mega, handles up to three axes natively, and has massive community support. The problem is that GRBL on a standard Arduino Uno has real limitations you won't notice until you're already in trouble. The Uno's 16MHz clock and limited memory mean that complex toolpaths with many linear interpolation points will cause the buffer to starve. The machine jerks, skips steps, and your part comes out wrong and you have no idea why because there's no error message — the G-code executed fine, it just executed slowly and inconsistently.
The USB Bottleneck Nobody Warns About
I spent a weekend troubleshooting a router that was cutting acceptable paths but consistently overshooting by about 0.3mm on longer moves. The G-code looked correct. The stepper drivers were set to the right microstepping. The belts were tensioned properly. The problem turned out to be USB packet fragmentation on the Uno. When the host PC sends G-code over USB at high baud rates, the Arduino's USB-to-serial chip can drop or reorder tiny packets if the host is doing anything else network-heavy. I switched to an Arduino Mega 2560, bumped the baud to 115200, and added a small delay buffer in the host software between line sends. The overshoot disappeared. That 0.3mm error was never a mechanical issue. It was the USB stack on a $20 microcontroller having an off day. This is one of those things that doesn't appear in any documentation. You have to hit it yourself before you believe it. If your cuts are consistently wrong in a predictable pattern, check the mechanical stuff first because that's what everyone tells you to do. But if the errors are random and intermittent, the problem is likely communication-related, not positioning-related. Run a test where you send a simple square G-code program and measure the actual output with a dial indicator. If the square comes out as a parallelogram, that's a timing issue. If it comes out slightly smaller or larger than programmed, that's a steps-per-mm calibration issue. Different problems, different fixes.
Get the Full Details

GRBL Configuration Is Where People Get Stuck
Flashing GRBL to your Arduino is straightforward. Uploading the compiled .hex file through the Arduino IDE takes maybe ten minutes if you've done it before. Configuring it properly takes another hour and determines whether your machine works or destroys material. The three settings that matter most are $100 through $103 (steps per millimeter for each axis), $110 and $111 (maximum rates), and $120 (acceleration). Most people leave the default steps-per-mm values and assume the software will calibrate itself. It won't. You need to physically measure what one full step of your motor moves your rail, account for your gear ratio or belt pitch, and calculate the correct value. A common 17mm leadscrew with 1.8-degree stepper motors at 1/16 microstepping gives you roughly 800 steps per millimeter. The GRBL default of 100 steps/mm means every command you send moves the axis ten times farther than it should. Your software will look like it's working fine while your router Carves a path three inches wide instead of the 0.3-inch path you told it to cut. Acceleration is another setting people get wrong. The default of 20 mm/s² is extremely conservative and makes your machine crawl. Raising it to 300 or 500 mm/s² is typical for a well-built router. But if your frame is any kind of aluminum extrusion sandwich with minimal bracing, higher acceleration will make the whole machine vibrate and walk across the floor during rapid movements. I learned this the hard way on a frame built from 2020 extrusion with no gussets. Dropped the acceleration to 100 and the part quality improved despite the slower cycle time. A stiffer frame would have let me run 400 without issues. The software can't fix a flexible machine.
Tool Selection Depends on What You're Actually Making
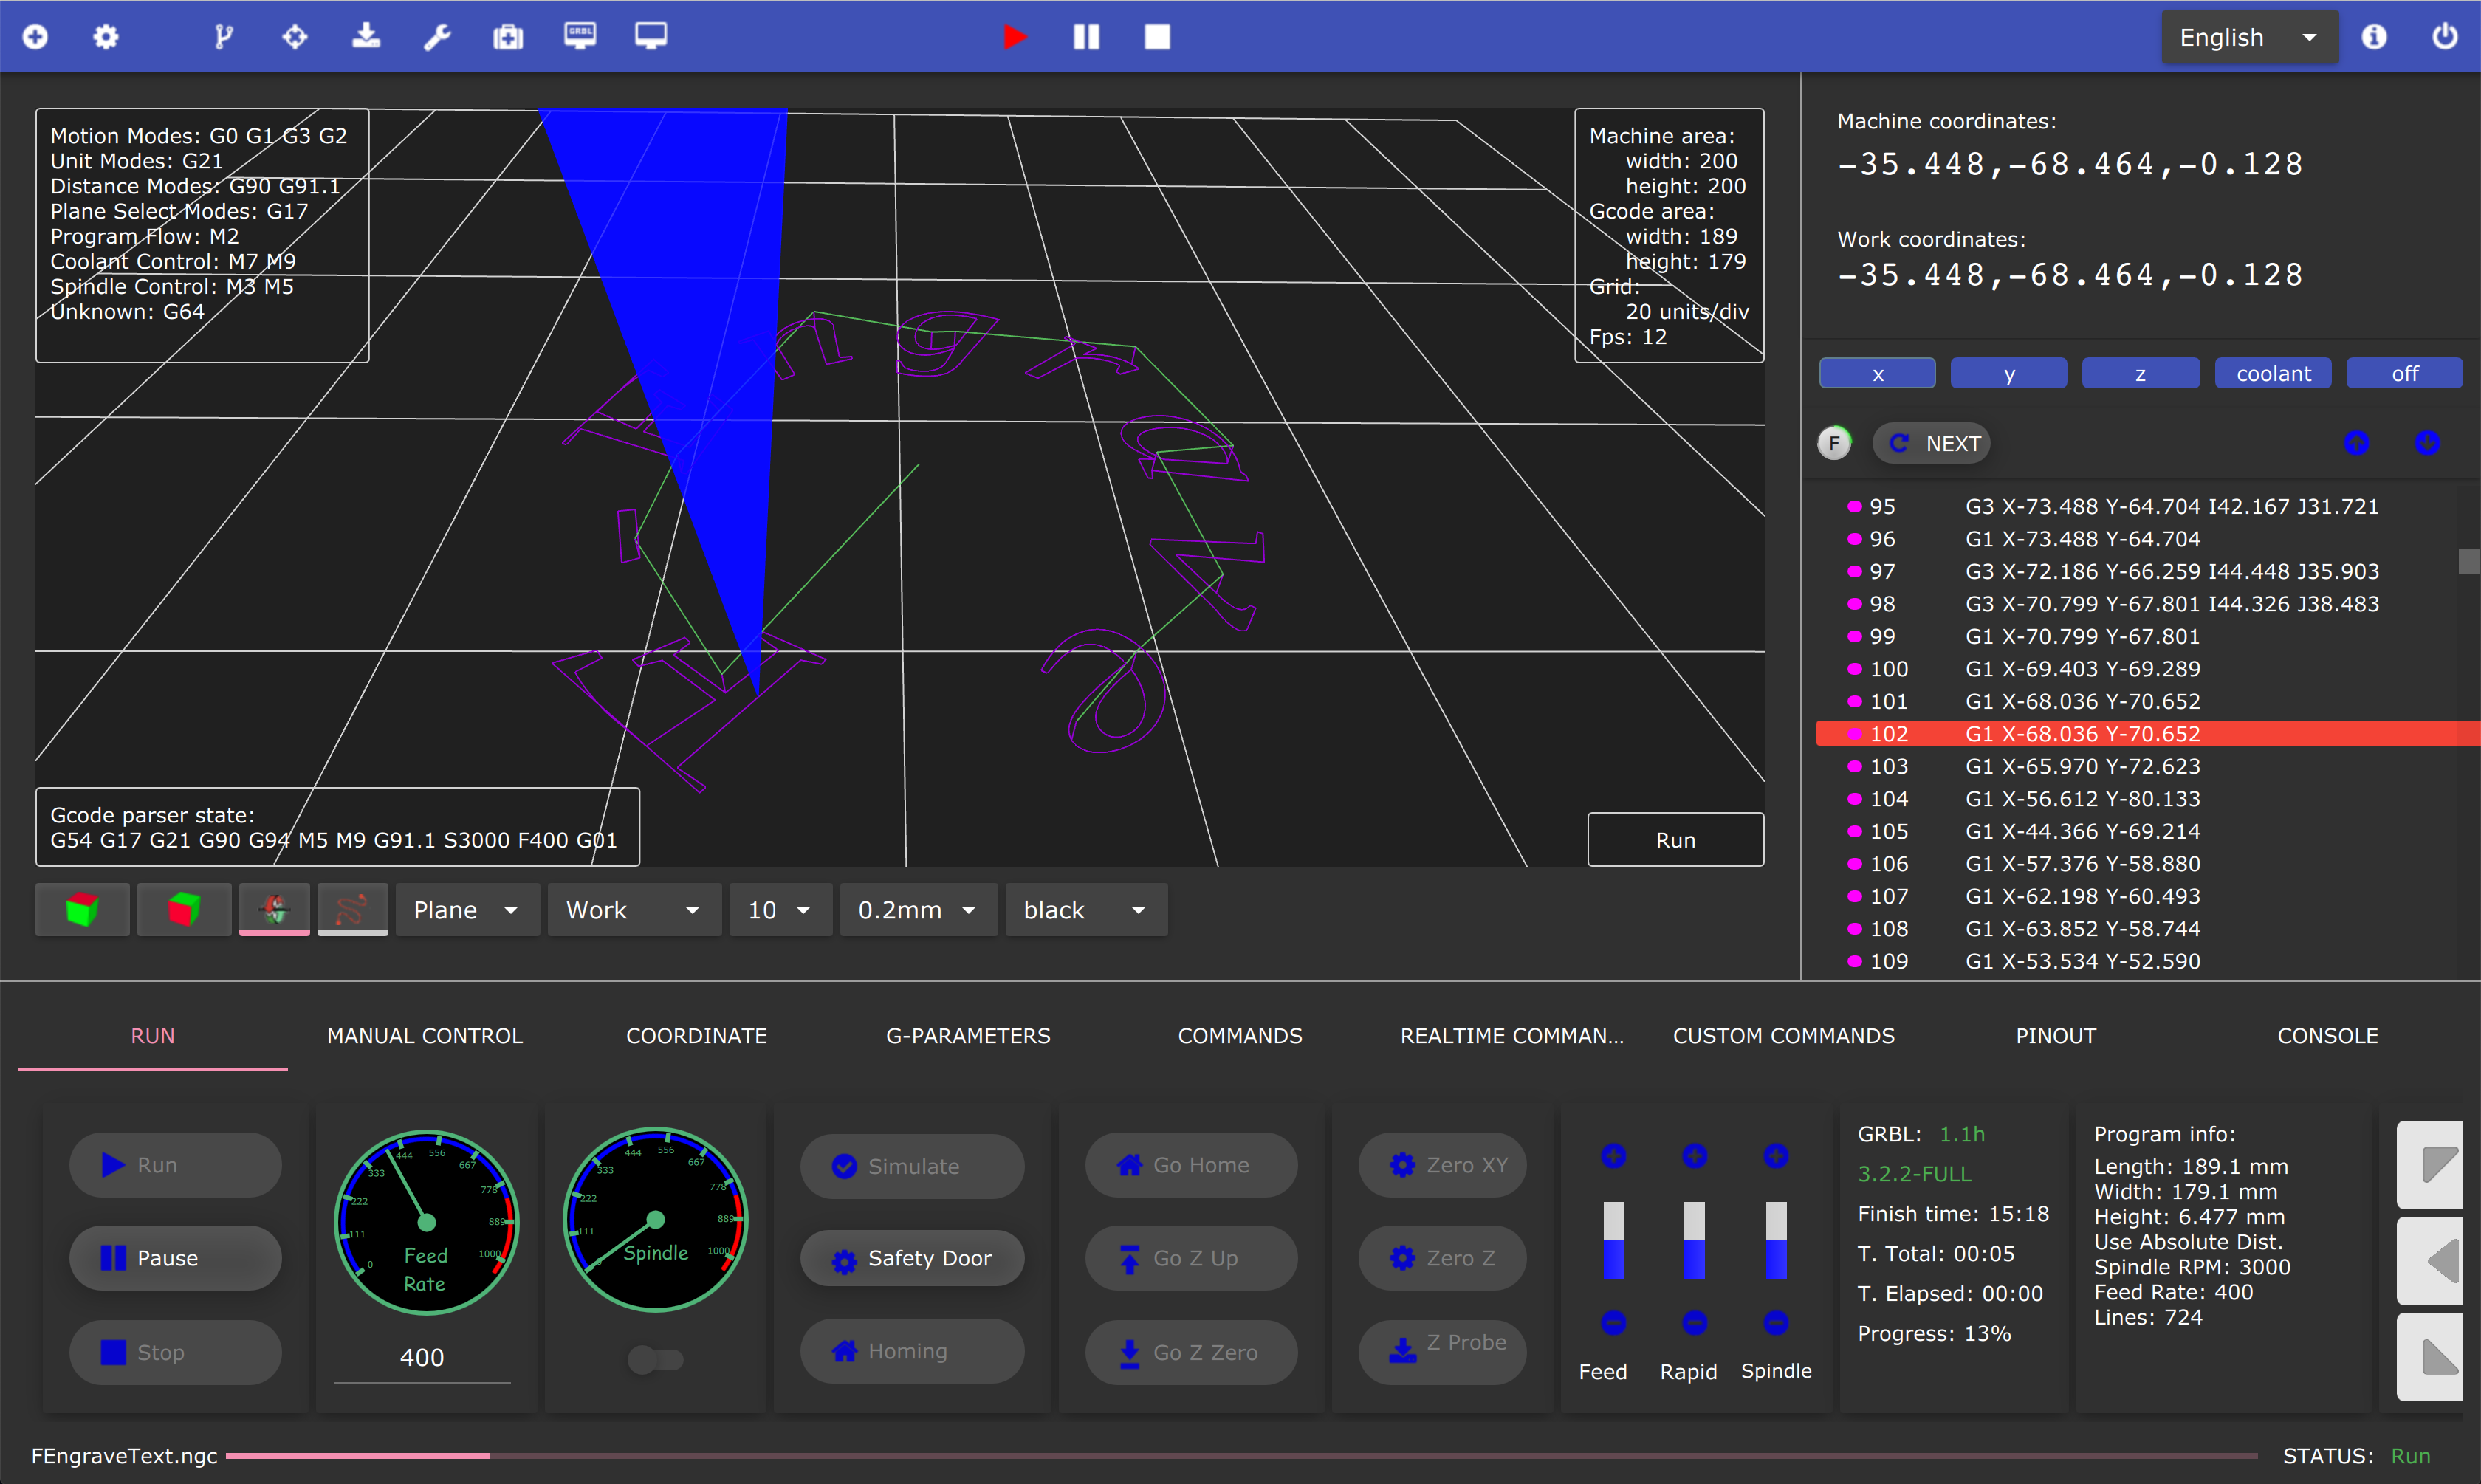
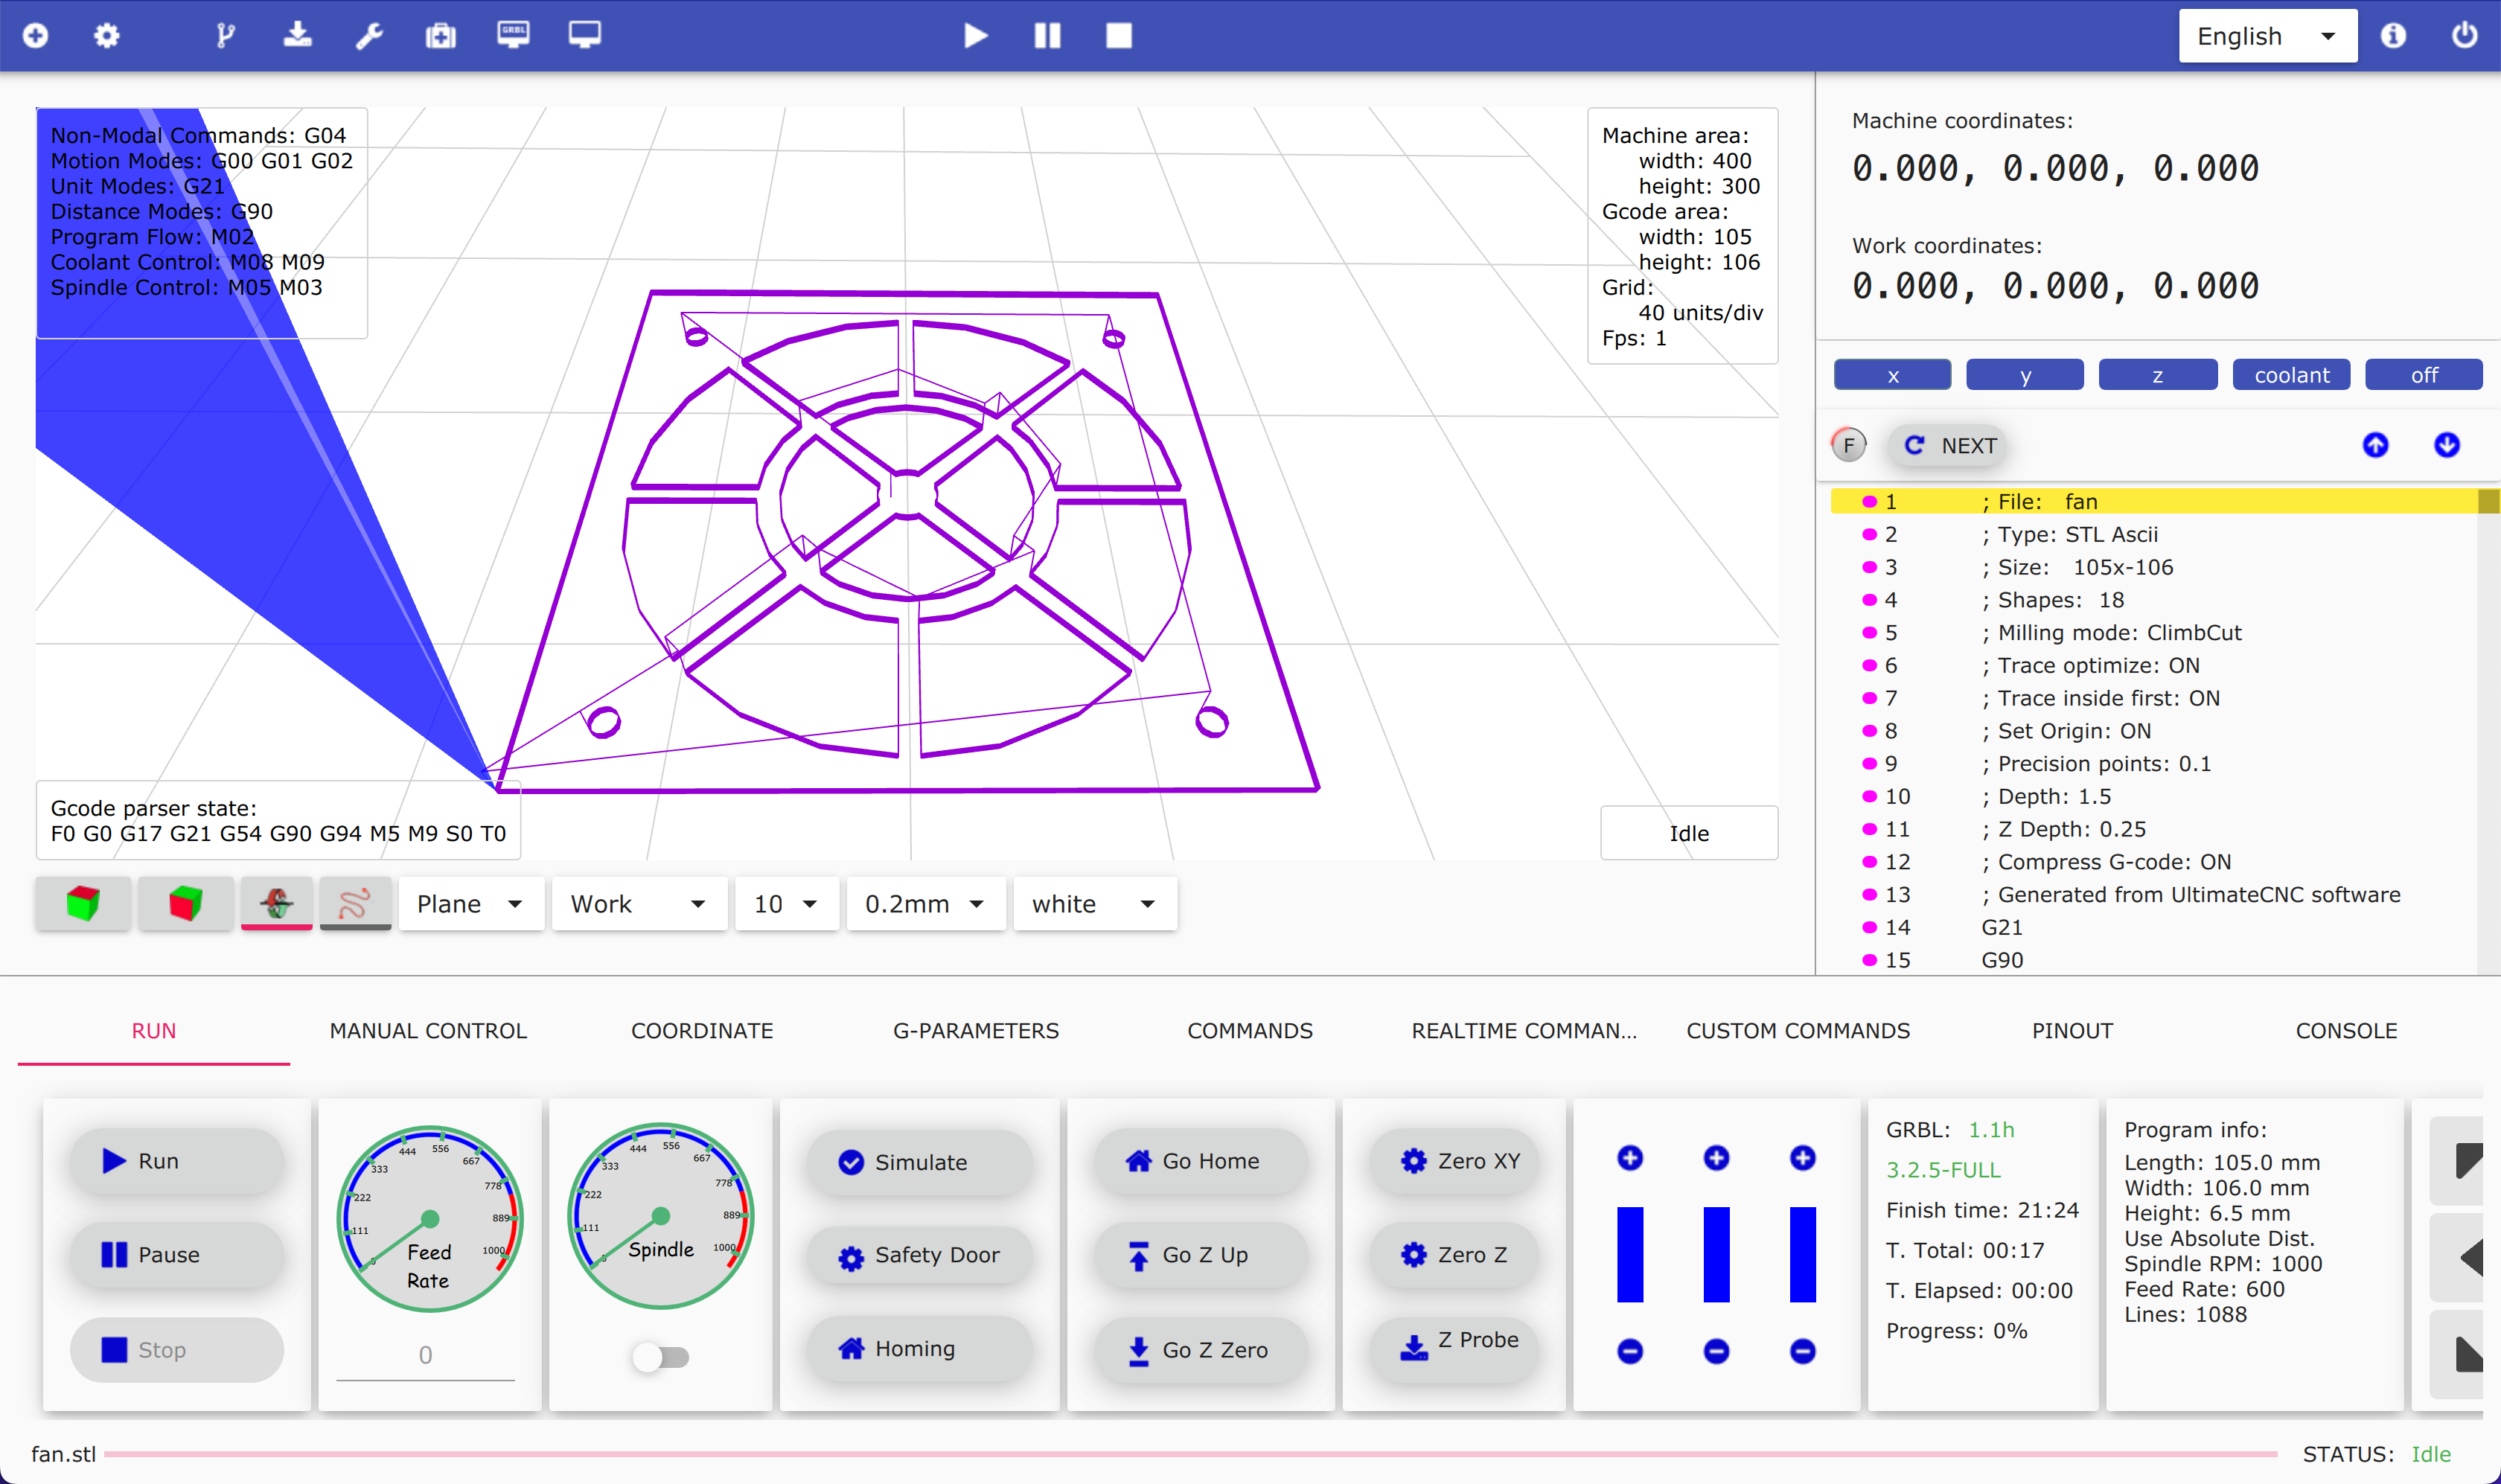
If you're cutting signage from 1/4 inch plywood with a 1/8 inch end mill, you don't need anything fancy. The default GRBL settings with a basic CAD-to-GCODE workflow in Fusion 360 or even a free tool like Carbide Create will get you through that project in a few hours. The bottleneck is your machine speed, not your software. If you're doing 3D relief carving from hardwood at depth, you're going to want adaptive clearing toolpaths and a CAM system that supports them. Fusion 360 does this well. For multi-axis work beyond simple 3-axis routing, you're leaving Arduino territory entirely and looking at something like Mach3 or LinuxCNC on a proper motion control card. The Arduino isn't going to handle four synchronized axes with compound interpolation reliably. It's possible with enough custom firmware work, but that's a different project from what you're probably thinking about. Universal Gcode Sender is the host program I'd recommend for most people. It's Java-based, runs on any OS, and gives you a visual representation of your toolpath before you send it. The free version has some limitations but they don't matter for basic routing work. The paid version adds features like laser mode and spindle control that you might find useful later. I've also used bCNC and it's lighter weight but less polished. Both will work fine with GRBL.
What Breaks First
In my experience, the failure sequence for Arduino-based CNC routers goes like this: someone builds the machine, flashes GRBL with defaults, skips calibration, cuts something successfully by luck, then tries a more ambitious project and everything falls apart because they never established baseline accuracy. The machine was never accurate to begin with. It just hadn't been asked to do anything that required accuracy yet. After that, the next common failure point is power supply sag under load. A 24V 5A supply might sound adequate on paper but can dip to 18V when all three axes are moving at speed. Stepper drivers lose torque when voltage drops, and you get skipped steps that look identical to calibration errors. Measure your voltage under load, not just at idle. If it sags more than 10%, you need a bigger supply or you need to slow the machine down. The third thing that breaks is the assumption that free CAD/CAM software is sufficient for production work. Fusion 360's free tier has usage limits and occasional license verification hiccups that can interrupt a workflow mid-project. If you're making five copies of the same part, the free version will let you do it. If you're making fifty, you'll hit the limit and have to wait or pay. This isn't a criticism of Fusion 360, it's just a boundary condition you need to plan around.
A Note on Alternative Firmware
GRBL isn't the only option. Marlin, originally written for 3D printers, works well on CNC routers and supports more axes and more complex kinematics. Smoothieware is another alternative but requires a different board architecture. TinyG is faster than GRBL in terms of internal processing but more expensive hardware to run it on. For a first build, stick with GRBL on an Arduino Mega if you can afford the extra $15 over the Uno. The additional I/O pins and slightly better memory management make a real difference when you're adding limit switches, probe inputs, and spindle control signals.