Why Your Friction Calculations Keep Going Wrong
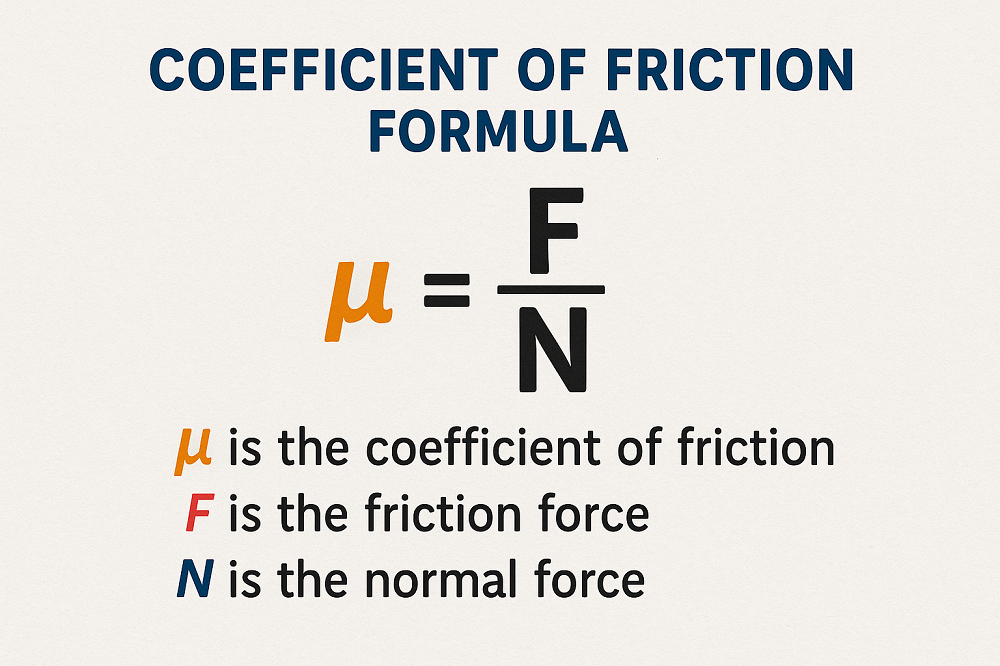
I spent three weeks debugging a conveyor system where the calculated friction value made zero sense against what was actually happening. The math checked out perfectly. The system still jumped and stalled every forty seconds. The problem wasn't the coefficient of friction formula. It was everything around it. Surface texture, temperature, the way the belt was tensioned, even the ambient humidity in that warehouse. Once I stopped treating mu as a fixed constant and started measuring it under actual operating conditions, the whole thing clicked into place. The coefficient of friction formula is deceptively simple on paper. You divide the frictional force by the normal force. That is it. F_friction divided by F_normal gives you mu, the dimensionless ratio that tells you how much two surfaces resist sliding past each other. But the second you try to use it for anything beyond a textbook problem, reality starts pushing back.
Understanding the Coefficient Of Friction Formula
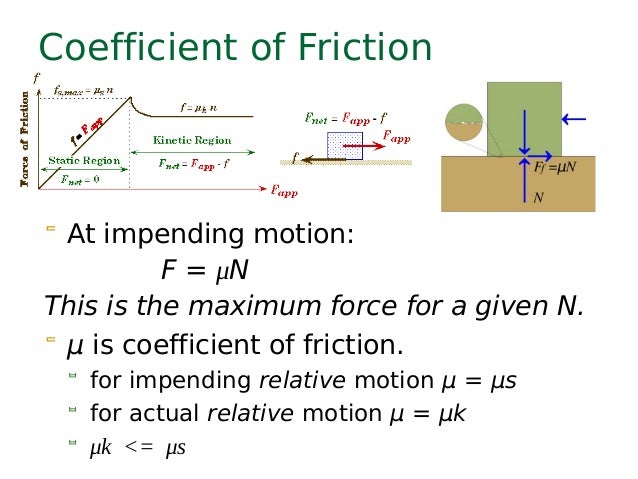
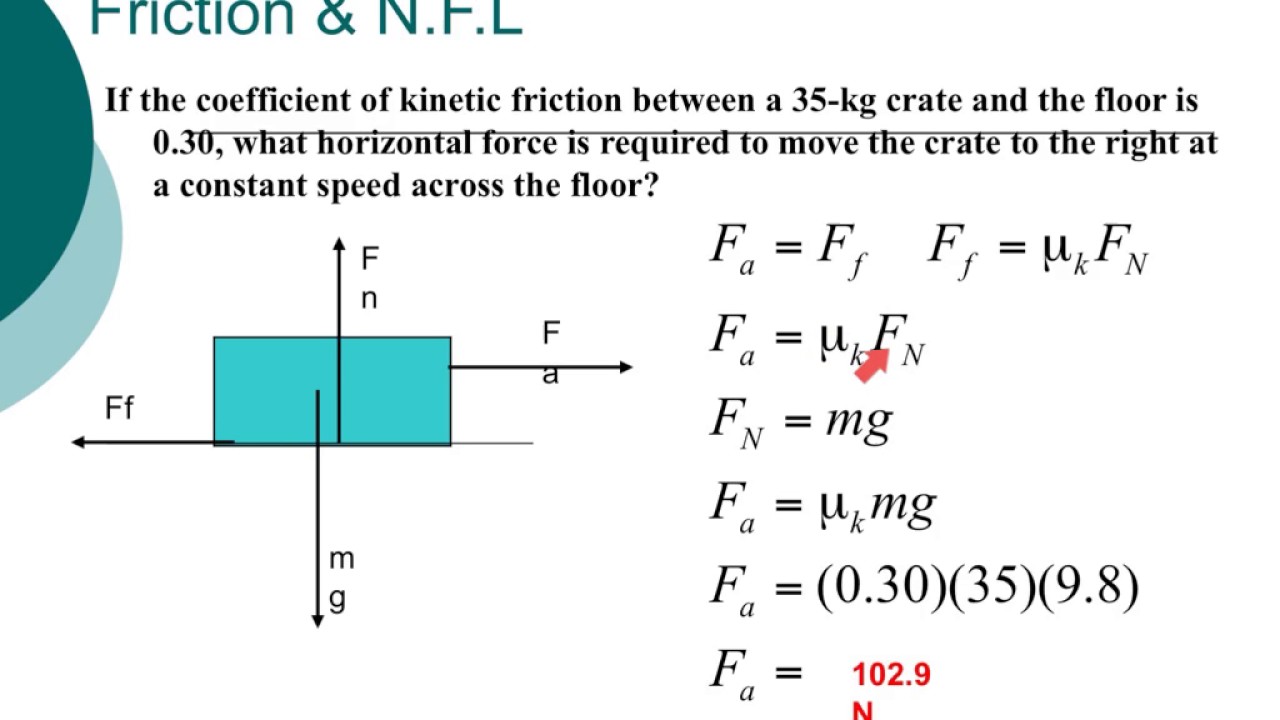
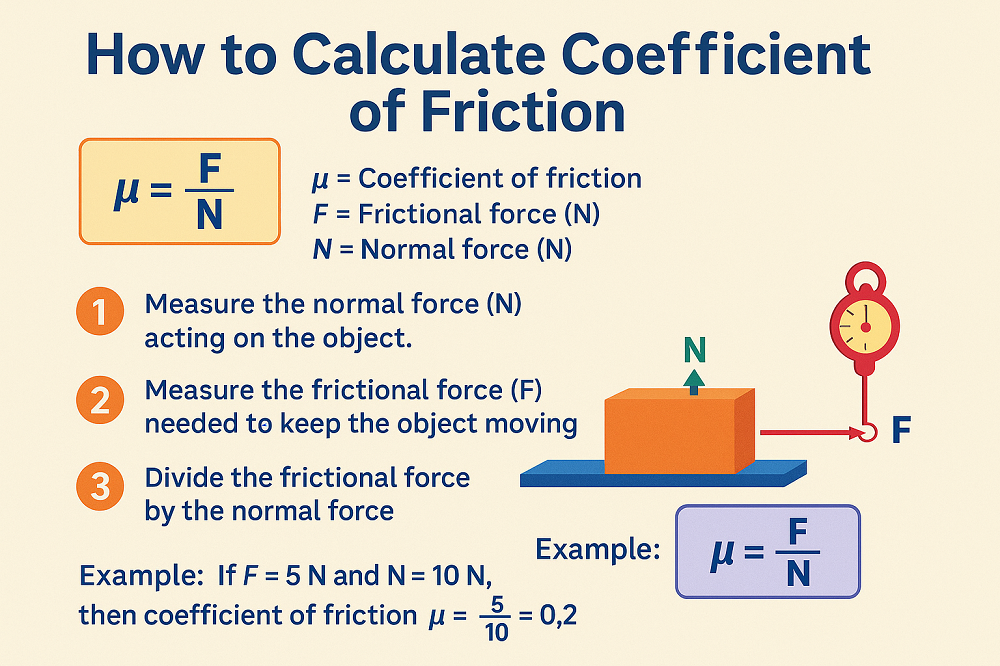
The standard form is mu equals F_f divided by F_n. F_f is the force parallel to the surface that you need to overcome to start or maintain sliding. F_n is the perpendicular force pressing the two surfaces together, which on a flat horizontal surface is usually just the weight of the object, mass times gravity. If you have a two-kilogram block sitting on steel and you need twelve point seven four newtons to pull it horizontally at a constant speed, your mu comes out to roughly 0.65. That is a reasonable number for dry steel on steel. What people miss is that mu is not a property of a material pair in the way thermal conductivity or density is. It is a property of a contact condition. Two surfaces can have dramatically different coefficients depending on surface finish, contamination, temperature, and whether you are measuring static or kinetic friction. The static coefficient, mu_s, is almost always higher than the kinetic coefficient, mu_k. That is why your heavy cabinet jerks forward once you get it moving. The transition from stationary to sliding involves breaking molecular bonds that formed during rest, and that takes more force than keeping them in motion. In practice, I usually work with the kinetic coefficient because that is what matters for most mechanical systems. Static friction is relevant for starting conditions and safety factor calculations, but kinetic governs the steady-state behavior you actually see in operation. If you are designing a braking system, both matter and you need to test under representative conditions. I learned that the hard way on a clutch assembly project where our published mu values from the material supplier didn't match what we measured after two hundred engagement cycles. The surface had glazed. The coefficient dropped by roughly eighteen percent. We had to redesign the heat dissipation and add a wear-in procedure to the acceptance testing. Took about a week of extra work that could have been avoided with real-world validation from day one.
How to Actually Use This in Real Work
When I need a reliable coefficient for a design, I don't grab a value from a handbook and call it done. I measure it on the actual materials, in the actual configuration, under the actual load and temperature. A quick test setup takes me about twenty minutes. I mount a force gauge on a low-friction pulley system, attach the test sample to the bottom surface, and pull at a consistent rate while recording the peak force for static friction and the average force during steady sliding for kinetic friction. I run at least five trials and take the average. The variation between trials is usually small, maybe five to ten percent, but that scatter is useful information in itself. High scatter means inconsistent surface conditions and you should probably investigate why before proceeding. If measurement isn't possible, handbooks like the Machinery's Handbook or data from the material supplier are your next best option. But treat those numbers as starting estimates, not truth. They are typically measured on cleaned, polished specimens at room temperature with no lubrication. Your real application will almost certainly differ. A plastic gear running against a steel shaft in a sealed housing with grease is a completely different scenario than the dry-tested values you will find in any table. I keep a small spreadsheet tracking my measured versus handbook values across projects. The pattern is always the same: handbook values are in the right ballpark but off by enough to cause problems if you design tightly around them. Allow a safety margin of at least twenty percent when using published data, and reduce that margin only after you have validated under your own conditions. One thing worth emphasizing is the difference between calculating mu and applying it correctly. Getting the number is straightforward. Using it properly requires understanding what regime your system operates in. Hydrodynamic lubrication, boundary lubrication, mixed mode, dry contact with asperity engagement. Each regime has a very different relationship between load, velocity, and the effective friction coefficient. In my experience, most friction problems show up because someone applied a dry-sliding mu to a situation where a thin oil film was actually present, or vice versa. The numbers looked fine on paper. The equipment suffered within months from unexpected wear.
Get the Full Details
Common Mistakes and What to Do Instead
The most frequent error I see is treating mu as a single constant for the entire operating envelope. It changes with temperature. It changes with speed. It changes with surface wear. I once saw a design where the team used a room-temperature coefficient for a bearing housing that would operate at seventy degrees Celsius under load. The actual coefficient was about twelve percent lower at that temperature. The bearing ran hotter than predicted, the lubricant thinned further, and the coefficient dropped even more. Positive feedback loop that ended in premature failure. We caught it by running a thermal-friction test that mapped mu across the expected temperature range. Twenty minutes of testing saved us from a warranty claim cycle. Another mistake is ignoring the normal force variation. On an incline, F_n is not mg. It is mg times cosine of the angle. On a rotating surface, centripetal effects change the effective normal load. These aren't subtle corrections. They are the difference between a calculation that works and one that doesn't. I always double-check the normal force component before trusting any mu calculation. It sounds basic but I have seen it trip up experienced engineers on occasion. Surface preparation matters more than most people realize. A machined surface that looks smooth to the eye can have a very different coefficient than a ground or polished surface. Roughness height, lay direction, residual stresses from machining, even the cleaning solvent used before testing can shift mu by ten to twenty percent. When precision matters, document your surface preparation method alongside your friction data. Future you will thank you when you need to reproduce results six months later.
The formula itself has limitations that deserve attention. It assumes a constant coefficient across the contact area, which is rarely true for real surfaces with varying pressure distribution. It does not account for adhesion effects at the microscopic level. It breaks down entirely for viscoelastic materials like rubber where the friction depends strongly on sliding speed and contact time. If you are working with polymers or elastomers, the Coulomb model is a rough approximation at best and you should look into more sophisticated approaches like the Greenwood-Williamson contact model or empirical testing tailored to your material system. There is also the issue of stick-slip motion, which the simple coefficient formula cannot predict. When the difference between static and kinetic friction is large and the system has stiffness in the driving mechanism, you get alternating stick and slip cycles. This causes vibration, noise, and uneven motion. I encountered this in a linear guide system where the calculated mu values suggested smooth operation, but the actual behavior was jerky at low speeds. The solution wasn't a different coefficient. It was increasing the system stiffness and adding a damping element to suppress the oscillation between the static and kinetic regimes. Sometimes the problem isn't in the number but in the dynamic interaction around it. For most everyday engineering work, the coefficient of friction formula gives you enough accuracy if you respect its assumptions and validate under real conditions. Measure when you can. Use handbook values cautiously. Account for temperature, speed, and surface condition. And remember that the number you calculate is only as good as the conditions you measured it under. A well-documented test result from your actual setup beats a perfect calculation based on idealized assumptions every time.