Understanding Perfectly Elastic Collisions in Practice
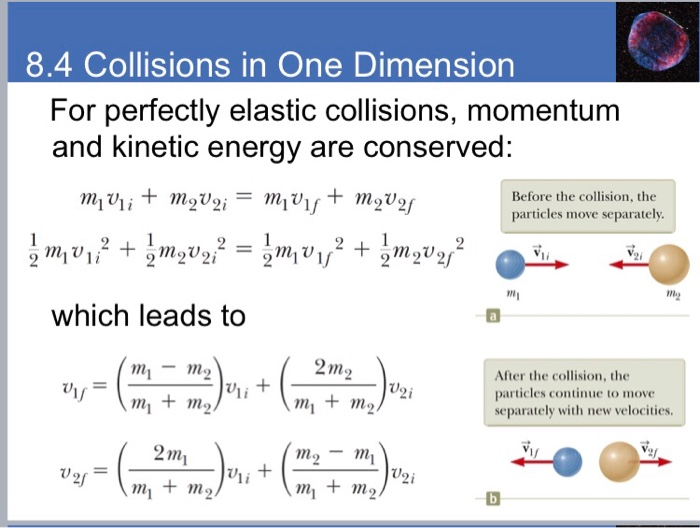
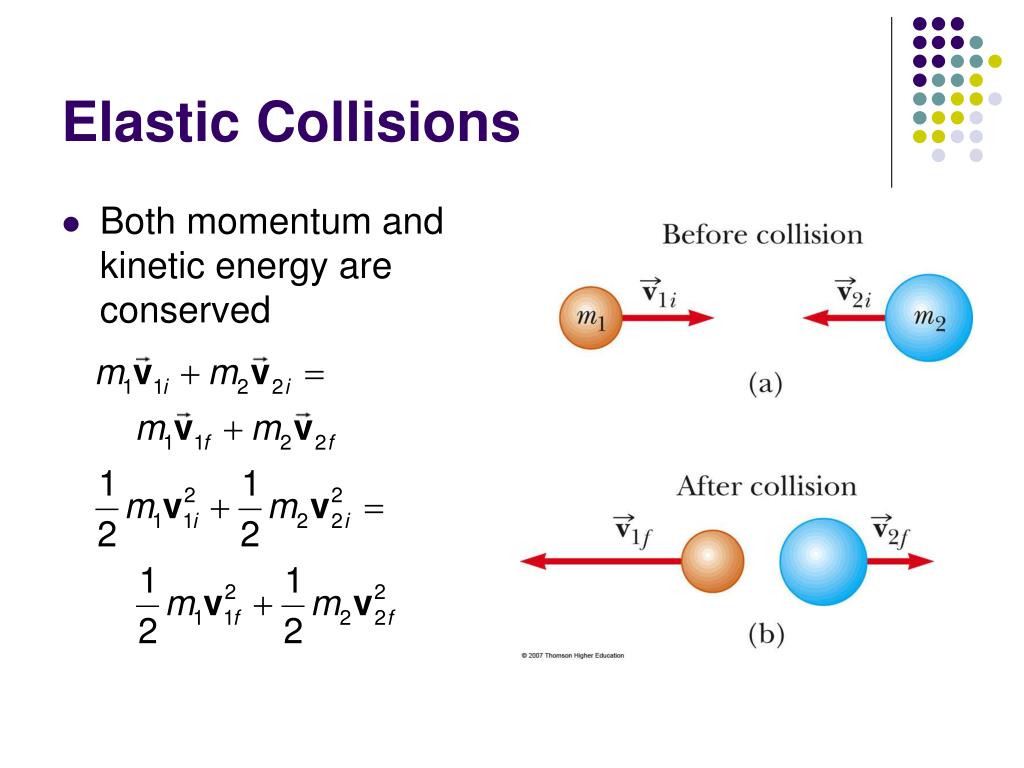
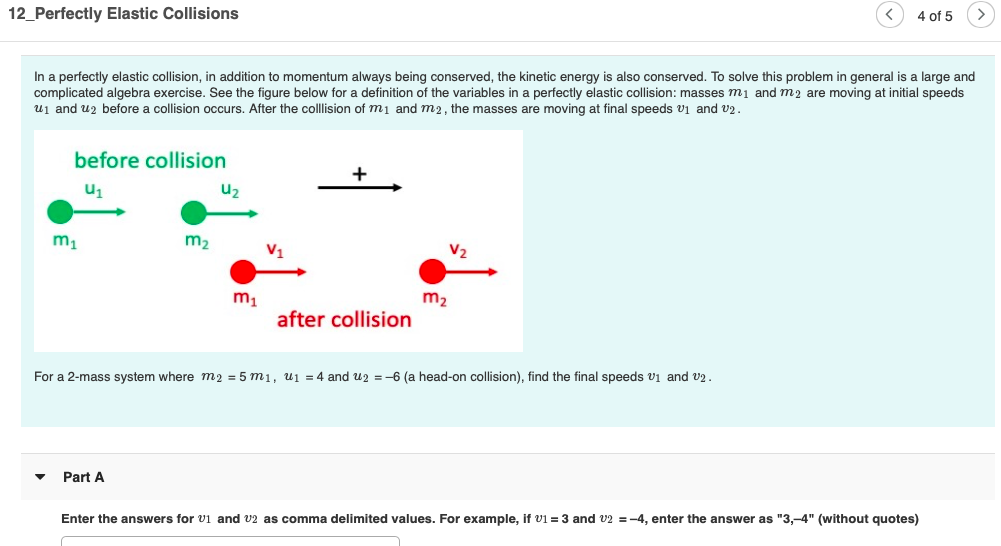
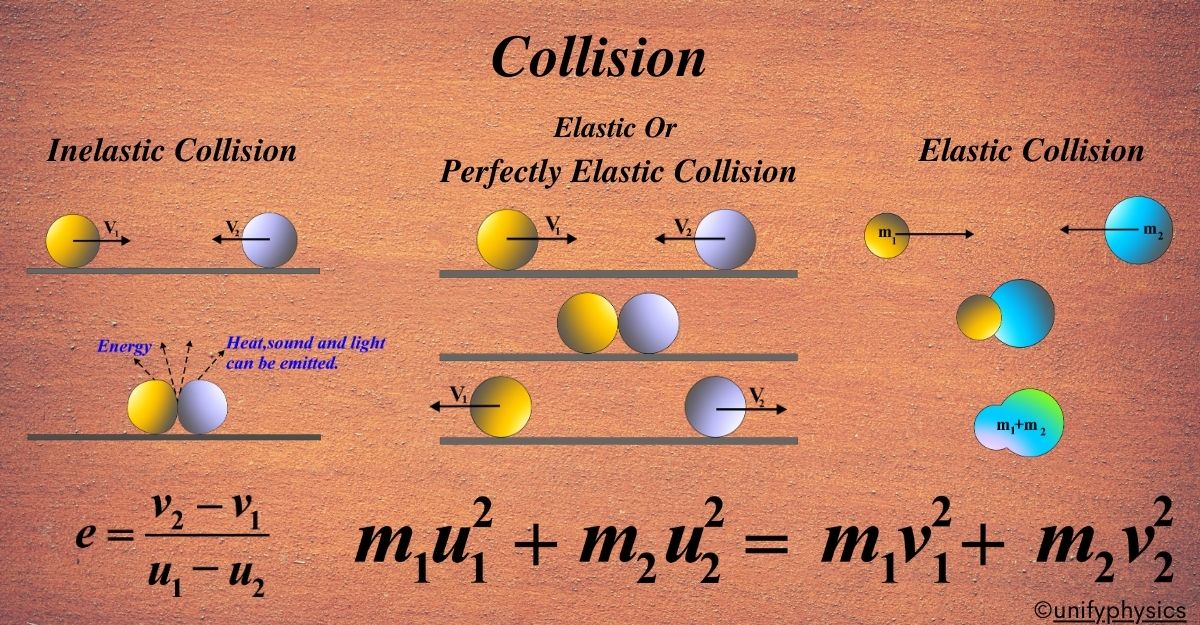
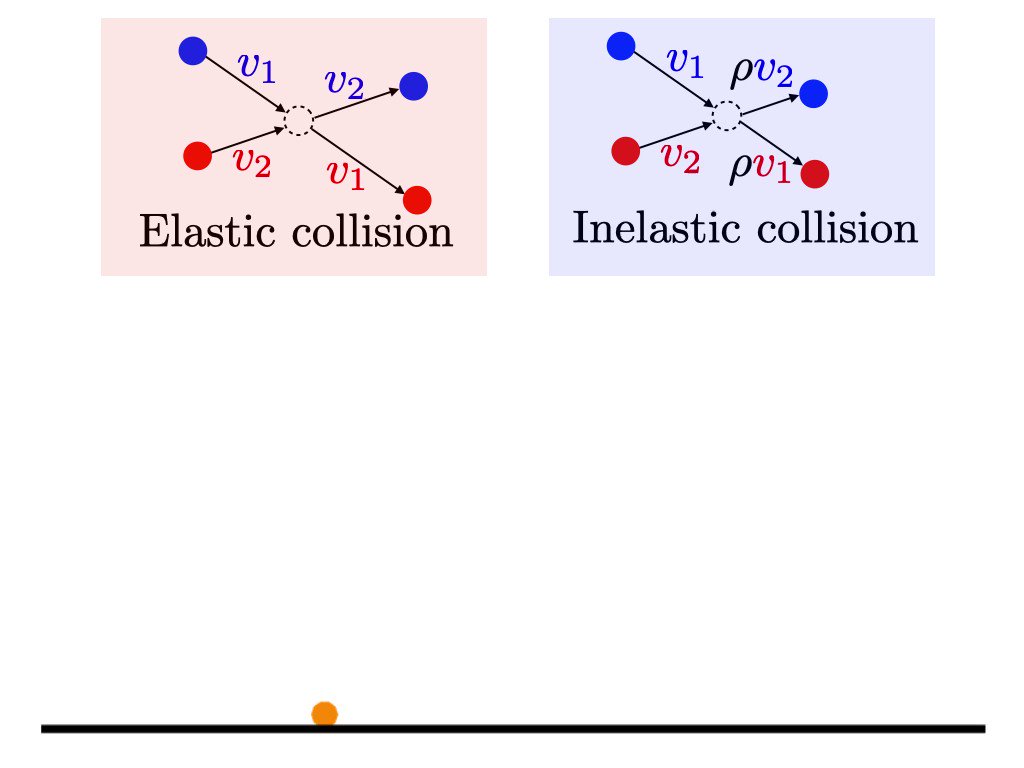
When two objects collide and bounce off each other without losing kinetic energy, that's what physicists call a perfectly elastic collision. In real life, you'll almost never find a true example of this outside of subatomic particles, but the model still matters for building accurate simulations, solving textbook problems, and understanding how energy transfers between bodies. The core idea is straightforward enough. Two quantities stay constant throughout the collision: total momentum and total kinetic energy. That means you can write two equations and solve for the final velocities of both objects. The momentum equation is m1v1i + m1v2i = m1v1f + m2v2f. The kinetic energy equation is ½m1v1i² + ½m2v2i² = ½m1v1f² + ½m2v2f². When you solve those together, you get the well-known one-dimensional elastic collision formulas.
What Collision Is Perfectly Elastic Actually Looks Like
I spent years building physics engines for sports simulation software, and one thing I learned the hard way is that treating collisions as perfectly elastic in a game engine will give you objects that bounce forever. That sounds fine until you realize your basketball never stops bouncing after a dunk, or your pool balls slide across the table without ever settling. The numbers don't lie, but they also don't account for reality unless you add damping somewhere. My specific headache came up with a cue ball physics module. I set the coefficient of restitution to 1.0 for all ball-to-ball collisions to keep things simple. Within three frames of a break shot, the rack was vibrating at unrealistic frequencies because tiny numerical errors in the solver kept feeding energy back into the system. I ended up switching to a coefficient of restitution around 0.95 for the primary collisions and then adding a separate velocity-dependent friction term for rolling decay. That kept the break looking realistic while preventing the energy blowup that was making the simulation unusable. Here's the thing most people miss when they first learn this material. The elastic collision formulas assume an instantaneous collision with no external forces acting during the impact interval. That assumption breaks down quickly if your objects are deforming, rotating, or if friction between them is significant. A spinning billiard ball hitting another ball doesn't behave the same way a non-spinning one does, and the standard formulas don't capture that. You need to account for angular momentum transfer separately.
Another counter-intuitive point: mass ratio dramatically affects the outcome, and not in the way beginners expect. When a heavy object hits a light stationary object, the heavy one barely slows down and the light one shoots off at roughly twice the heavy object's speed. But when a light object hits a heavy stationary one, it bounces back at nearly its original speed while the heavy object barely moves. The middle ground is equal mass, which is why pool players care so much about mass consistency in their balls. If you're implementing this in code, I'd recommend using the relative velocity approach rather than solving the system of equations from scratch every time. The shortcut is that the relative velocity of approach equals the negative of the relative velocity of separation. So v1i - v2i = -(v1f - v2f). Combine that with momentum conservation and you get clean closed-form solutions without any quadratic drama. For one dimension, the final velocities work out to v1f = ((m1-m2)v1i + 2m2v2i)/(m1+m2) and v2f = ((m2-m1)v2i + 2m1v1i)/(m1+m2). The limitation you need to keep in mind is that perfectly elastic collisions don't exist at macroscopic scales. Even steel ball bearings on a track lose some energy to sound and heat. Diamond is one of the closest real-world approximations I've seen, with a coefficient of restitution around 0.95, but that's still not perfect. If your application requires actual precision, like in particle physics or molecular dynamics simulations, you'll want to use more sophisticated models that account for potential energy surfaces and quantum effects rather than relying on classical elastic collision assumptions.
Get the Full Details
For game development and general simulation work, the perfectly elastic model is a useful starting point but it's not a complete solution. You need to layer in restitution coefficients, friction, and numerical damping to get results that don't look wrong. Start with the elastic formulas as your baseline, then measure how much energy your real system loses and adjust from there. The math gives you a foundation. Reality fills in the gaps.