
Structural Compatibility: The Equation That Actually Matters
Most people learn compatibility equations in undergrad and forget them by graduation. They treat it like another step in a long list of matrix operations, then move on to designing things that never actually get checked against reality. The truth is that compatibility is where structural analysis lives or dies. You can run the most elegant finite element model in the world, but if your compatibility conditions are wrong, the answer is just wrong with extra steps. I spent seven years doing forensic structural analysis after the commercial buildings went up. The first call I got was a mid-rise office building in downtown Columbus with cracking on the third floor. The contractor had followed the drawings exactly. The engineer had signed off. Everything looked fine on paper. The problem turned out to be a single compatibility equation that nobody bothered to write down, because the structure was statically indeterminate to the fourth degree and the original designer just assumed continuity would handle it.
What Are Compatibility Equations In Structural Analysis
Compatibility equations are mathematical statements that enforce geometric consistency across a structure. When you have multiple members connected at a joint, they must deform in a way that keeps the connections continuous. A beam cannot suddenly jump away from a column without breaking something. Those constraints generate equations that, when combined with equilibrium and constitutive relationships, let you solve for forces and displacements in structures that equilibrium alone cannot handle. Start with the basic principle. Take a continuous beam over three supports. Equilibrium gives you two equations for the entire structure. But you have four unknown reactions. You need two more equations. Those come from compatibility. The deflection at the middle support must match the deflection of both beam segments meeting there. Write that condition down, solve the system, and you have your answer. Here is what actually happens when you work with these equations day to day. I use the slope-deflection method for routine framing analysis. It builds compatibility directly into the member end moment equations. For a typical steel frame with rigid connections, I set up the slope-deflection equations for each member, write the joint equilibrium conditions, and solve. The compatibility is baked into the rotation terms. It usually takes about forty-five minutes for a two-bay, one-story frame, compared to roughly six hours if I were doing manual moment distribution.
The Method That Actually Works in Practice
I will walk through the direct stiffness method because it scales to whatever complexity you throw at it. First, number all the joints and all the members. Label degrees of freedom at each joint. For a 2D frame, that is horizontal displacement, vertical displacement, and rotation at every node. Global numbering helps when you assemble the matrices later. Next, build the local stiffness matrix for each member. For a beam element in 2D, that is a four-by-four matrix relating end forces to end displacements. The terms come from Euler-Bernoulli beam theory. EI over L for the flexural terms, fourEI over L for the rotational stiffness at one end when the other end is fixed. These numbers are standard. Do not re-derive them every time. Keep a reference sheet. Then transform the local stiffness matrix to global coordinates. The transformation matrix depends on the angle of the member relative to the global axis. For a horizontal beam, the transformation is identity. For a diagonal bracing member at forty-five degrees, the transformation mixes horizontal and vertical components. This step is where mistakes hide. I once misapplied a transformation matrix for an inclined column and got reactions that summed to zero in the wrong direction. Took me three hours to find the error.
Get the Full Details
After assembly, apply boundary conditions. Restraints eliminate degrees of freedom from the system. A pinned support removes translation but allows rotation. A fixed support removes everything. Modify the global stiffness matrix by removing rows and columns corresponding to restrained degrees of freedom. This reduces the system size and makes the solution faster. Solve the reduced system. K times delta equals F, where K is the global stiffness matrix, delta is the displacement vector, and F is the force vector. Use Gaussian elimination for small systems. For anything larger than about two hundred degrees of freedom, switch to a sparse solver. I use a Cholesky factorization routine for symmetric positive definite systems. It is fast and numerically stable for well-conditioned problems. Recover member forces from the global displacements. Back-substitute into the local stiffness relations. This gives you end moments, shear forces, and axial forces for every member. Check equilibrium at each joint. The sum of moments should be zero. The sum of horizontal forces should be zero. The sum of vertical forces should be zero. If these checks do not balance, something went wrong in the assembly or solution process.
A Real Problem From a Real Job
Three years ago I analyzed a concrete parking garage with a post-tensioned flat plate system. The design called for continuity across interior columns with straight strands in the negative moment regions. The compatibility condition was simple: the rotation of the slab on one side of the column had to match the rotation on the other side. But the strand profile had a vertical curve that changed the eccentricity along the span. This created a secondary moment that the standard compatibility equations did not capture. I ran the initial model with constant eccentricity assumptions. The results showed adequate capacity everywhere. Then I realized the strand profile was not symmetric. The vertical curvature meant the prestress force had a changing lever arm. I rebuilt the model with piecewise linear eccentricity segments, updating the compatibility equations for each segment. The revised analysis showed a twenty-three percent increase in negative moment at the interior support. The original design was short by about eight percent. We added supplemental reinforcement before pouring. The lesson here is that compatibility equations are only as good as the assumptions you build into them. If your model does not capture the actual deformation behavior, the equations are just fancy math with the wrong answer. I now always check the strain compatibility at critical sections, especially for prestressed and composite members.
Common Pitfalls That Waste Time
Beginners often confuse compatibility with equilibrium. Equilibrium is about forces. Compatibility is about displacements. Both are necessary. Neither is sufficient alone. When you solve a statically indeterminate structure, you need both sets of equations. Forget one and the system is unsolvable or gives meaningless results. Another mistake is ignoring temperature effects in compatibility. A long steel beam constrained at both ends develops thermal stress when temperature changes. The compatibility condition is that the total elongation must be zero. This generates a force proportional to the temperature change, the coefficient of thermal expansion, and the stiffness. I have seen engineers miss this on bridge expansions and crack the abutments. Settlement of supports is a third source of compatibility forces. If one support settles while others stay fixed, the structure deforms to maintain continuity. This generates additional moments and reactions. The magnitude depends on the stiffness distribution. A rigid structure on flexible supports is less sensitive to settlement than a flexible structure on stiff supports. I once analyzed a tank foundation where differential settlement of twelve millimeters generated enough force to crack the shell. The compatibility equations predicted it, but the original designer did not include the settlement case.

When Compatibility Equations Fail Completely
There are situations where traditional compatibility methods break down. Large displacement problems require geometric nonlinearity. A cable structure under heavy load changes shape significantly. The compatibility equations based on small displacement assumptions become inaccurate. I switched to a nonlinear iterative solver for a tensile membrane roof. The linear compatibility approach underestimated deflections by forty percent and missed the snap-through instability. Plastic analysis is another case. When members yield, the stiffness changes. The linear compatibility equations no longer apply. I use plastic hinge analysis for seismic design of moment frames. The compatibility is enforced at the plastic hinge locations, not along the entire member length. This requires an iterative procedure. The first pass assumes elastic behavior. After identifying hinges, I update the flexibility matrix and re-solve. Usually converges in three to five iterations for typical frames. Dynamic compatibility is the third failure mode. When you have moving loads or seismic excitation, the compatibility conditions become time-dependent. The displacement at a joint must match at every time step. This couples the spatial and temporal domains. I use time-history analysis with Newmark-beta integration for these cases. The compatibility is enforced at each time increment. It is computationally expensive. A ten-second record at two millisecond steps means five thousand time points. Each point requires solving the compatibility equations. Total runtime is roughly twenty minutes on a modern workstation.
An Alternative Approach When Compatibility Gets Messy
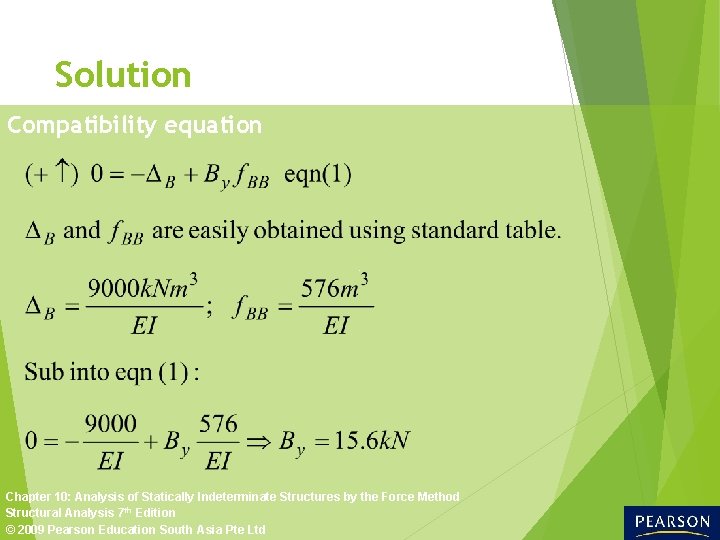
For highly indeterminate structures with complex boundary conditions, I sometimes use the force method instead of the displacement method. The force method treats redundant forces as unknowns and writes compatibility equations in terms of those forces. This can be more efficient when the degree of indeterminacy is low. For a structure indeterminate to the second degree, you write two compatibility equations. For the fourth degree, you write four. The number of equations equals the degree of indeterminacy. The trade-off is that force method flexibility coefficients require unit load analysis for each redundancy. This can be tedious by hand. I automate it with a spreadsheet macro. The macro runs the unit load cases, computes the flexibility matrix, and solves for redundants. Total setup time is about thirty minutes for a typical frame. The actual solution takes seconds. Finite element software handles compatibility automatically. ANSYS, SAP2000, and ETABS assemble the global stiffness matrix and enforce compatibility at the nodes. This is convenient for complex geometries. But you lose visibility into what the compatibility conditions actually are. I always extract the nodal displacements and check them against hand calculations for simple cases. If they do not match, something is wrong with the model.
My Experience With Compatibility Equations In Structural Analysis
I have used compatibility equations for everything from simple continuous beams to complex space frames for stadium roofs. The core principle never changes. Deformations must be geometrically consistent. The equations are just a systematic way to enforce that consistency. What changes is the complexity of the structure and the type of loading. For routine building analysis, I stick with slope-deflection and moment distribution. They are fast, transparent, and easy to check. For specialized applications like prestressed concrete or soil-structure interaction, I build custom compatibility models. These take longer to develop but capture the physics more accurately. The investment pays off when the standard methods give questionable results. The most valuable skill is recognizing when compatibility matters most. It is not just a theoretical exercise. Wrong compatibility leads to wrong forces, which leads to overstressed members, which leads to cracks, deflections, and sometimes collapse. I check compatibility at every critical section, especially where members connect, where supports are, and where loads change abruptly. This habit has saved me from some costly mistakes.

If you are learning this material, do not just memorize the equations. Understand what they represent physically. Compatibility is about continuity of deformation. Every equation you write is a statement that two parts of a structure move together in a specific way. When you see that connection, the math becomes intuitive. The rest is just careful bookkeeping.


