Getting Flexure Hinges Right
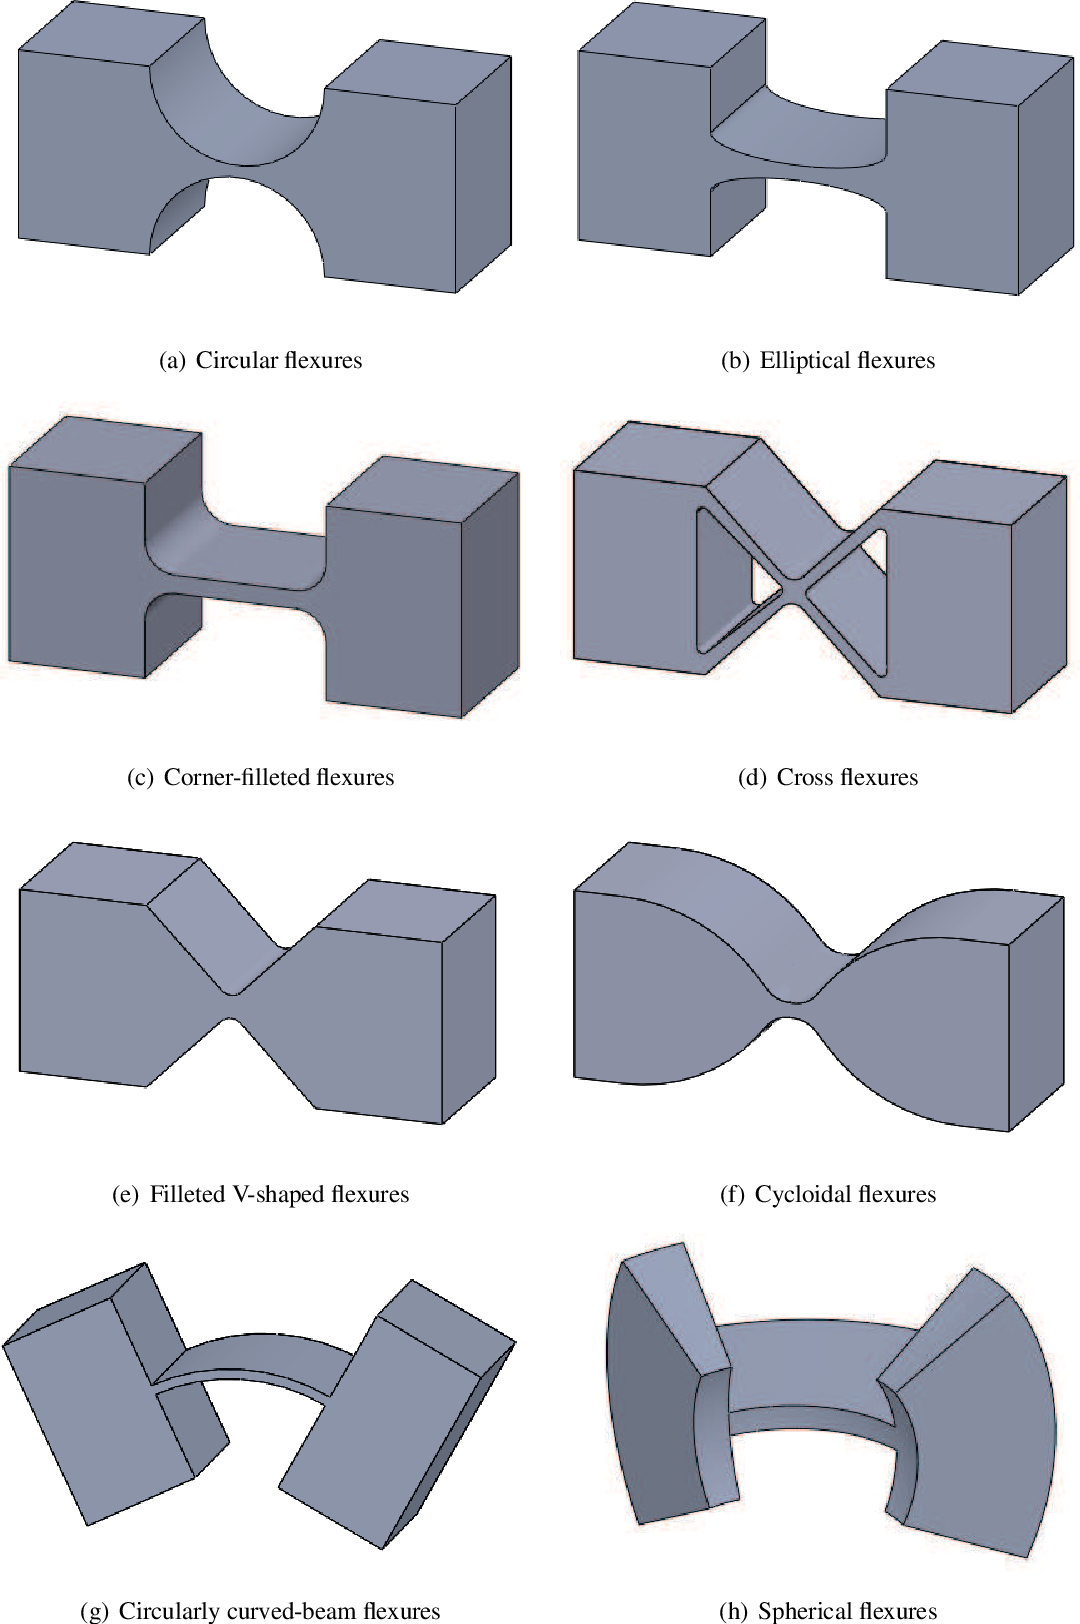
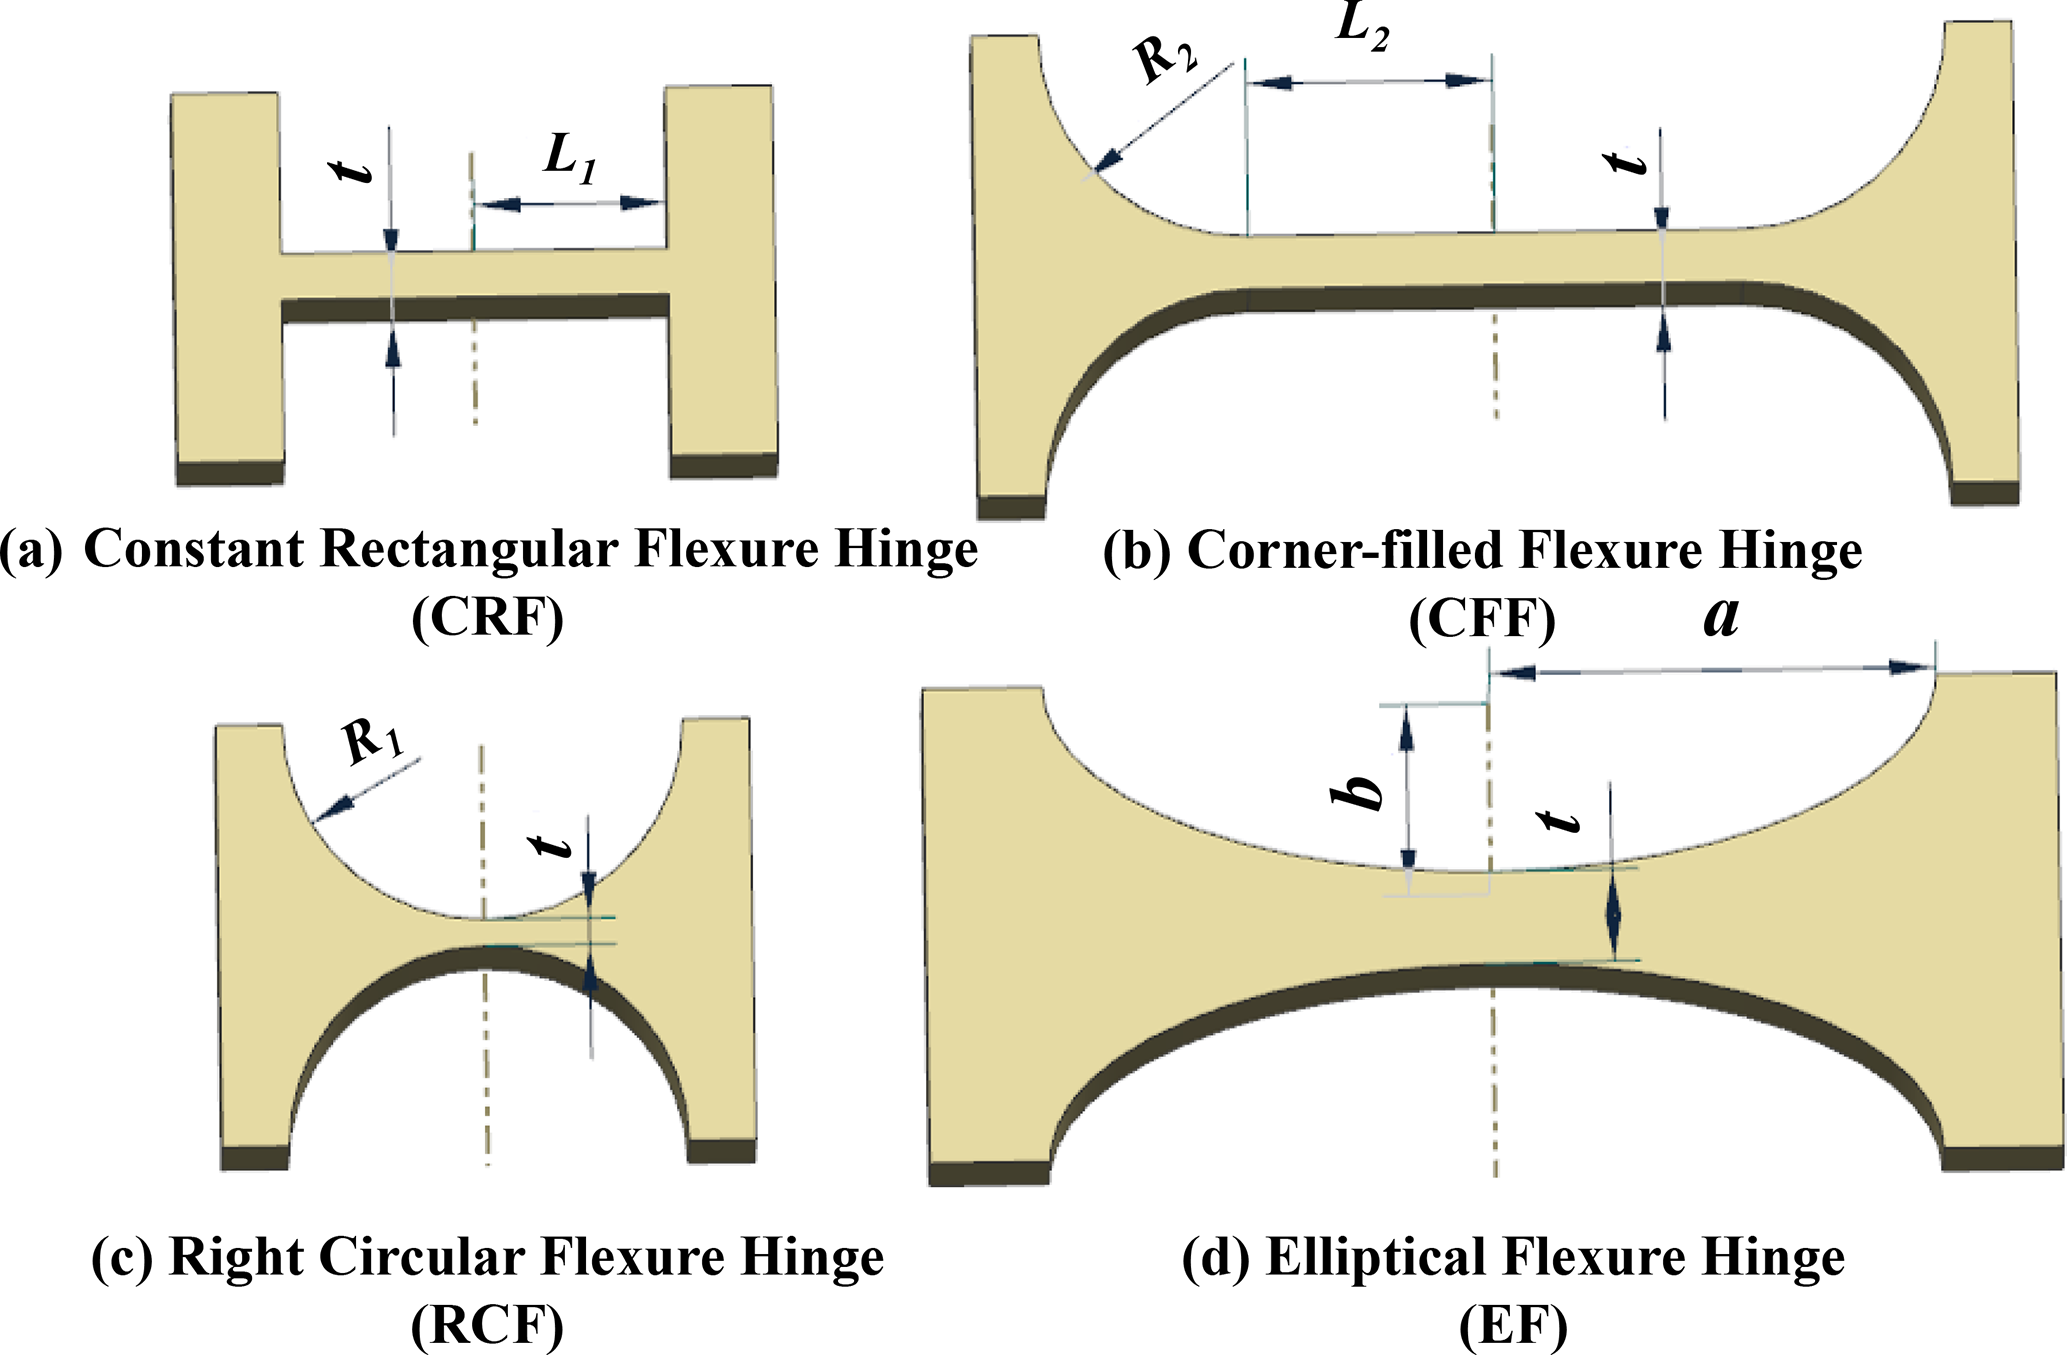
I spend most of my time doing finite element analysis on precision mechanisms, and flexure hinges come up constantly. People either love them or they hate them, usually based on whether they tried to design one without understanding the underlying mechanics first. This guide is for the people who want to actually build compliant mechanisms that work the first time instead of breaking during testing. A flexure hinge is a slender section of material that bends elastically to produce motion where a traditional hinge would use a joint. The whole concept of compliant mechanisms is that flexibility itself becomes the kinematic element. There's no pin, no bearing, no clearance. Just material deformation, which means no friction, no wear, no lubrication, and no backlash. That is the entire value proposition. The most common hinge geometries you will encounter are the notched hinge, the elliptical hinge, the parabolic hinge, and the right-circular hinge. Notched hinges are cheap to machine and easy to model but they concentrate stress badly at the corners of the notch. Elliptical and parabolic hinges spread the strain more evenly and give you better rotational compliance with less stress. Right-circular hinges are the cleanest analytically because you can derive their pseudorigid-body parameters using standard equations, but they remove more material than some other shapes and that matters when stiffness is a concern.
Here is a thing most online calculators do not tell you. The aspect ratio of your hinge width to thickness is not just a geometric detail. When you make a hinge wider, you increase its out-of-plane stiffness faster than its in-plane bending compliance. If you need pure rotational compliance in one plane and your hinge is too wide relative to its thickness, you will get unintended coupling. My rule of thumb is to keep the width under four times the hinge thickness unless you have a specific reason to go wider, and even then verify the coupling in FEA before committing to the design. I worked on a deployment mechanism last year where the primary hinge was a right-circular flexure designed for a 12 degree rotation. The FEA showed a maximum von Mises stress of about 280 MPa in titanium alloy, which looked fine on paper. During thermal cycling from minus ten to plus fifty celsius, the mechanism jammed after about forty cycles. The root cause was not the hinge itself. The adjacent supporting member had a thermal expansion mismatch that introduced an out-of-plane load of roughly two hundred microns. The flexure was not designed to handle parasitic deflection. I solved it by increasing the hinge thickness from point three millimeters to point five millimeters to raise the out-of-plane natural frequency, then added a second flexure in a differential configuration that cancelled the parasitic load. The rotational stiffness went up by about a factor of two point one, but the mechanism still met the required compliance budget. When you are designing these hinges, you need to pick your material before you do anything else. Titanium alloy gives you a good combination of elastic limit and fatigue life. Beryllium copper is excellent if you need high elasticity and can work with lower strength. Stainless steel is straightforward but its elastic range is narrower than most people expect when you push into sub-millimeter deflections. Polymer flexures exist but their viscoelasticity makes repeatability a nightmare unless you are designing for very low frequency, low load applications.
Manufacturing method determines your actual performance more than your analytical model does. Wire EDM gives you the best surface finish for metallic flexures and it does not introduce heat affected zones. If you mill a flexure hinge, the tool marks at the root of the notch become stress concentrators that reduce fatigue life by an order of magnitude compared to an EDM part. I tested this directly on a batch of notched titanium hinges where half were milled and half were EDM cut. The milled parts failed at roughly six thousand cycles under the same loading condition while the EDM parts lasted past one hundred and twenty thousand cycles without measurable degradation. The difference is not theoretical. It is a manufacturing decision. Laser cutting works for thin sheet metal flexures down to about point one millimeters thickness, but the kerf width and heat input make it unsuitable for precision mechanisms where the hinge geometry needs to be within tens of microns of the nominal design. If you are designing for a micro-positioning stage and the hinge is under half a millimeter thick, consider photolithography and electrochemical machining rather than trying to force laser cutting into the process. Modeling flexure hinges falls into three tiers of accuracy. The pseudorigid-body model gives you quick hand calculations that are useful for initial sizing. You replace the flexible segment with rigid links and a rotational spring, then solve the mechanism kinematics. This works well for simple single-degree-of-freedom mechanisms and it gives results within about fifteen percent of full FEA for small rotations. The beam-on-nonlinear-foundation approach is more accurate but requires iterative numerical solution. Full three-dimensional FEA is the most reliable method and it is what you should use for final validation. The pseudorigid model is not wrong. It is just an approximation that breaks down when you have large rotations, multi-axis loading, or when stress concentration effects matter for fatigue life.
Get the Full Details

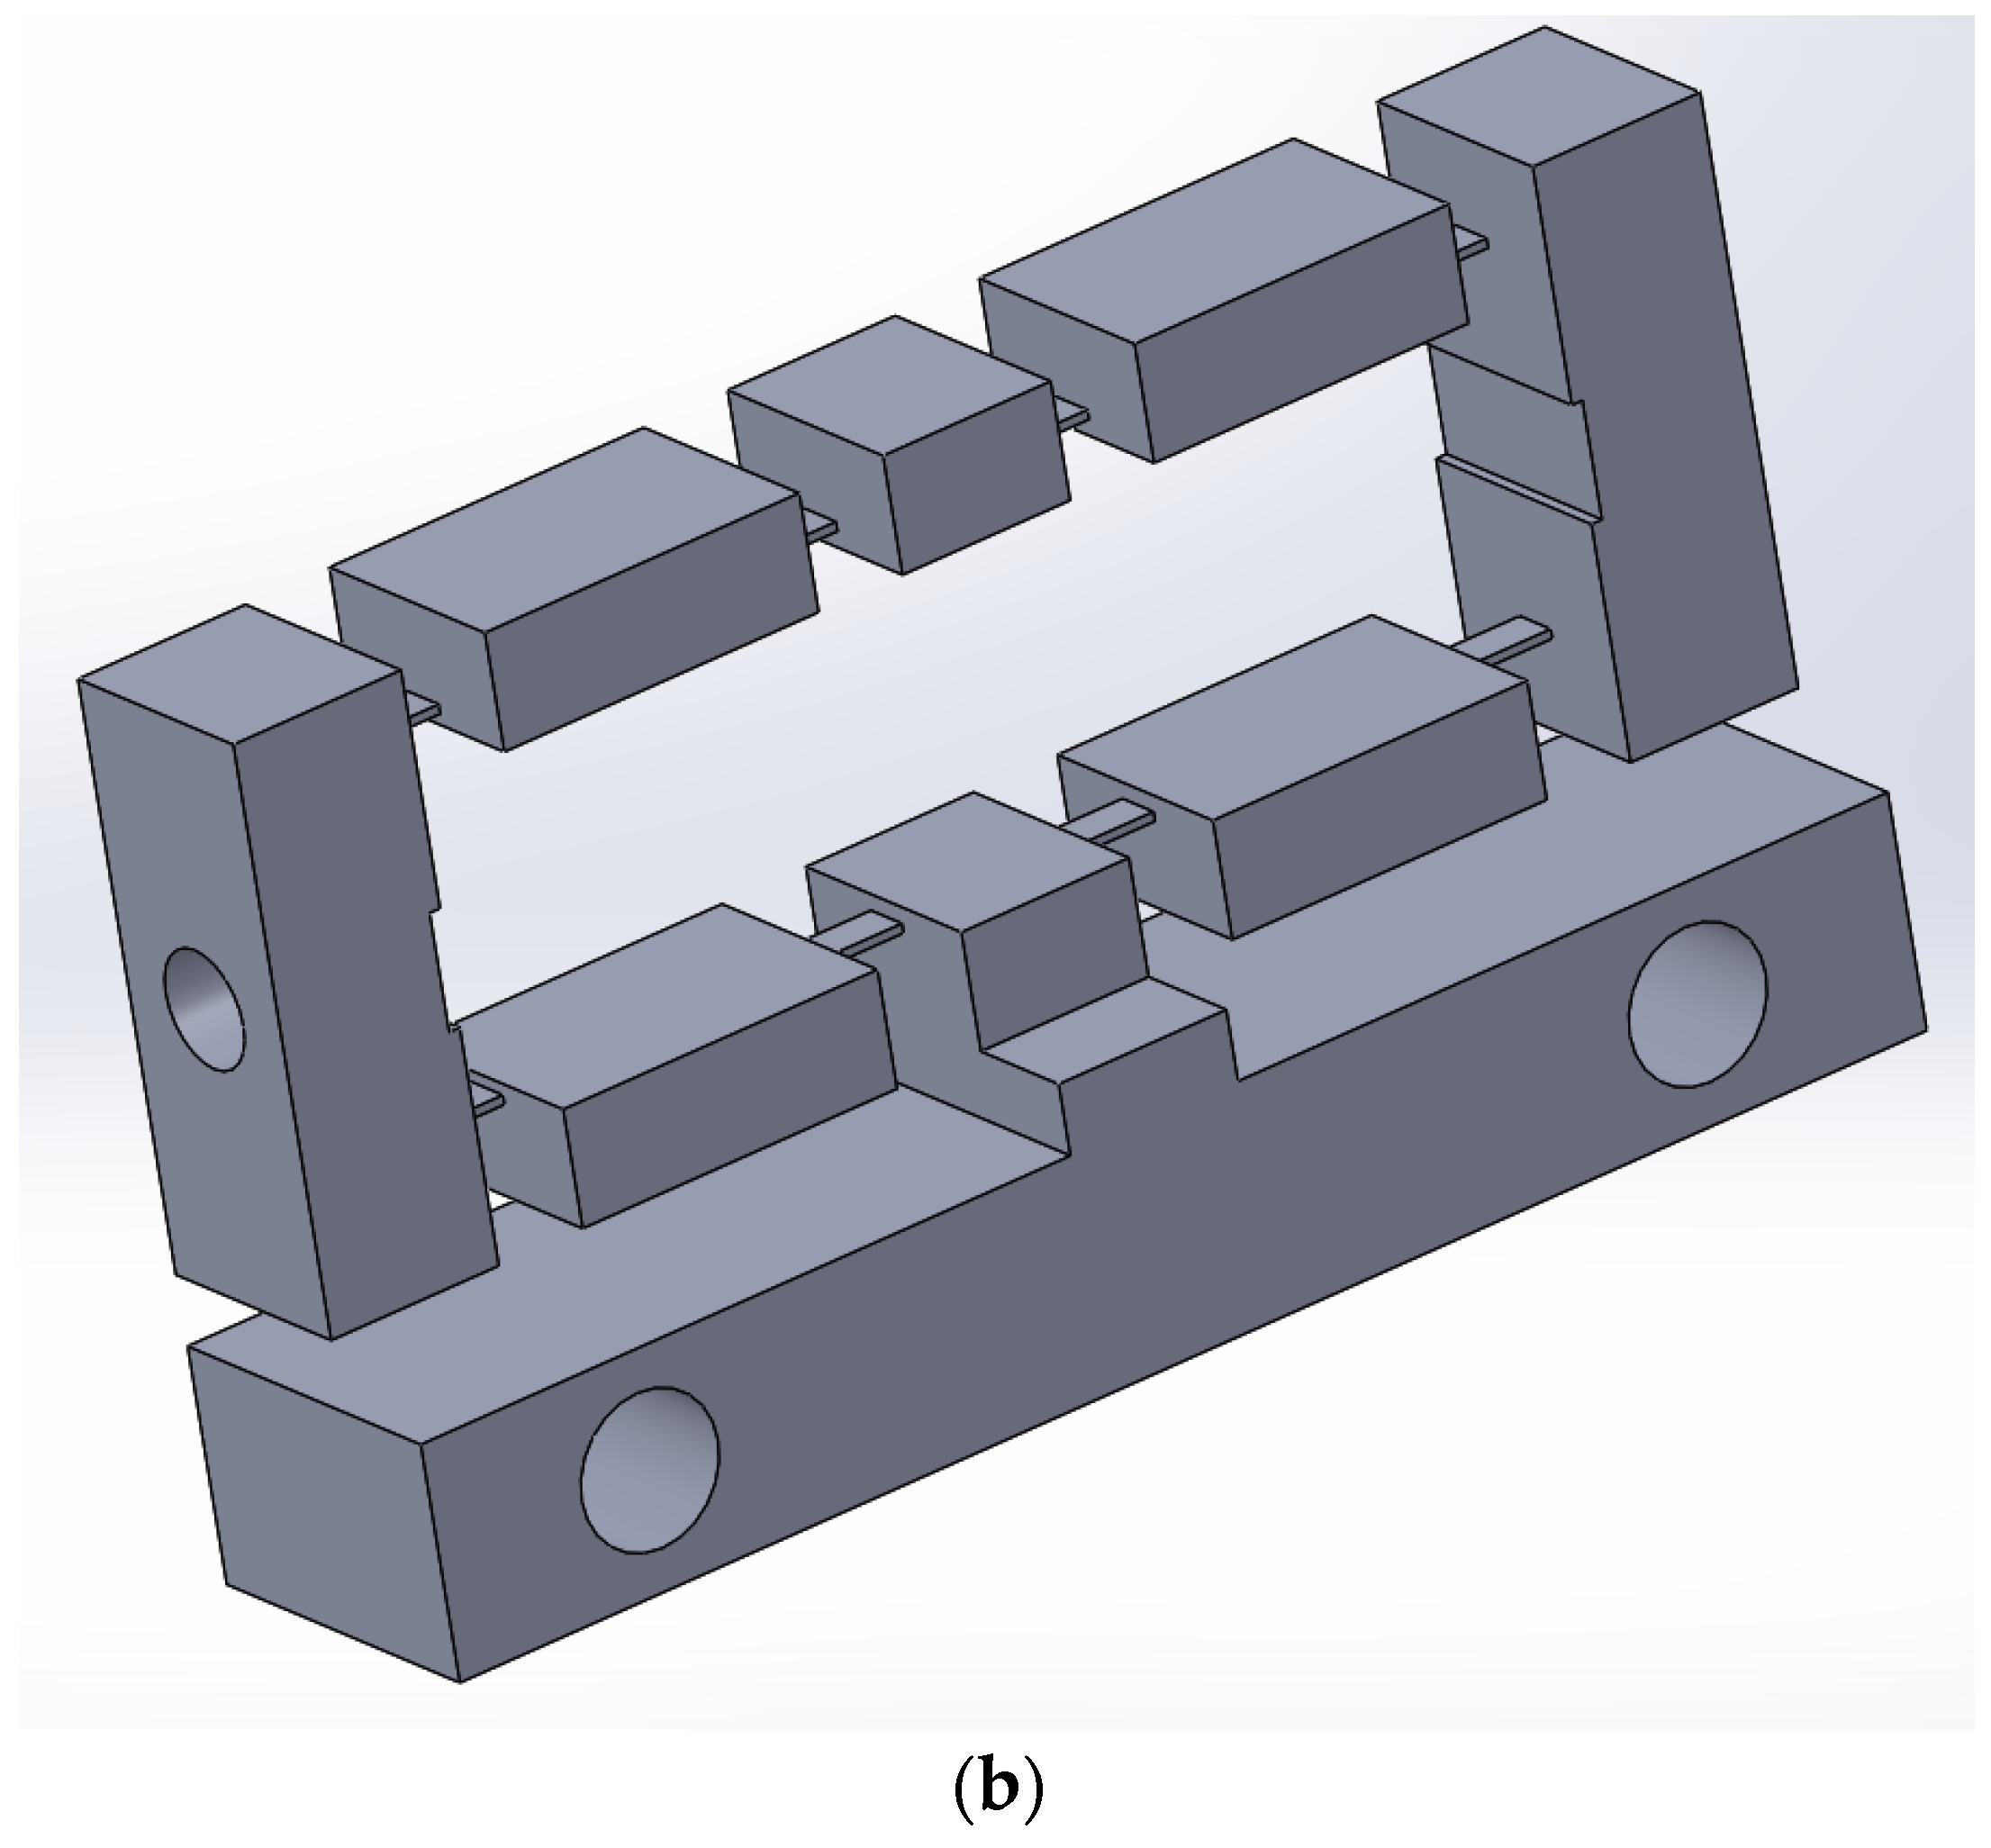
There is a practical shortcut for FEA that saves a lot of meshing time. You do not need to mesh the entire mechanism with fine elements. Concentrate your mesh refinement only in the flexure hinge region and use coarse tetrahedral or hexahedral elements elsewhere. I typically use a local mesh size of about point zero two millimeters in the hinge and point eight millimeters in the bulk material. This cuts mesh generation time from around forty minutes to about six minutes for a typical mechanism without sacrificing accuracy in the regions that matter. The global displacement results stay within two percent of a fully refined mesh. One common mistake I see repeatedly is designing flexure hinges to carry axial load. Flexure hinges are compliant in the directions you intend and stiff in the directions you do not. If your mechanism applies even a small off-axis force to a flexure hinge, the resulting parasitic deflection will rotate the output platform in an unintended way. This is called parasitic motion and it is the leading cause of precision loss in compliant mechanisms. The workaround is to use symmetric hinge pairs. Two identical flexure hinges arranged in parallel cancel out parasitic translation and leave you with nearly pure rotation. This is how you build a compliant bearing that actually behaves like a bearing. Another thing that surprises people is the fatigue behavior. A flexure hinge that operates entirely within the elastic range of the material should theoretically last indefinitely. In practice, surface defects from manufacturing, residual stresses from the process, and stress concentrations at geometric discontinuities mean that fatigue life is finite. For titanium flexure hinges operated at stress levels below two hundred and fifty megapascals with EDM surface finish, you can expect well over one million cycles. Above three hundred megapascals, life drops to somewhere between fifty thousand and two hundred thousand cycles depending on the surface quality. This is why I always run a stress check before declaring a design safe.
If you need a starting point for calculations, the Spring Design flexure hinge calculator is a free web-based tool that handles elliptical, parabolic, and right-circular geometries and gives you compliance matrices, stress estimates, and natural frequencies. I use it for initial sizing. For final design, I run the geometry through a linear static FEA simulation. The combination of quick hand calculations followed by targeted FEA validation is what keeps my design iteration time reasonable. Without it, every design change would require a full simulation cycle and the feedback loop becomes too slow to be useful. The main limitation of flexure hinges is that they cannot provide unlimited rotation. Most metallic flexures are practical up to about fifteen to twenty degrees of rotation before plastic deformation becomes a real risk or before the nonlinear geometric effects make the motion unpredictable. If you need larger angular travel, you need to use longer, thinner hinge segments, which reduces stiffness and makes the mechanism more sensitive to environmental disturbances. There is no free lunch here. Rotation range, stiffness, and load capacity are in tension with each other and your design is just a point in that trade space. For high-load applications where a flexure hinge would need to be impractically large, consider a hybrid approach. Use a flexure for the primary precision motion and a traditional bearing or slide for load support. This is not cheating. It is good engineering. Compliant mechanisms excel at precision, repeatability, and simplicity. They are not a universal replacement for conventional mechanical joints.
If you are new to this and want to start practicing, download any standard FEA software that has a linear static structural module and model a simple cantilever with a notched flexure hinge at the fixed end. Apply a tip load and compare the analytical compliance from the pseudorigid model against the FEA result. The difference will teach you more about the limitations of each method than any textbook explanation. Then modify the hinge geometry and repeat. This is how I learned the difference between what the equations say and what the hardware actually does.