What people get wrong about geometry before they even start
I spent years grading geometry assignments and tutoring students who would memorize five proof formats without understanding why any of them worked. The pattern was always the same: they could produce a two-column proof for triangle congruence, but the moment you asked them to figure out the locus of points equidistant from two skew lines in 3D space, they completely stalled. This isn't because the concepts are inherently hard. It's because most tutorials teach geometry as a collection of disconnected rules instead of a system of reasoning. A proper Comprehensive Geometry Tutorial needs to handle the full arc — starting with axiomatic foundations, moving through classical synthetic methods, then landing on analytic and computational approaches that are actually used in engineering and computer graphics. If you only learn one flavor, you're walking around with a Swiss Army knife that has just a single blade.
Why starting with axioms matters more than you think
Most tutorials skip Euclid's parallel postulate and jump straight to "here are your circle theorems." That's a mistake. The parallel postulate isn't just some historical footnote — it's the fulcrum that separates Euclidean geometry from hyperbolic and elliptic systems. When students understand that the sum of angles in a triangle equals 180 degrees depends on that one assumption, everything else clicks into place differently. I remember a student who was doing well in her high school geometry class until we got to the chapter on constructions with compass and straightedge. She kept trying to trisect an arbitrary angle. Not because she wanted to be difficult, but because she genuinely didn't understand the distinction between what's possible and what's provably impossible with those tools. A solid tutorial should address that frustration head-on by explaining the field extension argument behind why angle trisection is impossible, rather than just stating "it can't be done" and moving on.
The shift from synthetic to analytic geometry
Here's where things get interesting. Synthetic geometry — the pure proof-based approach — develops rigorous spatial reasoning. But in practice, I've found that analytic geometry, which translates geometric problems into algebra using coordinates, is vastly more efficient for anything involving calculation. The coordinate approach to proving that the altitudes of a triangle are concurrent takes about forty lines of algebra. The synthetic proof takes roughly the same amount but requires introducing three auxiliary points and a pair of cyclic quadrilaterals that most students won't see coming. The transition between these two paradigms is where most Comprehensive Geometry Tutorial material falls apart. They treat them as separate chapters rather than as complementary toolkits. In the real world, the smart move is to translate a geometry problem into coordinates, compute the answer algebraically, then ideally reconstruct a synthetic proof if one is needed for rigor. I once spent an afternoon verifying a property of the nine-point circle by computing everything in barycentric coordinates — it came out clean in about ten minutes of algebra, whereas the synthetic derivation required three pages of angle chasing and an auxiliary construction that wasn't obvious at all.
Get the Full Details
Common pitfalls in polygon geometry that nobody warns you about
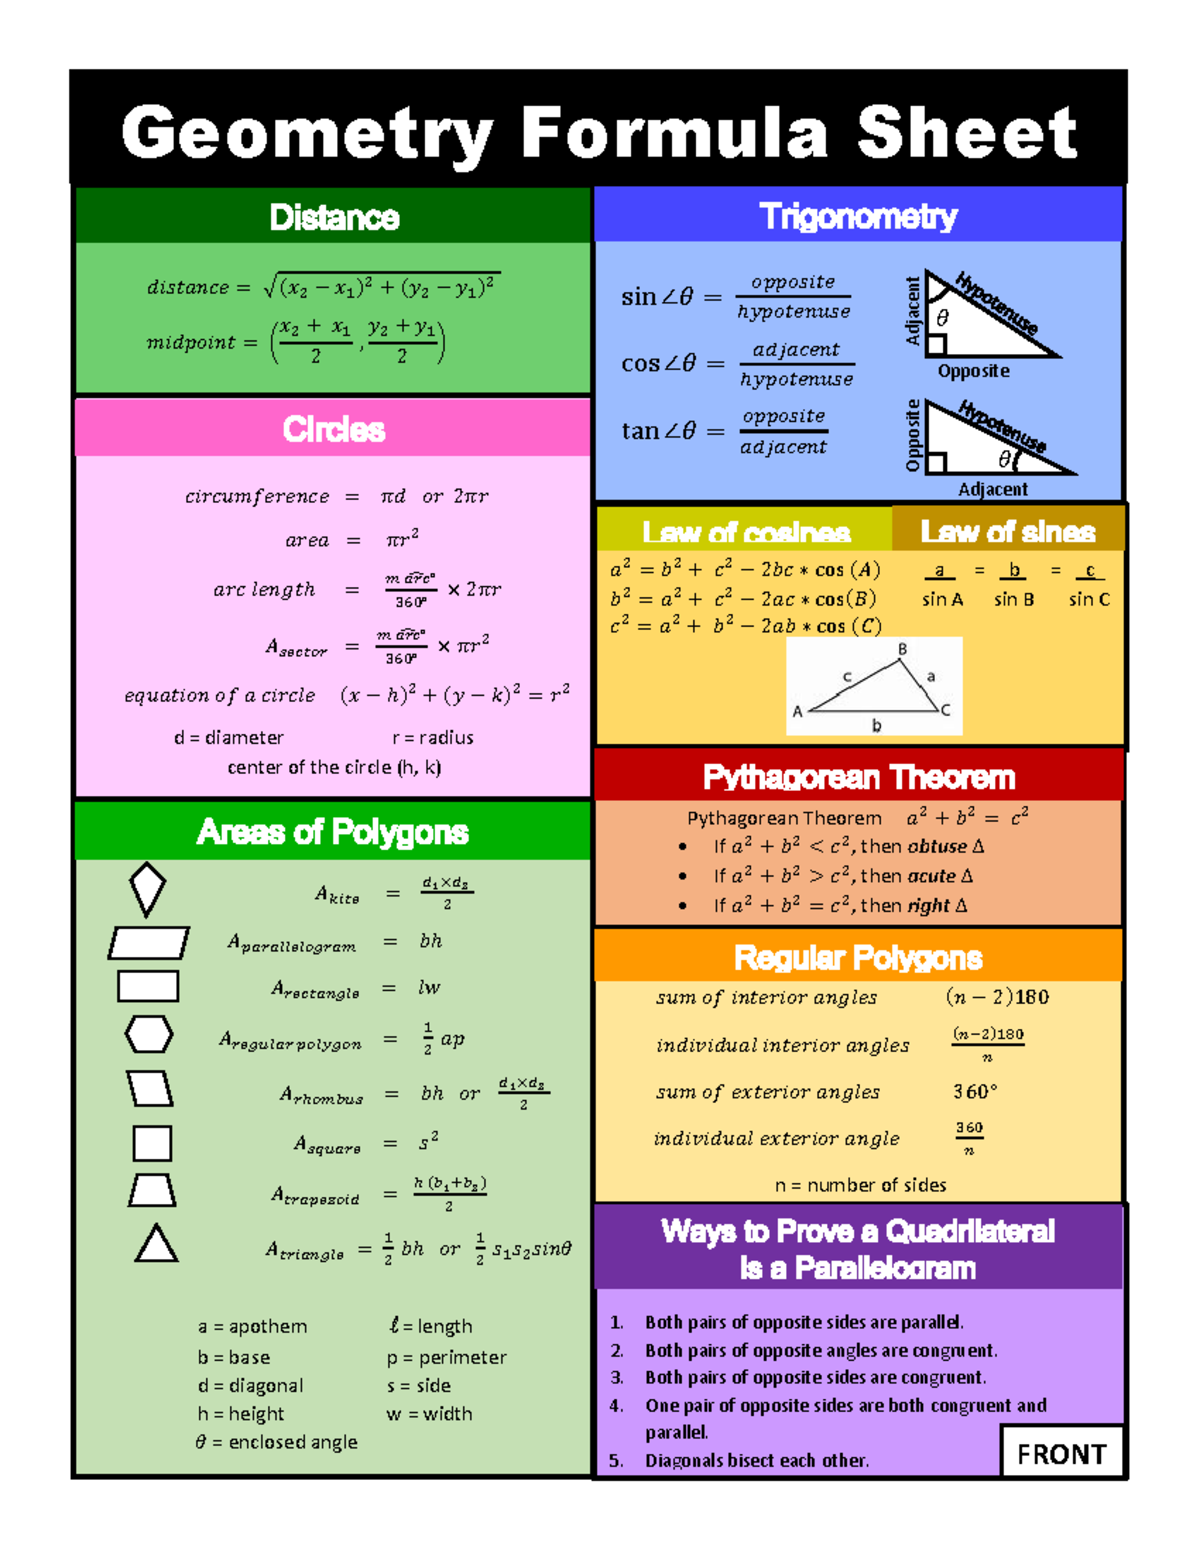
One thing I see constantly is students applying formulas for regular polygons to irregular ones. The area formula A = (n × s²) / (4 × tan(/n)) only works when all sides and angles are equal. I've lost count of the number of times I've seen this plug into problems involving arbitrary convex polygons. For those, you need the shoelace formula, which works for any polygon as long as the vertices are listed in order around the perimeter. Another subtle issue: orientation. When using the shoelace formula, listing vertices clockwise gives you the negative of the area compared to counterclockwise listing. This isn't just a sign error — it matters for cross products in 3D geometry and for determining whether a point lies inside a polygon using the ray casting method. I once debugged a collision detection system for nearly two days before realizing the polygon vertices in one mesh were wound clockwise while the rest were counterclockwise, causing the point-in-polygon test to flip its answer on half the objects.
3D geometry and the computational side
Moving into three dimensions introduces a whole new class of problems. Plane intersections, dihedral angles, volumes of polyhedra — these all require comfort with vector operations. The dot product gives you angles between vectors. The cross product gives you perpendicular directions and areas of parallelograms. The scalar triple product [a b c] tells you the signed volume of the parallelepiped formed by three vectors, and it's zero exactly when the vectors are coplanar. For a Comprehensive Geometry Tutorial, this section should also cover computational geometry basics: convex hull algorithms, Voronoi diagrams, Delaunay triangulations. These aren't just academic curiosities. Convex hulls are used in collision detection. Delaunay triangulations underpin terrain modeling and finite element mesh generation. I worked on a project where we needed to compute the convex hull of several thousand points in three dimensions, and using a naive algorithm ran overnight. Switching to a quickhull implementation cut it down to under a minute.
Circle geometry and the power of inversion
Inversion is one of those topics that most introductory tutorials either skip entirely or mention in a single paragraph as a "fun fact." That's a serious oversight. Inversion in a circle — mapping every point P to a point P' along the same ray from the center O such that OP × OP' = r² — transforms circles and lines into circles and lines. It turns certain impossible-looking configuration problems into trivial ones. Consider the classic problem of constructing a circle tangent to three given circles (the Problem of Apollonius). A direct synthetic approach is notoriously messy with up to ten distinct cases depending on whether the circles are internally or externally tangent. Apply an inversion centered at a point of tangency between two of the circles, and two of the circles become parallel lines. The problem collapses to finding a circle tangent to two parallel lines and one circle, which is straightforward. Inverting back gives the answer. I encountered a version of this in a competition setting where the configuration involved four mutually tangent circles. Inversion made the entire solution fit on one page. Without it, the same proof would have filled a notebook.

Practical advice for working through this material
If you're building your own study plan around a Comprehensive Geometry Tutorial, here's what actually works based on what I've seen over many years. Start with Euclidean foundations — points, lines, angles, triangles. Don't rush this. Get comfortable with proof writing. Then move to circles and their properties. The inscribed angle theorem and power of a point are workhorses that appear everywhere. Next, tackle coordinate geometry. Set up a coordinate system and redo your synthetic proofs computationally. This double exposure cements understanding. After that, introduce vectors and use them to handle 3D problems. By this point, you should be able to switch fluently between pictures, proofs, and calculations — which is exactly what separates someone who knows geometry from someone who understands it. Save transformations — reflections, rotations, translations, and especially inversion — for later. They're powerful precisely because they reframe problems, but that reframing ability takes practice. Don't try to learn them in isolation. Apply them to problems you've already solved synthetically and see what changes.
Where geometry breaks down and what to do instead
I should be honest about the limits. Synthetic Euclidean geometry, even extended with inversion and projective methods, doesn't scale well to high-dimensional spaces or curved manifolds. Once you move past three dimensions or leave flat space, you need differential geometry and linear algebra. A Comprehensive Geometry Tutorial can give you the intuition and the foundation, but it won't prepare you for Riemannian curvature or symplectic forms. That requires a different mathematical framework entirely. Another limitation: computational geometry algorithms assume exact arithmetic in their theoretical descriptions. In floating-point implementations, you'll encounter degenerate cases — collinear points that should form a triangle, intersection points that land exactly on edges, tolerance issues that make point-in-polygon tests inconsistent. These aren't bugs in the math. They're consequences of representing continuous objects with discrete numbers. The workaround is to use robust predicates, like Shewchuk's adaptive precision arithmetic for geometric computations, or to work in a symbolic computation system when exactness matters. For most people studying geometry seriously, investing time in a well-structured Comprehensive Geometry Tutorial that covers synthetic reasoning, analytic methods, and an introduction to computational techniques will give you more practical value than any single specialized resource. The key is not treating any one approach as sufficient. Geometry is too rich for that.