Working With Rotational Dynamics In Practice
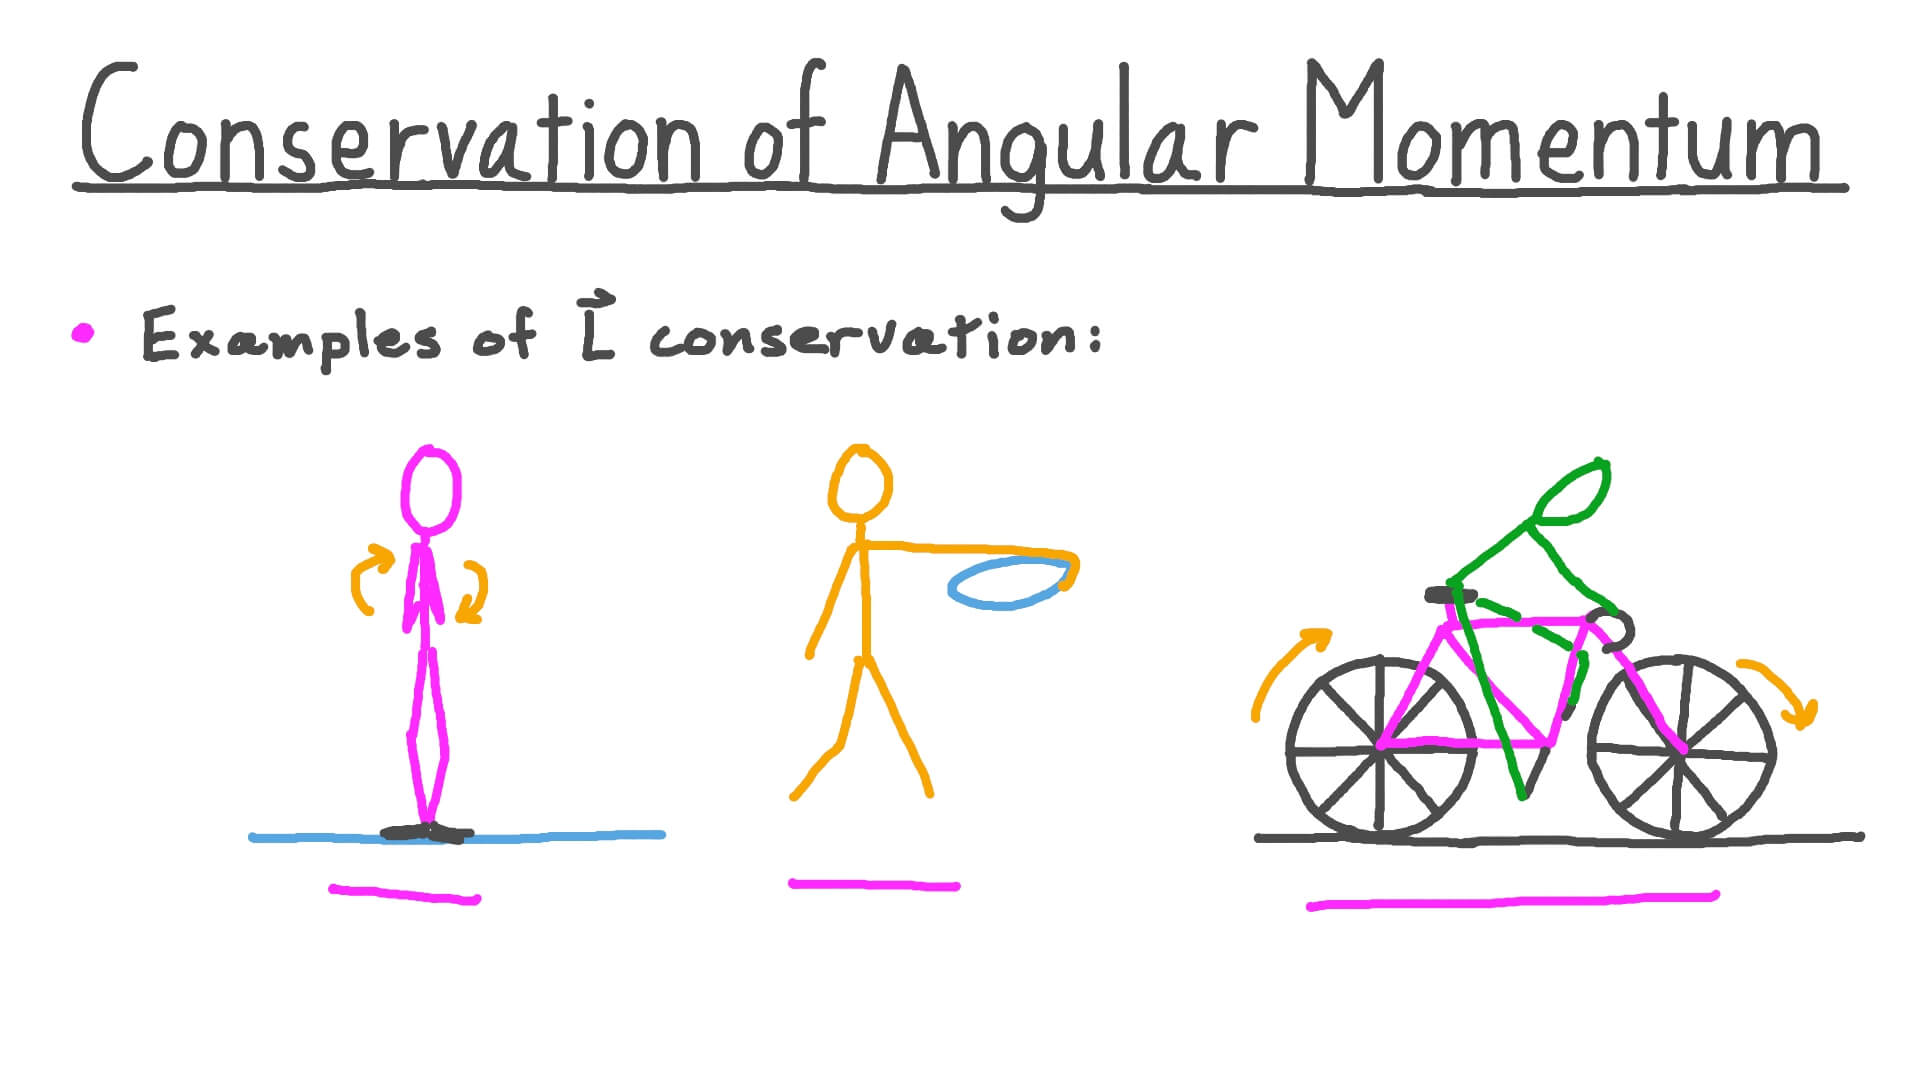
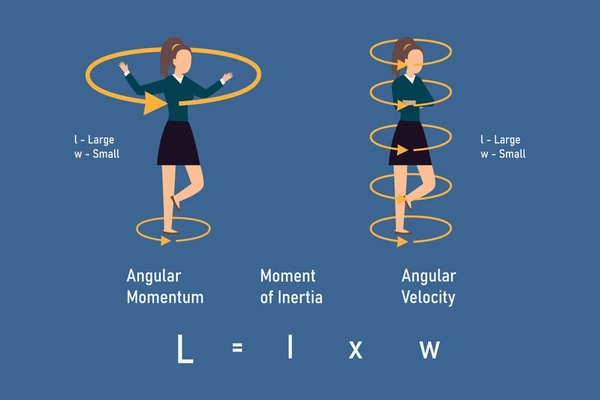
The first thing most people get wrong when approaching Conservation Of Angular Momentum is that they treat every rotating system as if it's perfectly isolated. It rarely is. In my experience setting up gyroscopic stabilization rigs and analyzing flywheel energy systems, the first calculation you should run is not about conserving anything. It's a check on external torques. If your bearings are misaligned by even a fraction of a degree, or if there's any asymmetry in the mass distribution of your rotor, you'll be chasing a conservation law that's constantly being violated by friction and imbalance. That will waste hours before you realize what's happening. Angular momentum is defined as L = I × , where I is the moment of inertia and is the angular velocity vector. The conservation principle states that in the absence of external torques, L remains constant. This sounds straightforward until you actually try to apply it to a system where I is changing over time. A figure skater pulling in their arms is the textbook example, sure, but in real engineering work you're usually dealing with something far messier. The moment of inertia can shift due to thermal expansion, component wear, fluid sloshing inside a tank, or moving parts within your mechanism. The vector nature of angular momentum is what trips people up most. It's not just a scalar magnitude you can play with carelessly. Direction matters. If you're working with a system that has multiple rotating components at different angles, you need to resolve everything into a common coordinate frame before applying conservation. I've seen simulation results go completely wrong because someone added angular momentum magnitudes like they were regular numbers. The cross-coupling terms alone can dominate your results.
Method For Solving Conservation Problems
Start by drawing a complete free-body diagram of your rotating system. Identify every torque acting on it, no matter how small. Most beginners skip this step because they want to get to the algebra, but it's the part that determines whether your answer will match reality. Once you've mapped the torques, check whether the net external torque is truly zero along the axis you're interested in. If it's not zero, you don't have conservation along that axis. You can still use Newton's second law for rotation: = dL/dt. The conservation shortcut only applies when _external equals zero. Next, write out the initial angular momentum. Calculate the moment of inertia for every component about its rotation axis. Don't combine them blindly. Keep them separate so you can track how each one changes individually. Then write the final angular momentum in the same format. Set them equal only after confirming the no-external-torque condition, and solve for whatever unknown you're looking for. For systems with variable geometry, parameterize the moment of inertia as a function of the changing variable. I usually set up I as a function of position x, then use the conservation equation to find how changes with x. This gives you a relationship you can differentiate if you need angular acceleration or forces at a specific configuration.
Where The Standard Approach Breaks Down
Here's something I learned the hard way. A few years back I was designing a reaction wheel assembly for a small satellite mockup. The theoretical conservation calculations looked perfect on paper. The wheel spun up, the body counter-rotated exactly as predicted, and everything matched. Then I tested it physically and the attitude change was off by about eighteen percent. Turns out the mounting structure had enough flexibility that a portion of the input torque was going into elastic deformation rather than pure rotation. The angular momentum was conserved, but my model treated the structure as rigid. By the time I caught it, I'd already spent three days debugging code before realizing the problem was mechanical, not computational. I added strain gauges to the mounting points and recalibrated the model with measured stiffness values, which brought the prediction error down to under two percent. Another common failure point is friction modeling. Bearing friction is rarely constant. It depends on load, speed, temperature, and lubrication state. If you assume zero friction when it's actually present, your conservation equation will give you answers that slowly drift from reality over time. This is especially noticeable in systems designed to run for extended periods, like flywheel energy storage or momentum wheels on spacecraft. The drift might seem small in individual calculations but compounds significantly over multiple cycles.
Get the Full Details

Conservation Of Angular Momentum In Complex Systems
When you move past single-axis rotors into systems with precession and nutation, the simple scalar approach stops working entirely. A spinning top, a gyroscope, or any rotating body with an offset center of mass will experience torque-induced precession that has nothing to do with what conservation alone predicts. The key insight here is that conservation still holds, but you have to account for the changing direction of the angular momentum vector. The magnitude might stay constant while the orientation shifts, and that shift is what creates the precessional motion. For multi-body rotational systems, I recommend using quaternions or rotation matrices rather than Euler angles. Euler angles introduce singularities at certain orientations that can corrupt your calculations mid-simulation. I learned this the hard way during a project involving a three-axis stabilized platform where the simulation would crash unpredictably whenever the intermediate angle approached ninety degrees. Switching to quaternions eliminated those singularities and reduced simulation artifacts considerably. There's also the issue of relativistic effects at very high rotational speeds, though this only becomes relevant in specialized applications like particle accelerators or precision timing systems. For nearly all practical engineering work, classical mechanics is sufficient. But if you're working with something rotating near material failure limits, the stresses themselves can alter the moment of inertia through deformation, creating a feedback loop that a simple conservation calculation won't capture.
Practical Tips That Actually Matter
When measuring angular momentum in a lab or field setup, use a torque sensor rather than trying to infer it from motion data alone. Force inference from acceleration readings accumulates error quickly, especially at low rotational speeds where the signal-to-noise ratio is poor. A properly calibrated torque transducer on the shaft will give you direct readings that are far more reliable. If you're building a system that relies on angular momentum conservation for stabilization, always include a desaturation mechanism. Reaction wheels and control moment gyros accumulate momentum over time when external disturbances are present. Without a way to dump that accumulated momentum, your system will eventually saturate and lose control authority. Magnetic torquers, thrusters, or passive dissipation elements are the usual options depending on your application. For quick estimations during the design phase, I usually start with a simplified 2D analysis to get ballpark numbers, then run a full 3D simulation to catch the coupling effects. The 2D analysis takes about ten minutes and tells you whether the concept is in the right order of magnitude. The 3D simulation might take a few hours depending on complexity, but it catches the things the simplified model misses. Skipping straight to 3D without the 2D check means you won't notice when something is fundamentally wrong until late in the process.
The biggest mistake I see repeatedly is applying conservation of angular momentum to open systems where mass is entering or leaving. A merry-go-round being loaded with people, a turbine with fluid flow, or a rocket spinning as it burns fuel are all cases where the standard conservation equation needs modification. The general form accounts for this with the addition of angular momentum flux terms, but most introductory treatments skip this entirely. If your system isn't closed, you need the extended formulation or you're not actually doing conservation.