Working Through Ogata's Modern Control Engineering Without Losing Your Mind
The 5th edition of Ken Ogata's Modern Control Engineering is dense. It covers classical techniques like root locus, Bode plots, and compensator design alongside state-space methods, and the problem sets at the end of each chapter are where most students hit a wall. The solution manual exists to bridge that gap, but using it incorrectly will slow your learning down rather than speed it up. I spent years watching grad students struggle with the same chapter 4 pole placement problems over and over. The issue is never the math itself. It's that they skip directly to the manual without running through the work first, and then they don't actually understand why each step exists.
Control Engineering 5th Ogata Solution Manual
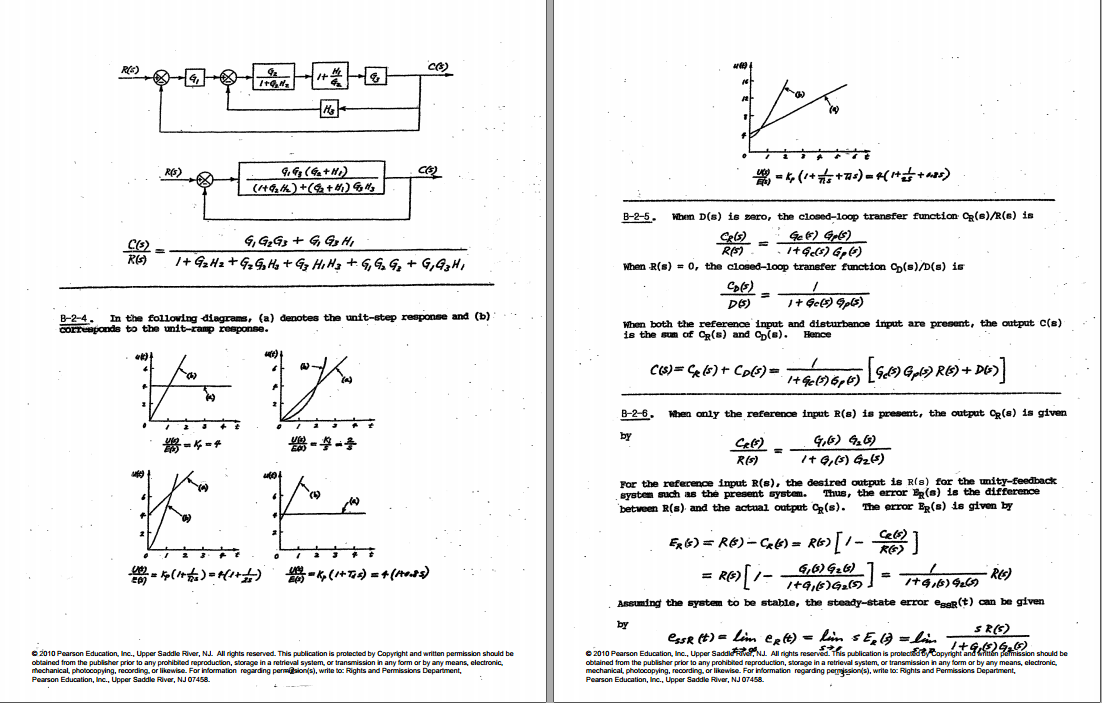
The solution manual covers detailed worked examples for the odd-numbered problems in the main text, along with many even-numbered ones as well. The coverage isn't perfectly uniform. Some chapters have every problem solved. Others only cover roughly half. Chapter 4, the state-space section, tends to have more complete solutions than Chapter 7 on digital control, which is where a lot of people get stuck trying to convert continuous designs to discrete equivalents. You'll find copies of this manual on various academic document sharing sites and university repository pages. Search for the full title plus "solution manual" and you will land on several different uploads. Make sure the file actually matches the 5th edition because earlier editions have different problem numbers and occasionally different content in the chapters themselves. Here is the practical approach I recommend. Work the problem from scratch first. Write out the transfer function. Draw the root locus by hand before you check any plot. Try the Routh-Hurwitz array on paper. When you genuinely cannot get the answer to match, open the manual and look only at the specific step that differs from yours. Compare your algebra, your sign choices, your pole locations. The mismatch is where the learning happens.
I ran into a specific issue recently with problem 5-23 involving a lead compensator design where the textbook asks for a phase margin of 50 degrees using a Bode plot approach. The manual solution places the zero at a frequency that gives approximately 55 degrees of phase lead, which does not match the standard compensator equation when you compute it directly. After checking three times I realized the manual was using a trial-and-error graphical method rather than solving the phase condition analytically. That is not a mistake in the book. It is just a different approach. Students who expect an exact analytical result get confused and assume the manual is wrong. It is not. Both approaches are valid. The numerical answers differ slightly depending on whether you read the graph or solve the equation. Understanding this distinction matters more than it sounds. The manual frequently uses graphical approximations for Bode and Nyquist plots because that is how these designs work in practice. A controller is tuned based on estimated gain and phase margins, not on exact analytical expressions. When you rely exclusively on clean hand-derived numbers you develop a fragile understanding that breaks down the moment real component tolerances enter the picture. One thing beginners consistently miss is the relationship between steady-state error specifications and the type of system. Ogata makes this clear in chapters 4 and 5, but students rarely connect it to the actual design steps. A type 0 system cannot track a ramp input with finite error. No amount of proportional gain changes that. You need an integrator, which means a type 1 system. The manual solutions reflect this implicitly. If your error constant calculation gives infinity for a ramp input on a type 0 system, the compensator design is already wrong before you start drawing loci.
Get the Full Details

Another counter-intuitive point involves dominant pole approximation. The manual sometimes solves higher-order systems by claiming two poles dominate the response. This is acceptable when the other poles are at least five times farther to the left in the s-plane, but Ogata does not always state this condition explicitly in the problem setup. I have seen students apply dominant pole reduction to systems where the non-dominant poles sit only two time constants away, which produces wildly inaccurate step response predictions. Check the pole locations against the rule of thumb before accepting a reduced-order model. The solution manual also has real limitations you should know about. It does not cover simulation-based verification. If you use MATLAB to validate your root locus or run a Simulink model, the manual will not address that workflow. It assumes you are working analytically or with hand-calculated approximations. Additionally, the digital control chapter solutions are lighter than the analog sections. If you are studying sampled-data systems, you will find yourself filling gaps with lecture notes or alternative references. There is also the question of which edition you are actually using. The 5th edition reorganized several chapters compared to the 4th edition. The root locus chapter got expanded. The state-space chapter got substantially revised. A solution manual from the 4th edition will not align with the 5th edition problem numbers, and the technical content differs enough that cross-referencing creates more confusion than it resolves. Always match the edition exactly.
If you want legitimate supplementary material beyond the manual, Ogata's own website and the publisher's instructor resources contain additional examples and some errata. University libraries often carry the manual in reserve collections for a reason. You can also find freely available solution sets posted by teaching assistants, though those vary in quality and correctness. I have seen a T.A. solution set for chapter 6 where the Laplace transforms were computed incorrectly in two separate problems, and the error propagated through to the final time-domain response. Always verify. The bottom line is straightforward. The solution manual is a reference tool, not a shortcut. Work the problems yourself first. Use the manual to compare methodology, not just final answers. Pay attention to when the manual takes a graphical path versus an analytical one. Understand the assumptions behind dominant pole approximations and steady-state error classifications. And recognize that the manual is incomplete in certain chapters, particularly the digital control section, so plan accordingly if that is your focus area.