What People Miss About Actually Designing A Control System
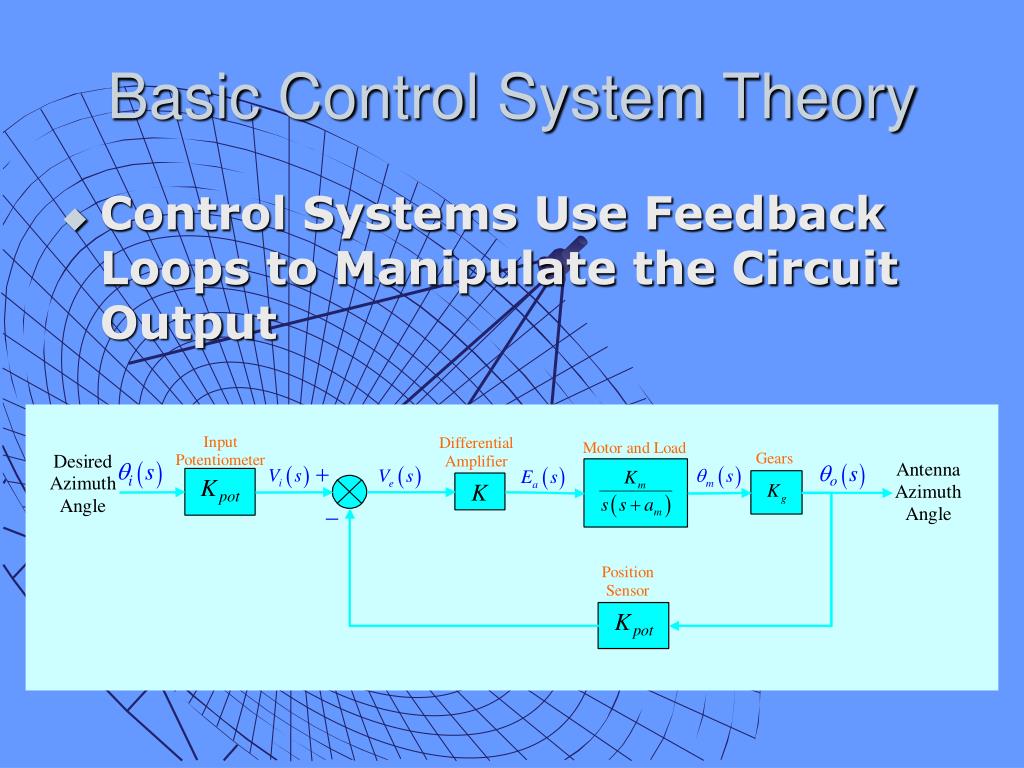
The textbook version of Control System Theory And Design starts with a block diagram, writes down a transfer function, and assigns you to place poles. That is not how this is done in practice. You get a physical system with nonlinearities, unmodeled dynamics, sensor noise that changes with temperature, and a requirement that the product ship next Tuesday. The theory tells you what stability looks like on paper. It does not tell you what to do when your Nyquist plot has a weird loop near the critical point because there is an unmodeled resonant mode at 847 Hz. Here is the way I approach this, the way most working engineers do, stripped of academic polish.
Getting Started With PID Tuning And Why It Is Never That Simple
Start by measuring the plant. Not simulating it. Physically measuring it with a network analyzer or at minimum a sine sweep run through your DAQ system. I have seen too many control loops that work perfectly in simulation and oscillate to death on the actual hardware because the model skipped a small delay in the power stage. A 2 millisecond PWM delay at a crossover frequency of 50 Hz eats about 36 degrees of phase margin. That is enough to turn a stable design into an unstable one without warning. The standard approach to the initial tuning is the Ziegler-Nichols method. It is famously aggressive. It will give you a closed loop with about 25% overshoot and likely borderline stability. I still use it as a starting point sometimes because it gives you a ballpark before you refine by hand. The process goes like this. You increase the proportional gain until the system sustains oscillations. Record that critical gain as Kc and measure the oscillation period Pc. Then apply the classic tuning rules for a PID controller. The proportional term becomes 0.6 times Kc. The integral time is Pc divided by 2. The derivative time is Pc divided by 8. These numbers will make the system respond fast and likely a bit too oscillatory. You then back off the gain by about 30% and reduce the derivative action until you are satisfied with the transient response.
This usually takes about 20 minutes on a bench with a decent scope, compared to the 2 hours I used to spend manually adjusting terms before I had a repeatable process. The catch is that Ziegler-Nichols assumes a relatively simple, well-behaved plant. If your system has significant dead time or non-minimum phase behavior, the resulting controller will make things worse, not better. In those cases you skip the heuristic and go straight to loop shaping through Bode plot analysis.
Get the Full Details
The Core Approach: Loop Shaping And Frequency Domain Design
Frequency domain design is the backbone of modern Control System Theory And Design. You shape the open loop transfer function so that the closed loop behaves the way you need it to. The three main goals are tracking, disturbance rejection, and robustness. You trade them against each other. You cannot maximize all three simultaneously. Start by drawing the Bode plot of your uncompensated plant. Identify the crossover frequency region where the magnitude crosses 0 dB. This is where your phase margin matters most. If the phase margin is too low here, the closed loop will be underdamped. If the crossover is too high, you are asking too much of your actuators and amplifying sensor noise. A typical industrial system targets a phase margin between 45 and 60 degrees at crossover, with a gain margin above 6 dB. Adding a lead compensator increases phase margin around a specific frequency. The transfer function has the form of a zero and a pole placed so that the maximum phase boost occurs at your desired crossover frequency. The amount of phase boost you can get from a single lead network is limited. Practically you get about 50 to 60 degrees of maximum phase advance. If you need more, you cascade two lead stages with the peak phase frequencies separated. Each stage adds magnitude gain as well, which shifts your crossover frequency higher. You usually need to add attenuation afterward to bring the crossover back to where you want it.
A lag compensator does the opposite. It increases low frequency gain to improve steady state error and disturbance rejection without significantly affecting the crossover region. The zero and pole are both placed well below crossover, typically at a decade or more below the desired gain crossover frequency. The ratio between the pole and zero locations determines how much low frequency gain you add. A common choice is a ten to one ratio, which gives you about 20 dB of low frequency gain boost. When you combine lead and lag networks into a single compensator, you get what is called a lag-lead compensator. This is the workhorse of analog and digital control implementation. The design procedure is iterative. You shape the Bode plot section by section, checking the margins after each addition. A complete loop shaping cycle for a moderately complex plant, from initial measurement to a tuned compensator ready for implementation, usually takes between 3 and 8 hours depending on how well the plant behaves and how many iterations the hardware testing requires.
State Space Design And Modern Techniques
For multivariable systems or when you need optimal performance, pole placement and LQR methods come into play. You write the system in state space form with matrices A, B, C, and D. The pole placement approach calculates a feedback gain matrix K such that the eigenvalues of the closed loop system matrix A minus B times K are at your desired locations. The Ackermann formula gives you a direct computation for single input systems. LQR takes a different angle. Instead of specifying pole locations directly, you define a cost function that penalizes state deviation and control effort. The matrices Q and R weight the relative importance of these terms. Solving the associated Riccati equation gives you the optimal feedback gain. The resulting controller minimizes the cost function by construction. You get good stability margins as a bonus property, which is one reason engineers prefer LQR over pure pole placement in practice. There is a practical limitation people do not emphasize enough. State space design assumes you have access to all state variables. In reality you rarely do. You need an observer or estimator to reconstruct the unmeasured states. A Luenberger observer estimates the state vector from the output measurements and the known input. The observer dynamics are placed separately from the controller poles. A common rule of thumb is to place observer poles about five to ten times faster than the controller poles. If you place them too close, estimation error dominates the transient response. If you place them too far apart, you amplify sensor noise to unacceptable levels.

A Real Problem I Dealt With And The Workaround
Several years ago I was designing a digital controller for a motor position system that used an optical encoder with a 16 bit resolution and a sampling rate of 10 kHz. The simulated response looked perfect. Phase margin was 58 degrees, rise time was 12 milliseconds, settling time was under 30 milliseconds. I loaded the code onto the DSP and ran the first test. The system oscillated at about 400 Hz with a growing amplitude until the current limit tripped and the drive shut down. The problem was aliasing in the encoder feedback path. The encoder had a small amount of periodic error at approximately 4 kHz due to a manufacturing defect in the scale. At a 10 kHz sampling rate, this error aliased down to 1.6 kHz, which was close to a mechanical resonance of the driven load at about 1.5 kHz. The controller was amplifying this aliased noise because the digital filter in the code only addressed frequencies above 2 kHz. The resonance was completely untouched. The fix was three parts. First I added an analog anti-aliasing low pass filter with a cutoff at 3 kHz before the encoder interface. This prevented the 4 kHz error from folding into the bandwidth of interest during sampling. Second I added a notch filter at 1.5 kHz in the digital controller code, implemented as a biquad section with a Q of about 30. Third I reduced the controller bandwidth by 20% to give more margin around the resonance. The redesign took about four hours total, including the hardware change and the code update. The final system had a phase margin of 52 degrees and performed within specification for the rest of its operational life.
This experience changed how I think about sampling rates and filter design. A higher sampling rate is not automatically better. It can make aliasing problems worse if you do not account for out-of-band noise that folds into your control bandwidth. The Nyquist criterion is necessary but not sufficient. You need to think about the full spectral content of your measurement signals, not just the frequencies inside your bandwidth of interest.
Numerical Issues In Digital Implementation
When you move a continuous time controller to a digital processor, discretization errors can destroy your design. The most common discretization methods are the bilinear transform, also called the Tustin method, and forward or backward Euler approximation. The bilinear transform is the preferred choice because it maps the entire left half of the s plane into the interior of the unit circle in the z plane, preserving stability. It also avoids the frequency warping issues that plague Euler methods. However, the bilinear transform introduces frequency warping. The relationship between the continuous frequency omega and the discrete frequency omega tilde is given by omega equals two times the sampling frequency times the arctangent of omega tilde divided by twice the sampling frequency. This means that a compensator designed in the continuous domain and then discretized using Tustin will have its frequency response shifted slightly. For most applications with a sampling rate at least ten times the crossover frequency, the shift is negligible. If your sampling rate is closer to five times the crossover, you should pre-warp the critical frequencies before applying the transformation. Another issue that is easy to overlook is coefficient quantization. Fixed point implementations with limited word length can shift pole locations significantly. A second order section implemented with 16 bit coefficients can have its actual pole locations deviate from the design values by several percent, which matters when you are designing a narrow notch filter. Using double precision internally and only quantizing at the final output stage mitigates this problem but increases computational load. On a modern DSP this is rarely a bottleneck. On a low cost microcontroller it can consume a meaningful fraction of the available processing time.
Common Pitfalls And What Fails
Model-based design fails when the model is wrong. This sounds obvious but it is the single most common cause of project delays. A model that is missing a dominant pole, has an incorrect gain, or omits a coupling between axes will produce a controller that works in simulation and fails on hardware. The only reliable mitigation is validation through incremental hardware testing. Test each component of the control loop separately before integrating the full system. Robustness analysis is often skipped because it is tedious. You should check your design against parameter variations and unmodeled dynamics. The most practical method is to run Monte Carlo simulations where you vary key plant parameters within their expected tolerance ranges and observe the closed loop performance. If more than 5% of the runs produce unacceptable behavior, your design is not robust enough. This testing typically adds one to two days to a project timeline but prevents far more expensive failures later. Integral windup is a persistent problem in real systems. When the actuator saturates, the integrator continues to accumulate error. When the error finally reverses sign, the integrator output must first unwind to the saturation level before the actuator can respond. This can add seconds of delay to the transient response. The standard solution is anti-windup compensation, where you feed back the difference between the unsaturated and saturated controller output to the integrator. Implementing this correctly requires access to the internal integrator state, which is not always available in off the shelf PID controllers. You may need to implement the controller from scratch or modify the existing code.
High order controllers are another source of trouble. A controller with more than four or five poles and zeros becomes difficult to tune, sensitive to parameter variations, and expensive to implement digitally. Every additional pole and zero requires additional computation per sample period and introduces more numerical precision requirements. There is rarely a benefit to a controller higher than fourth order. If your design calls for something more complex, the problem is usually with the plant model or the specification, not with the controller structure.
Practical Tools And Resources
The standard software environment for this work is MATLAB with the Control System Toolbox and the Control System Designer app. These tools provide interactive Bode and Nyquist plot editing, pole placement, LQR synthesis, and automatic compensator design based on your specified margins and bandwidth. The app lets you drag the magnitude and phase curves to shape the open loop response directly and displays the resulting compensator in real time. This cuts the manual iteration time significantly compared to calculating compensator parameters by hand. For Python based workflows, the Python Control Libraries package provides similar functionality including Bode plot generation, root locus analysis, and state space design tools. The API is less polished than MATLAB but the results are comparable and the tool is free. For embedded implementation, Simulink Coder or the Python equivalent libraries can generate production code from your designed controller, reducing the chance of implementation errors between the design and deployment phases. Hardware in the loop testing is essential before field deployment. This involves running your controller code on the target processor while the plant is simulated in real time. You catch discretization errors, timing issues, and numerical overflow problems before they become expensive field failures. A proper HIL test setup with a real-time simulator and the actual controller hardware typically takes one to two days to configure but provides confidence that the deployed system will behave as designed.


