The Quick Math
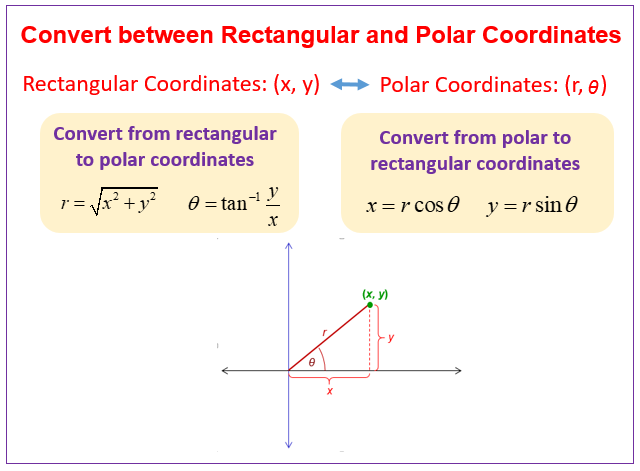
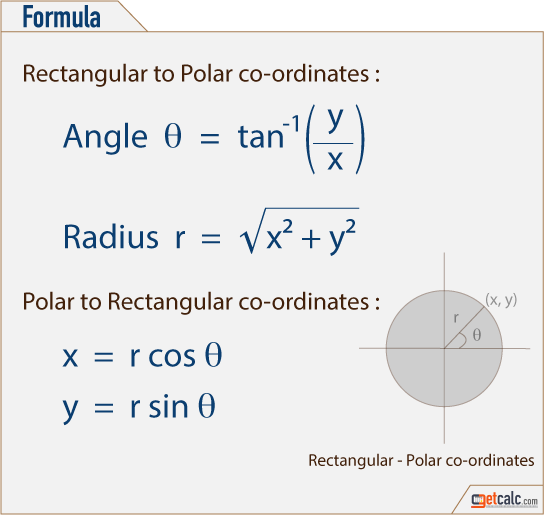
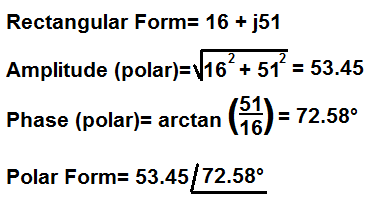
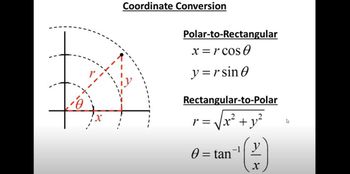
If you have a point (x, y) in rectangular form, the polar equivalents are r and . You calculate r with the Pythagorean theorem: r equals the square root of x squared plus y squared. The angle is where things get slightly more complicated. You use the atan2 function—atan2(y, x)—not plain arctangent. That distinction matters because it handles all four quadrants correctly without you having to manually adjust for signs. I still see people writing their own quadrant-checking logic in production code. Don't. atan2 exists for exactly this reason, and it's been part of C since the 70s. Using it cuts conversion errors down to essentially zero on the angle side, which is where most bugs hide.
Why This Matters for Convert Rectangular To Polar
The conversion itself is straightforward, but the implications show up when you start working with signals, control systems, or RF measurements. A lot of instrument output comes in rectangular (I/Q data), but the things you actually want to read—magnitude, phase, reflection coefficient—are naturally expressed in polar. Trying to do magnitude calculations on I and Q separately is an exercise in frustration. I spent a week debugging a phase discontinuity in a software-defined radio project back in 2019. The signal looked fine in rectangular form. Every sample was correct. But when I plotted the converted phase, it jumped by 360 degrees at certain points. The issue wasn't the conversion itself—it was phase unwrapping. The raw atan2 output clamps between - and , so when the true phase crosses that boundary, your plot snaps. The fix was running the phase data through a standard unwrap routine that adds or subtracts 2 whenever it detects a jump larger than . Once I did that, the spectrum cleaned up immediately. Took about ten minutes after a week of not understanding why the numbers looked wrong.
The Mechanics, More Precisely
For Convert Rectangular To Polar, you're really doing two independent operations that happen to share the same input pair. The magnitude calculation is trivial and numerically stable as long as x and y aren't extreme. But if your values approach the floating-point limits, sqrt(x² + y²) can overflow or underflow before the square root even evaluates. I've encountered this in a power amplifier simulation where I and Q values were in the range of 10. The intermediate squares blew past double-precision capacity. The workaround is to scale the inputs first—divide both by the larger absolute value, compute r, then multiply back. MATLAB's hypot function does this automatically, and most modern math libraries have an equivalent. Use it instead of rolling your own. The angle calculation has its own edge case: the origin. If both x and y are zero, atan2 returns 0 by convention, but the angle is technically undefined. In practice this shows up when your signal truly has zero magnitude—noise floor samples, dead channels, failed calibration references. Don't trust the angle at r equals zero. It's garbage being masked by a clean default value. In my experience the cleanest approach is to skip the angle entirely whenever r falls below a defined threshold, usually something like 1e-12 relative to your signal scale. Anything below that is measurement noise, not a real phase. Another thing beginners miss: the units. atan2 returns radians. Most engineers understand that, but the next step often trips people up. If you're feeding the result into a lookup table or a hardware register that expects degrees, or if your downstream algorithm assumes degree input, you'll get nonsensical results that look like a code bug rather than a unit mismatch. I once had a control loop oscillate because someone mixed radians and degrees across two subroutines and the Bode plot still looked reasonable at low frequency. The phase margin was completely wrong by the time we hit crossover. Converting atan2 output to degrees is just a multiplication by 180 over , but the point is to be explicit about it early rather than discovering it later.
Get the Full Details

When the Conversion Fails You
Polar representation has a real limitation that rectangular doesn't: the phase becomes unstable near the origin. As magnitude approaches zero, any noise in x or y gets amplified into wild phase swings. This isn't a numerical issue you can fix with better precision—it's inherent to the coordinate system. If you're working with noisy low-signal data and need smooth phase tracking, rectangular form is the better representation throughout the pipeline. Convert to polar only at the final visualization or reporting stage. There's also the matter of additivity. In rectangular coordinates, adding two vectors means adding their components. In polar, you have to convert back to rectangular, add, and then convert again if you need the result in polar. This comes up constantly in antenna array work and filter design where you're summing contributions. Don't try to add polar vectors directly. It doesn't work that way, no matter how clean the math looks on paper. For those situations, I typically keep everything in rectangular form through the computation and only call the conversion routine at the end. The overhead of sqrt and atan2 on a single pair of numbers is negligible on modern hardware—even on an embedded MCU, a single conversion takes microseconds, not milliseconds. The real cost shows up when you're converting millions of samples per second in real time, and even then, vectorized DSP instructions handle it without breaking a sweat.