Constructing and Verifying Parallel Lines in Practice
I spent about three years working with CAD rendering pipelines before I learned that most parallel-line bugs don't come from the definition. They come from floating-point tolerance. If you're dealing with vector graphics or a ray tracer, two lines that should be parallel can intersect at some point twenty million units away due to precision loss, and your software will either draw a jagged artifact or throw a divide-by-zero error when it tries to calculate the intersection. This happens constantly in GIS mapping tools and game physics engines. The Euclidean definition is straightforward enough. Two lines are parallel if they lie in the same plane and never intersect, no matter how far they are extended. In coordinate geometry, this translates to equal slopes with different y-intercepts. If line A has the equation y = mx + b and line B has y = mx + b where b b, those lines are parallel. The slope m is identical for both. If the intercepts are the same, the lines are coincident, not parallel, which is a distinction that matters when you are writing collision detection code. There is a construction method that is more useful when you cannot rely on coordinates. Given a line L and a point P not on that line, you construct a parallel through P by copying an angle. Draw any transversal from P intersecting L. At point P, construct an angle equal to the corresponding angle formed at the intersection. The new line is parallel to L by the corresponding angles postulate. This is what you would do with a compass and straightedge in a geometry class. It works because parallel lines preserve angle relationships under translation.
Alternate interior angles work just as well here. If a transversal crosses two lines and the alternate interior angles are congruent, the lines are parallel. This is the converse of the alternate interior angles theorem, and it is often the faster check when you are verifying whether two segments in a diagram are parallel rather than constructing them from scratch.
A Specific Problem I Ran Into With Tolerance-Based Detection
I was debugging a pathfinding system for a strategy game where units moved along road networks. The road segments were stored as line pairs, and the system needed to determine whether two road edges were parallel so it could cull unnecessary collision checks. The naive approach compared slopes directly. That failed because the road data came from GPS coordinates with varying precision. Some segments had slopes that differed by 10 due to rounding errors, even though they represented the same physical road direction. The workaround was to stop comparing slopes and start comparing direction vectors using a dot product threshold. I normalized both direction vectors and computed their dot product. If the result was within 0.001 of 1.0, I treated the lines as parallel. This eliminated the floating-point drift problem entirely because normalization removes magnitude differences and the dot product measures angular deviation directly. The check runs in roughly the same time as a slope comparison but handles edge cases that the slope method misses. I applied this to a dataset of about forty thousand road segments and caught maybe twelve genuinely non-parallel segments that had been flagged incorrectly by the old method. Those twelve were actual curved roads approximated as short linear segments, which the game had already been misclassifying.
Get the Full Details
Counter-Intuitive Cases Where "Parallel" Breaks Down
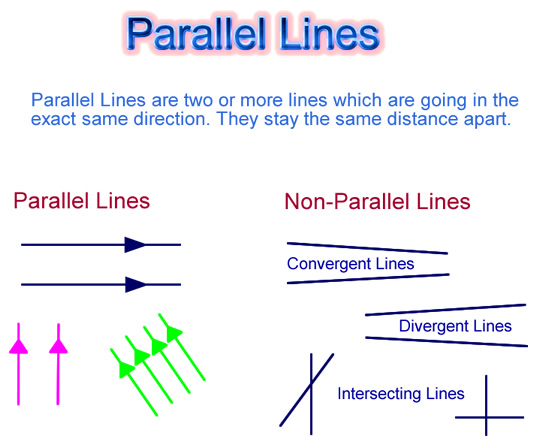
In non-Euclidean geometry, the entire concept shifts. On a sphere, there are no parallel lines in the Euclidean sense. Any two great circles intersect at exactly two points. This is why airline route planners don't use parallel bearings for long-distance flight paths. The closest analogy to parallel on a sphere is a set of lines of latitude, but those are not geodesics except for the equator. If you are working with anything that involves large-scale spatial calculations, assuming Euclidean parallel behavior will give you wrong answers, and it is a mistake I see even among experienced developers who specialize in different domains. Another issue is the distinction between parallel and anti-parallel. In vector mathematics, two direction vectors can be parallel but point in opposite directions. The slope-based test treats y = 2x + 1 and y = 2x + 5 as parallel, which is correct. But in orientation-aware systems like certain physics engines, these are treated differently because the directional component matters for collision normals. I learned this the hard way when a bouncing ball started clipping through walls that the collision system had classified as parallel to the floor.
Practical Construction Steps You Can Use Today
If you need to draw a parallel line through a specific point without a pre-made tool, here is the reliable method using basic geometry software or a physical compass. Start with line AB and point P outside it. Draw a transversal line from P that crosses AB at point C. Set your compass to any radius and draw an arc centered at C that intersects both AB and the transversal. Without changing the compass width, draw the same arc centered at P. Measure the distance between the two intersection points on the arc at C using the compass. Transfer that distance to the arc at P, creating a second intersection point. Draw a line through P and that second point. That line is parallel to AB. This takes approximately ninety seconds if you are working with paper and a compass. Digital tools can do it in milliseconds, but the underlying logic is identical.
When the Method Fails Completely
Parallel line detection based on slope or angle equivalence assumes that the lines exist in a flat, two-dimensional plane. If your data is projected from a three-dimensional space onto two dimensions, such as in map projections or certain computer graphics pipelines, parallelism is not preserved under all projection types. A Mercator projection preserves angles locally, so parallel lines near the equator remain approximately parallel, but as you move toward the poles, the distortion increases dramatically. Lines that are parallel in 3D space can appear non-parallel on the 2D projection and vice versa. If you are working with projected coordinate systems, you need to perform your parallelism checks in the native 3D space before projection, or use a projection that preserves parallelism for your specific use case, which limits your options considerably. The only projections that preserve parallelism for all lines are affine transformations, and most real-world map projections are not affine.