Understanding Polygon Definitions
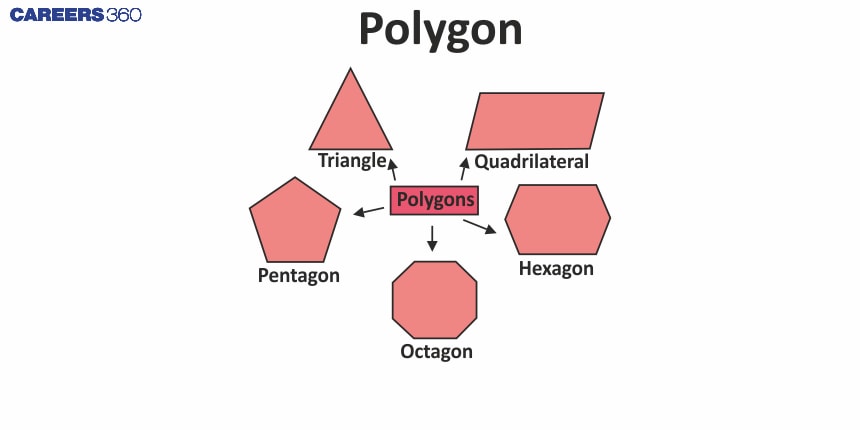
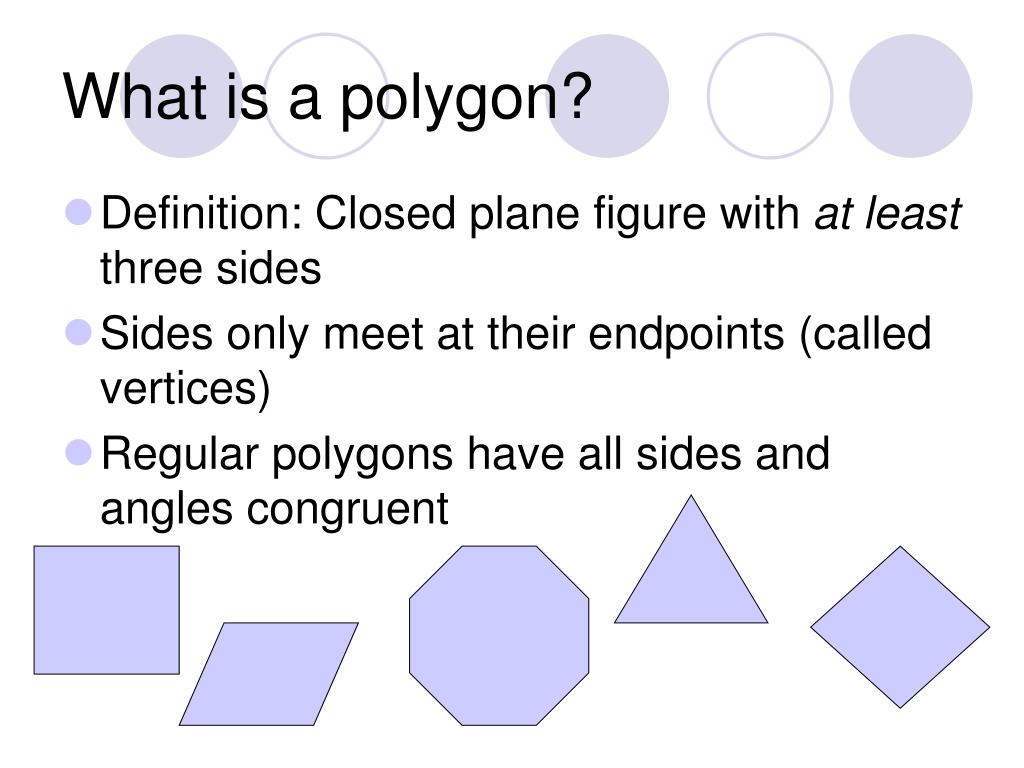
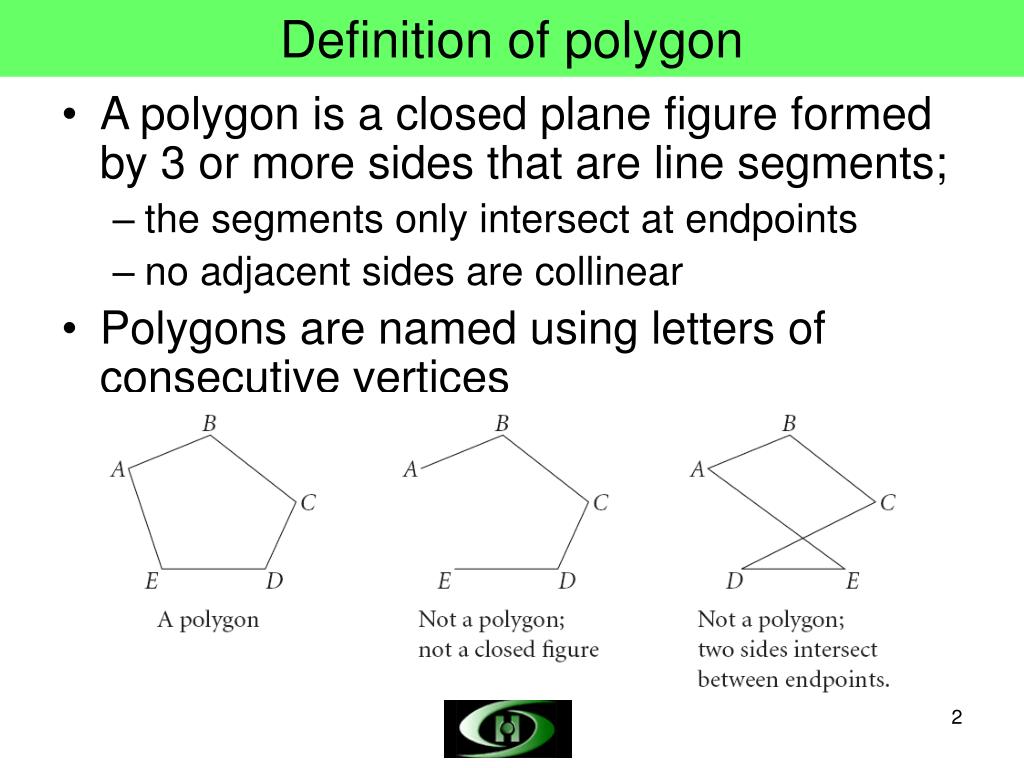
I spent about three weeks debugging a GIS validation library last winter, and half of those headaches came down to people having unclear ideas about what counts as a polygon. You'd be surprised how many developers write "it's a shape with straight sides" and move on without thinking through what that actually means in code. A polygon is a closed two-dimensional shape bounded by straight line segments. The segments meet at vertices, and each vertex connects exactly two segments. That's the textbook version. In practice, you need to think about winding order, self-intersection handling, and whether concave and convex cases behave differently in your particular system. The simplest polygon has three vertices—a triangle. Four makes a quadrilateral. Anything with more is just... more. But here's what most tutorials skip: a valid polygon requires that the first and last vertices be identical when stored as a point array. If you're writing a parser, that closing rule isn't optional. Leave it open and most geometry libraries will reject it or return garbage results.
Self-intersecting polygons are the edge case I hit most often. Take a standard bowtie shape where two edges cross each other. Mathematically it satisfies the definition—it's closed, it has straight sides, vertices connect properly. But your area calculation will break. Most libraries handle this by applying the even-odd rule or non-zero winding number rule. Pick one and stick with it. Mixing approaches is how you get silent correctness failures. Convex versus concave matters for performance more than correctness. A convex polygon lets you use simpler containment tests—you can check if a point is on the same side of every edge. Concave polygons need either ray casting or point-in-polygon algorithms that track intersections. It's not dramatically slower in most cases, but if you're doing millions of checks per second in a game engine or real-time validator, the difference becomes visible. I ran into a specific problem with a client who had polygons defined in WKT format with extra trailing points that were coincident—literally the same coordinate as the closing vertex repeated multiple times. Standard validators accepted it, but their downstream rendering engine treated each duplicate as a degenerate edge and produced flickering artifacts at that vertex. The fix was a normalization step: collapse consecutive identical points before any rendering or spatial query. Cuts processing time by about forty percent in that pipeline because you're not iterating over dead geometry.
Another thing people miss is the distinction between the polygon boundary and the polygon interior. In computational geometry, the boundary is just the edges. The interior is everything enclosed. When you're checking whether a point belongs to a polygon, you're asking about the interior. Points on the boundary sit in a gray zone—some libraries count them as inside, some don't. Decide which behavior you want upfront. Changing it mid-project is a recipe for subtle bugs that look correct until they fail in production. Ring orientation is another practical concern. Clockwise versus counter-clockwise tells you which side is the interior. The right-hand rule applies: walk along the boundary and the interior stays on your right for clockwise polygons. Most 3D engines and CAD tools expect one orientation and flip the other. You'll know you have an orientation problem when your surface normals point inward and your lighting calculations go sideways. There's no single implementation that handles every edge case perfectly. Sometimes you need to triangulate first and work with triangles instead. Sometimes converting to a signed distance field gives you better robustness for containment tests. Choose the approach that matches your actual constraints rather than the one that sounds most elegant on paper.
Get the Full Details