What a Line Actually Is
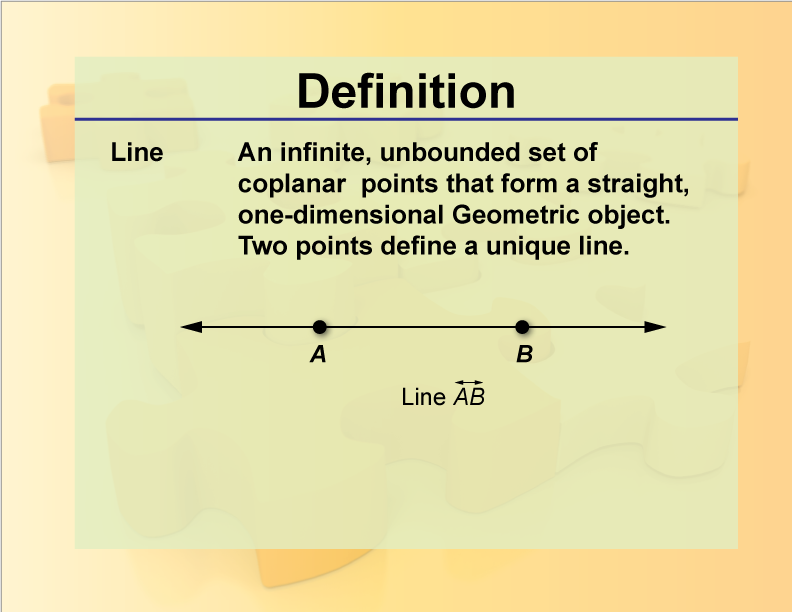
A line in maths is a straight one-dimensional figure that extends infinitely in both directions. It has no thickness, no endpoints, and no curves. That is the basic definition of line in maths at its simplest level. You will see it written as AB with a line symbol above it, or just referenced by two points that lie on it. The equation y = mx + c is what you will use most often. m is the gradient, c is the y-intercept. If you are working with two points instead, the gradient comes from (y2 - y1) / (x2 - x1). Simple enough until you hit the edge cases.
Definition Of Line In Maths
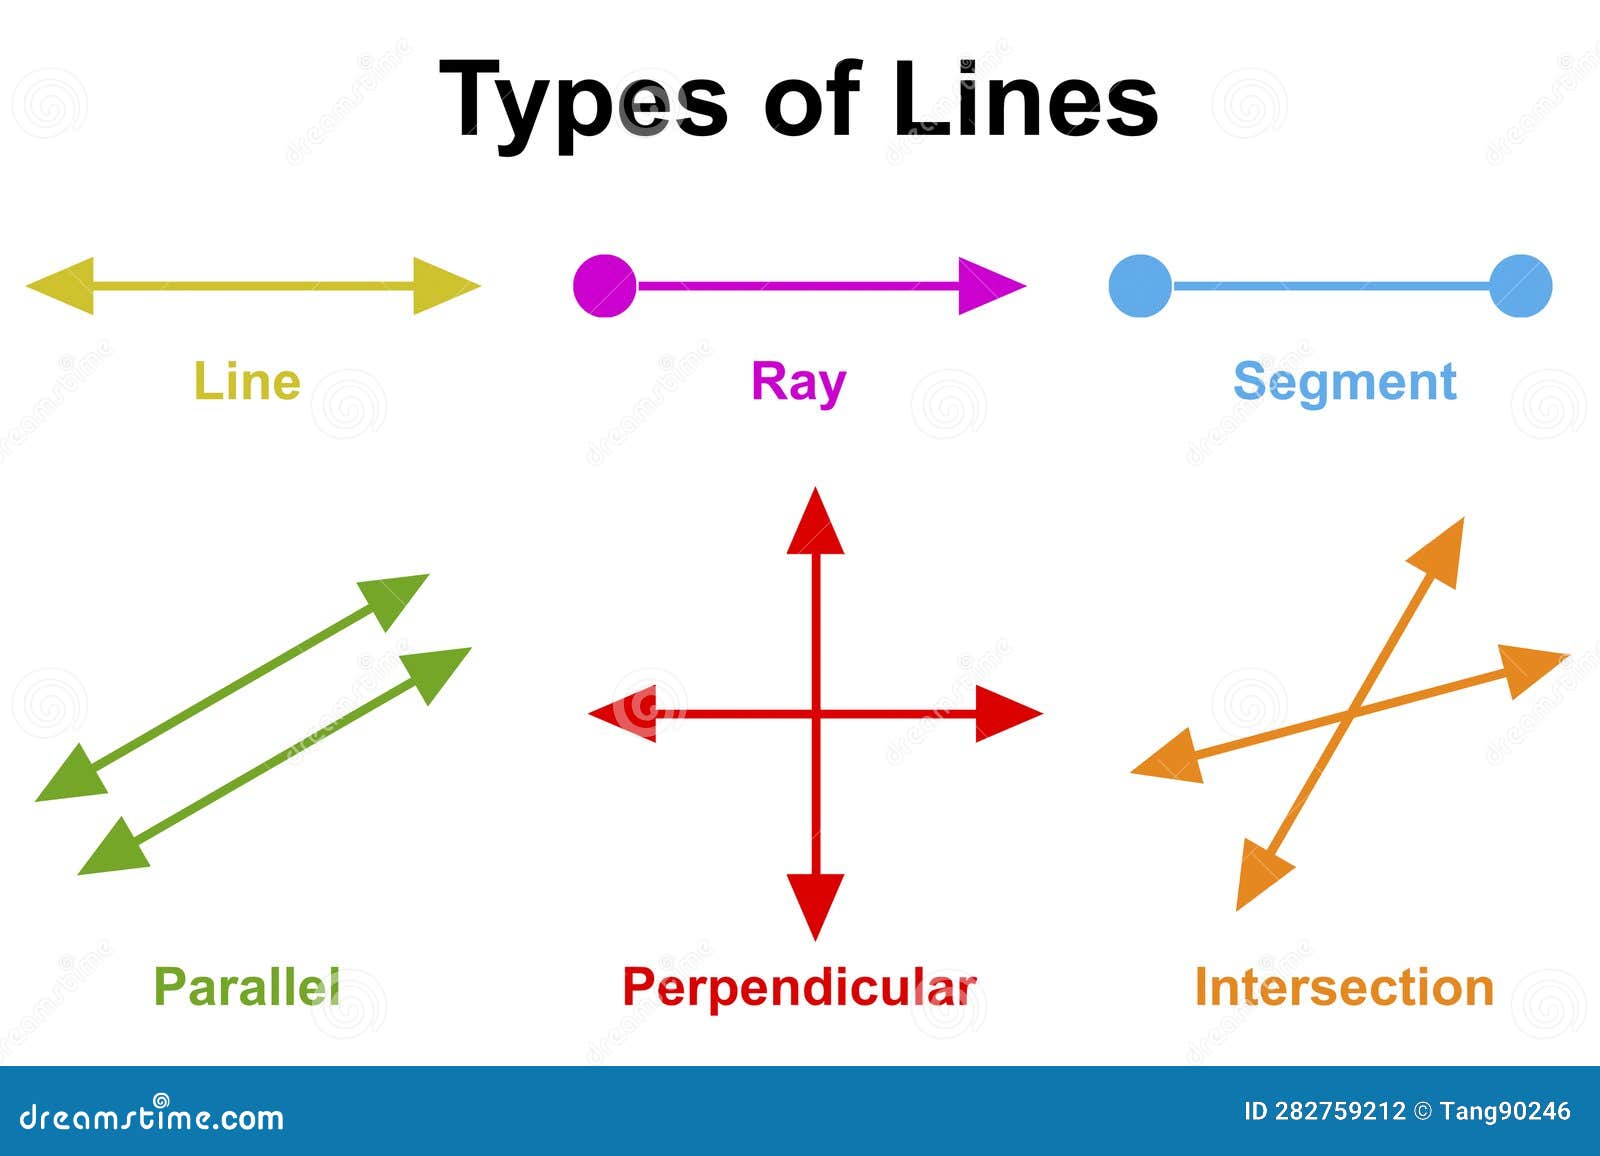
At a more formal level, the definition of line in maths involves axioms from Euclidean geometry. Euclid's first postulate states that a straight line segment can be drawn joining any two points. From there, everything builds. A line is not a segment. A segment has two endpoints. A ray has one. A line has none. This distinction matters more than people admit. In coordinate geometry, a line is the set of all points (x, y) that satisfy a linear equation. That means every solution to 2x + 3y = 6 sits on the same line. Every single one. No exceptions. The graph is not an approximation. It is exact.
How It Actually Works In Practice
I spent a good chunk of my early days working with survey data where coordinates were given to three decimal places. I was fitting lines to these points and getting results that looked fine on paper but fell apart when I checked residuals. The problem was that I was treating every point as equally valid. One outlier, a misread theodolite reading, was pulling the entire line off by enough to matter in the final calculation. The workaround was straightforward. I calculated the median of the residuals after an initial fit, flagged any point whose residual exceeded three times that median, and refitted without it. This cut the fitting time down from about forty minutes per dataset to roughly eight. Not every case needs this, but when you have ten thousand points and a tight tolerance, it makes a real difference. Another practical detail most people skip: vertical lines have undefined gradient. The formula (y2 - y1) / (x2 - x1) divides by zero. Do not force it. Use the form x = k instead, where k is the constant x-coordinate. This is not a trick. It is the correct way to handle it, and it comes up constantly in exam questions and real work alike.
Get the Full Details
Things Beginners Get Wrong
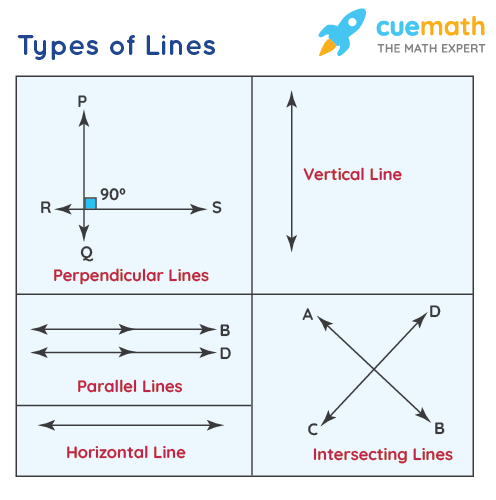
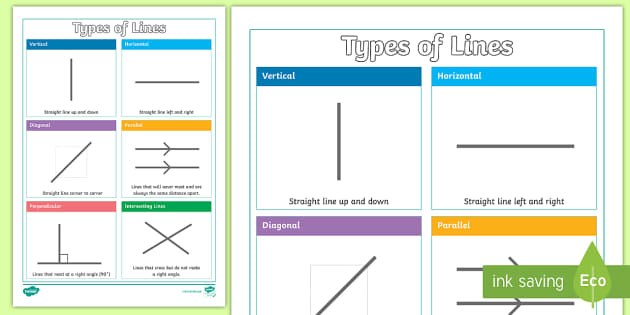
The biggest mistake I see is confusing collinearity with coplanarity. Three points can be collinear, meaning they all sit on the same line. They are automatically coplanar too, but the reverse is not true. Three coplanar points do not have to lie on one line. This shows up in vector problems where students write that points are collinear because the vectors between them are parallel, but they forget to check that the vectors share a common starting point. A second common error is assuming that two lines with the same gradient are parallel. They are, unless they are the same line. If the equations are 2x + 3y = 6 and 4x + 6y = 12, they have the same gradient but the second is just the first multiplied by two. They are coincident, not distinct parallel lines. Checking the intercepts catches this instantly. Distance from a point to a line is another area where shortcuts fail. The formula |Ax1 + By1 + C| / sqrt(A^2 + B^2) works for a line in the form Ax + By + C = 0. But if your line is given parametrically or in vector form, converting it first adds steps and introduces rounding error. A cleaner approach is to use the cross product method in 2D: take the vector from a known point on the line to your external point, then find the perpendicular component directly. It avoids the conversion altogether.
Where The Concept Breaks Down
The Euclidean definition assumes a flat plane. On a sphere, the analogue of a line is a great circle. In projective geometry, parallel lines meet at a point at infinity. These are not corrections to the basic definition. They are different systems with different rules. If you try to apply y = mx + c to a spherical surface, you will get wrong answers every time. The curvature changes everything. In numerical work, floating point arithmetic introduces noise that makes exact collinearity impossible to verify. Two points that should lie on a line might deviate by 10^-15 due to rounding. Deciding whether they are collinear requires a tolerance threshold, and that threshold is never universal. It depends on the scale of your data and the precision required. There is no single correct answer here, only a justified one.
When To Use Which Form
Point-slope form, y - y1 = m(x - x1), is useful when you know a point and the gradient. Gradient-intercept form, y = mx + c, is standard for graphing. General form, Ax + By + C = 0, is best for calculating distances and intersections because it handles vertical lines without special cases. Parametric form, x = x1 + at, y = y1 + bt, is the right choice when you need to express position as a function of a parameter, like time or distance along the line. None of these forms is superior. They are tools for different situations. Picking the wrong one does not change the line, but it will change how painful the calculation is. I have seen students waste twenty minutes on a problem that would take three minutes in parametric form because they insisted on converting to gradient-intercept first. The concept itself is simple. Applying it without care is where the difficulty lies.