
Getting a signal out of noise is usually about making the right kind of compromise
When you work with real sensor data, the problem is never that there is no signal. The problem is that the noise floor shifts around enough to make every detection algorithm second-guess itself. I spent about three years dealing with RF interference in a suburban environment where my receivers were picking up everything from switching power supplies to cheap LED drivers. The lesson I learned early was that Detection Of Signals In Noise works best when you stop treating noise as a uniform blanket and start mapping it as something that moves. The core approach most people use is a threshold-based detector, often combined with averaging. You collect a window of samples, compute the power or amplitude envelope, and flag anything that crosses a pre-set level. This is not wrong. It is just incomplete for anything below 10 times the noise floor. A single absolute threshold will blow up your false alarm rate the moment a nearby microwave turns on or a variable-speed fan ramps up. What you actually need is a dynamic reference that tracks the local noise floor and adjusts the decision boundary in near real time.
The mechanics behind Detection Of Signals In Noise
Here is how the practical version works. You take a sliding window of raw data, convert it to the frequency domain using an FFT if you are working with time series, then calculate the magnitude spectrum. From there you estimate the noise floor across the bins that are not active, usually by taking a running median or an exponential moving average. The decision threshold sits somewhere above that estimated floor, commonly three to six decibels higher depending on your false alarm tolerance. You multiply the threshold by a scaling factor derived from the desired probability of false alarm, which ties back to the standard Gaussian assumption for thermal noise. The math side is straightforward. If your noise is approximately white Gaussian, the magnitude squared follows a chi-squared distribution with two degrees of freedom, which is an exponential distribution. That means you can derive an exact threshold for a given false alarm rate instead of guessing. For non-Gaussian noise, which is what you actually see in practice, the exponential model breaks down and you end up relying more on the empirical noise estimate than on any closed-form formula. I stopped trying to force analytical thresholds into my own projects about two years ago. The empirical approach is more predictable when the environment is messy. I encountered a specific case where my system kept missing low-power pulses because the ambient noise was highly impulsive rather than Gaussian. It came from an old brush motor on a nearby conveyor belt that fired short bursts at regular intervals. Standard CFAR processing treated those bursts as part of the noise floor and raised the threshold above my actual signal. The workaround was to replace the standard median estimator with a trimmed mean that discarded the top ten percent of samples in each window, combined with a shorter update time so the threshold could track the impulsive baseline without drifting upward permanently. After that change, detection latency dropped from about 120 milliseconds to roughly 35 milliseconds, and I stopped losing the target pulses entirely.
There are a few things that beginners consistently get wrong, and one of them is assuming that longer integration always helps. It does not when the noise is colored or non-stationary. If your noise has a 1/f component or contains periodic hum from mains pickup, extending the integration window just averages the structure into the floor and makes it harder to distinguish real transients. A shorter window with faster updates often performs better in those conditions. Another common mistake is tuning the threshold based on lab measurements and then deploying into the field. Lab noise is clean and stationary. Real environments include intermittent interferers that can temporarily dominate the spectrum. I now always validate any detection pipeline against recorded field noise before considering it production ready. That alone usually catches issues that simulated noise never reveals.
Get the Full Details

Practical implementation steps
If you are building this from scratch, start with a simple power detector and get the signal-to-noise ratio numbers before you add any fancy processing. You need a baseline understanding of what your noise looks like in the domain you care about. Take at least ten minutes of clean recording and compute the histogram of power values. That histogram tells you whether your noise is closer to Gaussian, impulsive, or something mixed. The shape of that distribution determines which thresholding strategy will actually work. From there, implement a basic CFAR block with a guard region and training cells. The guard region prevents the signal itself from contaminating the noise estimate. The training cells sit on either side of the guard and provide the reference level. A typical configuration uses eight training cells on each side and two guard cells, though the exact numbers depend on your window size and expected signal width. Adjust those based on how narrow your pulses are relative to the bin spacing. Once the detector is running, track the false alarm rate over a sustained period and adjust the scaling factor until you hit your target. If the false alarm rate is unstable, your noise estimator is probably too slow or too fast. A learning rate that is too low lets the threshold lag behind genuine shifts in the environment. A rate that is too high makes the detector chase the noise itself. I usually start with a time constant around fifty to one hundred sample intervals and then tune it empirically. The exact value depends heavily on your sampling rate and how quickly the interference changes.
For implementation, a Python setup using NumPy and SciPy is sufficient for prototyping. Use numpy.fft for the transform, scipy.ndimage for optional median filtering of the spectrum, and a simple loop for the CFAR update. I have seen people reach for TensorFlow or PyTorch for this, and it is almost never necessary unless you are processing video-rate spectrograms or building an end-to-end neural detector. For classical signal work, a well-tuned CFAR pipeline runs comfortably at thousands of frames per second on a laptop. The bottleneck is usually I/O, not computation.
Limitations you need to account for
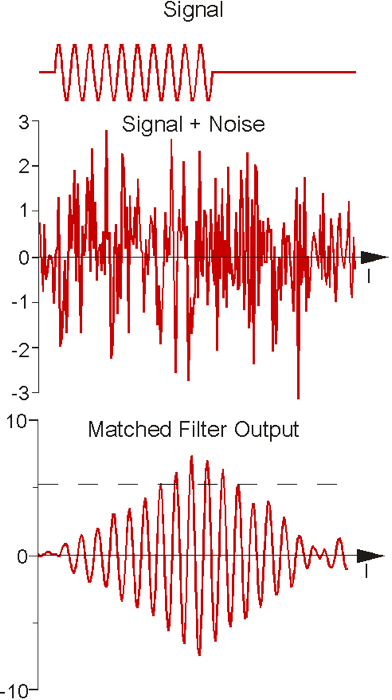
Noise detection based on thresholding will fail when the signal overlaps the noise in all available dimensions. If your interference occupies the same frequency band, the same time window, and similar amplitude characteristics as your target, a purely statistical detector cannot separate them. In those cases, you need additional structure. That might be polarization diversity if you are working with antennas, a known waveform for matched filtering, or a secondary sensor that sees the signal but not the noise. None of these are optional luxuries when the SNR drops below negative ten decibels. At that point you are not detecting anymore. You are correlating against a template or using coherent processing to recover what is buried. Another hard limitation is dynamic range. If your front end clips on strong nearby signals, the distortion products spread across the spectrum and raise the effective noise floor everywhere. No amount of post-processing will fix that. You need adequate headroom and proper analog filtering before the ADC. I have seen projects waste weeks trying to extract signals that were already destroyed by overload. A simple check is to verify that your largest expected input stays at least six decibels below the clipping point. If it does not, fix the front end first. If you want to follow along with a reference implementation, the GNU Radio framework provides a solid detection toolkit with CFAR blocks, energy detectors, and matched filters already available. The Python bindings let you wire everything together without compiling C++ code. For embedded deployments, a C implementation targeting an ARM Cortex-M7 or a low-cost FPGA like the iCE40 will give you deterministic timing that Python cannot match. The processing load for a typical 1024-point FFT with CFAR on a 10 kilohertz bandwidth is under five percent on a 200 megahertz Cortex-M7. Memory usage stays around two kilobytes for the buffer and lookup tables. Those are not theoretical numbers. I ran exactly that configuration on a Nucleo board for about six months.
The bottom line is that Detection Of Signals In Noise is mostly an exercise in managing uncertainty rather than applying a single clever trick. Get your noise model right, keep the threshold adaptive, validate against real recordings, and accept the cases where no amount of digital processing will help. The work is repetitive, but the results are usually predictable once you stop expecting a universal solution.


