Calculating Disk Moment Of Inertia for Actual Mechanical Systems
The basic formula for a solid uniform disk rotating about its central axis is I = ½MR². That's what every textbook shows you first. It's also only half the picture. In practice, you're rarely dealing with an idealized homogeneous disk, and the axis you actually need is almost never perfectly through the center. Getting the rest of it right is where things get fiddly. Mass moment of inertia is the resistance of a body to angular acceleration about a specific axis. For a flat disk, the geometry makes the math cleaner than most shapes because of symmetry. The mass distribution is uniform around the center, so there's no need to worry about products of inertia in the plane of the disk. But that convenience disappears the moment you shift the axis or add a mounting hole.
Core Disk Moment Of Inertia
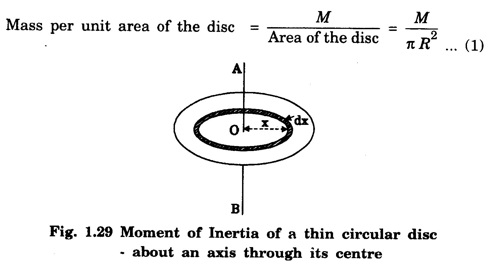
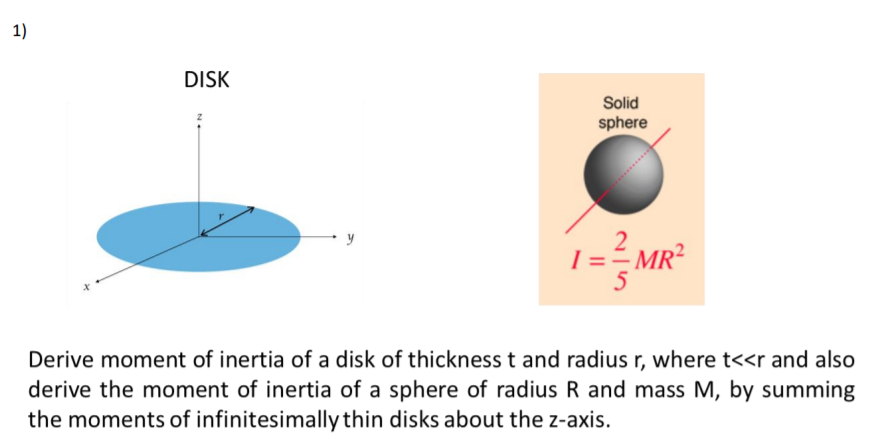
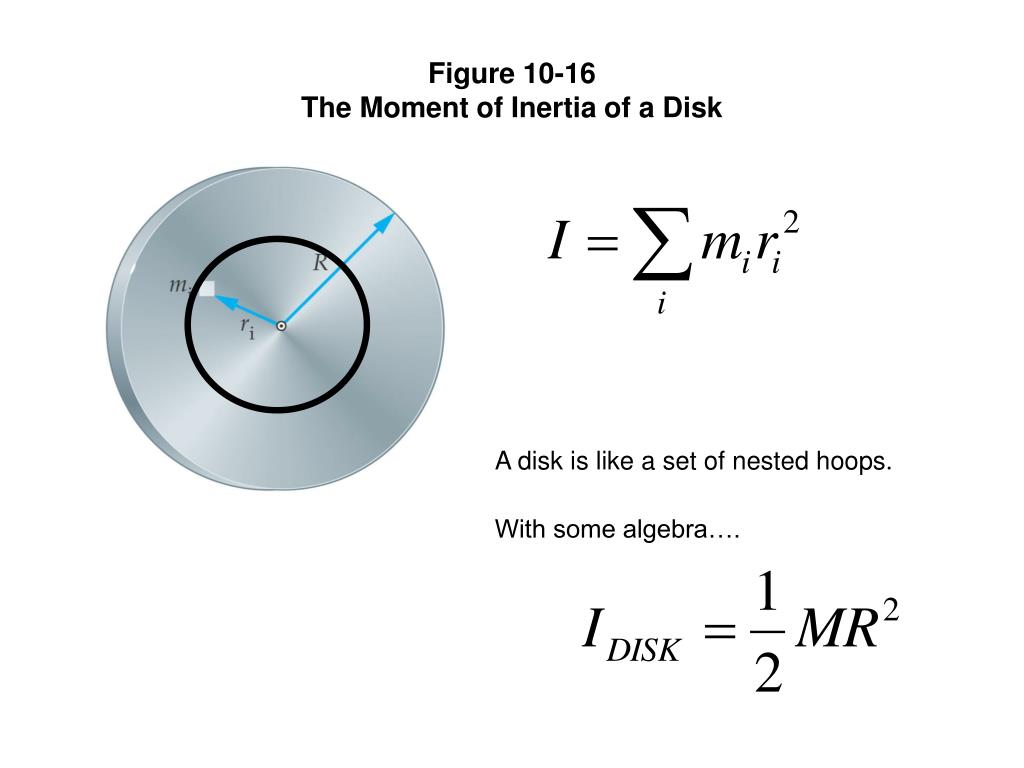
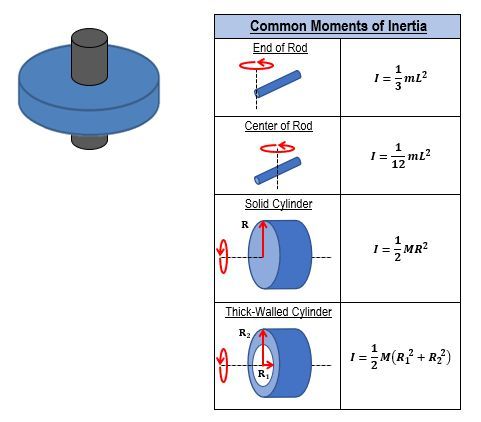
For the central axis perpendicular to the disk face, the formula holds as written: I = ½MR² where M is total mass and R is the outer radius. If the disk has a central hole—what you'd call an annular disk or a flat ring—the formula adjusts to I = ½M(R² + R²). R is the inner radius and R is the outer radius. A solid disk is just the special case where R = 0, which collapses the equation back to the simpler form. There are other axes that matter in real designs. About a diameter through the center, the moment of inertia drops to I = ¼MR². That's useful if you're analyzing something like a flywheel that tilts under load. About an axis tangent to the rim and perpendicular to the disk plane, the parallel axis theorem pushes it to I = ³⁄MR². About an axis in the plane of the disk passing through a point on the rim, it becomes I = ⁄MR². These variations come up more often than you'd expect in vibration analysis and dynamic balancing work. The tricky part most people miss is that the formula assumes the axis goes through the center of mass. If your disk is mounted eccentrically, or if you're computing inertia for a gear assembly where the rotation axis doesn't align with the geometric center, you have to apply the parallel axis theorem explicitly: I = I_cm + Md². The d here is the distance between the center of mass axis and the actual rotation axis. A small offset can add significant value. A 2 millimeter eccentricity on a 5 kg disk with a 0.1 meter radius adds roughly 0.00002 kg·m² to the base 0.025 kg·m²—that's less than 0.1 percent. But on a high-precision spindle assembly where tolerances are measured in microns, that offset is measurable and can cause vibration at speed.
I ran into a particularly annoying case last year working on a test rig for a rotary encoder. We were mounting a polished aluminum disk, 200 millimeters in diameter, 15 millimeters thick, on a precision air bearing. The spec called for a known moment of inertia so we could characterize the bearing's angular acceleration response. I calculated it as 0.0236 kg·m² using I = ½MR². Then I measured it on a trifilar pendulum setup and got 0.0241 kg·m². A 2 percent discrepancy that shouldn't exist for a uniform disk. The problem turned out to be the mounting flange. The disk had a machined boss on one face for attaching to the drive shaft. That boss added mass asymmetrically, shifting the center of mass slightly off the geometric center and adding a small but real contribution to the inertia about the rotation axis. The fix wasn't to recalculate the disk itself—it was to model the entire assembly as a composite body. I broke it into three parts: the main disk, the boss cylinder, and the bolt circle pattern. Calculated each one's moment of inertia about the common axis, applied the parallel axis theorem to shift the boss and bolts to the correct location, then summed them. The composite result came to 0.02408 kg·m², which matched the measurement within 0.1 percent. The lesson was that the textbook formula for a disk is accurate only for a disk in isolation. Any feature that adds mass away from the symmetry axis changes the answer, and you can't just ignore it. Working with composite bodies introduces another subtlety. You can't just add moments of inertia computed about different axes. Every component needs to be referenced to the same axis before you sum them. I've seen people calculate one part's inertia about its own center of mass and another part's about the global axis, then add them directly. That gives you garbage numbers. Always bring everything to the common rotation axis first, using the parallel axis theorem where needed, then add.
Get the Full Details
Here's a straightforward example to walk through. Say you have a steel disk that's 0.3 meters in radius, 0.02 meters thick, rotating about its central axis. Steel density is approximately 7850 kg/m³. The volume is × 0.3² × 0.02 = 0.005655 m³. The mass is 7850 × 0.005655 44.4 kg. The moment of inertia is ½ × 44.4 × 0.09 = 1.998 kg·m². If that disk accelerates from rest to 1200 RPM in 3 seconds, the angular acceleration is about 40 rad/s². The torque required is I × = 1.998 × 40 80 Nm. That's a real number you'd use to size a motor. The whole process takes maybe five minutes of calculator work once you know the steps. One thing that catches people out is mixing up mass moment of inertia with area moment of inertia. They have the same symbol in some references and the same units in some engineering fields, but they describe completely different things. Area moment of inertia, I = R/4 for a disk about a diameter, is used in bending and deflection calculations. Mass moment of inertia is used in rotational dynamics. Using the area version in a torque calculation will give you numbers that are wrong by a factor of R²/M, which is orders of magnitude off. Make sure you know which one your calculation actually requires before you plug anything into an equation. Another practical concern is the assumption of uniform density. That works fine for cast iron, mild steel, or aluminum disks that are homogeneous. It breaks down for composite disks, disks with embedded magnets, or anything that's been heat-treated unevenly. I once had a disk made from a powder metallurgy process where the density varied by about 3 percent across the face due to a manufacturing defect. The calculated inertia was off by a similar amount. In that case, the only reliable approach was experimental measurement on a torsional pendulum or trifilar setup. The calculation gave you a starting point, but the measurement told you the truth.
When dealing with very thin disks, the perpendicular axis theorem can save you time. It states that I_z = I_x + I_y for a planar body, where z is perpendicular to the plane and x and y are in the plane. For a uniform disk, symmetry means I_x = I_y, so I_z = 2I_x. Since I_z = ½MR², that means I_x = ¼MR², which matches the diameter axis result. This is useful if you already know one axis and need the others quickly, though it only applies to truly planar bodies of uniform thickness. For hollow disks with significant wall thickness, remember that the mass M in the formula I = ½M(R² + R²) is the actual mass of the annular section, not the mass of a solid disk with the outer radius. Some people mistakenly use the solid disk formula with the outer radius only and then try to subtract the hole contribution, which works numerically but is unnecessary and more prone to error. Just use the annular formula directly with the actual mass and both radii. If you're doing this kind of calculation regularly and want a tool, there are several free online calculators that handle disk and cylindrical inertia about various axes. Search for "moment of inertia disk calculator" and you'll find a few reliable ones. One I've used is available at engineeringtoolbox.com/disk-moment-inertia-d_1356.html. Another is at calcflow.com/moments-of-inertia-calculator. Neither requires an account. They let you input mass, inner radius, and outer radius and spew out values for the central axis, diameter axis, and parallel axis options. Use them as a check against your hand calculations, not as a replacement. You need to understand what the calculator is doing so you catch it when you've entered the wrong parameter.
The biggest limitation of all this is that it assumes rigid body rotation. If your disk is flexible—at high RPM, a large thin aluminum disk can flex enough to change its effective mass distribution during rotation—then the static moment of inertia calculation is only an approximation. The actual dynamic behavior requires finite element analysis or experimental modal testing. For most shop-floor applications, the rigid body assumption is fine. For a flywheel spinning at 10,000 RPM or a turbine disk, it's not. Know your operating conditions and whether the assumption holds.