Understanding When to Multiply Vectors and How the Results Actually Differ
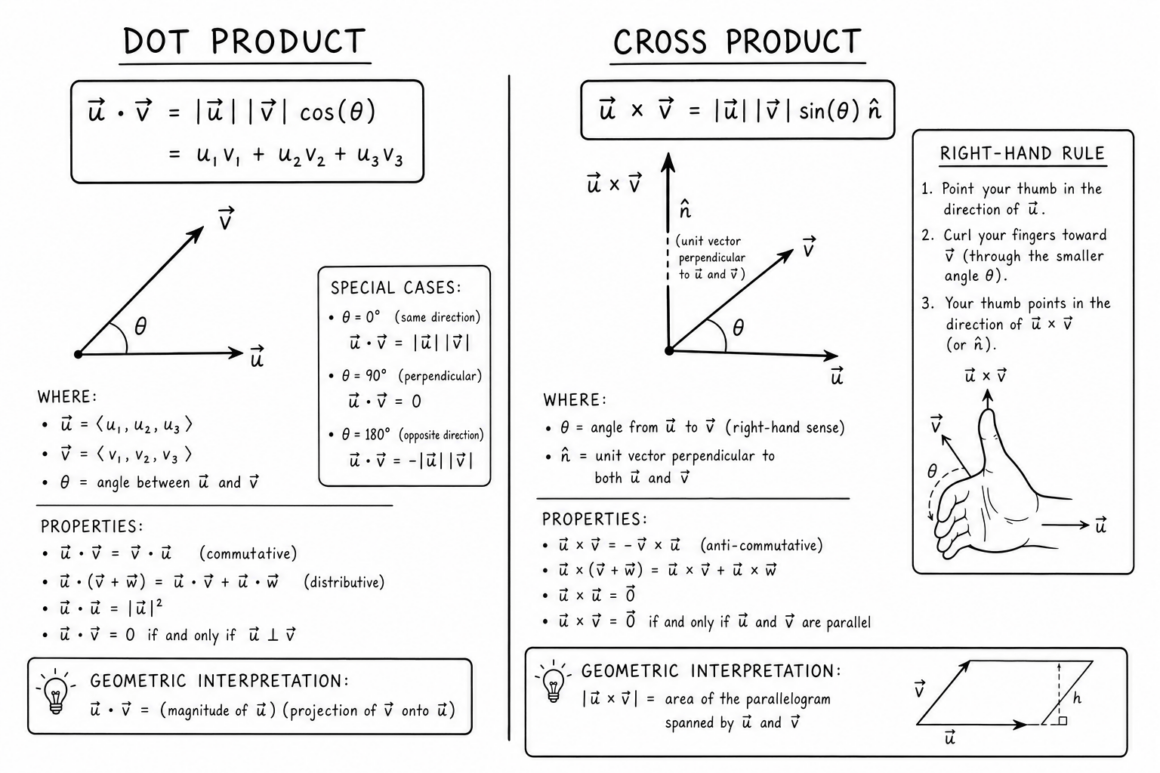
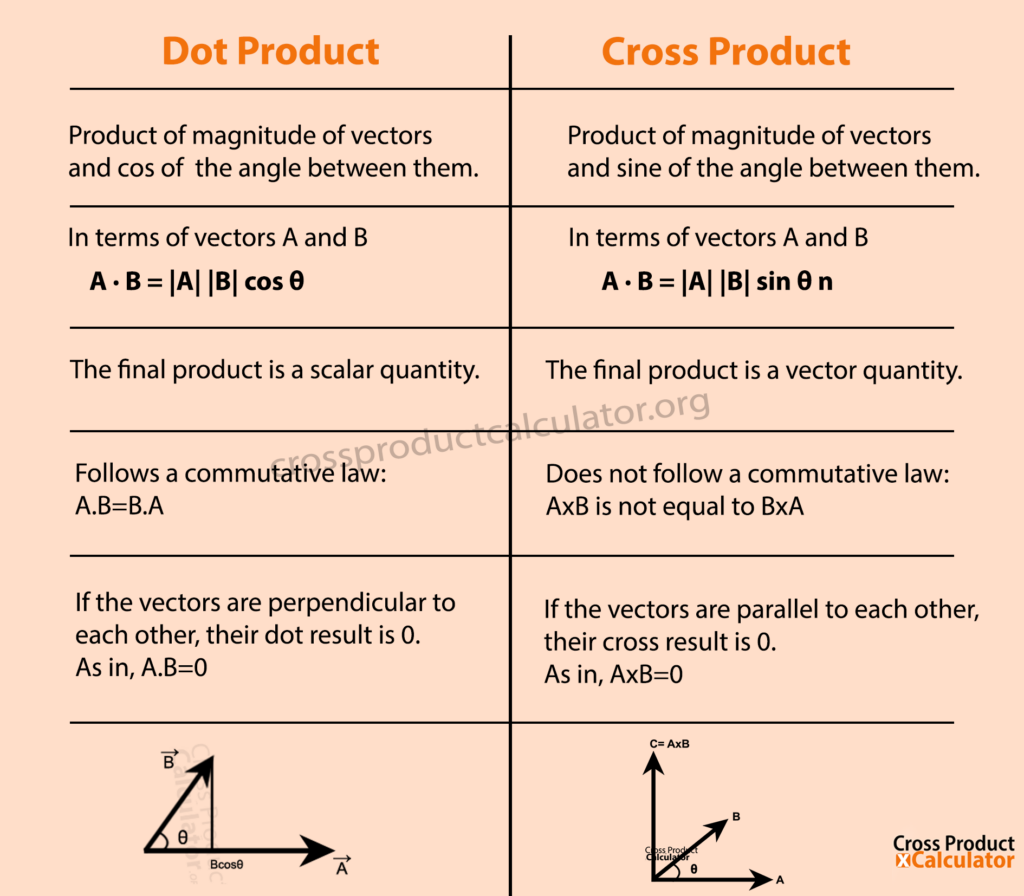
Vectors show up everywhere in graphics work, physics simulation, and collision detection, but most people only ever use them without thinking about what the math actually represents. The problem isn't that these operations are hard — it's that applying the wrong one gives you an answer that looks correct but is completely useless for whatever you're trying to do. Let me start with the operation that most people mess up first. The dot product, sometimes called the scalar product, takes two vectors and returns a single number. Here's what that actually looks like in code: dot(a, b) = a.x * b.x + a.y * b.y + a.z * b.z
That's it. Four multiplications and three additions. The result tells you something about the relationship between the two vectors' directions. If the result is positive, the vectors are generally pointing the same way. If it's zero, they're perpendicular. If it's negative, they're pointing in opposite directions relative to each other. In a lighting calculation, for example, you'd dot the surface normal with the light direction. A negative result means the surface is facing away from the light and shouldn't receive diffuse illumination. The cross product does something entirely different. Instead of giving you a scalar, it produces a new vector that is perpendicular to both input vectors. The formula in 3D is: c.x = a.y * b.z - a.z * b.y
c.y = a.z * b.x - a.x * b.z c.z = a.x * b.y - a.y * b.x This is six multiplications and three subtractions. More expensive than the dot product, and the result is a vector with direction, not a magnitude.
Get the Full Details
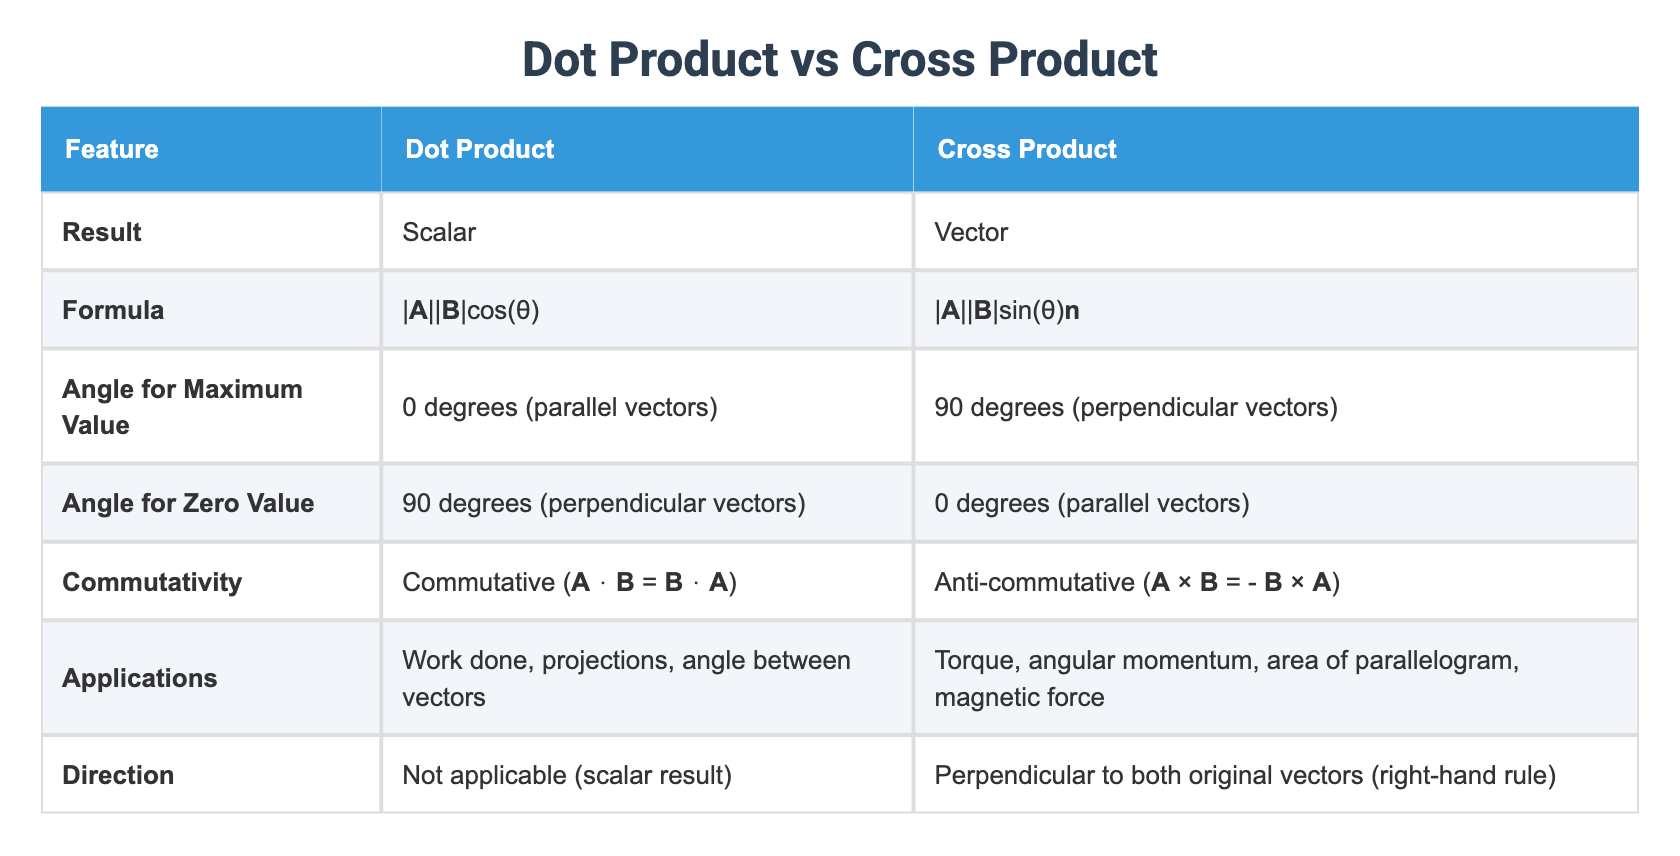
Here's what most tutorials don't emphasize enough: the order of your vectors in a cross product matters. Swap them and you get the exact opposite direction. a × b = -(b × a). I wasted a solid afternoon debugging a normals calculation where my cross product was producing flipped face normals, causing half my geometry to render back-face culled. The fix was simply swapping the operand order to match the winding of my vertex buffer. The magnitude of the cross product result equals the area of the parallelogram spanned by the two input vectors. When the vectors are parallel, the magnitude drops to zero. This is actually a useful property. I once used this behavior as a quick parallel-check in a pathfinding system to detect when a unit was moving directly toward or away from a target. Rather than doing a full angle calculation, I'd just check if the cross product magnitude was below a small threshold. Saved me from calling atan2 on every movement update, which mattered when I was processing thousands of agents simultaneously. A critical limitation with the cross product: it only exists in three dimensions and seven dimensions. If you're working in 2D space and think you can cross two 2D vectors, you can't. What people typically do in 2D is treat the vectors as if they have a z-component of zero, compute the cross product, and then read just the resulting z-component as a scalar. It works, but it's a hack that breaks down when you need to compose multiple cross operations together. In that case, using a scalar cross product formula — a.x * b.y - a.y * b.x — is cleaner and more explicit about what you're actually computing.
Another edge case that caught me once: when both input vectors to a cross product are nearly parallel, floating-point precision errors can make the resulting perpendicular vector unreliable. I encountered this in a physics simulation where two velocity vectors were almost aligned during a near-miss collision. The computed normal was garbage, and objects would tunnel through each other. The workaround was to add a fallback — if the cross product magnitude is below a epsilon threshold, use an arbitrary perpendicular vector instead. For 3D vectors, if the x-component is smallest, you can use (-y, x, 0) normalized as your fallback normal. It's not elegant, but it prevents the simulation from blowing up. The dot product has its own quirks. When both vectors aren't normalized, the result depends on both direction and length. This is fine when you explicitly want magnitude information baked in, like in a simple distance heuristic. But if you're comparing angles between pairs of vectors of different lengths, you need to normalize first or divide by the product of their magnitudes. I once had a ranking system that compared direction similarity between user preferences and item attributes, and it produced wildly wrong rankings because I forgot that a long vector dotted with a short one could produce the same scalar as two medium-length vectors at a different angle. Normalizing both sides fixed it immediately. There's also a performance consideration worth noting. The dot product is cheaper and more numerically stable than the cross product. In tight loops where you're checking hundreds or thousands of vector pairs per frame — occlusion culling, visibility tests, proximity checks — the dot product will burn fewer cycles and introduce less floating-point drift. If your algorithm can be reformulated to use dot products instead of cross products, it's usually worth doing. Gram-Schmidt orthogonalization and projection formulas are good examples where thoughtful reformulation can replace a cross product with a dot product plus a scalar multiplication.
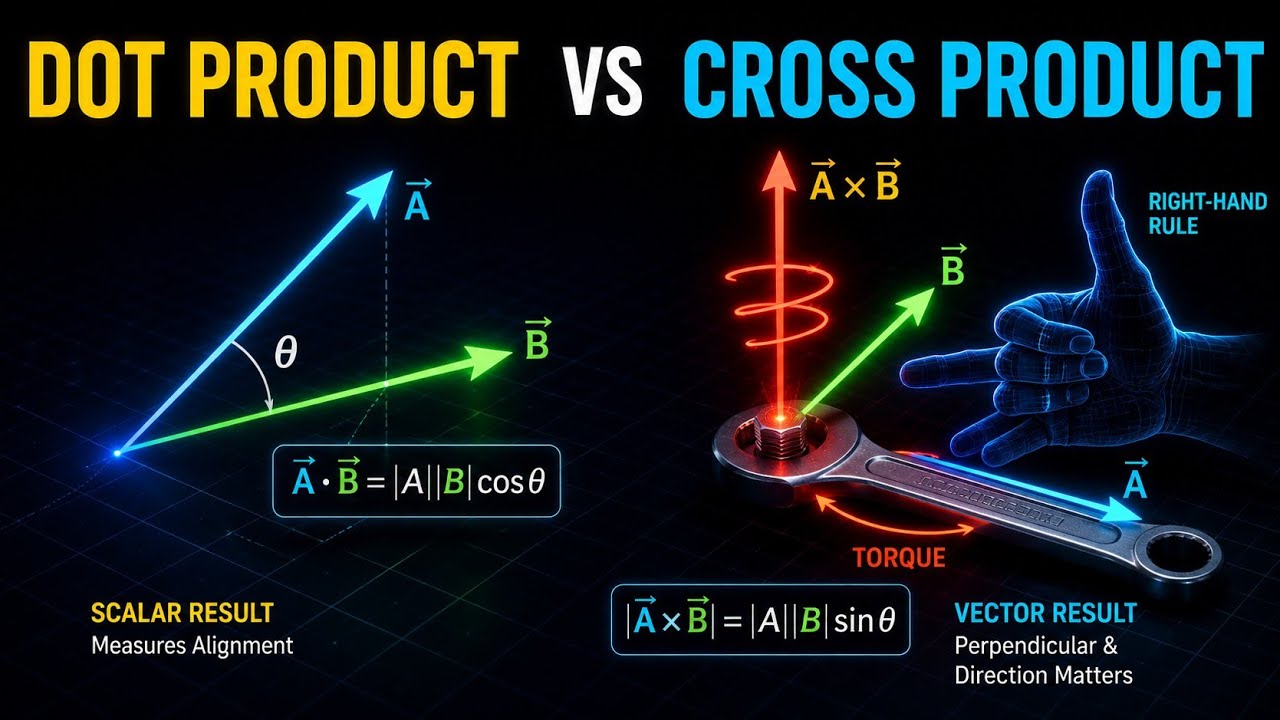
Neither operation commutes. The dot product is commutative — a · b = b · a — which is nice and sometimes convenient. The cross product is not commutative, and that non-commutativity is fundamental to what it represents. Angular momentum, torque, magnetic force — all of these depend on which vector comes first. Treating them as interchangeable is a category error that shows up in everything from game engine bugs to textbook mistakes. When I need both operations in the same pipeline, which is common in rendering code, I structure my vector math library so that the dot product function returns a float and the cross product returns a vector type. Mixing the return types by accident — passing a dot product result where a vector is expected — will cause compilation errors in strongly typed languages but silent semantic bugs in loosely typed ones. That's another reason to keep them as separate function calls rather than operators, even if it costs you a few extra keystrokes. If you're working in 2D exclusively, consider whether you even need a cross product at all. The scalar version I mentioned earlier — a.x * b.y - a.y * b.x — gives you a signed area value that tells you both the magnitude and the orientation (clockwise or counterclockwise) of the turn from one vector to another. It's faster than embedding 2D vectors in 3D space and crossing them, and the sign directly encodes information that would otherwise require an additional step to extract from a 3D cross product result.
Quick Reference
Use the dot product when you need to measure alignment, project one vector onto another, compute angles, or test whether surfaces face toward or away from a light source. Use the cross product when you need a perpendicular vector, want to compute surface normals from triangle edges, calculate torque or angular quantities, or determine the orientation relationship between two directions. Normalize your vectors before taking dot products if you only care about angular relationship and not magnitude. Use the scalar cross product in 2D instead of pretending you're doing 3D math. Watch for near-parallel edge cases in cross product inputs and handle them with a fallback. Check your operand order when computing normals — left-handed and right-handed coordinate systems will flip your result in opposite directions.