Getting a Handle on Modern Driver Assist Technology
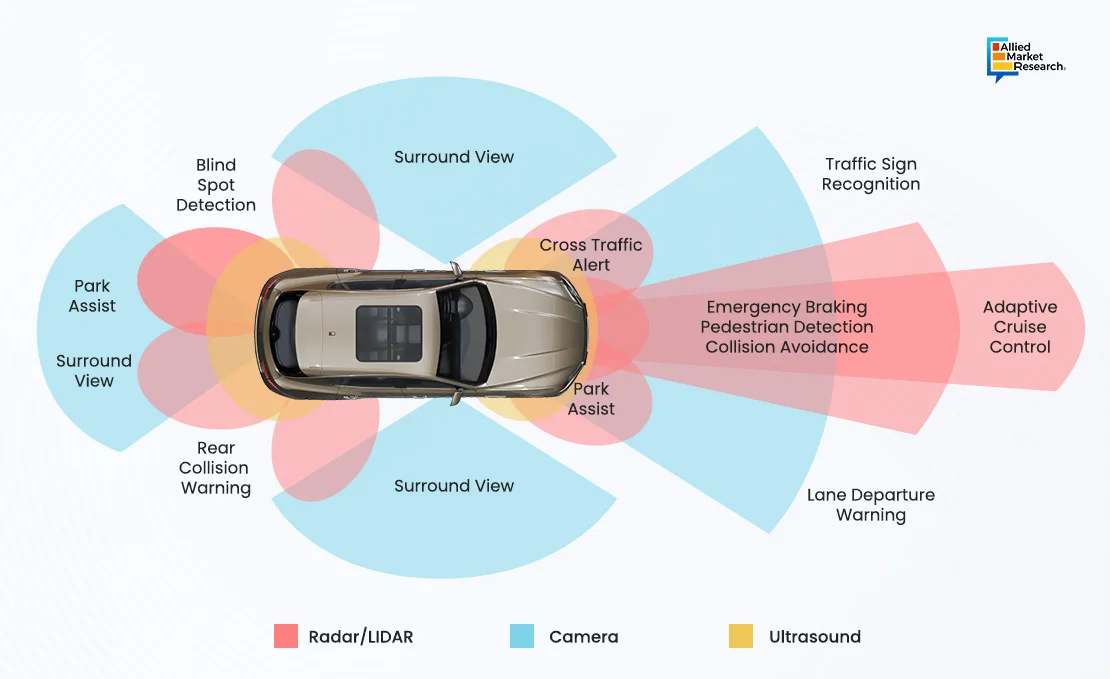
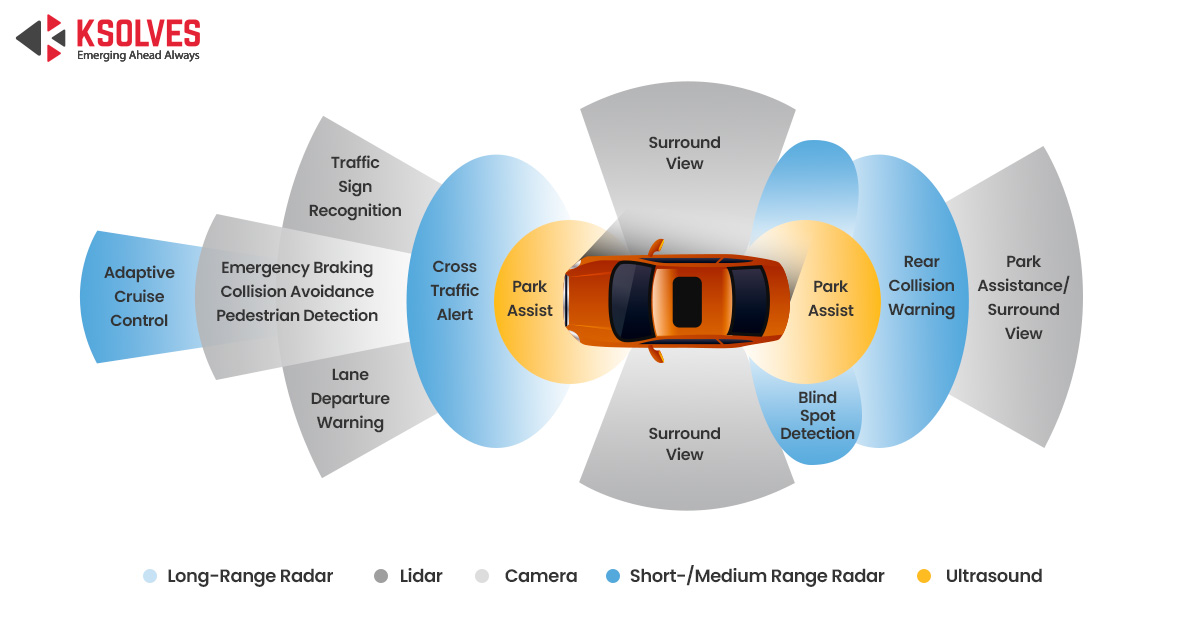
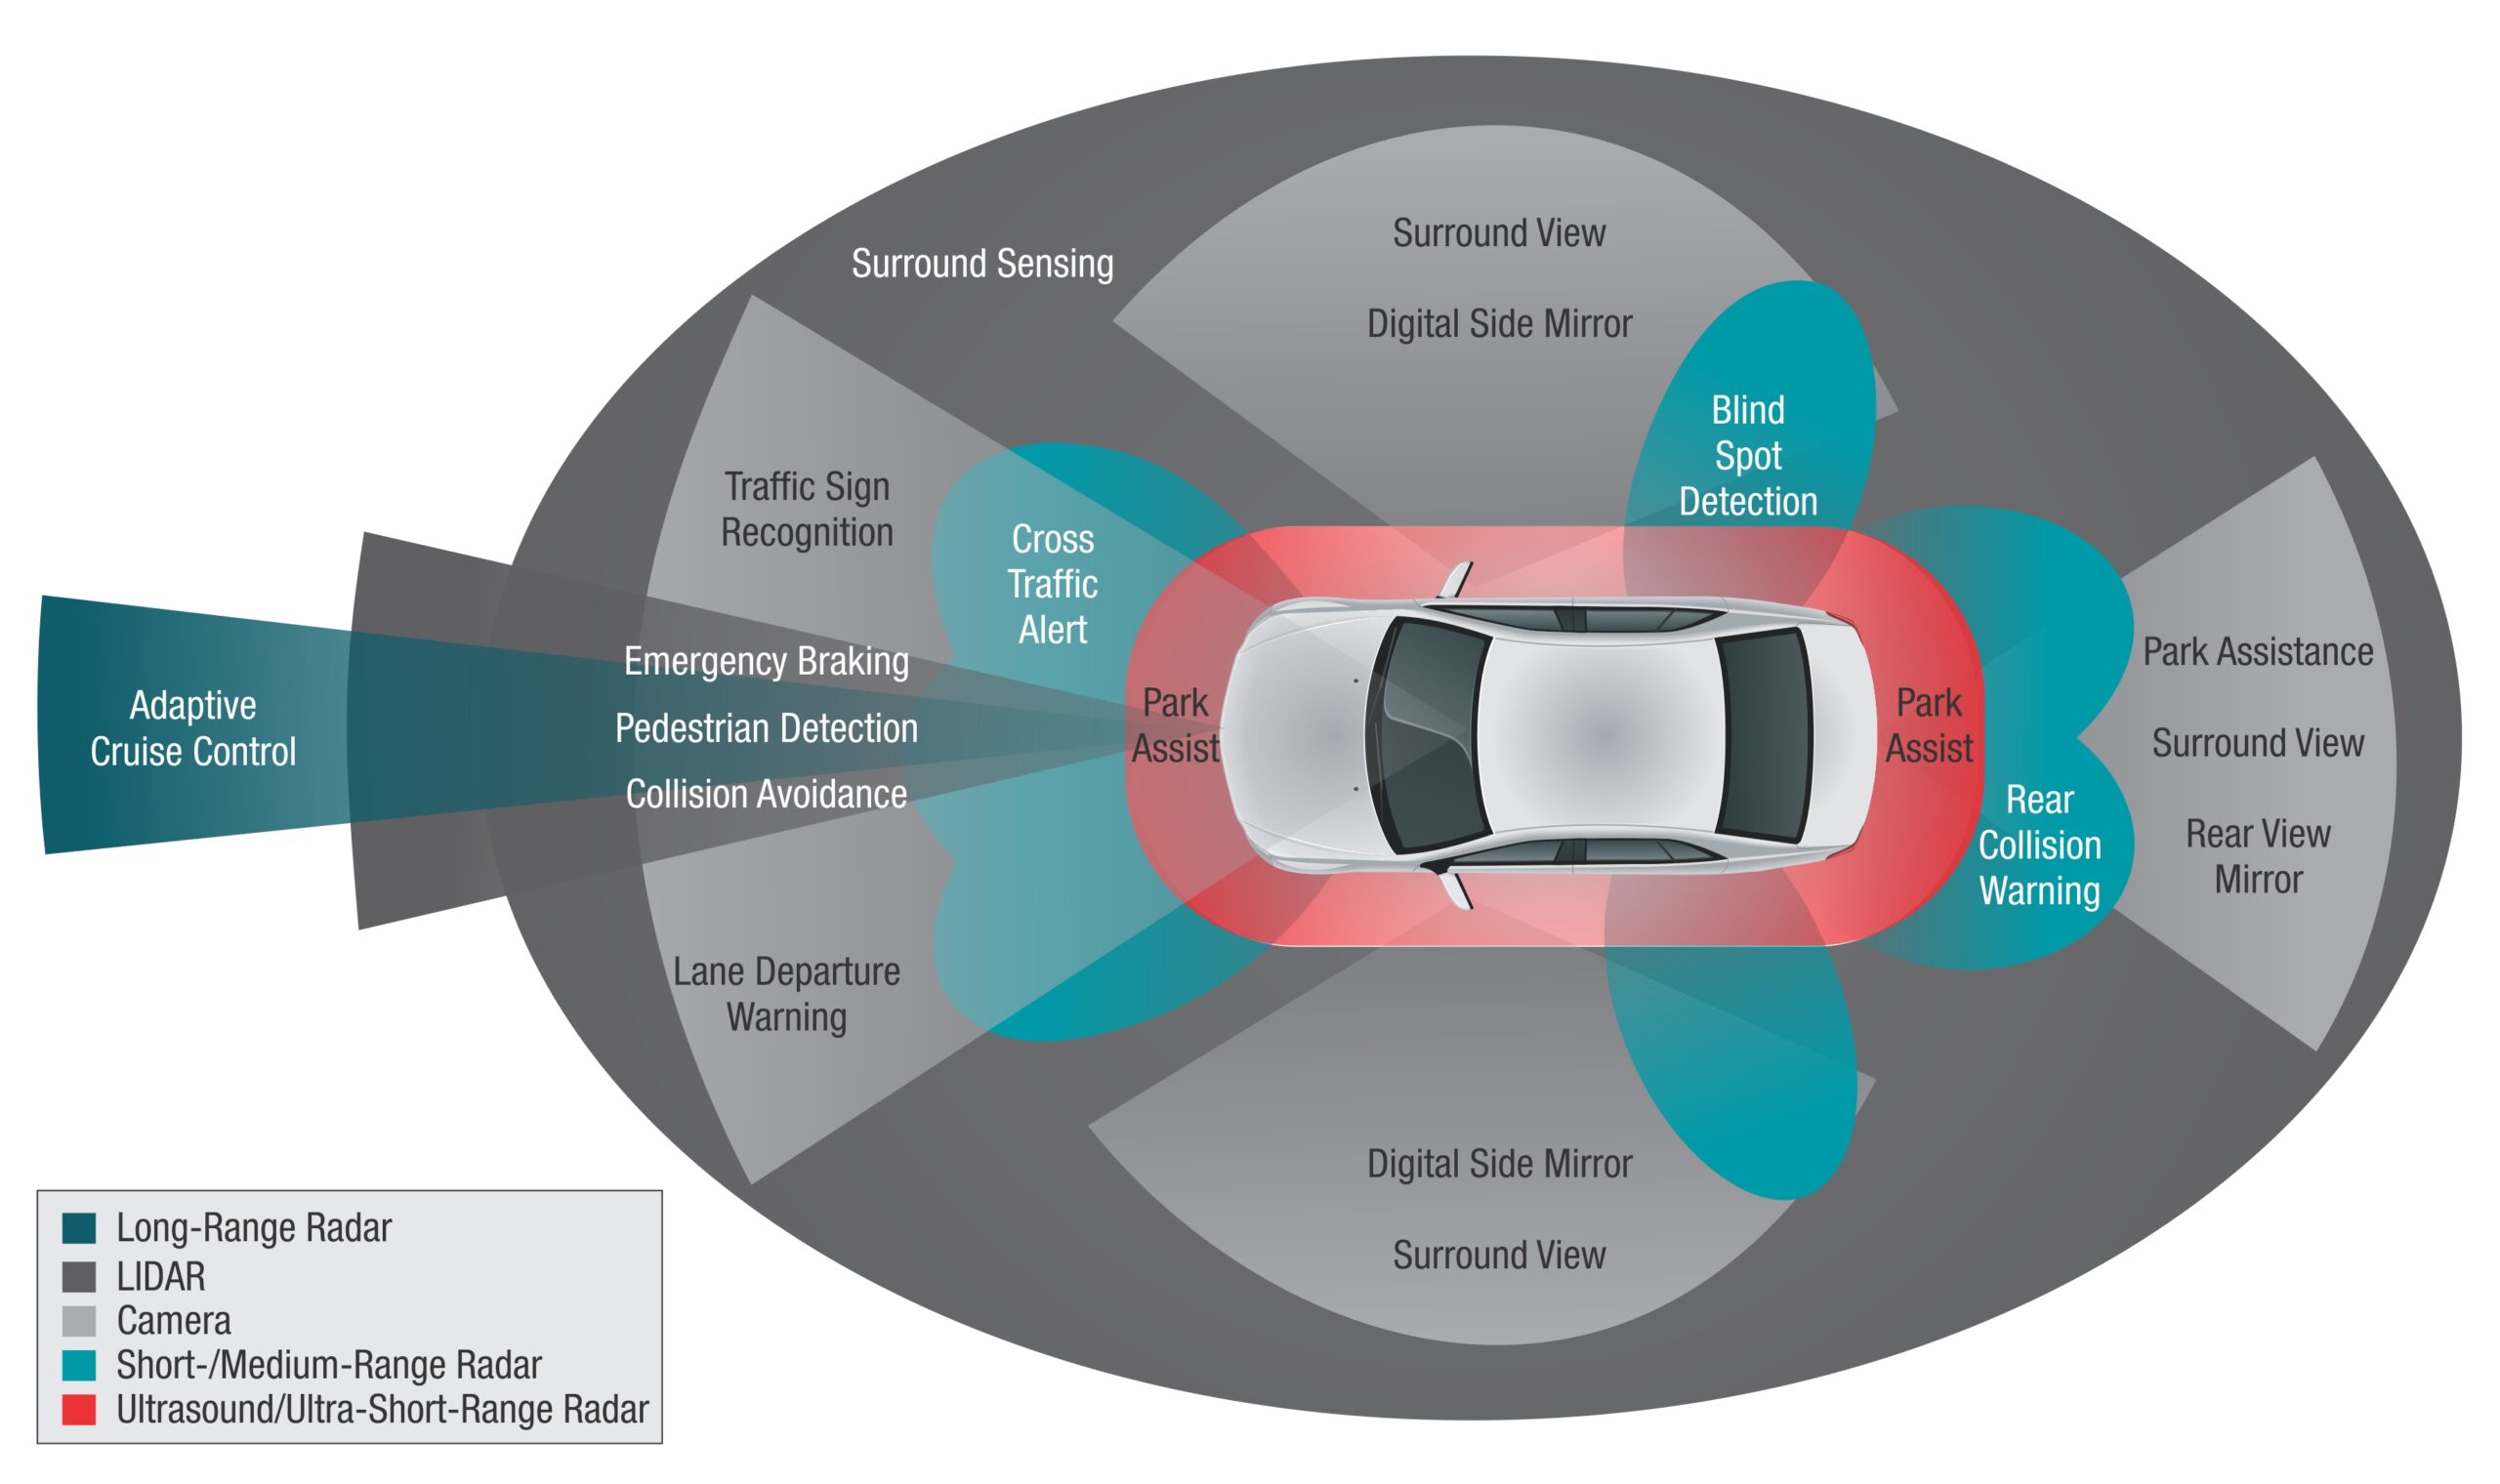
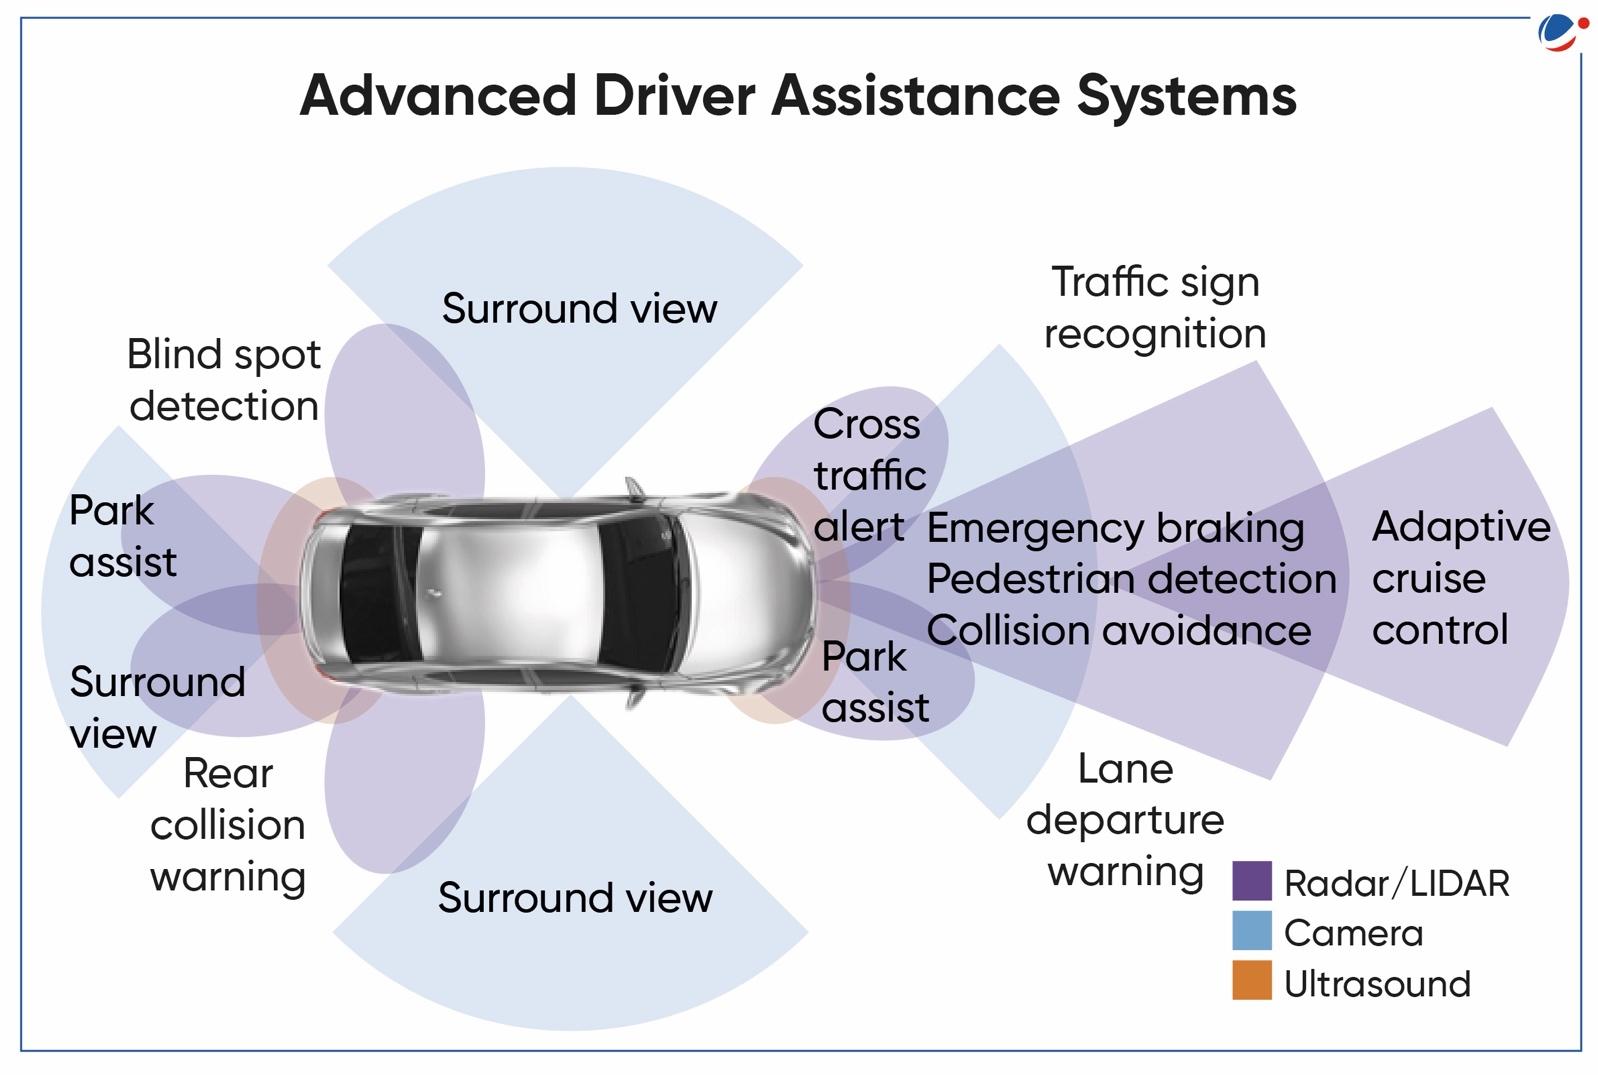
I spent about four years workingADAS validation before moving to a calibration role, so I have a reasonably clear picture of how these systems actually perform versus how they are advertised. The short version is that most consumer Driver Assist Technology on the market today relies on a combination of radar, cameras, and ultrasonic sensors fused together through software algorithms. That combination works well enough for highway cruising and parking assistance, but it breaks down in conditions nobody ever seems to prepare for. The term covers several different systems that operate at very different levels of complexity. You have basic lane keep assist, which uses a single forward-facing camera to detect lane markings and apply gentle steering corrections. Then there is adaptive cruise control, which uses millimeter-wave radar to maintain a set following distance. The more expensive packages combine both into what the industry calls Level 2 automation, meaning the system can handle both steering and acceleration/deceleration simultaneously under the right conditions. What most people do not realize is that these systems are not actually autonomous. They are driver supervision aids. The vehicle is always expecting you to be paying attention and ready to take over. That expectation matters more than anything else about how you should interact with the technology.
How These Systems Actually Work Under the Hood
The sensor fusion pipeline runs in real time, typically at around 10 to 20 hertz depending on the platform. Cameras feed image data into convolutional neural networks that identify lane lines, traffic signs, vehicles, and pedestrians. Radar provides distance and relative velocity measurements that cameras cannot reliably produce, especially in poor visibility. Ultrasonic sensors cover the low-speed perimeter for parking scenarios. The fusion layer combines all of this into a single environmental model that the control modules use to make steering and throttle decisions. The bottleneck in almost every production system is the camera. Radar handles rain and fog reasonably well. Ultrasonics are limited to about five meters and are mostly useless beyond that. Cameras struggle with glare, sudden lighting changes, heavy rain, and anything that obscures lane markings. This is the single biggest reliability gap in current Driver Assist Technology and it is why you will still see systems disengage on mountain roads with inconsistent lane painting or on highways during heavy downpours.
Setting Up Your System for Actual Usability
Most manufacturers preload these systems with conservative tuning by default, which means the lane keep assist tugs at the wheel aggressively and the adaptive cruise control brakes too hard when traffic slows. If you have access to a settings menu for your driver assist features, spend ten minutes adjusting them. Turn off the steering wheel tug sensitivity if your vehicle allows it. Set your following distance to at least three seconds rather than the default two. Disable lane departure warnings that flash the steering wheel vibration at highway speeds unless you actually want that distraction. The calibration procedure for cameras and radar sensors requires specialized equipment. If your vehicle has been in a front-end collision or the windshield was replaced, the forward-facing camera likely needs recalibration. Doing this yourself without the proper targeting fixtures and calibration software will result in the system misreading lane positions and triggering false disengagements. A proper shop with OEM-level equipment will spend about forty-five minutes on a full calibration and charge somewhere between two hundred and four hundred dollars depending on your region. It is not optional after any significant impact to the sensor mounting area.
Get the Full Details
A Real Problem I Encountered and How I Fixed It
I once spent three days debugging why a fleet test vehicle kept randomly disengaging its lane keep assist on a particular stretch of interstate. The system worked perfectly everywhere else. Rain, sun, shadows, curves, straightaways, no issues. That one four-mile segment caused consistent false positives. I initially suspected a camera calibration issue and ran the diagnostic procedure twice. Both came back nominal. The radar was fine too. The actual cause turned out to be a series of overhead highway signs with highly reflective metallic backing. When the sun hit them at a specific angle, the reflected light overwhelmed the camera sensor just long enough for the lane detection algorithm to lose track of the markings entirely. The system would briefly report no lane visible and disengage. This is not a hypothetical edge case. It happens regularly on routes with overhead gantries in western states during late afternoon driving. My workaround was straightforward. I adjusted the camera exposure parameters through the diagnostic tool, setting a faster shutter speed and reducing the dynamic range processing. This made the camera less susceptible to glare spikes at the cost of slightly reduced performance in tunnel entrances and exit lighting transitions. For our testing purposes the tradeoff was acceptable. If you are dealing with this in a personal vehicle, simply being aware of the issue helps. When you notice the lane assist icon flickering near overhead signs, keep your hands on the wheel and expect a disengagement. Do not fight it. The system will re-engage within a couple seconds once you pass under the structure.
Common Pitfalls That People Keep Making
The biggest mistake owners make is assuming that because the system activates, it is safe to disengage mentally. Lane keep assist will work correctly maybe ninety percent of the time in good conditions. That leaves ten percent of scenarios where it will either do nothing or do something dangerous. A faded lane line, a construction zone with temporary yellow tape instead of paint, a deer on the shoulder, a police officer directing traffic with hand signals. The system does not recognize any of these reliably. You need to be monitoring the road constantly regardless of what the dashboard tells you. Another frequent error is using adaptive cruise control in stop-and-go traffic without paying attention to the lead vehicle's behavior. Some systems will brake for a stopped car ahead. Others will not, particularly if the vehicle was already stationary when your system engaged. Reading your owner's manual about the specific limitations of your system's radar is actually useful advice, not something to skip over.
When Driver Assist Technology Falls Completely Short
These systems are not designed for unpaved roads, unmapped construction zones, or intersections where traffic control devices are absent or nonstandard. If you are driving in an area where lane markings have been scraped off for road work, the lane assist will fail. If you enter a construction zone with temporary cones and signage, the adaptive cruise will not respond appropriately to the new geometry. If you are navigating a roundabout or an uncontrolled intersection, expect the system to disengage immediately. The honest assessment is that current Driver Assist Technology is competent for predictable highway driving in clear weather. It is a useful tool for reducing fatigue on long commutes. It is not a replacement for attentive driving and it never will be with the sensor suite available in consumer vehicles today. Anyone selling you otherwise is either misunderstanding the technology or intentionally misleading you. If you want to get the most out of your system, learn its limits through controlled practice in a safe environment like an empty parking lot or a quiet residential street. Test how it responds to gentle steering inputs. Observe how quickly it re-engages after you take over. Pay attention to what weather and lighting conditions cause disengagements in your specific vehicle. That practical knowledge is worth more than any marketing material you will encounter.