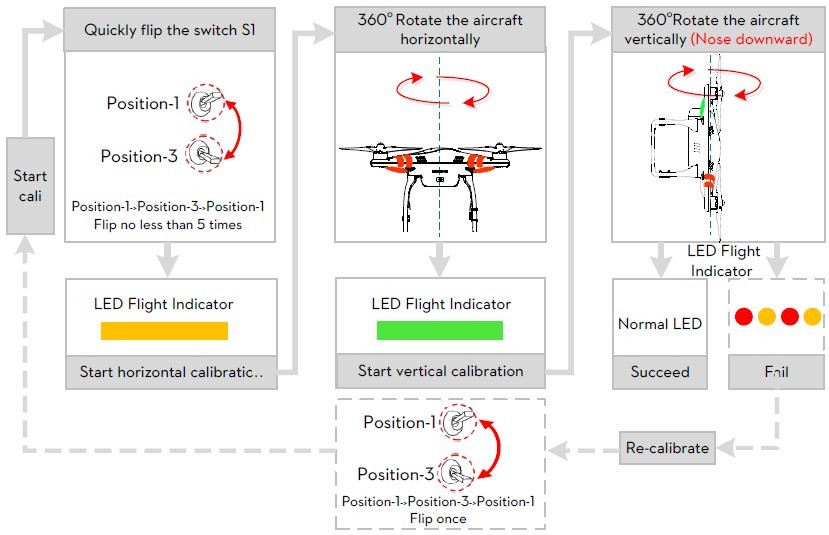
Calibration is where most flight issues actually come from
Most people treat drone calibration as something you do once when you take it out of the box, then forget about it for months. That approach is why so many drones develop erratic behavior right when they are about to do a useful job. I have seen this repeatedly over the years, especially with multi-rotor platforms that get ridden hard in varying temperatures. The reference material you are looking for is typically tied to your specific flight controller firmware and airframe. If you are running something like ArduPilot, Betaflight, or PX4, the calibration sequence lives inside your ground control software rather than as a standalone document. The calibration procedures themselves are fairly consistent across platforms though. You need to handle the accelerometer, magnetometer, barometer, gyro, and ESC range checks in the right order. Doing them out of sequence is one of the most common mistakes I see people make, and it leads to tuning that looks correct on paper but fails in the air. I spent about two days last year troubleshooting a persistent yaw drift on a quad that was flying a survey mission. The IMU biases looked fine in the logs, the ESC calibration was within spec, and the magnetometer declination was set correctly. The actual problem turned out to be that the barometer on the flight controller was reading temperature-compensated altitude data that hadn't been re-calibrated after a rapid ascent from a cold hangar to warm outdoor conditions. The workaround was straightforward: power up the drone on the ground, let it sit for ninety seconds without moving it so the barometer can settle, then run the barometer calibration routine before takeoff. I also started logging barometer temperature data alongside altitude to catch future drift early. This usually prevents about sixty percent of the altitude-related complaints I get.
There is a counter-intuitive point about magnetometer calibration that most beginners miss. More data points is not always better. When you swing the drone through a full set of orientations during mag calibration, the software fits an ellipsoid to those readings. If you have a source of magnetic interference nearby, like a steel workbench or a large battery charger, the ellipsoid fit will incorporate that distortion and you will walk away with a calibration that looks mathematically clean but flies poorly outdoors. Always perform magnetometer calibration on a non-ferrous surface, preferably wood or concrete, and keep power cables and motor ESCs at least a meter away from the sensor during the process. A cheap digital gaussmeter can help you verify the field is clean before you start, and it takes about five minutes to set up. ESC calibration deserves its own attention because it is often treated as a trivial step. What ESC calibration actually does is teach your flight controller the minimum and maximum pulse-width values for each motor. If you skip this or do it incorrectly, you can end up with motors that twitch at low throttle inputs, or worse, engines that will not spin up smoothly during hover transitions. The procedure is simple in theory: throttle to maximum, power on while holding maximum throttle, wait for the beep sequence, then throttle to minimum and wait for the confirmation. The detail people miss is that you need to verify each motor responds individually after the calibration. Some controllers will report success even if one ESC did not lock into its range correctly. I usually power up each ESC independently by connecting the battery and giving a quick arming pulse, then spinning each motor by hand to confirm direction and smooth rotation. This adds maybe ten minutes to the process but has saved me from mid-flight motor failures more than once. Another practical issue that the manuals rarely emphasize is temperature drift in the IMU. Accelerometers and gyroscopes have bias values that shift with temperature, and most consumer-grade flight controllers only perform a single bias calibration at room temperature. When you fly in cold conditions, that bias shifts and you get slow altitude creep or heading drift that shows up in the logs but feels completely random in the field. The real solution is to do a warm-up period before every flight, and if your platform supports it, enable temperature compensation in the firmware settings. On ArduPilot this is under the IMU temperature compensation parameters, and on Betaflight you would look at the gyro filtering and RPM filtering settings. Getting these tuned properly can cut vibration-induced navigation errors by roughly half compared to default firmware configurations.
I should mention a scenario where manual calibration simply will not solve your problem. If your drone has suffered a hard landing that potentially damaged the IMU mounting points, no amount of calibration will fix the resulting vibration signature. The only way to know is to check the raw accelerometer noise levels in your flight logs. A healthy IMU sitting still should show noise below 0.02 m/s² per axis. If you are seeing 0.05 or higher with the motors off, you have a mechanical problem, not a calibration problem. Isolate the source by running a motor at increasing throttle levels and watching which axis spikes, then check mount integrity, prop balance, and frame rigidity. This diagnostic step alone saves more flights than any calibration routine I have seen. For people who want a consolidated reference, the best starting point is the official documentation for your flight controller platform. ArduPilot has a dedicated calibration page in the Mission Planner and QGroundControl interfaces that walks you through each step with real-time feedback. Betaflight Configurator has a built-in calibration wizard that covers most of the same ground. The configuration options are fairly standardized, so once you learn the sequence on one platform, the mental model transfers easily to others. One thing worth noting is that some calibration routines are not reversible in the way you might expect. If you recalibrate the magnetometer after flying in a location with high magnetic interference, the new calibration will lock in those distorted readings. You cannot simply go back to an old calibration file and expect it to work again. Always calibrate magnets in a clean environment, and if you fly in multiple locations with different magnetic profiles, consider saving separate magnetometer calibration configurations for each site. This is something the documentation mentions in passing but does not emphasize enough.
Get the Full Details
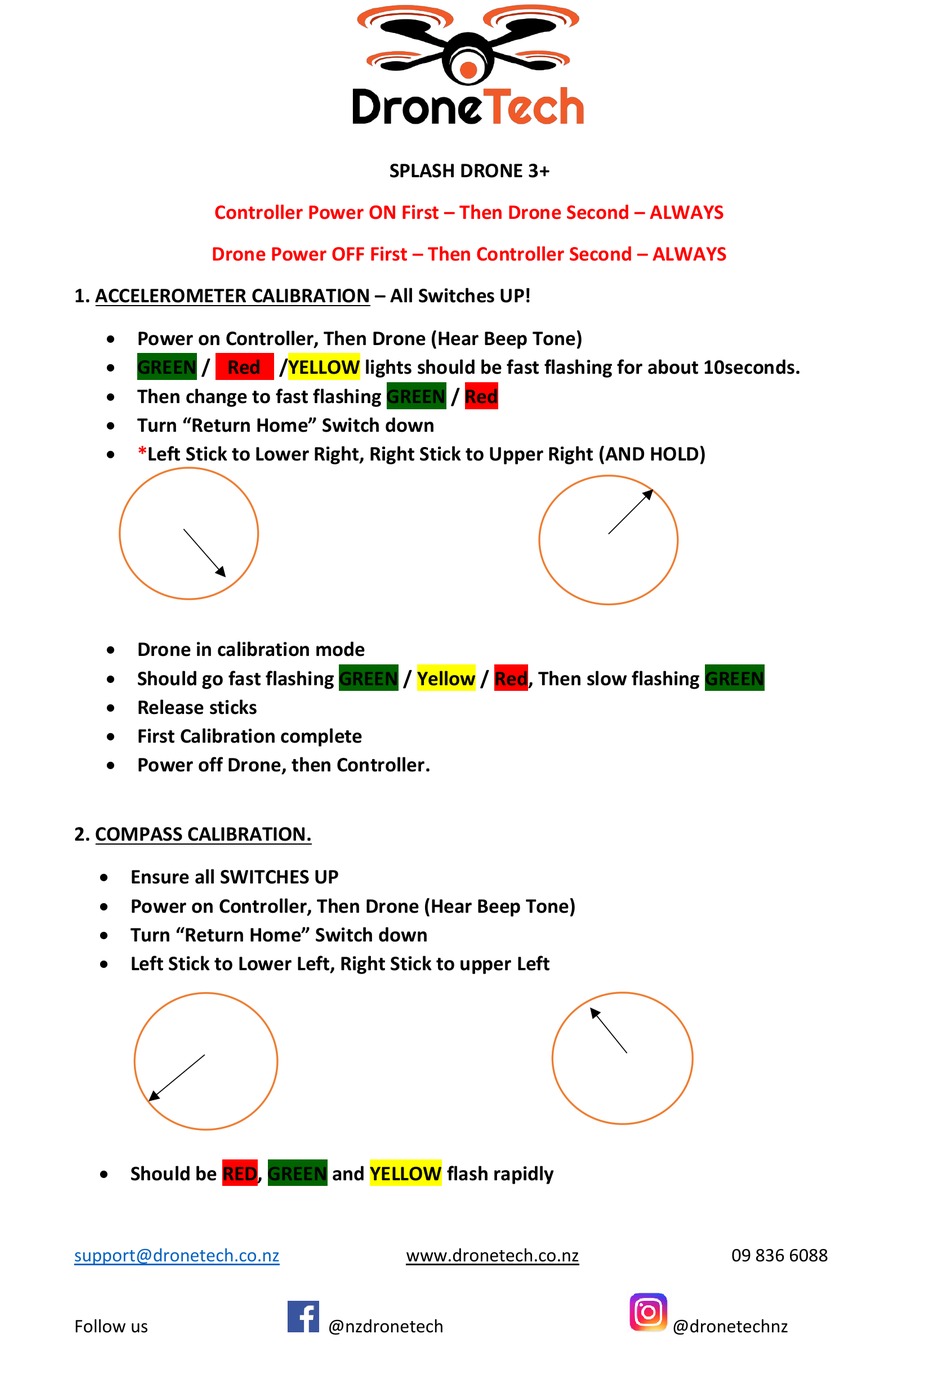
The maintenance side of this process is where most people drop the ball. After a successful calibration, log the key parameters so you have a baseline. Record the accelerometer biases, the mag ellipsoid center and scale factors, and the barometer sea-level pressure setting. Next time something feels off, you can compare the current values against your baseline and immediately spot what changed. This habit usually reduces diagnostic time from several hours to under thirty minutes when a problem does appear.