Getting Your Mesh to Not Tear Apart
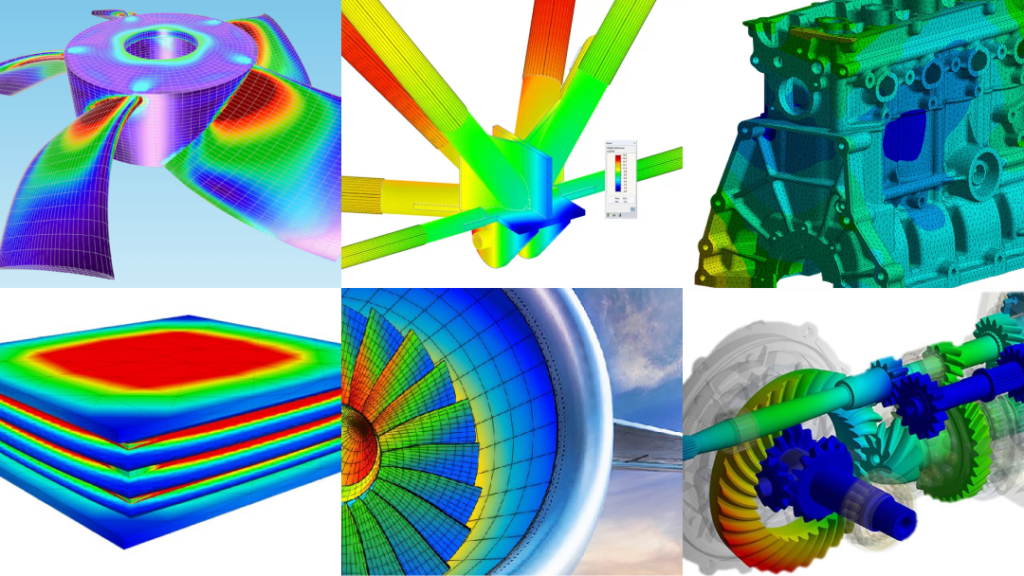
I spent three weeks debugging a thermal stress model last year where the simulation would converge perfectly on a coarse mesh but produce physically impossible temperature gradients once I refined it past a certain threshold. Turns out the element quality was degrading in a way that wasn't showing up in any standard diagnostic. That kind of problem is what makes Finite Element Analysis both essential and frustrating. At its core, element analysis — more commonly called finite element analysis or FEA — is a numerical method for solving partial differential equations over complex geometries. You break a continuous domain into discrete pieces called elements, approximate the solution within each piece using basis functions, then assemble everything into a system of algebraic equations you can actually solve on a computer. That's the whole thing. The art is in knowing which approximations will bite you later. The governing principle is straightforward enough. You take a physical problem — structural mechanics, heat transfer, fluid flow, electromagnetic fields — write it as a set of PDEs with boundary conditions, discretize the domain, and let linear algebra do the rest. Software packages like ANSYS, Abaqus, COMSOL, or open-source alternatives like CalculiX and FEniCS handle the heavy lifting. But the software doesn't know if your setup is garbage unless you check it yourself.
Setting Up a Real Simulation
Here's how I approach a new analysis from scratch, not the textbook version but the version that has kept my models from being wrong. Start with geometry cleanup. Most commercial pre-processors will import a CAD model with invisible gaps, overlapping faces, and tiny sliver elements that look fine at first glance but will destroy your solver. I run a volume check and a face normal consistency check before I even think about meshing. If the geometry has stitching errors, no mesh quality improvement will save you. Fixing a bad import took me about forty-five minutes on a turbine blade model once, and it was entirely preventable. Mesh generation is where most beginners lose control. The default settings in any package are designed for generic problems, not yours. I start with a global element size based on the smallest feature that matters physically — not the smallest geometric detail, the smallest feature that affects your answer. For a bracket under load, the bolt hole diameter matters. A scratch on the surface doesn't. Then I apply local refinements only where gradients are expected: near stress concentrators, thermal boundaries, contact interfaces. Blanket refinement wastes compute time and often makes things worse by introducing elements with poor aspect ratios.
I learned this the hard way on a pressure vessel model. I refined everything uniformly to get "better accuracy" and the solver started failing on numerical conditioning. The large dense matrix had an effective rank deficiency because the refinement created elements that were essentially copies of each other in the coarse regions. Dropping back to targeted refinement cut my solve time from eight hours to about forty minutes and actually improved the results.
Get the Full Details

Element Types and When to Use Them
Choosing the right element shape and order is not a trivial decision and it affects accuracy, convergence behavior, and computational cost in ways that aren't always obvious. Linear tetrahedra are the default for a reason — they mesh automatically on complex geometries. But they're stiff. A single linear tetrahedron under bending will significantly overestimate stiffness compared to a quadratic one. If you're doing a static structural analysis and your results show displacements that seem too small, check whether your elements are linear. Switching to quadratic tets or hex-dominant meshes usually corrects this, sometimes by a factor of two or three in displacement magnitude. Hexahedral elements are more efficient per degree of freedom but require structured meshing. I use them when the geometry allows — simple extrusions, blocks, cylinders. A well-meshed hex element can give the same accuracy as four or five tets with far fewer degrees of freedom. The tradeoff is time spent setting up the sweep and mapping parameters. For quick checks, tets are fine. For production models where I'm iterating on design changes, hexes pay for themselves.
Shell elements deserve special mention. When you're modeling thin structures — sheets, plates, casings — using solid elements through the thickness is wasteful and often inaccurate because through-thickness stresses require many elements to resolve properly. Shell elements capture bending and membrane behavior efficiently. The catch is that they assume the thickness is small compared to other dimensions and that transverse shear deformation is negligible, or you need a shear-corrected formulation. Using shells on a thick block just because it's easier to mesh is a common mistake that produces misleading results.
Verification and Validation
This is the part everyone skips and the part that separates useful analysis from expensive pretension. Mesh convergence study is non-negotiable. Run the same model with progressively finer meshes and watch your key output quantities — maximum stress, displacement at a point, natural frequency — stabilize. If they're still moving significantly at your finest mesh, you haven't converged. I typically look for changes below five percent between successive refinements before accepting a result. Sometimes you need twelve percent tolerance depending on what the analysis is for. The rule of thumb is that your engineering judgment should determine the tolerance, not the software's default behavior. Singularities are a real problem in element analysis and they don't behave the way beginners expect. A sharp re-entrant corner in a stress analysis will produce theoretically infinite stress as you refine the mesh. The stress keeps increasing with no convergence point. This isn't a bug — it's a mathematical consequence of the geometry. The workaround is either to add a realistic fillet radius (even a small one, like half the thickness) or to interpret the result as a trend indicator rather than an absolute value. I've seen engineers cite von Mises stress at a sharp corner as a failure criterion and then wonder why their physical part failed right at that spot regardless of mesh refinement. The singularity means the number is meaningless.

Boundary condition sanity checks save a lot of headaches. I always run a quick rigid body check — apply your constraints and loads, then verify that the model doesn't have unconstrained rigid body modes unless they're physically expected. A simply supported beam should have zero displacement at the support nodes but free rotation. If your displacement is nonzero at a pinned support, something is wrong with the constraint definition. This caught me once on a modal analysis where I'd accidentally applied a fixed constraint instead of a pin, and the first natural frequency was off by forty percent because the model was artificially stiffened.
Common Pitfalls I've Encountered
Material nonlinearity is where most models start going off the rails without obvious warning signs. Linear elastic analysis is simple and fast. Real materials yield, harden, creep, and relax. If you're analyzing a component that operates beyond its elastic limit, running a linear model will give you answers that look clean but are fundamentally wrong. I've seen yield predictions that were off by factors of three because the analyst didn't account for plastic hardening behavior. The fix is to use a proper constitutive model — elastic-plastic with isotropic or kinematic hardening depending on whether you're doing cyclic loading. For cyclic loading, kinematic hardening captures the Bauschinger effect which isotropic hardening completely misses. Contact definitions are another minefield. Two surfaces touching in reality need a contact pair in the model. But the default friction coefficient, the penalty stiffness, the contact detection algorithm — these all affect results significantly. I once ran a bolted joint simulation where changing the friction coefficient from 0.1 to 0.2 doubled the predicted clamp force transfer through the threads. The geometry and loads were identical. The only change was friction. Without experimental validation or sensitivity studies, you're guessing at these parameters. Dynamic analysis introduces a whole other layer of complexity. Explicit dynamics for impact events and implicit dynamics for vibration behave very differently. Using an implicit solver for a high-speed impact will either fail to converge or require time steps so small they're computationally impractical. Explicit solvers handle contact and large deformation natively but require careful mass scaling and energy balance checks. The artificial strain energy should be less than ten percent of the internal energy for the results to be trustworthy. I check this every run. It takes thirty seconds and has prevented me from publishing wrong results more than once.
When Element Analysis Fails Completely
There are problems where FEA simply cannot help you and you need to know this before you waste days setting up a model. Fracture mechanics at crack tips requires specialized elements — singular elements or extended finite element methods (XFEM). Standard elements will not capture the stress intensity factor correctly. If you're analyzing crack propagation, you need a dedicated fracture mechanics module or a specialized mesh strategy with radial refinement toward the tip. Generic FEA software won't save you here. Highly heterogeneous materials with length scales approaching the element size are problematic. If your microstructure has features smaller than a few elements, the continuum assumption breaks down. You'd need multiscale modeling or a different approach entirely. I encountered this with a composite material where the fiber diameter was on the order of the element size I needed for convergence. Switching to a homogenized equivalent model gave reasonable macroscopic results but completely missed the local damage initiation that was the actual failure mode. The lesson was to validate the homogenization assumption against a detailed micro-model before committing to the simpler approach.
Problems dominated by large deformations with material instability — things like metal forming, indentation, or tearing — can cause mesh distortion so severe that the elements invert and the solver crashes. Remeshing helps but introduces interpolation errors at each remeshing step. For these problems, smoothed particle hydrodynamics (SPH) or meshfree methods may be more appropriate, though they come with their own validation challenges.
Practical Workflow Recommendations
Keep your first model simple. A fully detailed assembly with ten contact pairs, nonlinear materials, and dynamic loading is not a good starting point. Start with a simplified geometry, linear elastic material, static loads, and bonded contacts. Verify that the simplified model gives sensible results — check reaction forces against equilibrium, verify displacements are in the right direction and order of magnitude, compare against hand calculations where possible. Then add complexity one thing at a time and observe how the results change. Document every parameter. I keep a simple text file alongside each model listing element type, mesh size, material properties, boundary conditions, contact settings, and solver controls. Six months later when someone asks why a result changed, having this record is invaluable. Without it, you're reconstructing assumptions from memory and memory is unreliable under pressure. Compare against analytical solutions whenever possible. A simply supported beam with a point load has a closed-form deflection equation. A pressurized cylinder has thin-wall stress formulas. If your FEA result is within ten percent of the analytical answer for a simple case, you have some confidence in the setup. If it's off by fifty percent, something is wrong before you even look at the complex case. I use these benchmarks as a checkout procedure for every new model type I set up.
The tools available range from commercial packages with full GUIs and support — ANSYS Mechanical, Abaqus, Simulia, COMSOL Multiphysics — to open-source options that require more command-line comfort. CalculiX is free and handles structural analysis well. FEniCS is powerful for custom formulations but has a steep learning curve. For most engineering applications, a commercial package with good documentation and vendor support is worth the license cost. The time saved on debugging configuration issues typically exceeds the annual subscription price. There's no substitute for understanding the physics behind what the mesh is computing. Element analysis is a tool, not a truth machine. The numbers it produces are only as reliable as the assumptions encoded in the model, and those assumptions are invisible to anyone who just clicks "solve" without checking convergence, reviewing element quality, or validating against known cases. The models that survive peer review are the ones where someone actually looked at the mesh, questioned the boundary conditions, and compared the results against something independent. That's the discipline that matters more than any software feature.