Picking the Right Language for Embedded Work
Most people learning embedded systems think the language choice is about preference. It isn't. It's about constraints you'll discover the hard way. Memory availability, real-time deadlines, toolchain maturity, and whether your employer already funds licenses for specific compilers will all decide for you before you get to vote. I've shipped firmware on Cortex-M cores with 32KB of RAM where every byte mattered, and I've debugged race conditions in FreeRTOS tasks that only appeared after the product was in the field for three months. The language you pick shapes both of those experiences in ways you won't appreciate until it's too late.
Understanding Embedded Systems Programming Languages
The term covers everything from bare-metal C to Rust on microcontrollers, from Ada on flight-critical systems to Python running on Raspberry Pi compute modules. The common thread is that these languages operate under tighter constraints than general-purpose software. You don't have gigabytes of heap. You don't get to recompile in seconds. A timing bug might not show up on the bench. C remains the default everywhere because it compiles predictably, tools exist for every architecture, and every embedded engineer alive knows it well enough to argue about it. That last part matters more than you'd think. Documentation, example code, community support, and the ability to find someone who can actually help when your system hangs at 3 AM all correlate strongly with C adoption.
What Actually Happens When You Write Code for a Microcontroller
Here's the part nobody mentions enough. The language is only 40% of the problem. The other 60% is understanding how that language maps to hardware you didn't design and can't fully control. In C, you deal with volatile keyword battles, memory-mapped registers, and the occasional compiler optimization that silently breaks your interrupt service routine. I spent two weeks tracking down a bug where GCC 11 started reordering memory operations across a peripheral access in an STM32 project. The fix wasn't elegant. I added explicit memory barriers using __DSB() and __ISB() instructions at the exact points where the hardware needed them to see writes in order. The alternative would've been to downgrade the compiler toolchain and hope nothing else broke, which is never a good strategy. Rust on embedded is different. The borrow checker catches entire classes of errors at compile time that C lets slide until something fails in production. But the compiler will reject code that would've been perfectly valid in C, and the learning curve is steeper than most tutorials suggest. I've seen engineers spend days fighting the type system on things that would take five minutes in C, then spend weeks debugging the equivalent C code later when memory safety issues surfaced unexpectedly.
Get the Full Details
Language Choice by Use Case
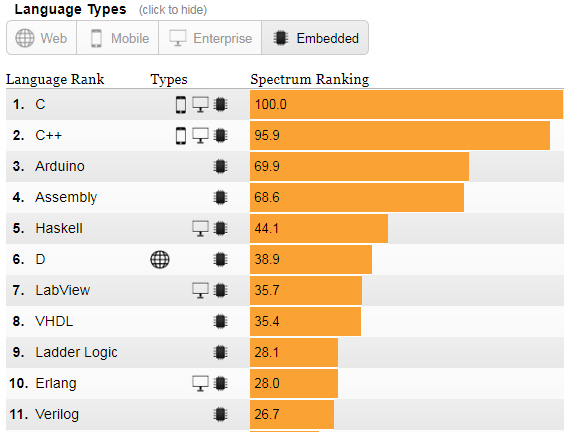
Real-time industrial control with strict determinism requirements: C with MISRA guidelines. You're writing for PLCs, automotive ECUs, medical devices. The code needs to be auditable and reviewable by multiple teams across years. Prototyping and development boards: Python, CircuitPython, MicroPython. These run on ESP32, RP2040, and similar devices. Perfect for getting something working fast. Not suitable for production unless you understand the runtime overhead and memory footprint deeply enough to justify it. New projects where memory safety matters and you have the team experience: Rust. The ecosystem around embedded-hal, embassy, and RTIC has matured significantly. But if your timeline is tight and your team doesn't know Rust yet, budget at least 40% more development time compared to C.
FPGA and SoC designs: Verilog, VHDL, and SystemVerilog are technically hardware description languages, but they're essential embedded languages too. Don't skip them just because your project doesn't involve FPGA work. Understanding how these map to silicon changes how you think about CPU-level optimization.
The Pitfalls Beginners Miss
Stack size estimation is one. Most embedded devices use fixed stack sizes configured at build time. If your C function calls are deeper than expected, or if an interrupt fires inside a deep call chain, the stack overflows silently. The program doesn't crash in a predictable way. It just starts corrupting data. I learned this from a project where the stack overflow only happened during a specific USB transfer sequence that nobody tested until field deployment. Another one: compiler optimization levels. -O0 is useful for debugging. -O2 or -O3 is what ships. But intermediate levels like -Os exist for a reason on resource-constrained devices. The optimization level changes how the compiler handles inline expansion, loop unrolling, and register allocation. Picking the wrong one without measuring the output binary size and execution time is reckless. Toolchain fragmentation is the third. ARM, RISC-V, Xtensa, AVR, DSPs. Each has different compiler behavior, different standard library implementations, different debugging capabilities. A codebase that builds and runs correctly on one toolchain might exhibit completely different behavior on another with the same source code.

A Practical Selection Checklist
Start with your hardware. What compiler and linker scripts are available? What does the vendor documentation recommend? STMicroelectronics, NXP, and Microchip all publish language-specific application notes that are worth reading before you commit to anything. Check your real-time requirements. Do you need sub-millisecond deterministic response? C with a proper RTOS like FreeRTOS or Zephyr gives you that. Python-based solutions on microcontrollers cannot guarantee this reliably. Consider your team. No amount of Rust's compile-time guarantees matter if nobody on the team can read the error messages quickly enough to ship on time. The best language is the one your team can write, read, and debug under pressure.
Measure before you commit. Write a small benchmark that exercises your actual workload patterns. Run it on the target hardware with the target compiler at the target optimization level. Don't guess about performance. Measure it. The ecosystem around Embedded Systems Programming Languages continues to evolve. New languages arrive with safety guarantees that previous generations couldn't offer. But the fundamental constraints of embedded development—limited resources, real-time requirements, and hardware-specific behavior—haven't changed. The language that serves you best is the one that lets you respect those constraints while still shipping functional code on schedule.