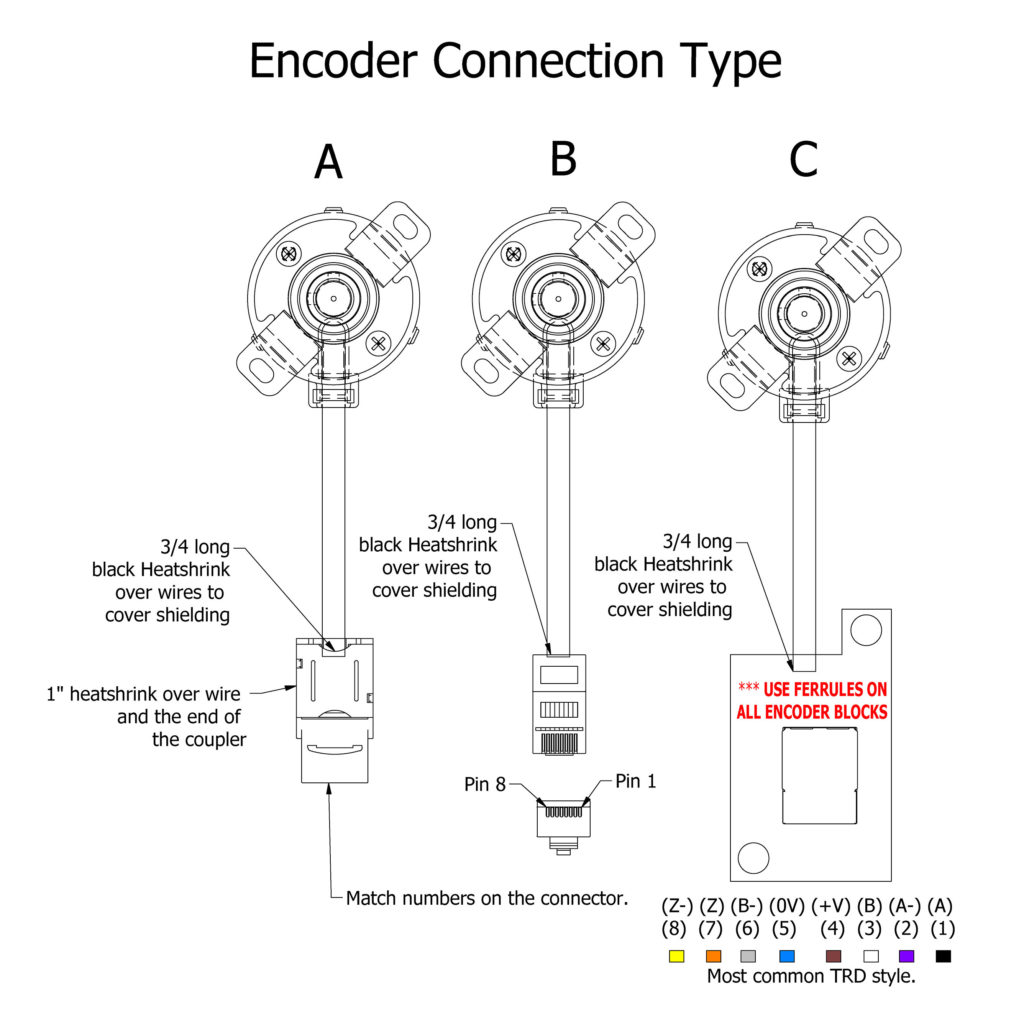
What You Actually Need to Know About Encoder Wiring
Most people looking at an encoder wiring diagram get stuck on the color codes. Forget the colors. Different manufacturers use different schemes. A B brown doesn't mean the same thing as an R brown on a different brand. What matters is understanding the output type and matching it to your PLC or motion controller's input circuitry. Get that wrong and you'll spend hours chasing ghosts before you ever plug anything in. An incremental encoder gives you pulses on channels A and B, plus an index pulse Z. An absolute encoder gives you a unique binary or Gray code word for every position. The wiring changes depending on which type you have. Single-ended outputs need a common ground. Differential outputs like RS422 don't and are far more immune to noise over long cable runs. This is one of those things where the Encoder Wiring Diagram you pull from the datasheet can be misleading if you don't understand what each pin actually represents electrically.Reading an Encoder Wiring Diagram Like a Technician
Start by identifying the supply voltage. Most industrial encoders run on 10 to 30 VDC, but some legacy models expect 5V TTL. Check the nameplate. Then look at the output configuration. Is it push-pull? Open collector? Line driver? This determines everything downstream. I once wired a SICK incremental encoder using what I thought was a standard NPN open-collector setup. The datasheet showed the A and B outputs going to ground through a transistor symbol. My PLC inputs were also NPN. Should have been fine. It wasn't. The encoder was actually configured for PNP sourcing internally despite what the diagram implied. Every channel looked correct on a multimeter but the controller received nothing. I ended up swapping the ground and positive leads on the power input and suddenly everything came alive. The workaround was realizing that some manufacturers flip the internal pull-up configuration and the diagram doesn't always call it out clearly. Always verify with a continuity test before trusting the schematic.Power pins: Usually labeled V+ and V- or 24V and 0V. Connect these first and confirm voltage with a multimeter before touching any signal wires. Channel A and B: These are your quadrature outputs. The phase relationship between them tells you direction. A leads B for one direction, B leads A for the other. Wire them to matching differential pairs if your controller supports it. Index or Z channel: One pulse per revolution. Used for reference positioning. Often overlooked but critical for homing routines.
Shield drain wire: Connect this to ground at the controller end only. Connecting it at both ends creates ground loops that introduce noise into your signal lines. I've seen entire production lines go intermittent because someone grounded the shield at the encoder cabinet and the PLC panel simultaneously. The ground potential difference between those two points was enough to couple into the signal wires and corrupt readings.
There's a counter-intuitive thing about cable length that nobody mentions in the documentation. The maximum distance isn't just about voltage drop. It's about capacitance. Twisted pair cables for differential outputs can run 100 meters or more. Single-ended cables? Maybe 30 meters before the signal degrades from capacitive loading. If you need longer runs with single-ended outputs, you're better off switching to a differential line receiver at the encoder end and running the longer cable as RS422. I've converted several setups this way. A $15 isolator module at the encoder solved what I originally thought was a faulty controller input. Another thing beginners miss: the difference between star and daisy-chain grounding in multi-encoder installations. If you're wiring three or four encoders back to one controller, don't daisy-chain the grounds. Each encoder should return to a single common ground point. Otherwise you're creating ground impedance paths where the switching current from one encoder's output stage flows through the shared ground and appears as noise on the other channels. This shows up as random pulse loss or direction flipping. Happened to me on a CNC retrofit where the X and Y axes would occasionally jump positions during rapid moves. Traced it to the grounded encoder shields all converging on a single terminal strip that had built up resistance over time.


