Approaching Statics and Dynamics Problem Sets the Right Way
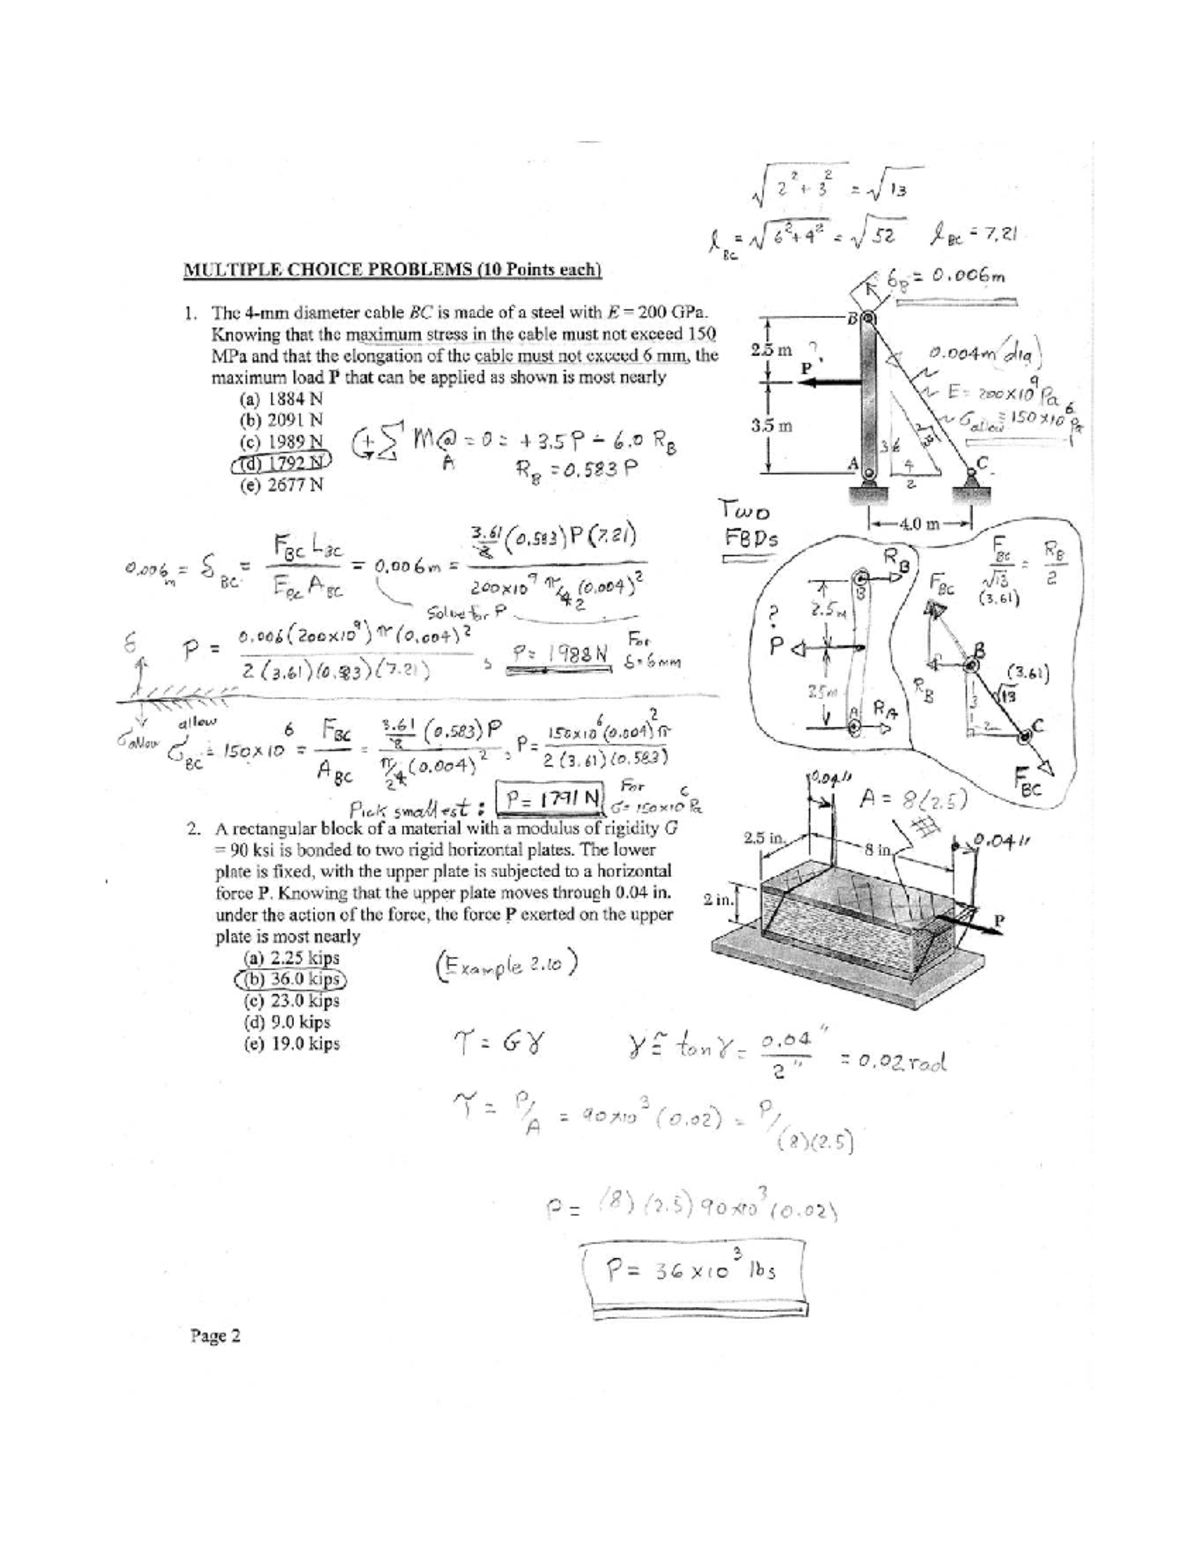
The biggest mistake I see students make is jumping straight into equations without drawing a proper free body diagram. It sounds basic, but it accounts for roughly half of the errors on exams. You can have the correct formula memorized and still get the wrong answer if your FBD has a force pointing the wrong way or a moment arm that doesn't match the actual geometry. When I was tutoring undergrads, I made everyone spend at least five minutes just sketching forces before they were allowed to write a single equation. It actually slowed them down initially but cut their total solve time in half once they got used to it. Here's how I break down a typical rigid body equilibrium problem. First, isolate the body you're analyzing. Draw every external force acting on it—weights, normal forces, friction, tension, applied loads. Label unknowns with letters like R_Ax and R_Ay instead of just question marks. Then pick your coordinate system. Most people default to horizontal and vertical, but if the problem involves an incline, rotating your axes by the angle of the slope makes the math significantly cleaner. After that, write your three equilibrium equations: sum of forces in x equals zero, sum of forces in y equals zero, and sum of moments equals zero. For 2D problems, that's three equations and hopefully three unknowns. If you have more unknowns than equations, the system is statically indeterminate and you need additional compatibility conditions from material deformation analysis. I spent a whole semester dealing with frames and machines problems that required disassembling the entire structure into individual members. One particular problem had a compound beam with a pin connection at an intermediate point, two distributed loads, and a cable supporting one end. The trick was realizing that the pin at the middle could transmit both horizontal and vertical forces but not moment. I solved it by first finding the reactions at the support using the whole structure as my free body, then cutting through the pin and analyzing each segment separately. Taking moments about the pin location eliminated those unknown reaction components and gave me the cable tension directly. Without that realization, I would have been writing substitution chains for twenty minutes trying to solve five equations at once.
For dynamics problems involving particles, Newton's second law is your starting point. But here's something most textbooks don't emphasize enough: work-energy methods and impulse-momentum methods are often faster than force-acceleration approaches, and sometimes they're the only practical option. When a problem gives you displacements and asks for velocity, or forces acting over a time interval and asks for final velocity, energy and momentum conservation bypass the acceleration calculation entirely. Conservation of energy only works when all forces are conservative, so you have to check for friction or other dissipative forces first. If friction is present, you include it as a negative work term rather than trying to find the deceleration and use kinematics. Impulse-momentum becomes essential in impact problems where the contact time is very short and the forces are enormous but unknown. You can't integrate F equals ma over the collision because you don't have a function for the contact force. But if you know the coefficient of restitution and the pre-impact velocities, you can solve for post-impact velocities using only momentum conservation and the restitution equation. I've seen students try to work these problems with Newton's second law and just give up because the force function was impossible to determine. Rotating reference frames and relative motion are where things get genuinely tricky. When you're analyzing a particle moving along a rotating arm, the acceleration equation has five terms: the absolute acceleration of the moving frame's origin, angular acceleration cross radius, angular velocity cross angular velocity cross radius, the relative acceleration, and twice the angular velocity cross the relative velocity. That last term is the Coriolis acceleration. Students consistently forget it. In a problem where a slider moves outward on a spinning rod, omitting Coriolis acceleration will give you an answer that's off by a significant margin. The direction matters too—Coriolis acceleration is always perpendicular to the relative velocity, rotated ninety degrees in the direction of the angular velocity.
Finite element modeling software like ANSYS or Abaqus handles many of these problems now, but there are serious limitations. Mesh quality dominates solution accuracy more than solver settings or material model selection. I've seen models fail because someone used linear triangular elements on a curved boundary where the geometry needed quadratic elements to approximate the surface properly. Stress concentrations at re-entrant corners also produce singularities that never converge no matter how fine you make the mesh. The stress values at those points are mathematically infinite in a perfect elastic model, which means the numbers the software spits out are meaningless. You have to either fillet the corner or extract stresses at a distance from the singularity and compare against yield criteria there. Another common trap in computational mechanics is boundary condition modeling. Applying a fixed support to an entire face of a component might look correct on paper, but in reality the connection is rarely perfectly rigid. Over-constraining a model artificially stiffens it and produces displacement results that are too low and stress distributions that don't match physical testing. I once reviewed a simulation where the deflection at load was fifty percent lower than what we measured on the test rig. The issue traced back to a boundary condition that restrained rotational degrees of freedom on a bolted flange that clearly rotates under load in the real assembly. Correcting that to a frictionless contact with separation capability brought the simulation into agreement within five percent. When working through problems manually, dimensional consistency is non-negotiable. I've found errors simply by checking that every term in an equation has the same units before plugging in numbers. If your force equation has a term in newtons and another in kilogram-meters per second squared, something is wrong because those are the same thing, but if one term came out in kilonewtons and you didn't convert it, your balance is off by a factor of a thousand. Writing units alongside every numerical value during the derivation process catches conversion mistakes immediately. It adds maybe thirty seconds to each problem but prevents the kind of error that makes you redo the entire solution.
Get the Full Details

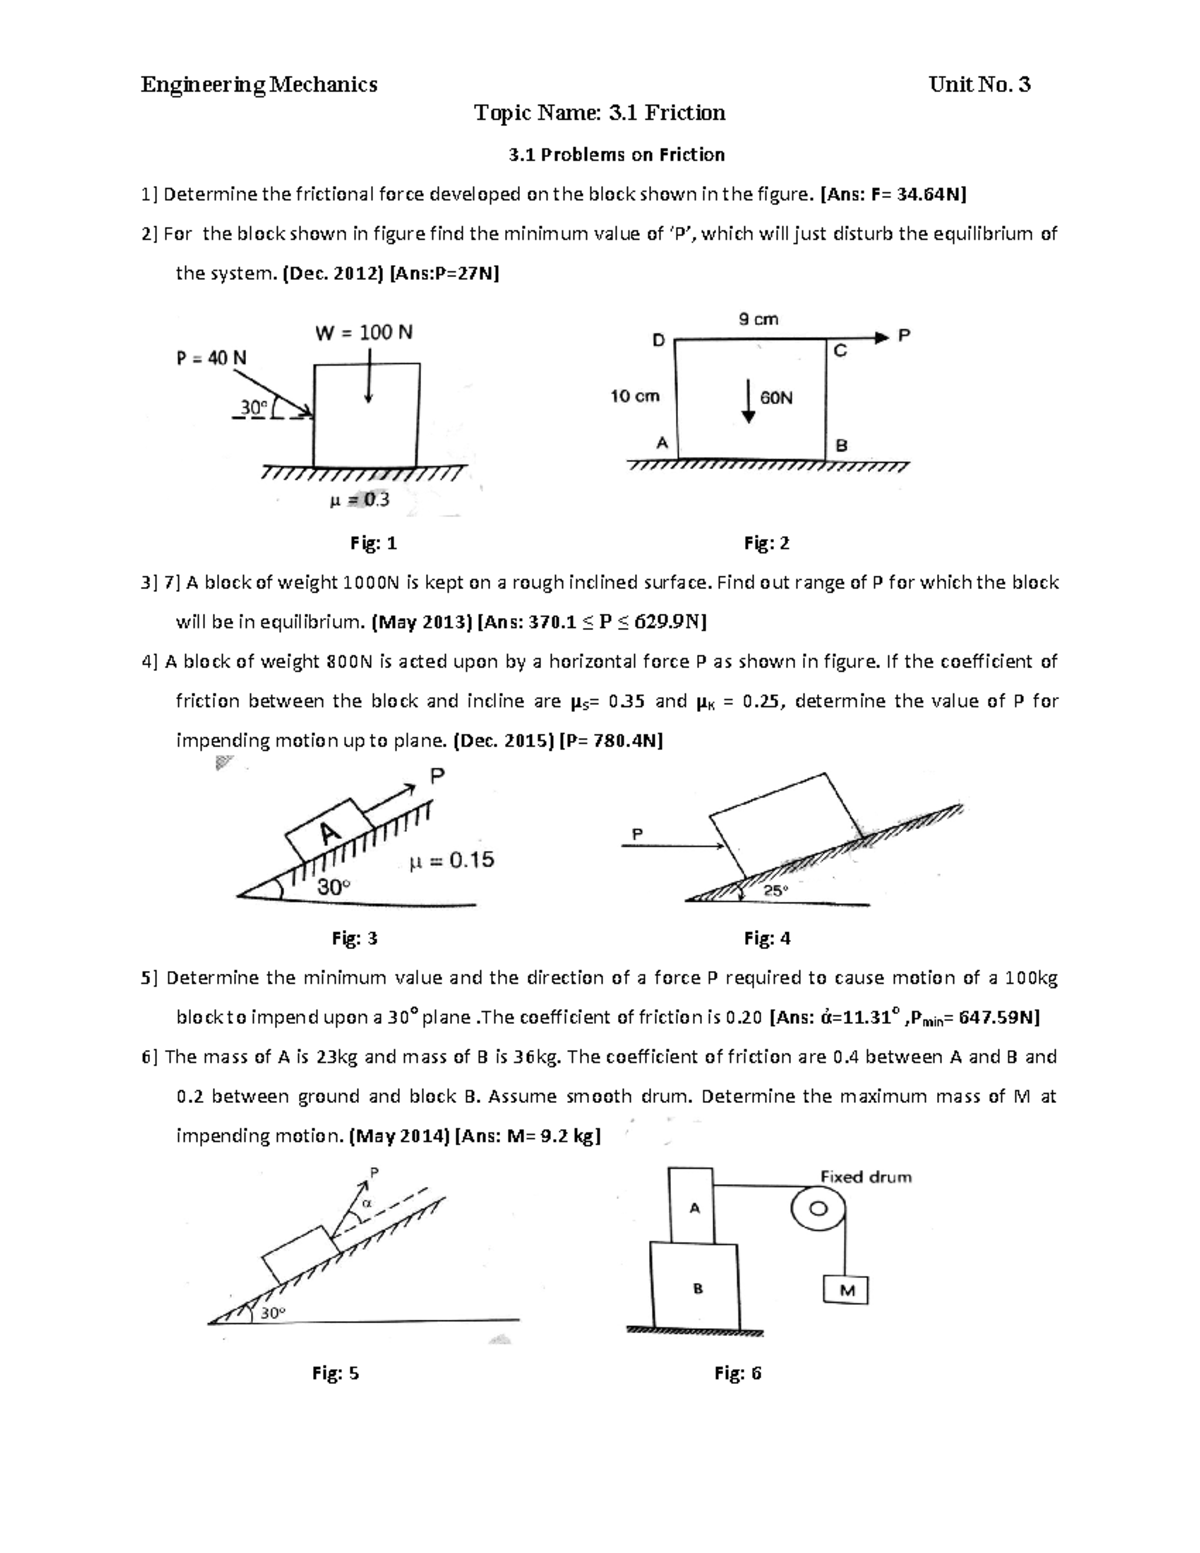
For beam deflection problems, the double integration method, moment-area method, and virtual work method all give the same answer but with different levels of effort depending on the loading. Macaulay's bracket notation for distributed loads that start partway along a beam is worth learning because it lets you write a single moment equation for the entire span instead of piecewise equations for each segment. singularity functions handle discontinuities in loading, shear, and moment automatically when you integrate them correctly. The key rule is that you can only integrate a singularity function if its exponent is greater than negative one. Truss analysis with the method of joints versus method of sections comes down to what you're looking for. Method of joints solves for every member force sequentially, which is useful when you need the complete force diagram. Method of sections cuts through three members and uses equilibrium equations to find just those forces directly, which is much faster when you only need a few specific member forces. The standard approach of solving joint by joint from a support through the entire truss becomes computationally expensive for large structures, especially when you only care about one member near the center. A single section cut gives you that answer in three equations instead of ten or fifteen. Friction problems often trip people up because of the transition between static and kinetic regimes. The maximum static friction force is mu_s times the normal force, but the actual static friction force is whatever is needed to prevent slipping, up to that maximum. Once slipping starts, friction drops to mu_k times the normal force, and mu_k is always less than or equal to mu_s. I had a belt drive problem where the belt was on the verge of slipping on the pulley, and the tension ratio was governed by the capstan equation with exponential dependence on the wrap angle and friction coefficient. Getting that relationship wrong by treating friction as a simple constant force rather than an exponential function of contact angle changed the entire solution.
Center of mass and centroid calculations for composite bodies are straightforward but tedious. The workaround is to treat cutouts and hollow regions as negative areas or volumes. Instead of integrating over a complex shape, decompose it into rectangles, triangles, and circles, assign positive or negative values based on whether the region is material or void, and sum the first moments. This approach also works for calculating moments of inertia, where you apply the parallel axis theorem to shift each component's centroidal inertia to the common reference axis before adding them together.
Resources for Practice
Engineering Mechanics Problems With Solutions collections are available through textbook companion websites and university course repositories. Hibbeler'sStatics and Dynamics problem sets are widely used, and his solution manuals show complete worked examples for most end-of-chapter problems. Meriam and Kraige's books have a different style that some instructors prefer because the problems tend to be more applied and less abstract. Beer and Johnston takes a vector-based approach early on, which can be helpful for students who are comfortable with vector operations. For free resources, MIT OpenCourseWare posts full problem sets with solutions for their mechanics courses. The University of Michigan and Stanford also have publicly available problem collections with detailed answers. YouTube channels like Jeff Hanson and Brian Johns walk through specific problem types step by step, which is useful when you're stuck on the methodology rather than the arithmetic. One thing no resource covers adequately is the gap between textbook problems and real engineering work. Textbook problems have clean numbers, idealized supports, and loading conditions that match standard cases. Real structures have connection stiffness, unintended eccentricities, dynamic amplification from operational vibrations, and material imperfections. Learning to recognize when a textbook assumption breaks down in practice takes exposure to actual engineering documentation—shop drawings, calculation reports, and failure investigations. Reading through peer-reviewed case studies of structural failures shows you how small modeling assumptions in the original analysis can lead to significant deviations from predicted behavior under actual service conditions.
Time management during exams is a separate skill from knowing the mechanics. A typical problem set might ask you to solve three to four problems in two hours. That gives you roughly thirty to forty minutes per problem including setup, derivation, and verification. If you spend more than fifteen minutes on a single problem without making progress, you're likely missing a simplification or approaching it from the wrong angle. Move on, come back later. The problems worth the most points are usually the ones you identify quickly and execute cleanly, not the ones you struggle with for twenty minutes.