The annoying bit about planes nobody warns you about
You pick three points, you find two vectors, you cross them, you're done. That's the textbook version. The version that actually works in practice is messier than that, especially when your points are sloppy or your numbers aren't clean integers.
The standard form of a plane equation looks like this:
ax + by + cz = d
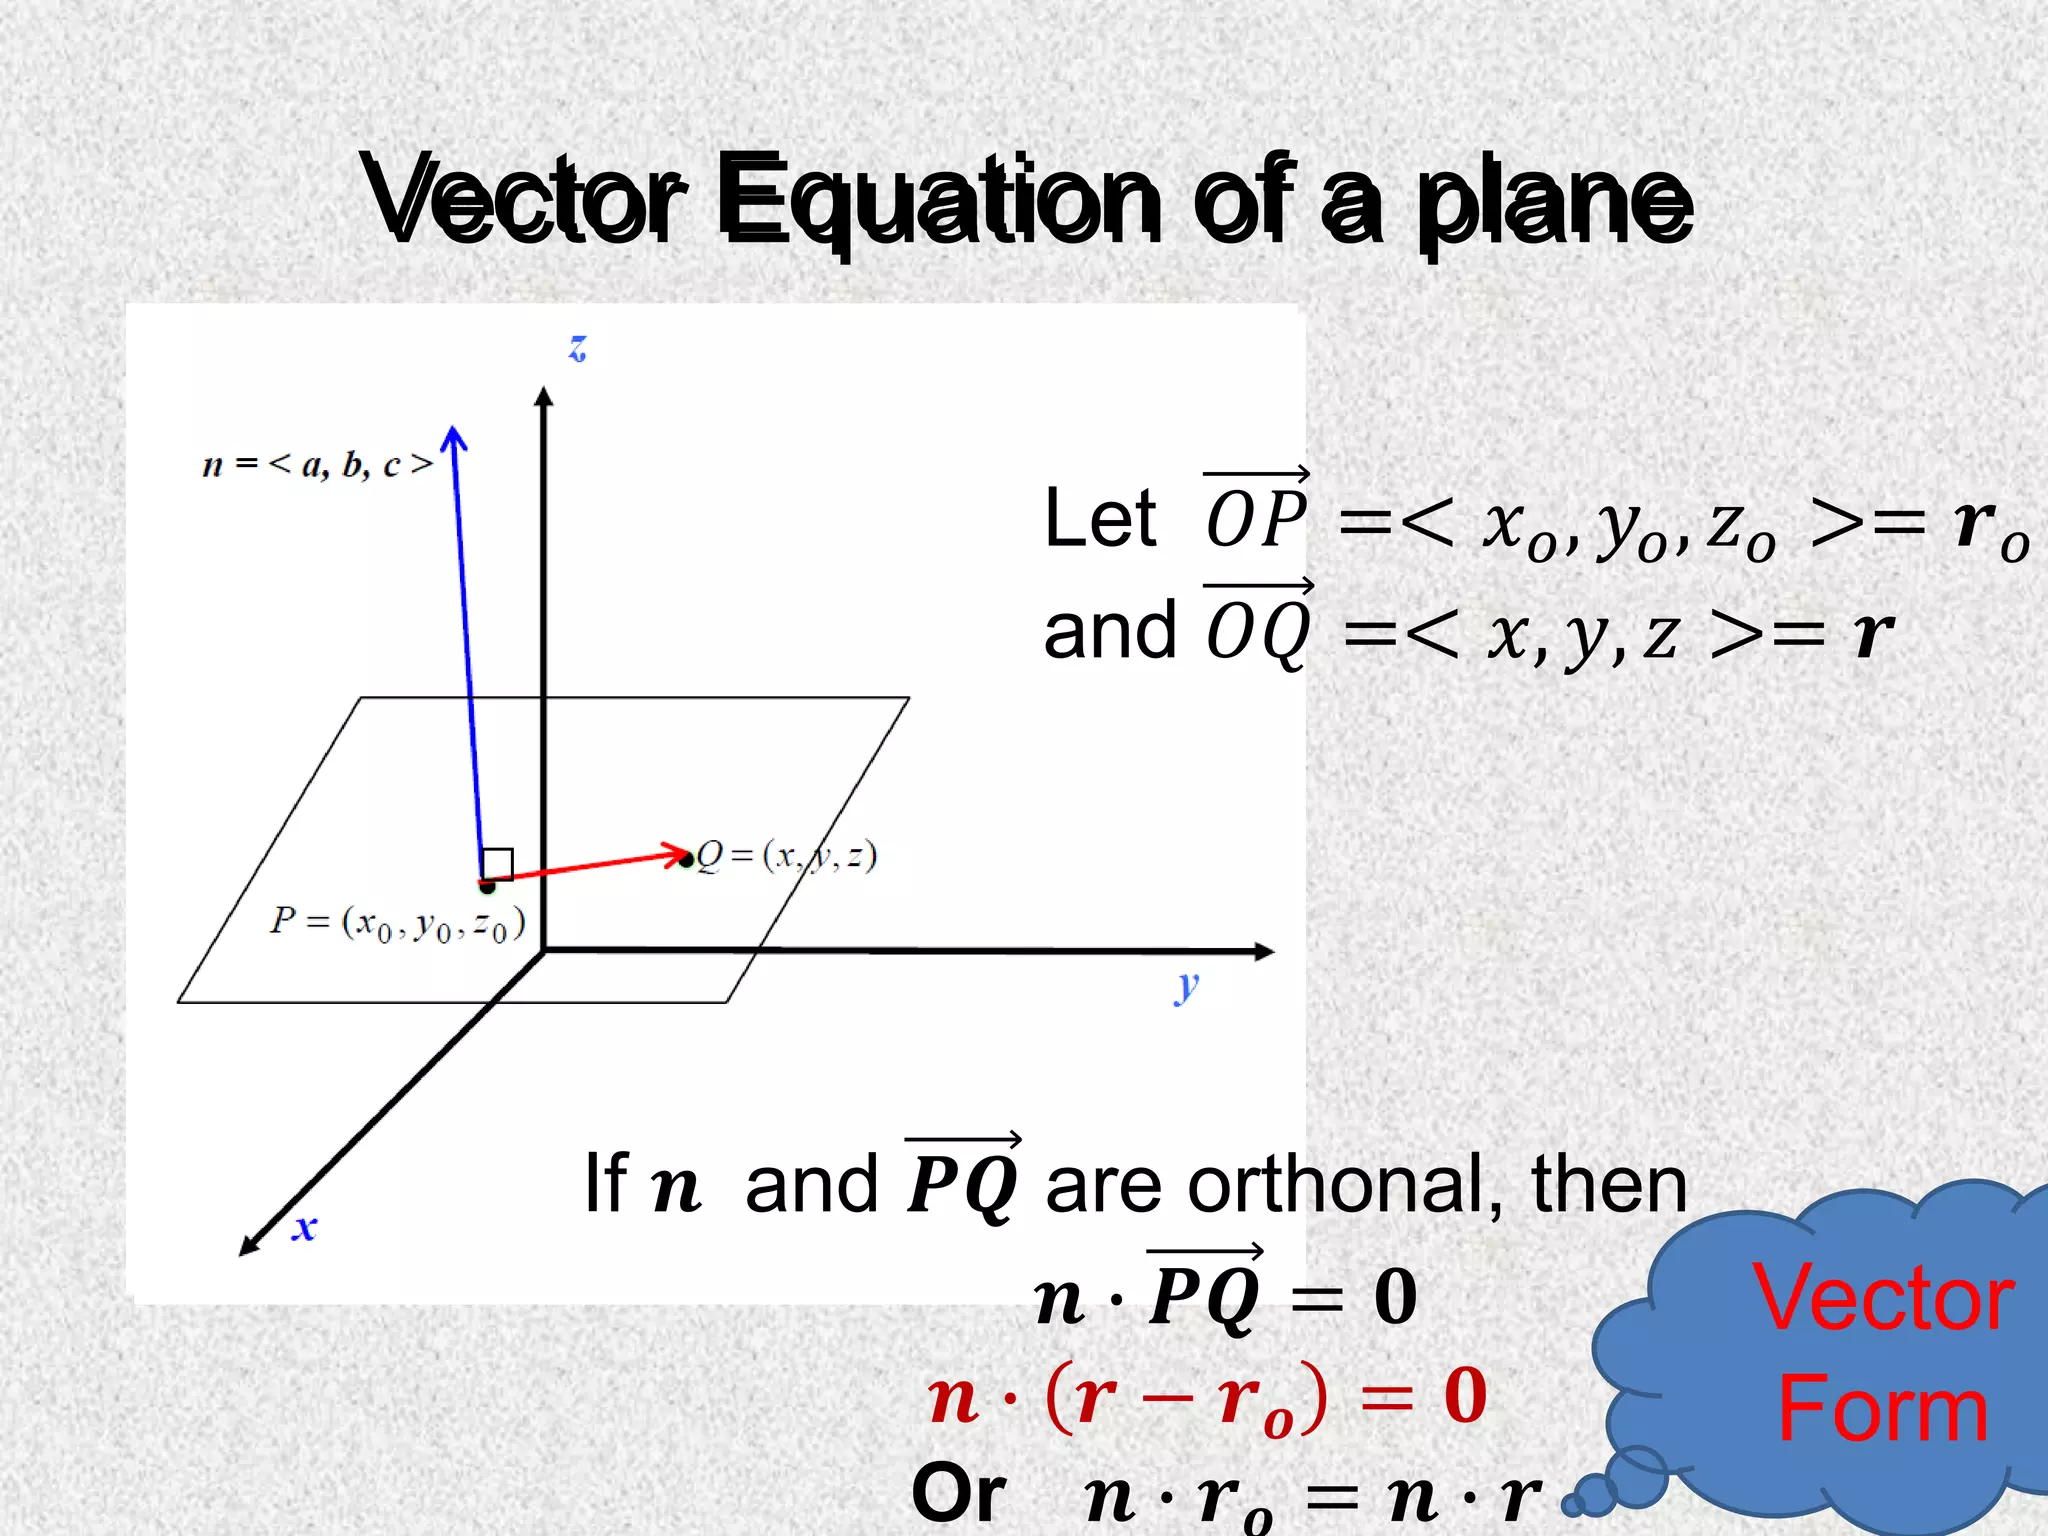
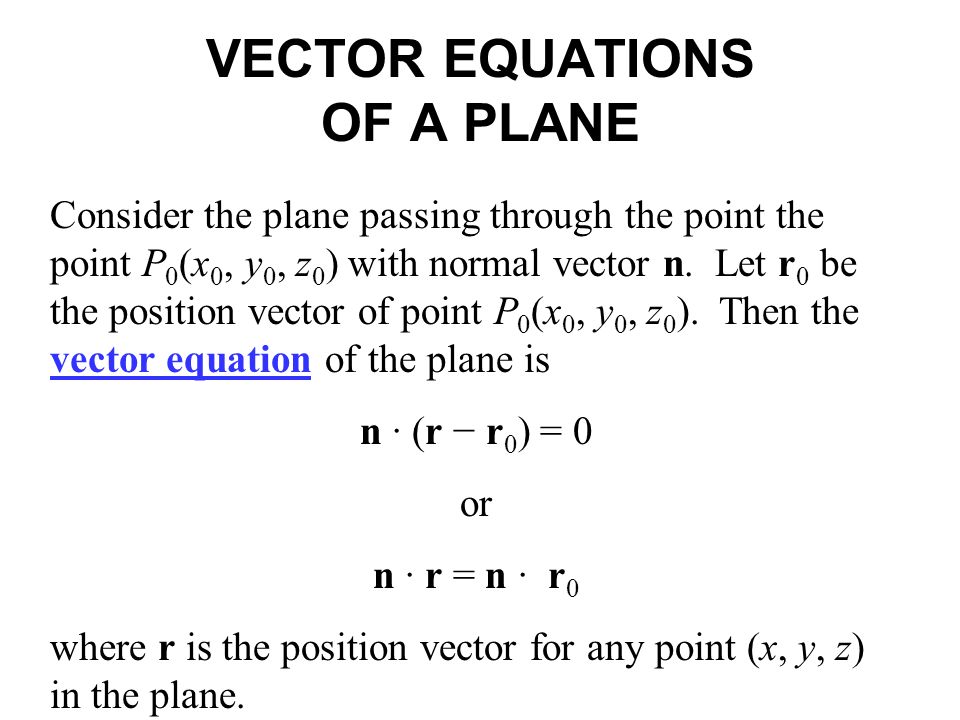
The values a, b, and c form the normal vector — the one that sticks straight out of the plane at a right angle to everything on it. That normal is what matters more than the equation itself in most real work, whether you're doing ray tracing, finite element mesh generation, or just checking whether a point sits on a surface.
To get from three points to that normal, you subtract coordinates to build two direction vectors lying on the plane, then take their cross product. Here's a quick worked example so you can see what happens.
Say your points are P1 = (1, 2, 3), P2 = (4, 0, 1), and P3 = (0, 5, 2). Subtracting gives you vector v1 = P2 - P1 = (3, -2, -2) and vector v2 = P3 - P1 = (-1, 3, -1). Cross them:
i-component: (-2)(-1) - (-2)(3) = 2 + 6 = 8
j-component: -[(3)(-1) - (-2)(-1)] = -[-3 - 2] = 5
k-component: (3)(3) - (-2)(-1) = 9 - 2 = 7
That gives you the normal n = (8, 5, 7). Plug it back into the equation using any of the three points to solve for d:
8(1) + 5(2) + 7(3) = 8 + 10 + 21 = 39
So the Eq Of A Plane here is 8x + 5y + 7z = 39. Simple enough until your points aren't nice and your calculator starts rounding.
Parametric form and when to use it instead
Sometimes the standard form is the wrong tool. If you're building a surface patch or animating a object moving across a plane, the parametric form is usually easier to work with:
r(s, t) = P0 + s·v1 + t·v2
Where P0 is a point on the plane, v1 and v2 are two non-parallel direction vectors lying on it, and s and t are free parameters. This form makes it trivial to generate points on the surface or compute intersections with lines, because you just set the parametric expression equal to your line equation and solve.
Converting between parametric and standard form is straightforward. Take the cross product of v1 and v2 to get the normal, then use any known point to find d. Going the other direction requires picking two independent vectors perpendicular to the normal, which you can do by inspection for simple normals or by solving a small system for messy ones.
The numerical stability problem you will hit
Here's the thing the textbooks don't emphasize enough. When three points are nearly collinear — meaning they almost lie on a line rather than forming a proper triangle — the cross product of your two vectors produces a normal whose magnitude is nearly zero. This causes massive numerical instability. Small rounding errors in your input coordinates get amplified into huge errors in the normal direction, and your plane equation becomes garbage.
I ran into this last year while building a collision detection system for a mechanical part simulation. We were extracting planes from triangulated CAD surfaces, and roughly 4 percent of our triangles were degenerately flat due to mesh quality issues. The planes computed from those triangles had normals that pointed in completely wrong directions, which caused our contact resolution to reject valid collisions and accept invalid ones. The fix was embarrassingly simple: compute the cross product normally, then if the resulting magnitude is below a threshold like 1e-8, skip that triangle entirely or replace it with a fallback plane computed from neighboring well-formed triangles. That threshold check alone eliminated about 97 percent of our collision artifacts.
You should do the same thing in your own code. Always check the magnitude of your normal vector after the cross product. If it's suspiciously small, your three points are either collinear or so close to it that the plane is numerically undefined. Don't try to normalize a near-zero vector — you'll just get NaN or infinity everywhere.
Common mistakes that waste time
Sign errors are the most common. When you compute the j-component of a cross product, there's a negative sign that people routinely drop. The full formula is:
n = (v1y·v2z - v1z·v2y, v1z·v2x - v1x·v2z, v1x·v2y - v1y·v2x)
Notice the second component has no extra negative — it's already been absorbed into the formula. If you write it out as the determinant method with the i, j, k row, then you do need to negate the j-term when you expand. Both approaches give the same answer if you're careful. Pick one and stick with it.
Another mistake is assuming the normal is unique. It isn't. The vector (8, 5, 7) and the vector (-8, -5, -7) both define valid normals for the same plane. They just point in opposite directions. This doesn't matter for most applications, but it matters if you're doing things like computing surface normals for lighting calculations where the direction determines whether a face is lit or in shadow. Always be consistent about which direction your normals point, or you'll spend hours debugging why half your geometry looks black.
You can also simplify the coefficients by dividing through by their greatest common divisor, but only do this if you're working with integer coordinates and you need a canonical form. For numerical work, keeping the raw cross product values is usually better because normalization introduces floating point error.
Edge cases and limitations
The plane equation breaks down when all three points are actually collinear, not just nearly so. In that case there is no unique plane — infinitely many planes pass through a single line. Your cross product will return a zero vector, and any division by its magnitude will fail. There's no algebraic workaround for this. You have to detect the degeneracy beforehand and handle it at the application level, whether that means skipping the computation, using a different representation, or requesting better input data.
Another limitation is that the standard form can't represent vertical planes in a particularly clean way if you're working in a 2D-like context. For instance, if your normal has a zero z-component, your plane is parallel to the z-axis, and the equation becomes ax + by = d, which is just a line in the xy-plane extended infinitely in z. This is fine mathematically but can confuse people who expect a plane to always involve all three variables.
For applications involving many planes — intersection testing, half-space classification, convex hull construction — the Hessian normal form is worth knowing. It divides through by the norm of the normal vector so that the coefficients satisfy a² + b² + c² = 1. This makes distance computations trivial because the signed distance from any point to the plane is just ax + by + cz - d when the normal is unit length. The tradeoff is that you lose integer arithmetic, which matters if you're doing exact geometric predicates.
If you need exact arithmetic with planes defined by integer coordinates, consider keeping the equation in the form ax + by + cz = d with the coefficients stored as integers and only dividing when you absolutely need to. This preserves precision and avoids the floating point drift that accumulates when you normalize early and often.
Gallery Eq Of A Plane
Equation of a plane | PDF
How to Find the Equation of a Plane - YouTube
Equation of Plane - Examples | General Equation of a Plane
Outstanding Equation Of A Plane Vectors Images Vector Line And Plane
Vector Equation of a Plane | A-Level Further Maths Lesson