How I Actually Use the Equation When Solving Dynamics Problems
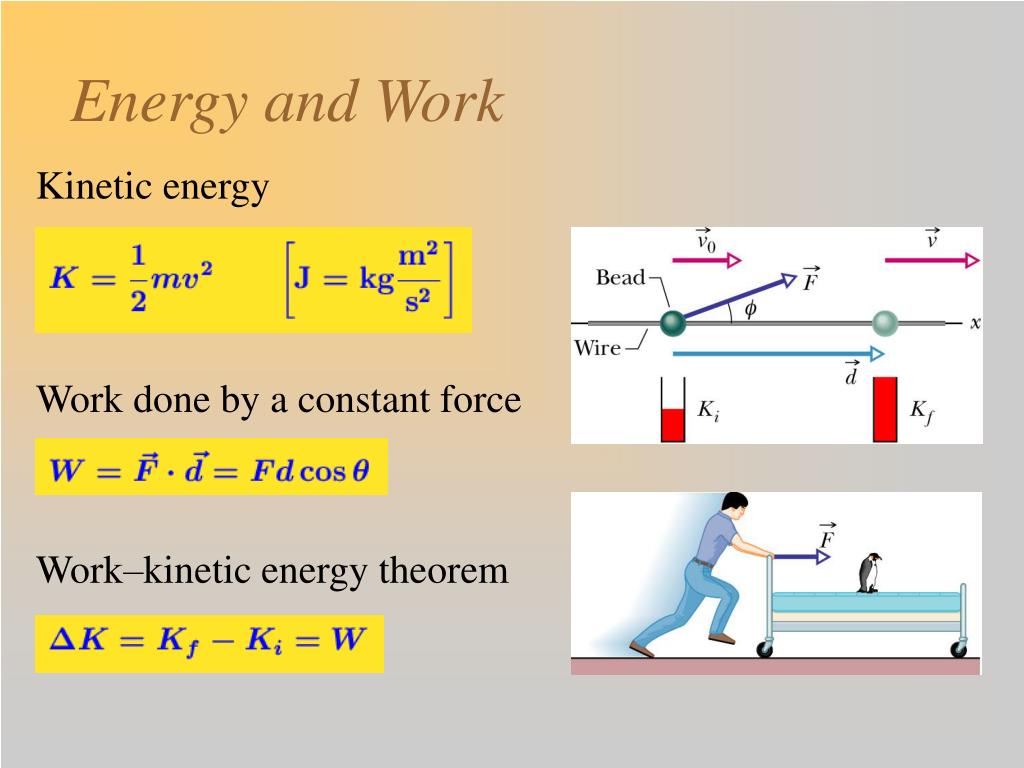
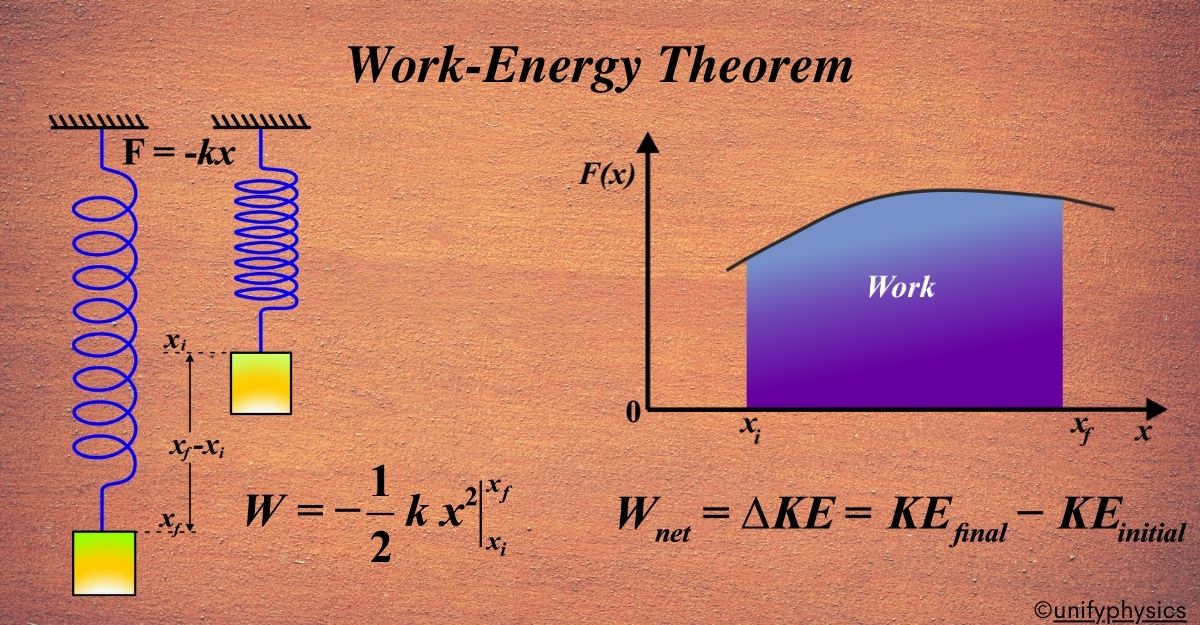
The first time I tried teaching this topic, my students kept drawing free-body diagrams for everything, even when it wasn't necessary. They'd spend ten minutes resolving forces along two axes just to find a velocity at a certain displacement. Then I started making them try the Equation Of Work And Energy approach on the same problem, and most of them finished in under two minutes. The difference isn't really about speed, though. It's about which problems the equation can solve cleanly without turning into a system of differential equations. The work-energy principle states that the net work done on a particle equals the change in its kinetic energy. In scalar form: T + U = T. T is kinetic energy, equal to ½mv². The U terms are work done by each force along the actual path of motion. Positive work adds energy; negative work removes it. That's the whole thing in one line. The equation becomes genuinely useful when you know displacement and velocity but not time or acceleration, because it bypasses those variables entirely. Time never shows up in the formulation. If your problem involves force, displacement, and speed with no interest in how long it takes, this is usually your fastest path.
When the Equation Of Work And Energy Breaks Down
I wish someone had told me earlier that the work-energy equation is fundamentally limited to scenarios where forces are functions of position or constant. When force depends on time in a complicated way, or when you need acceleration as an intermediate variable, the scalar energy equation gives you nothing directly. You'd be better off falling back to F = ma with integration, or using the impulse-momentum equation if time is relevant. Here's a concrete case I ran into last semester. A student was analyzing a spring-mass-damper system where the damping force was quadratic, proportional to velocity squared. She tried to plug the damping force directly into the work integral F·ds and got stuck because the force depended on v, which itself was a function of position. The integral was intractable in closed form. What actually worked was rewriting the damping work term as cv²(dx/dt)dt and switching to a numerical approach, or alternatively using the differential equation of motion and solving it with a Runge-Kutta routine in Python. The work-energy equation didn't fail because it was wrong. It failed because the velocity-squared damping force meant the work integral couldn't be expressed purely in terms of position without first solving the trajectory. That's a boundary condition beginners rarely encounter. Another practical limitation: the equation gives you a scalar relationship. It tells you nothing about direction. If you need to know which way an object is moving at the end of a curved path, you still need kinematics or momentum conservation. I've seen students assume that because the energy equation gave them a magnitude for velocity, that magnitude alone was sufficient for the rest of the problem. It never is. Always pair it with a direction check from the kinematic constraints or the geometry of the system.
Building the Energy Equation Step by Step
Start by identifying the initial and final states. State 1 is where you begin, state 2 is where you want to know something. Write down the kinetic energy at both states. At state 1, T = ½mv². At state 2, T = ½mv². These are scalars. Speed is always non-negative, so the square root you take at the end is unambiguous. Next, catalog every force that does work between the two states. Gravity, springs, friction, applied forces, tension in cables. For each one, compute the work integral. Constant forces are straightforward: U = F·d·cos(), where is the angle between the force vector and the displacement vector. Variable forces require integration: U = F(x)dx over the path. Spring forces are special. The work done by a spring going from x to x is ½k(x² - x²). Note the sign convention. If the spring compresses further, it does negative work on the mass. If it relaxes, it does positive work. Getting this sign wrong is the single most common error I see. Friction is another place where signs trip people up. Kinetic friction always does negative work because it opposes motion. The magnitude is N times the distance traveled. But static friction does zero work when there's no slip, because the point of application doesn't move relative to the surface. Rolling without slipping is a boundary case where static friction can exist without doing work. Don't include it in your energy balance.
Get the Full Details
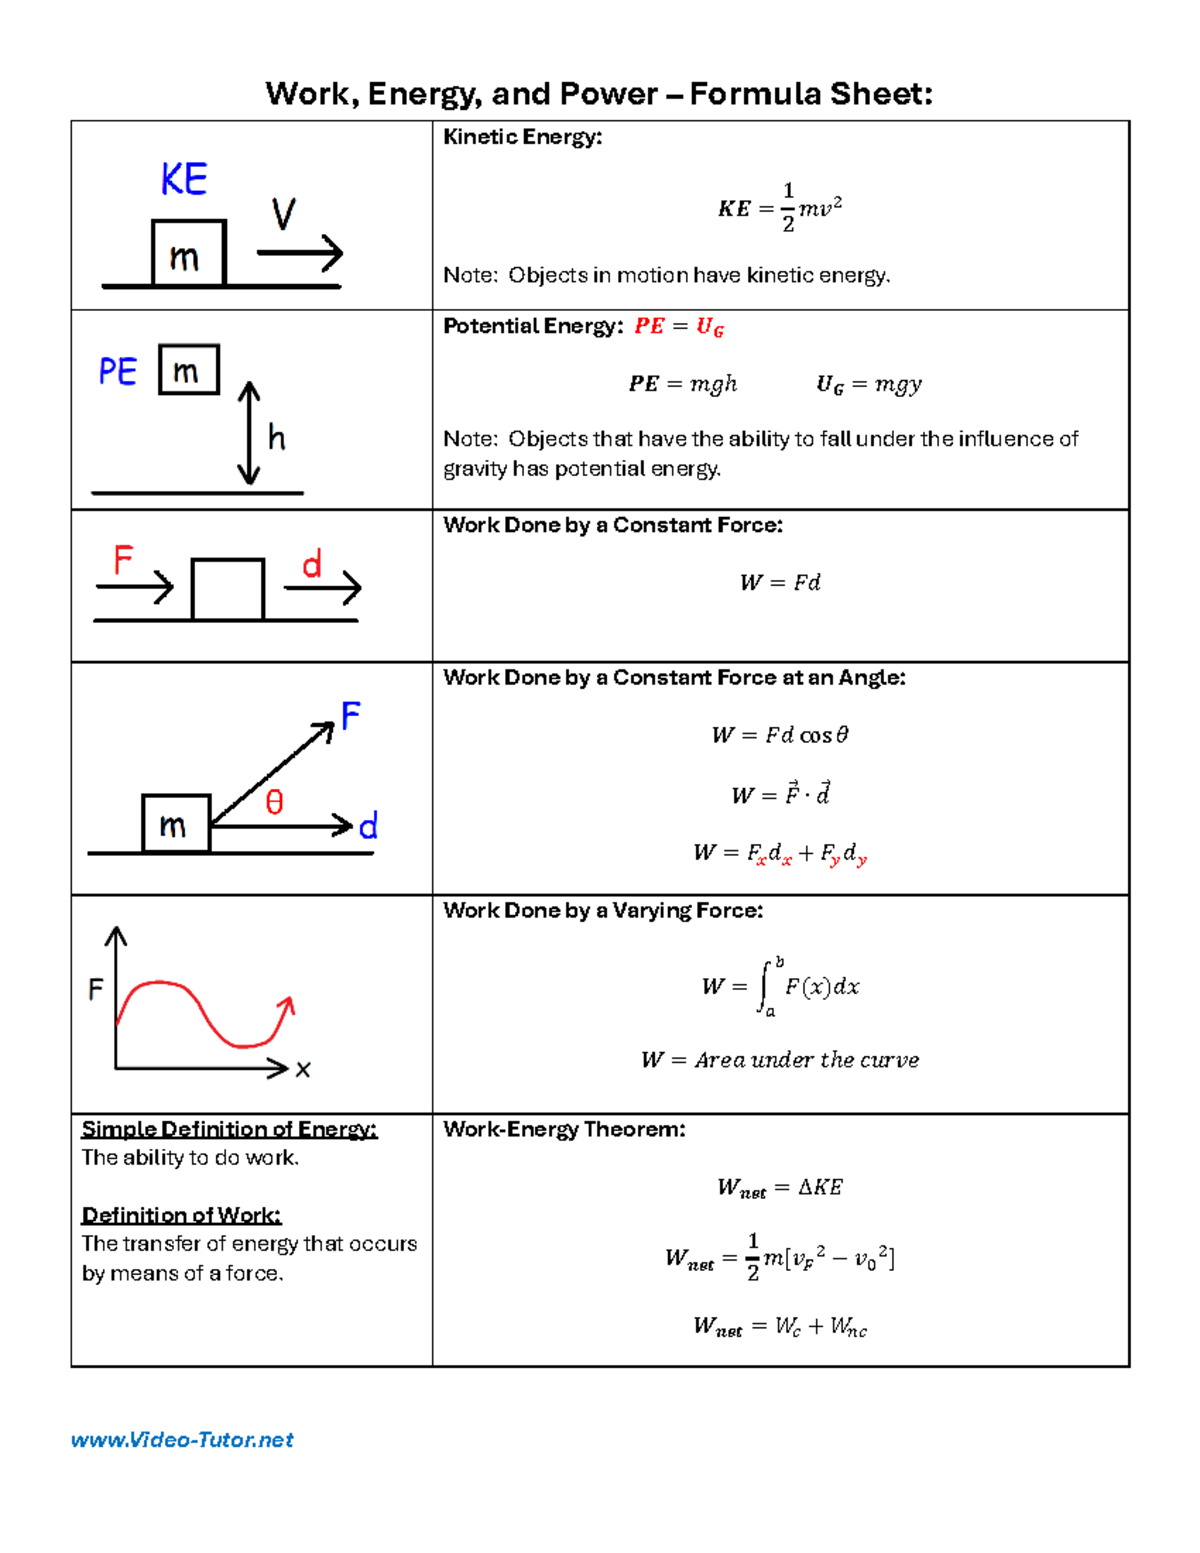
Once all the U terms are computed, assemble the equation: T + U = T. Solve for the unknown. Usually it's a velocity or a displacement. If the equation gives you a negative value under a square root, you've made a sign error or the scenario is physically impossible given the initial conditions.
A Problem That Shows How It Actually Works
Consider a 5 kg block sliding down a 30-degree incline with a kinetic friction coefficient of 0.2. The block starts from rest at the top of a 4-meter incline. Find the speed at the bottom. State 1: v = 0, so T = 0. State 2: v = ?, so T = ½(5)v² = 2.5v². Forces doing work: gravity and friction. Normal force does zero work because it's perpendicular to displacement.
Gravity work: U_g = mgh = (5)(9.81)(4sin30°) = 5(9.81)(2) = 98.1 J. Positive, because the block moves downward along the component of gravity. Friction work: normal force N = mgcos30° = 5(9.81)(0.866) = 42.48 N. Friction force f = N = 0.2(42.48) = 8.496 N. Work U_f = -f·d = -8.496(4) = -33.98 J. Negative, because friction opposes the displacement. Energy equation: 0 + 98.1 - 33.98 = 2.5v². So v² = 64.12/2.5 = 25.65. v = 5.06 m/s.
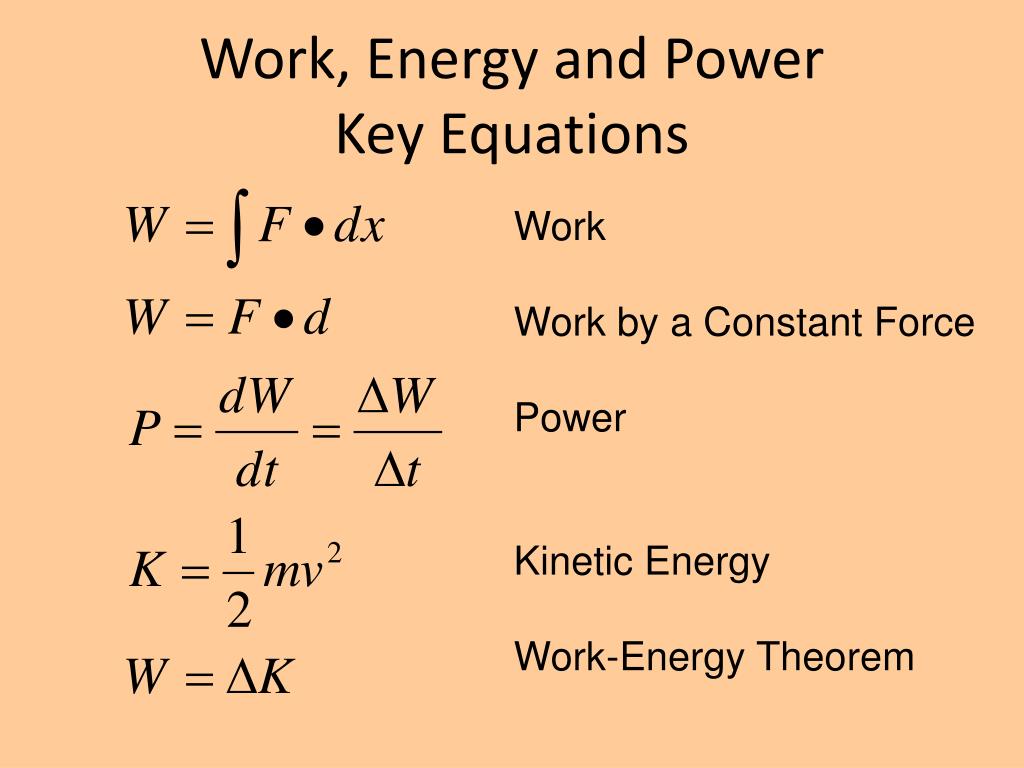
The same problem solved with F = ma would require finding acceleration first, then using kinematics. Both methods give the same answer. The energy method skips the intermediate step of acceleration, which saves time and reduces algebraic errors. But the energy method also hides the acceleration profile. If the question later asks for the time to reach the bottom, you're back to kinematics anyway.
Counter-Intuitive Things Beginners Miss
Work is frame-dependent. Two observers in different inertial frames will measure different velocities and therefore different kinetic energies, and they'll also measure different work values because displacement depends on the frame. The equation is consistent within each frame, but you can't mix frame-dependent quantities across observers. I've seen students complain that their answer didn't match the textbook because they computed displacement in one frame and velocity in another. It sounds obvious now, but it trips people up on exams. Another subtlety: internal forces in a system of particles can do net work even when they sum to zero as a vector. Think of two masses connected by a compressed spring. The spring forces are equal and opposite, so the net force is zero. But when the spring expands, each mass gains kinetic energy. The work done by the spring on each mass is positive from each mass's perspective. The internal forces converted stored potential energy into kinetic energy. The work-energy equation for the system still holds if you include the elastic potential energy term explicitly, or if you treat the spring force as doing work on each individual mass. Non-conservative forces don't violate energy conservation. They convert mechanical energy into other forms. Friction turns kinetic energy into heat. Air drag does the same. The work-energy equation tracks the mechanical energy change caused by these forces. If you want to include thermal energy, you need the first law of thermodynamics, not just the mechanics formulation. In a standard dynamics course, you just acknowledge that the U term for friction is negative and the kinetic energy at the end is less than it would have been without friction.
What to Do When the Force Law Is Complicated
Real-world problems often involve forces that don't have clean closed-form integrals. A good workaround is piecewise linearization. Break the force-displacement curve into segments where the force is approximately constant or linear, compute the work for each segment numerically, and sum them. This is what I did when working with a suspension system that had a nonlinear spring rate increasing with compression. The force curve was F(x) = kx + x³, and the integral was doable analytically but messy. For quick estimates, I approximated the curve with four linear segments and got the answer within 3% of the exact result. That's usually sufficient for preliminary design. For truly intractable force laws, numerical quadrature is the standard approach. Simpson's rule or Gaussian quadrature over the displacement interval gives machine-precision results in most cases. The work-energy equation then becomes a numerical root-finding problem: solve for v such that ½mv² - ½mv² equals the numerically integrated work. This is computationally trivial on any modern machine and takes about three seconds to set up in Python or MATLAB. The Equation Of Work And Energy remains one of the most direct tools in dynamics when used within its valid range. It doesn't replace Newton's second law. It complements it. Knowing when to reach for it and when to fall back on F = ma or impulse-momentum is what separates students who struggle through problem sets from those who finish them in half the time.