Newton's Second Law: Force, Mass, and Acceleration in the Real World
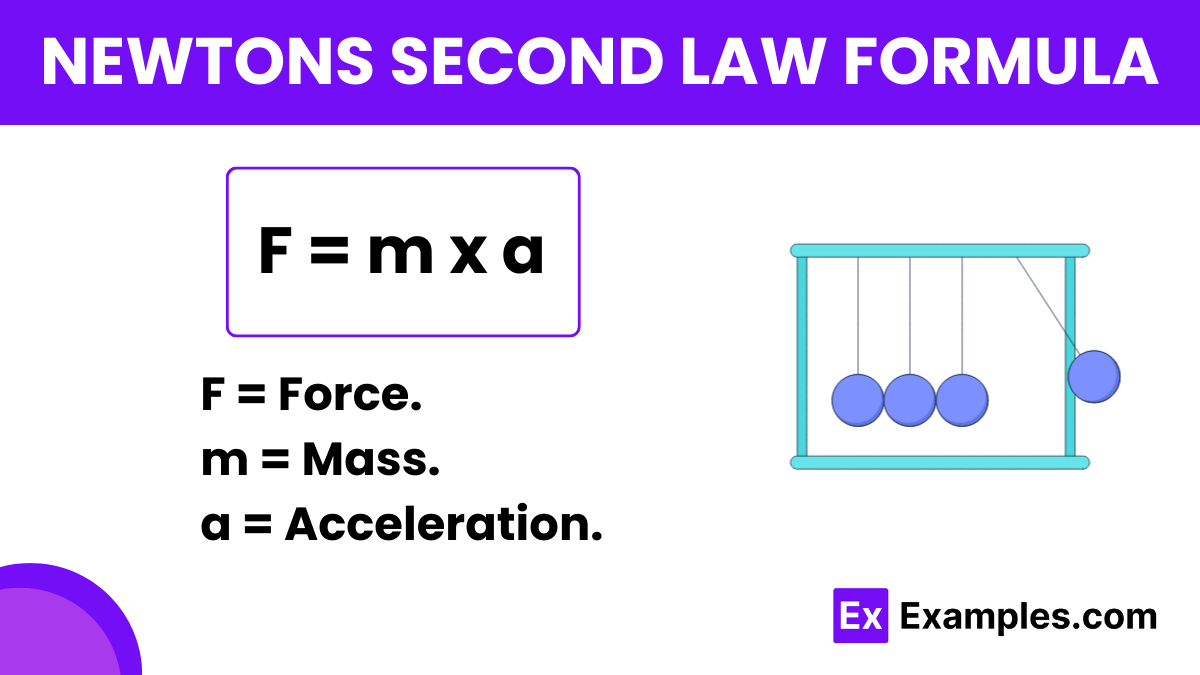
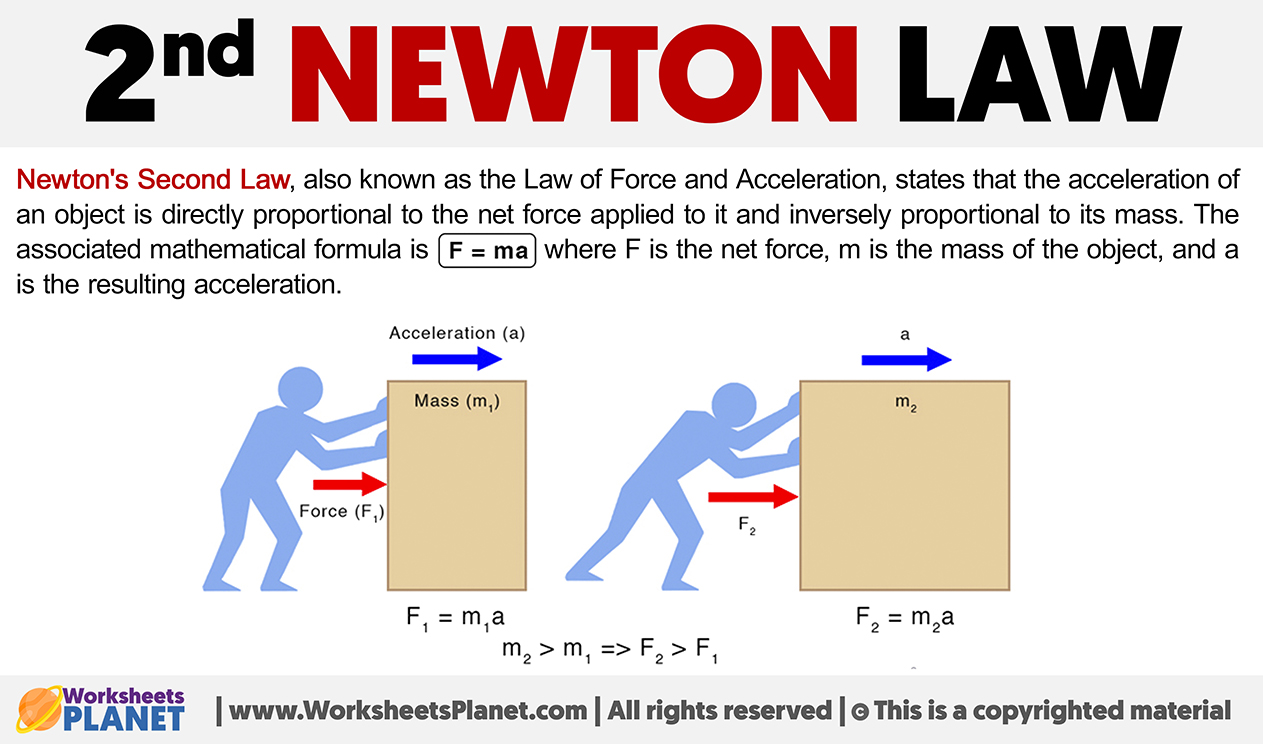
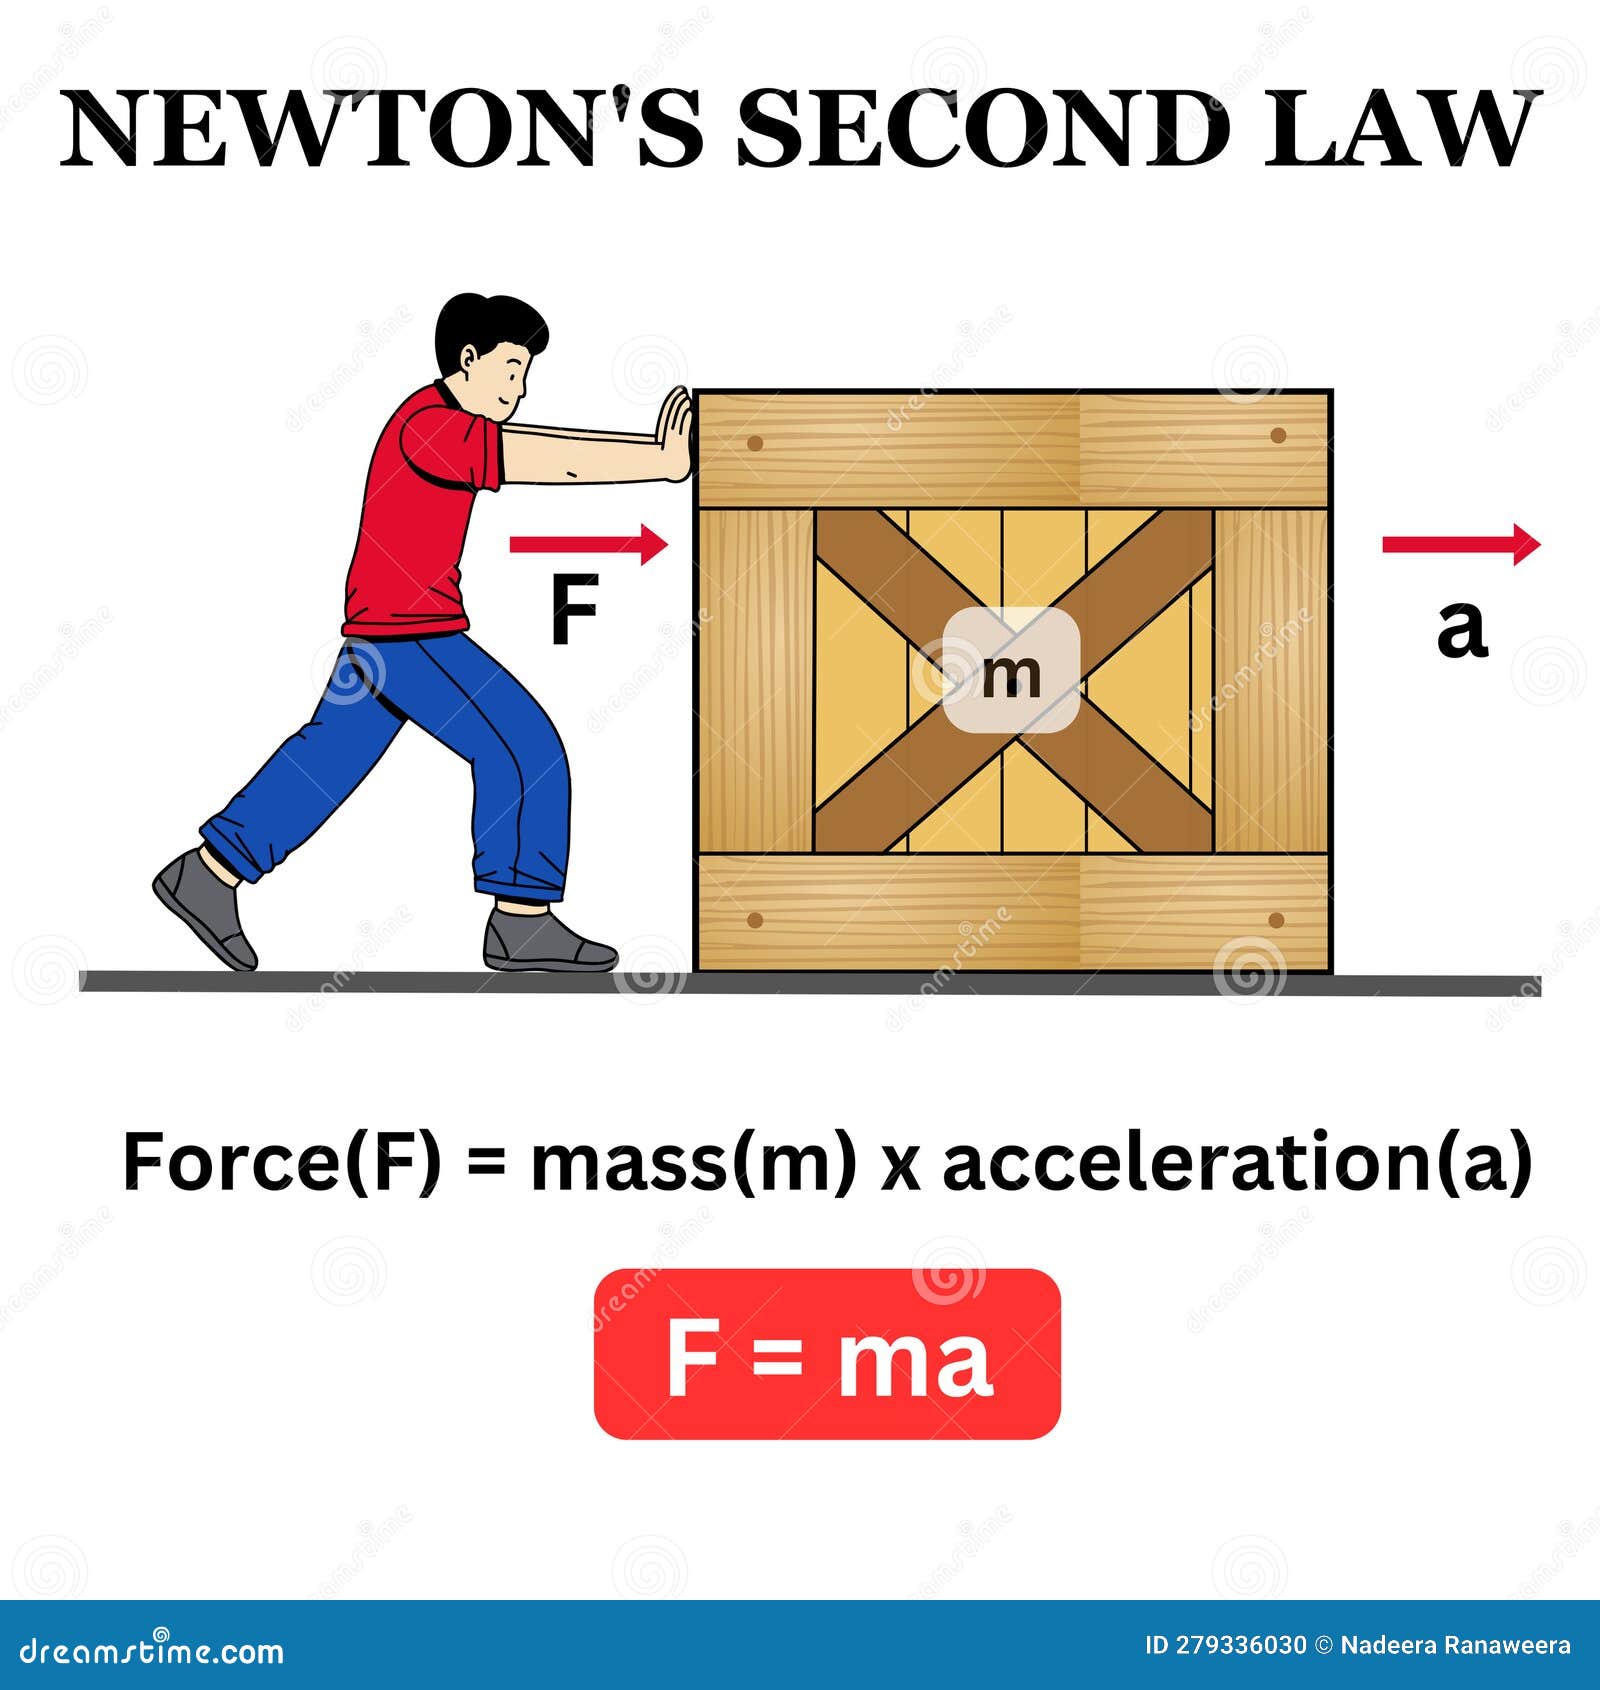
Most people learn F=ma in high school physics and then immediately forget it. The equation itself is trivial. What most of us end up using regularly is the deeper version: a = F_net / m. You divide the total force acting on an object by its mass to get acceleration. That rearrangement is the one that actually shows up in engineering calculations, simulations, and any situation where things move under multiple forces. Here's a concrete case. You're designing a motor-driven conveyor belt system. The belt needs to accelerate a 45-kilogram load from rest to 1.2 meters per second in roughly two seconds. Using the rearranged formula, you need an acceleration of 0.6 meters per second squared. Multiply that by 45 kilograms and you get 27 newtons of net force required just for the acceleration phase. But that's not the whole story. Friction in the rollers, the weight of the belt itself, and any incline all add forces you have to account for. In my case I ended up specifying a motor rated for about 40 newtons of continuous thrust because the friction alone was pulling roughly 13 newtons against the motion. The point is that the textbook example always gives you a block on a frictionless surface. Real systems never work that way. You always have to identify every force vector acting on the body, sum them as vectors, then divide by mass. The direction matters. If forces are opposing, they subtract. If they're at angles, you resolve components first.
How to Actually Use This in Calculations
Start by drawing a free body diagram. Every object, every force arrow, label the magnitude and direction. Then pick your coordinate system. In simple cases it's just horizontal and vertical. In ramp problems you tilt the axes so one aligns with the surface. Once the diagram is right, sum the forces in each direction independently. The acceleration comes out of each direction separately. I once spent three days debugging a simulation where my calculated acceleration was consistently 15 percent too high. The model was a simple block sliding down an incline with kinetic friction. I had used the static friction coefficient instead of the kinetic one. Static friction is always higher, and using it in a sliding problem gave me a smaller net force, which sounds like it should reduce acceleration, but the real issue was that I also forgot to resolve the normal force properly on the tilted axis. The normal force on an incline is mg times the cosine of the angle, not mg. Fixing both issues brought my simulation within 2 percent of the measured data.
Common Pitfalls That Cost Time
Weight versus mass is the most common error. Weight is a force measured in newtons. Mass is the amount of matter measured in kilograms. On Earth they relate through g, which is approximately 9.81 meters per second squared, but that relationship breaks the moment you leave the surface. A 10-kilogram object weighs about 98 newtons on Earth, roughly 16 newtons on the Moon, and effectively zero in orbit. The mass stays 10 kilograms in all three cases. Mixing these up throws every subsequent calculation off. Another pitfall is treating forces as scalars when they are vectors. Two people pushing a car from different angles do not simply add their forces arithmetically. You need components. If one person pushes east at 150 newtons and another pushes northeast at 200 newtons, you resolve the second force into east and north components first, then add everything together.
Get the Full Details
When This Approach Falls Apart
Newton's second law assumes constant mass. If you're dealing with a rocket burning fuel, the mass is changing continuously, and the simple form a = F/m no longer applies directly. You need the full form F = dp/dt, where p is momentum and t is time. The derivative of momentum accounts for the mass change. This is why rocket equations look completely different from basic force problems. If your problem involves significant mass loss or gain during the time interval you're analyzing, stick to the momentum formulation or use numerical integration. Relativistic speeds are another boundary. Above roughly 10 percent of the speed of light, the classical relationship between force and acceleration breaks down because mass effectively increases with velocity. For most practical engineering work this is irrelevant, but it matters in particle accelerators and certain orbital mechanics calculations.
A Counter-Intuitive Insight
People often assume that more force always means more acceleration, which is true only if mass stays constant. But consider two objects where you apply the same force. The lighter one accelerates more, yes, but the work done and the energy transferred depend on distance, not just acceleration. A small force applied over a long distance can deliver more kinetic energy than a large force applied briefly. This distinction matters when you're sizing motors or designing braking systems, because energy requirements and force requirements are not interchangeable. The net force concept is also where most people get tripped up. An object moving at constant velocity has zero net force, not no force. The engine force balances friction and air resistance exactly. That's why a car cruising at 60 miles per hour on a flat road doesn't keep accelerating even though the engine is running. The forces cancel. Newton's second law describes what happens when they don't cancel.
Summary of Key Points
The working form you should remember is a = F_net divided by m. Draw the free body diagram first. Resolve forces into components along your chosen axes. Check whether mass is constant. Watch out for the weight-mass confusion. And always verify your answer makes physical sense before trusting the numbers.