What the Origin Actually Means in Math
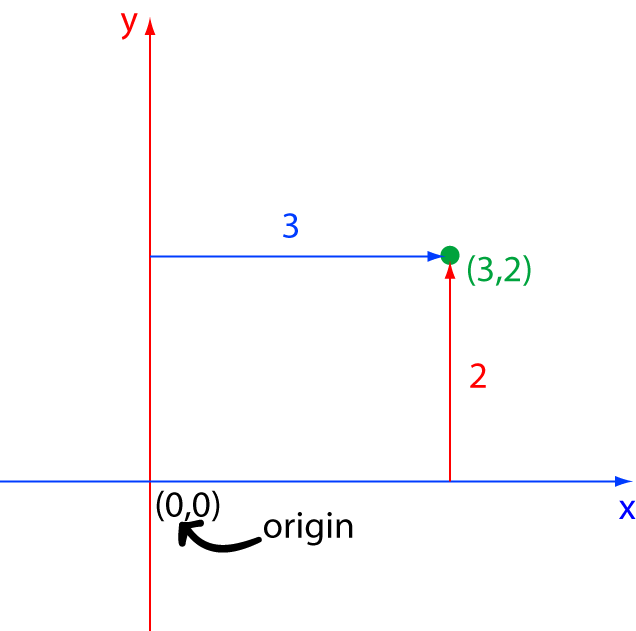
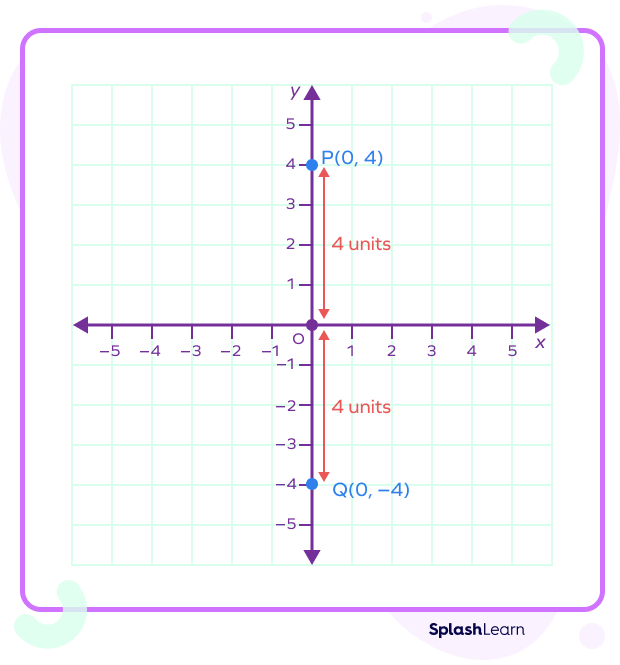
The origin in mathematics is simply the point where all coordinate axes intersect at zero. It looks straightforward on paper, but picking the wrong origin or misunderstanding its role will slow you down fast. I spent too many hours wrestling with coordinate systems that refused to align because I treated the origin as interchangeable when it wasn't. In a Cartesian plane, the origin is (0, 0). In three dimensions, it becomes (0, 0, 0). But here is the part most people skip: the origin is not an immutable fact about a problem. It is a choice. Moving the origin is a translation, and that changes every coordinate in your system. Engineers do this all the time when they shift a frame of reference to make calculations cleaner.
Examples Of Origin In Math
Coordinate Geometry: The classic example. The origin sits at the intersection of the x and y axes. Any point is measured as a distance from that zero point. When you plot a line, the y-intercept tells you where the line crosses the y-axis, which is directly tied to the origin's position. Vectors: A vector has both magnitude and direction, and it is often drawn as an arrow starting from the origin. But free vectors don't have to start there. Position vectors do. When I was working on a robotics project, I had to convert between a robot's local frame and the world frame, and mixing up bound vectors with free vectors almost cost me two days of debugging. Polynomial Functions: The origin matters here too. A polynomial like f(x) = x² - 4 crosses the x-axis at -2 and 2, but the value at the origin is f(0) = -4. That single point tells you where the graph starts vertically. It seems trivial until you are fitting curves and the origin constraint becomes a boundary condition.
Linear Algebra: In linear transformations, the origin must stay fixed. A matrix multiplication always maps (0, 0, 0) to itself. If your transformation moves the origin, it is not purely linear. It is affine. That distinction breaks a lot of students who assume any transformation can be represented by a single matrix. Calculus: When you compute a definite integral, the origin is your default lower bound unless you change it. Improper integrals sometimes start at negative infinity, but the idea of an origin point still anchors how you set up the problem. I once misread a problem because the question implied a shifted origin without stating it clearly. Took me an hour to catch.
Get the Full Details

How to Work With the Origin Correctly
Start by identifying what kind of origin the problem gives you. Is it fixed at (0, 0)? Is it implied somewhere else? Draw it. Seriously, draw it. Most mistakes come from assuming the origin is where you expect it to be. When translating coordinates, use the formula: new_x = old_x - h, new_y = old_y - k, where (h, k) is the old origin expressed in the new system. This is basic, but I have seen people apply it backwards and then wonder why their numbers were negative when they should have been positive. In vector problems, decide early whether your vector is bound to the origin or free to move. A force vector in physics is free. A position vector is bound. Confusing the two leads to errors in moment calculations and torque problems. I learned that the hard way on a dynamics assignment that ate my grade.
For linear transformations, always verify that T(0) = 0. If it isn't, you need an affine transformation, which means adding a translation vector to your matrix. The standard form becomes a 3x3 matrix in 2D space or a 4x4 in 3D. It adds a row and column, but it fixes the problem cleanly.
When the Origin Fails You
Not every problem plays nice with a standard origin. Non-Cartesian systems like polar, cylindrical, and spherical coordinates use a different kind of origin reference. In polar coordinates, the origin is the pole, but distances are measured as r and angles as theta. Switching between polar and Cartesian requires knowing which origin convention you are using, and they are not always compatible without conversion. Another edge case: modular arithmetic. There is no visual origin here, but the concept of a zero element still exists. The additive identity acts as the origin of the group. Beginners often overlook this because there is no graph to point at, but it is the same structural idea. If you are working with numerical methods and floating-point arithmetic, the origin can introduce rounding errors. Computers represent zero exactly, but values near zero can behave unpredictably depending on your precision settings. I ran into this when simulating particle trajectories. Near the origin, the integrator would oscillate because the step size defaulted to values that were too large relative to the coordinate magnitude. The workaround was scaling the entire system by a factor of 1000 before integration, then scaling back. It sounds cheesy, but it eliminated the drift entirely.
Common Mistakes to Avoid
Assuming the origin is always (0, 0) without checking the problem setup. Some questions define a custom origin. Read carefully. Forgetting that the origin is a reference point, not a physical object. It has no mass, no size, no properties beyond being the zero point. Treat it like one. Mixing up the origin with the centroid or the center of mass. They can coincide in symmetric shapes, but they are fundamentally different concepts. The origin is a coordinate choice. The centroid is a geometric property.
Neglecting the origin when working with inverse functions. The domain and range of an inverse swap, and the origin's role in that swap matters for continuity and differentiability checks. One more thing: the origin is not the same as the initial condition in differential equations. Initial conditions specify values at a particular point, which may or may not be the origin. Confusing these two leads to wrong setup on boundary value problems.
A Practical Walkthrough
Take a simple problem: find the distance from point A(3, 4) to the origin. The formula is sqrt(x² + y²). Plugging in gives sqrt(9 + 16) = sqrt(25) = 5. That is the Euclidean distance. Straightforward. Now make it harder. Translate the origin to (1, 2). Point A is now at (2, 2) in the new system. The distance from A to the new origin is sqrt(4 + 4) = sqrt(8) 2.83. The point moved, the origin moved, the distance changed. All correct. Now add a rotation. Rotate the coordinate system 45 degrees counterclockwind around the new origin. The new coordinates of A become approximately (0, 2.83). The distance to the origin stays the same because rotation preserves distance. That is the key insight: translation changes coordinates. Rotation preserves distances from the origin. Both are valid transformations, but they do different things.
This is the kind of thing that clicks once you have done it enough times. The math doesn't lie. Your interpretation of it does.
Bottom Line
The origin is a tool, not a rule. It simplifies problems when used correctly and complicates them when ignored. Know your coordinate system. Know your transformations. And for god's sake, draw the damn diagram before you start calculating.