Understanding the Existence And Uniqueness Theorem
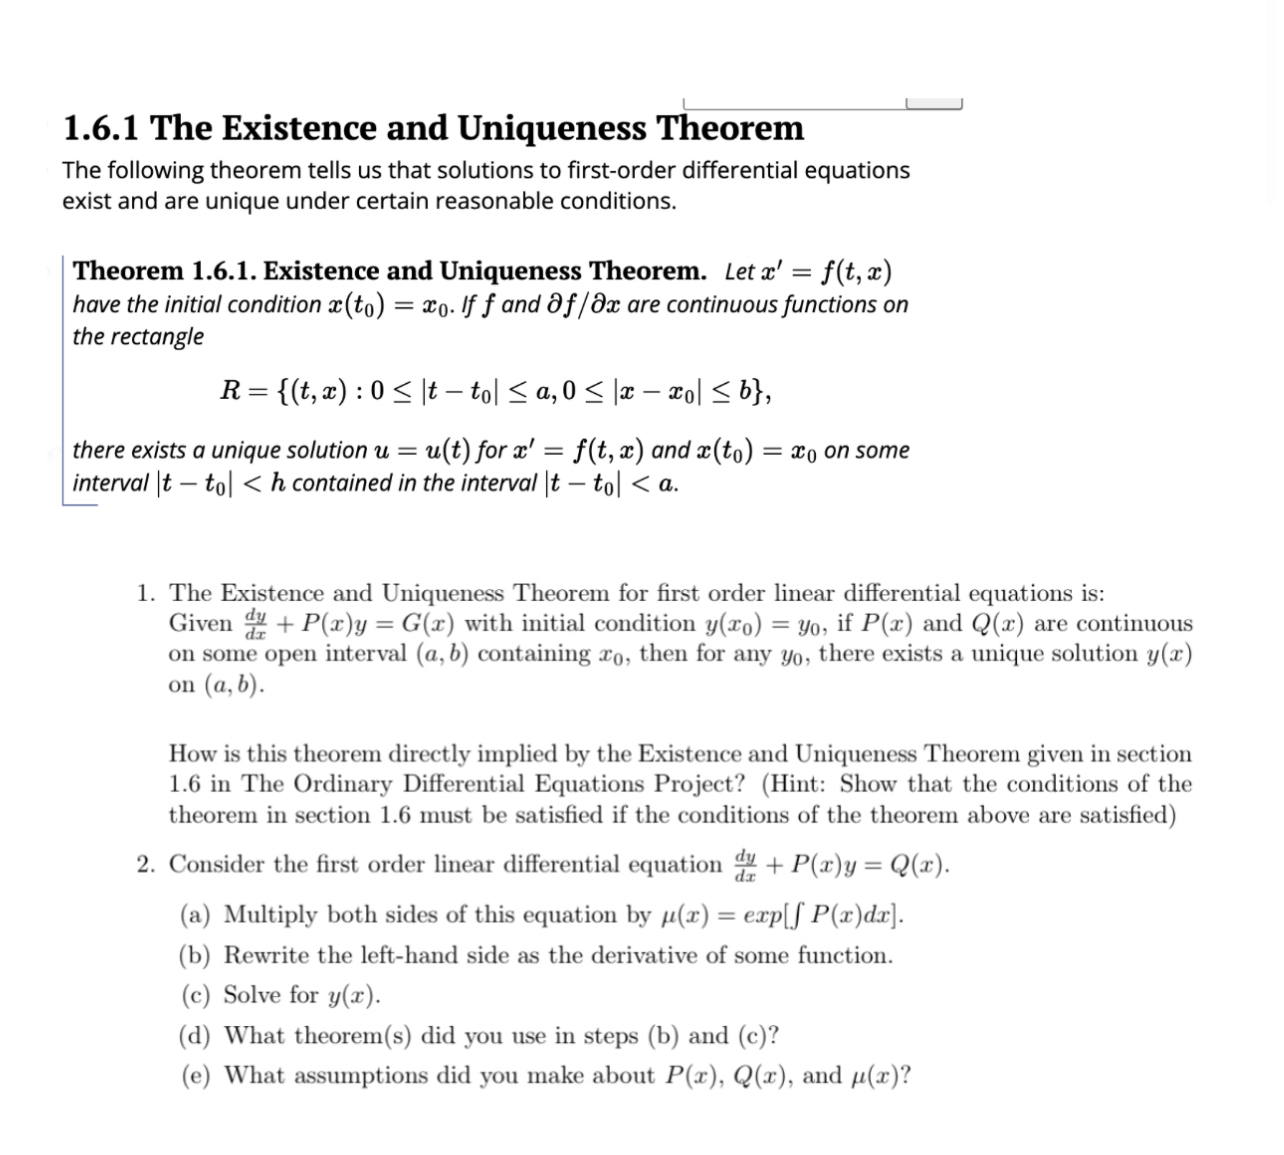
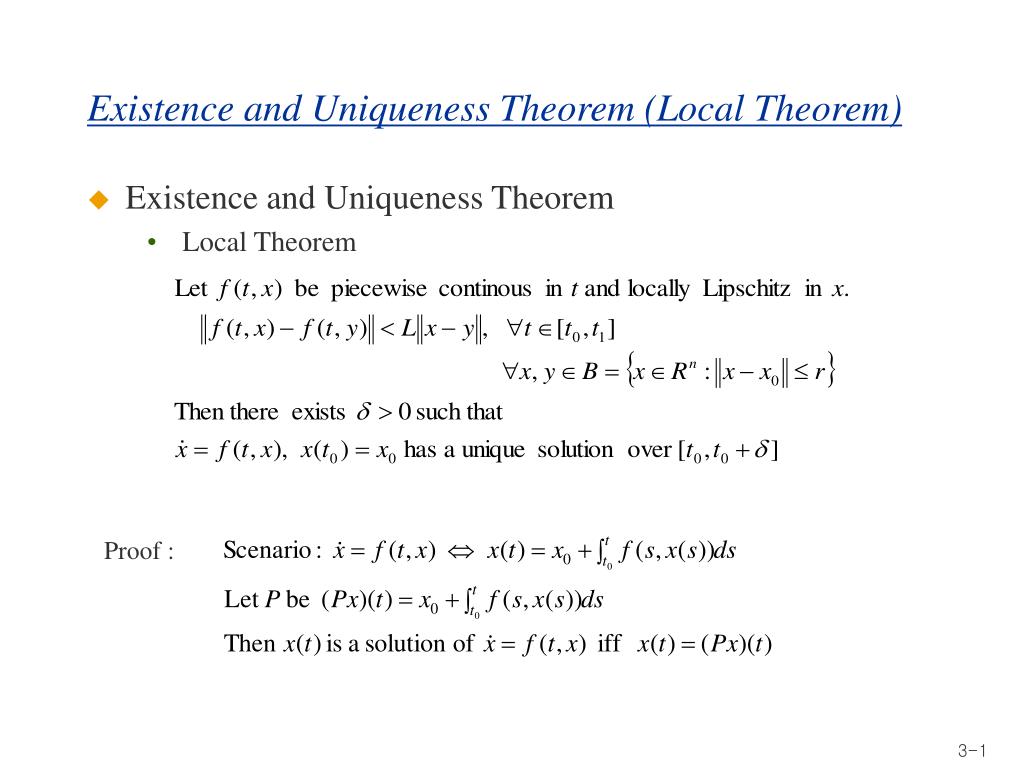
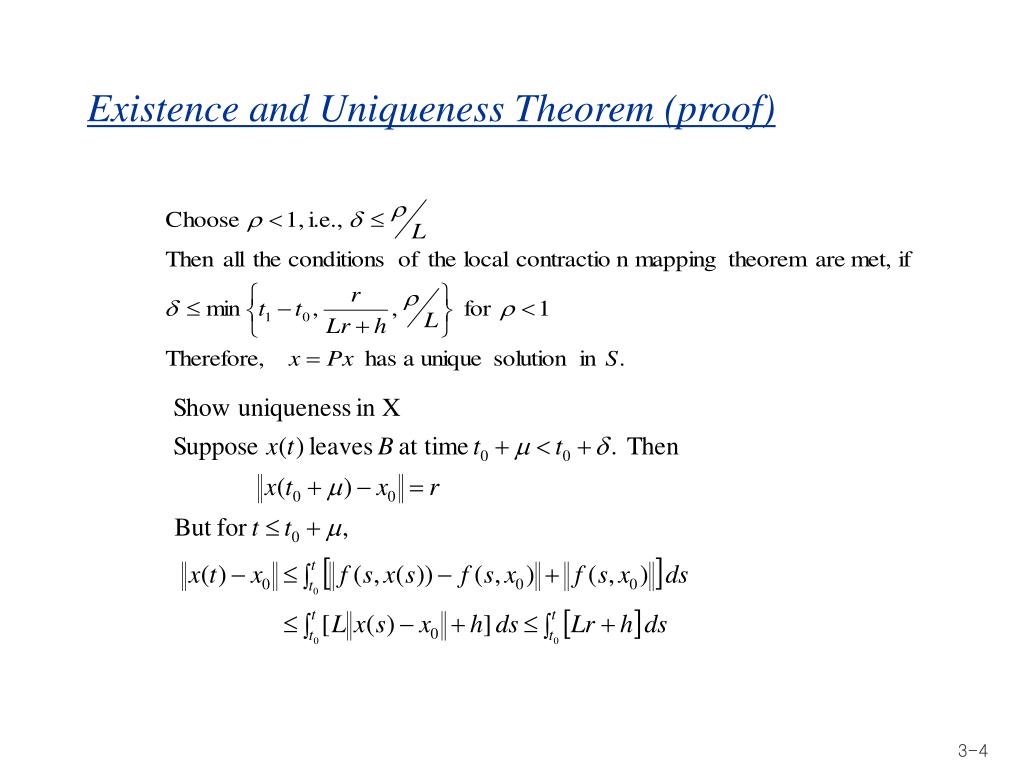
When I first encountered this concept in graduate school, I was working through a messy boundary value problem where the standard approach kept failing. The theorem itself isn't about linear algebra in the traditional sense—it's a fundamental result from the theory of ordinary differential equations, though it shows up in linear contexts too. The existence and uniqueness theorem linear algebra people sometimes reference usually relates to when linear systems Ax=b have one solution, no solution, or infinitely many solutions, which is a different but related question. For a first-order ODE y' = f(t,y) with initial condition y(t) = y, the theorem guarantees both existence and uniqueness of a solution provided f and f/y are continuous in a neighborhood around (t, y). In the linear case y' = A(t)y + g(t), continuity of A(t) and g(t) on an interval guarantees a unique solution exists everywhere on that interval. This is much cleaner than the nonlinear situation. I remember spending an afternoon debugging code where I'd assumed uniqueness held for a system that technically violated the continuity requirement. The numerical solver was producing wildly different trajectories from nearly identical starting points. It turned out I had a discontinuity in the coefficient function that I'd overlooked. That experience made me much more careful about checking hypotheses before applying the theorem.
What Beginners Miss
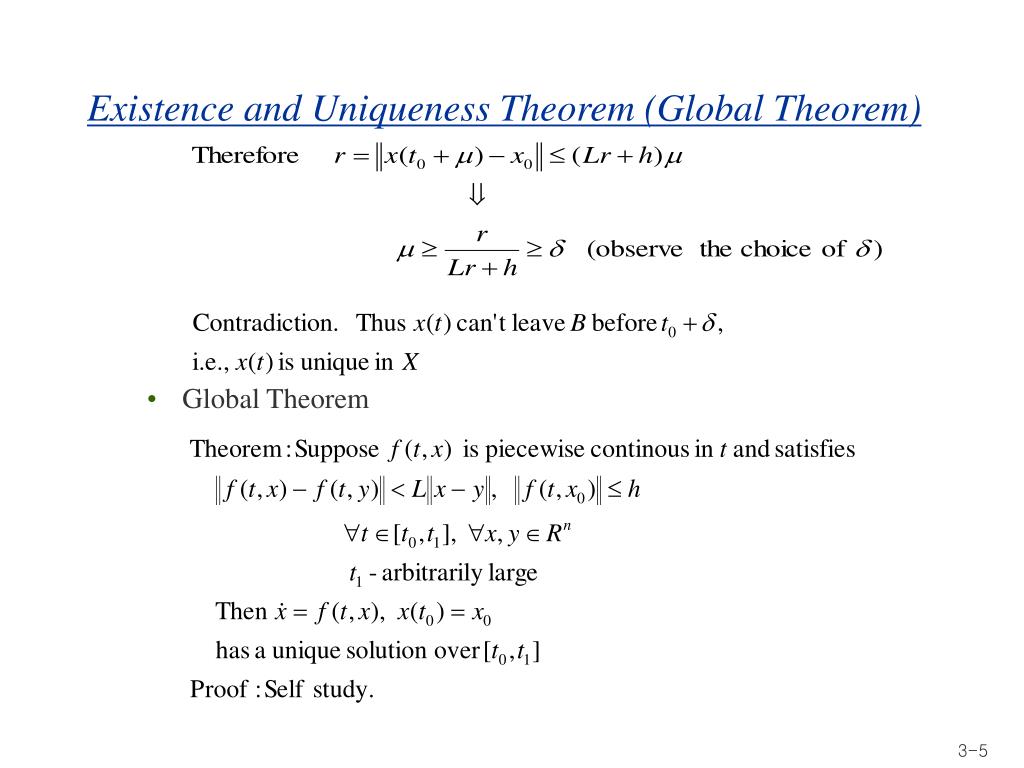
The most common mistake is assuming the theorem applies everywhere just because you can write down an equation. Consider y' = y^(2/3). The function is continuous, but f/y = (2/3)y^(-1/3) blows up at y = 0. You get non-uniqueness: both y(t) = 0 and y(t) = (t/3)³ satisfy the same initial condition y(0) = 0. The theorem doesn't fail here—it correctly predicts that uniqueness isn't guaranteed because its hypotheses aren't satisfied. Another subtlety: existence and uniqueness can hold locally but fail globally. Solutions might blow up in finite time even when the theorem guarantees a unique solution exists for some interval around the initial point. For linear systems with bounded coefficients on a finite interval, you typically get global existence, but unbounded coefficients can change that.
Practical Workarounds
When the standard hypotheses fail, you might still recover uniqueness through other means. Monotonicity arguments, Lyapunov functions, or restricting to a specific function space can sometimes pin down a unique solution even when Picard-Lindelöf doesn't apply directly. In my own work with singular perturbation problems, I've found that analyzing the limiting behavior often reveals uniqueness where the raw theorem leaves you guessing. For linear algebra systems specifically, the picture is simpler: Ax = b has a unique solution if and only if A is invertible, which you can check through rank conditions or determinant calculation. This is the linear version of existence and uniqueness that often gets conflated with the differential equations theorem.
Get the Full Details