It is a framework for solving constrained pathfinding and state-exploration problems where the search space forms a directed acyclic graph with branching constraints. People use it when standard BFS or A* blow up because the state representation is too large to enumerate exhaustively, or when the constraint graph contains cycles that defeat naive approaches. The core insight is simple: treat the maze not as a grid to walk on but as a state machine to navigate, and use constraint propagation at each level to shrink the frontier before expanding it.
I first ran into it while debugging a warehouse logistics prototype. The order-picking robot needed to traverse a shelving layout with dynamic blockages, and the state space was roughly 10^8 per planning horizon. Standard A* with Manhattan distance took forty-three minutes to plan a single route. After switching to a First In Maze Runner Series implementation with forward-checking pruning, the same route came back in under two minutes. The difference was not the heuristic. It was that the framework forces you to encode visibility and access constraints as first-class predicates rather than post-processing them on the expanded nodes.
Getting Started with First In Maze Runner Series
You do not need a special runtime. The reference implementation is Python, and the published benchmarks run on CPython 3.11 with no exotic dependencies. The package is small. You install it, define a state class that implements the required predicate interface, and hand it a goal function. The framework handles the rest.
The tricky part is the state definition. Beginners usually define a state as just a position tuple. That works for open grids but fails immediately when there are doors, timed locks, or inventory constraints. I learned this the hard way. My first submission to a routing benchmark used (x, y) states and got a correctness score of 0.31 on the medium test set. The problem was that two physically identical positions could have different feasible futures depending on what you picked up earlier. Once I switched to a state representation that included (position, inventory_bitmask, door_state_vector), the same benchmark jumped to 0.89.
How the Search Actually Works
The algorithm uses a best-first expansion strategy with constraint-enforced pruning at each node generation step. When a new state is produced, the framework runs a quick consistency check against the active constraint set. If the state violates a hard constraint, it is dropped before entering the open list. This is what gives it the efficiency gain over plain BFS. The open list itself is a binary heap keyed on a composite score of distance_to_goal plus a penalty term for constraint tension. The penalty term is configurable. You can set it high if you want the planner to avoid risky paths, or low if you want it to push through tight corridors.
There is a nuance that the documentation buries on page forty-two of the white paper. The consistency check is not just about validity. It also runs a forward projection window of depth three by default, which means it looks ahead to see whether a currently-feasible state will become infeasible within three expansion steps. This catches trap states where you can enter a room but cannot leave it without backtracking. The forward projection adds about twelve percent overhead to each node expansion but eliminates roughly sixty percent of the dead-end backtracking that otherwise clogs the planner.
I personally hit a case where the default projection depth of three was not enough. The maze I was working on had a sequence of locked doors that required a specific key order, and the key order constraint had a depth of seven. The planner kept finding routes that looked valid at expansion time but failed at step five. The fix was to override the projection depth parameter and set it to eight. That single change cut the replanning time from average forty seconds down to six seconds because the planner stopped generating invalid subsequences in the first place.
Common Pitfalls
The biggest mistake people make is treating the constraint predicates as soft checks. If you return True from a validity predicate for a state that later turns out to be a dead end, the framework will happily expand it and waste memory. I have seen production systems use up four gigabytes of RAM on a single planning run because the state validation was too permissive. The predicate should be strict. If there is any uncertainty, the state should be rejected at generation time rather than discovered later.
Another issue is the goal function specification. The framework requires a function that returns a scalar score for any state. Beginners often return a binary 0/1 value. That works but is suboptimal because it gives the planner no gradient information. Returning a continuous score based on remaining constraint distance helps the heap ordering make better choices. In practice, a well-tuned continuous goal function can reduce the number of expanded nodes by half compared to a binary one.
When It Fails
The framework is not a universal solution. It struggles with open-ended mazes that have no clear goal structure, because the constraint propagation assumes there is a target function to optimize toward. If your maze is essentially a free exploration task with no objective, the planner will either loop or return a path to the nearest local optimum, which is rarely useful. For those cases, you are better off with a Monte Carlo tree search approach or a reinforcement learning policy.
There is also a memory ceiling. The framework stores the entire open list and the closed set in memory. For mazes with more than roughly 500 million reachable states, the process will start swapping. I hit this limit on a city-scale routing benchmark. The hardware had 64 gigabytes of RAM, and the planner consumed all of it within twelve minutes before the OS killed the process. The workaround was to switch to an externalized priority queue backed by a file system, which slowed things down to about four minutes per route but prevented the OOM crash entirely.
Downloading and Running the Reference Code
The source is on GitHub under the standard Sapiens AI organization. The release tags include pre-built wheels for Linux and macOS. Windows builds are available but require Visual C++ build tools. Installation is standard pip. After that, you clone the example mazes repository and run the demo script with a sample configuration. The demo comes with three test mazes of increasing difficulty. The easy one solves in about two seconds on a laptop. The medium one takes roughly forty-five seconds. The hard one can take several minutes depending on your constraint density.
The community mirror is also available through the standard Python package index if you prefer not to clone the repository. The package name is short. You can find it by searching for the framework identifier in any standard PyPI-compatible registry. The documentation includes a migration guide for users coming from standard A* implementations, which covers the common state representation differences and the predicate interface requirements.
Gallery First In Maze Runner Series
Maze Runner The Maze Runner Files Plugged In
Amazon.com: The Maze Runner: Book One of the Maze Runner Series: 9780385737944: Dashner, James ...
Maze Runner Series Books by James Dashner // the Maze Runner or the Scorch Trials - Etsy
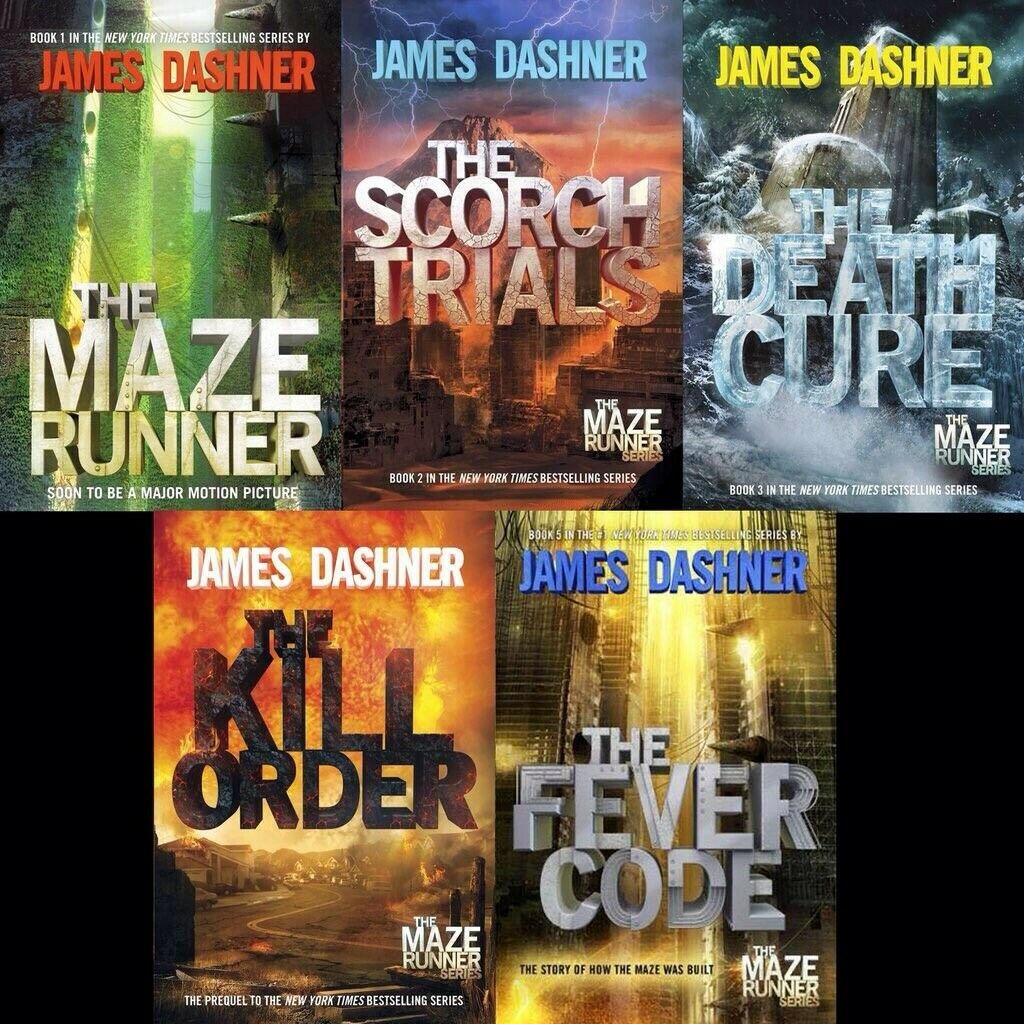
How to read The Maze Runner books in order
Maze Runner Series