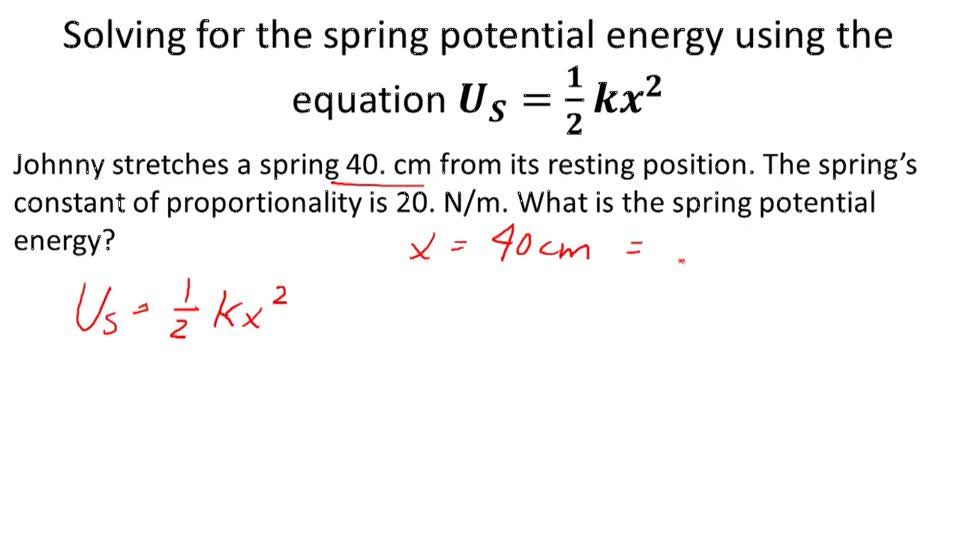
The Real Formula For Spring Potential Energy
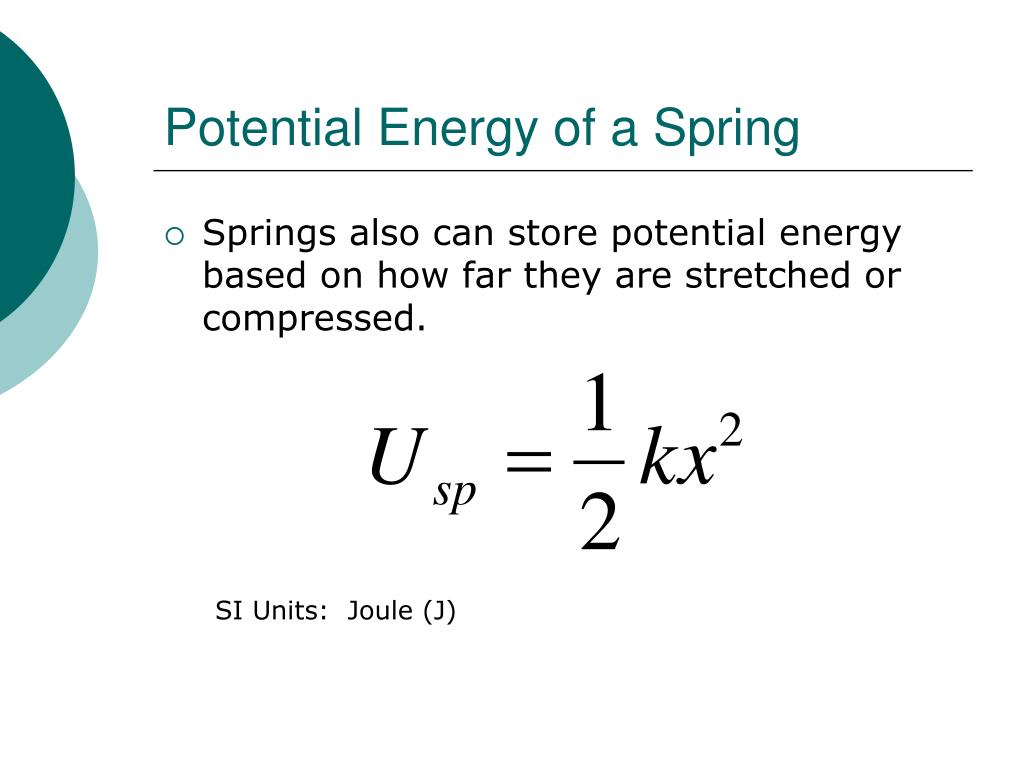
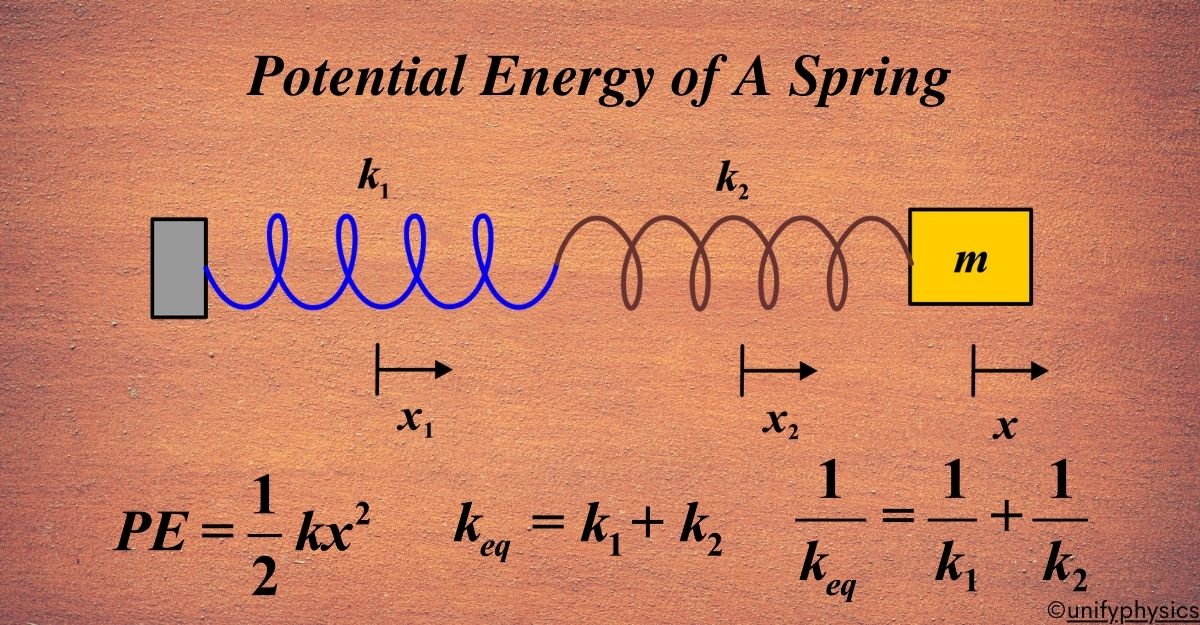
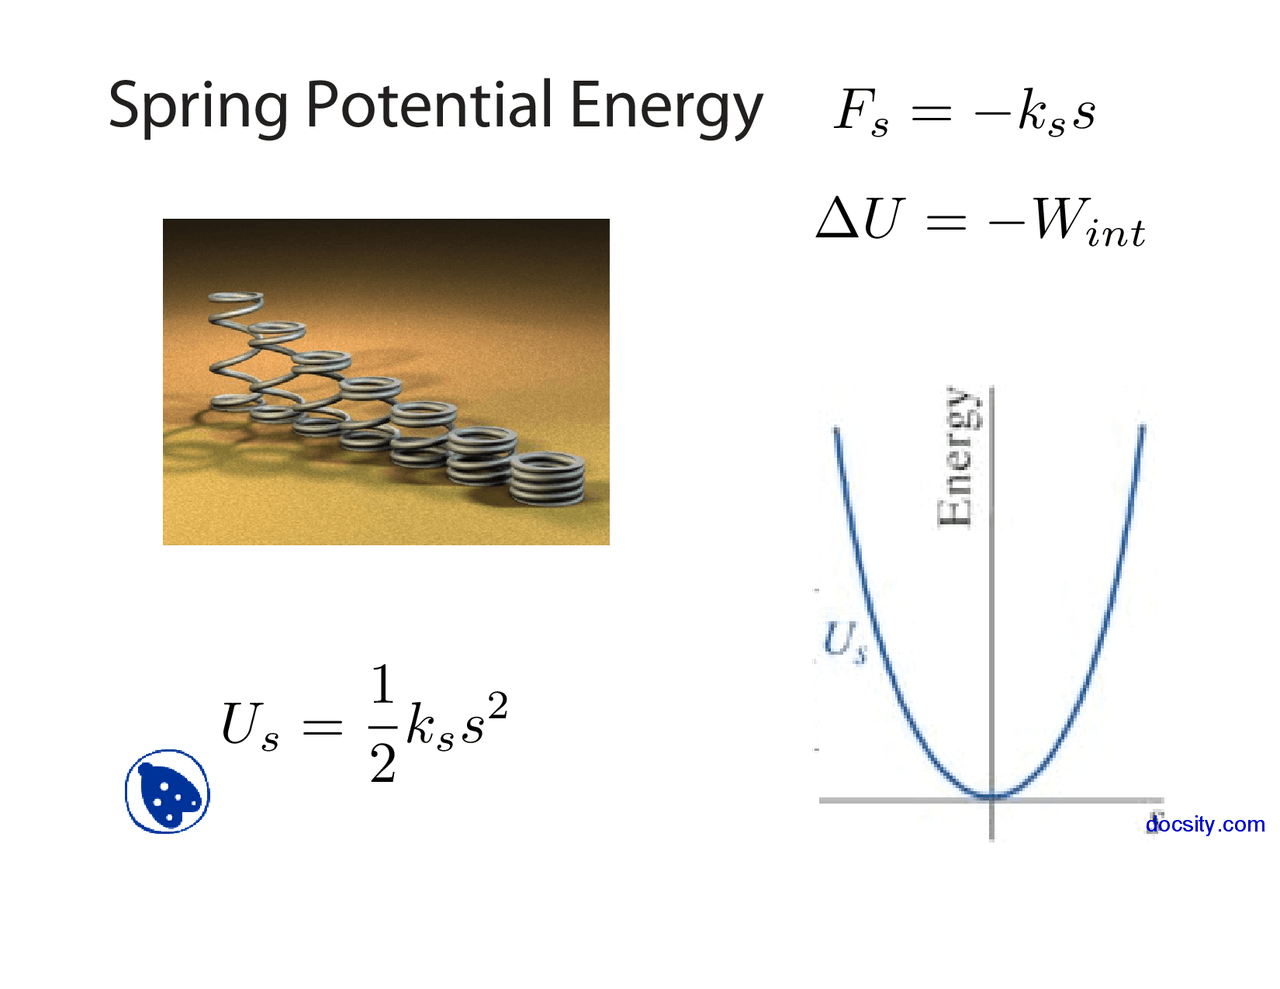
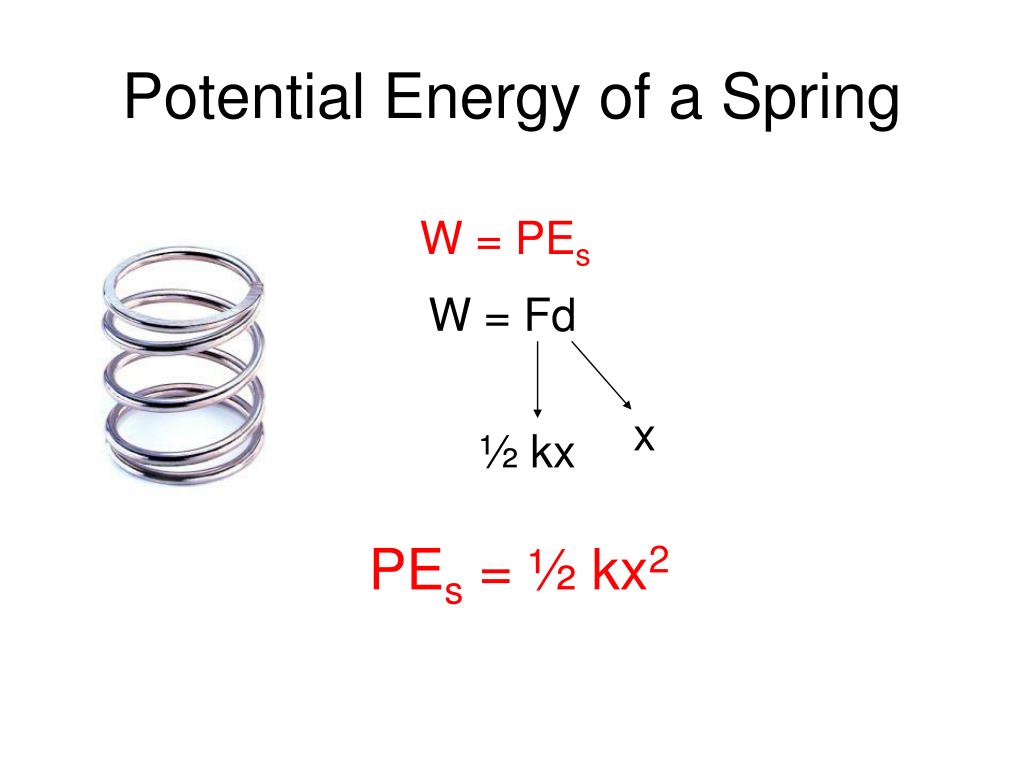
Most people encounter this in their first physics class and memorize it without really understanding what the equation is telling you. The standard formula is straightforward: the elastic potential energy stored in a spring equals one half times the spring constant times the displacement squared. Written out, that's U equals one half k x squared. The spring constant k is measured in newtons per meter and represents the stiffness of the spring. The displacement x is how far you've compressed or stretched the spring from its natural resting position, measured in meters. Energy comes out in joules. Before jumping into calculation, it helps to know where this comes from. Hooke's Law states that the force a spring exerts is proportional to its displacement: F equals minus k x. The potential energy is the work you do against that force as you compress or extend the spring. Since the force changes continuously with displacement, you can't just multiply force by distance like you would with a constant force. You have to integrate. The integral of k x with respect to x gives you one half k x squared. That half factor is the part most people skip when they're rushing through homework. I spent years working with suspension systems in automotive applications, and I can tell you that seeing this formula written on a whiteboard and actually applying it to a real coil spring are two completely different things. A coil spring doesn't behave like the textbook version of itself under most conditions. The linear relationship breaks down pretty quickly once you get beyond small displacements.
Here's what nobody tells you in the basic course: real springs have a solid height. That's the point where all the coils are pressed together and the spring can't compress any further. Once you hit solid height, the displacement value in your equation becomes meaningless because the spring constant effectively becomes infinite. The force spikes unpredictably. I once designed a suspension system where the travel was barely enough to avoid hitting solid height under normal driving conditions, and under heavy braking with weight transfer, we were exceeding the elastic limit. The potential energy equation gave us one number, but the actual energy absorbed was drastically different because the material had started to deform permanently. The workaround was switching to a progressive rate spring where the pitch changes along the length of the coil, giving a variable spring rate rather than a constant one. That way the displacement could be larger without hitting a hard limit. Another thing that catches people out is whether x is measured from the equilibrium position or from some other reference point. It has to be from the natural, uncompressed length of the spring. If you hang a spring vertically with a mass attached and it stretches by some amount due to gravity, that's not your x for the potential energy calculation relative to the unstretched position. It depends entirely on where you define zero displacement to be. In many lab setups, the spring is already preloaded before the experiment even starts, and if you don't account for that preload in your x value, every single calculation will be wrong by a fixed amount. The formula also assumes an ideal spring with no damping, no hysteresis, and no energy loss to heat. Real springs lose energy. Each compression and release cycle dissipates a small amount as heat due to internal friction between the coils and within the material itself. For high-frequency applications like valve springs in engines, this becomes significant. The potential energy you calculate using the formula is the maximum theoretical storage capacity, but the actual energy returned to the system is lower. The difference is the damping ratio, which is a separate measurement entirely.
If you're working with a spring that has a known spring rate and you need the potential energy at a given compression, the calculation itself takes about thirty seconds. You square the displacement, multiply by the spring constant, and divide by two. The challenge is never the arithmetic. The challenge is making sure your inputs are physically realistic. A displacement of zero means zero stored energy, obviously. But a negative displacement simply means the spring is compressed rather than stretched, and the result is the same because x is squared. Direction doesn't matter for the magnitude of stored energy, only the distance from equilibrium matters. I also want to flag something about units that people regularly mess up. If your spring constant is given in newtons per millimeter instead of newtons per meter, and you plug in a displacement in meters without converting, your answer will be off by a factor of a thousand. Conversely, if the displacement is in millimeters and you use it directly with a spring constant in newtons per meter, you'll be off by a factor of one million. I've seen this error repeatedly in engineering reports, and it always traces back to someone not double-checking the unit consistency before running the calculation. For most practical purposes in a classroom or basic design scenario, the formula works well within the linear range of the spring. Beyond that, you need experimental data or a finite element analysis to get accurate results. There's no simple corrected formula that accounts for all the real-world factors like material yield strength, coil bind, and fatigue over repeated cycles. Those require testing, not calculation.
Get the Full Details