Starting With What Actually Matters
The math here is straightforward if you've done any structural dynamics at all. For a single-degree-of-freedom system, the natural frequency comes from _n = (k/m), where _n is in radians per second. Convert to Hz by dividing by 2. That's it. One degree of freedom, one frequency, one mode shape that's just a number representing displacement. The mode shape for a single DOF system is trivial because there's only one way it can move. Things get messier with multiple degrees of freedom. You're solving the generalized eigenvalue problem [K]{} = ²[M]{}, where K is the stiffness matrix, M is the mass matrix, is the mode shape vector, and is the natural frequency. You don't hand-solve this for anything beyond a handful of DOFs. It's an eigenvalue problem, and you use a numerical solver. The characteristic equation det(K - ²M) = 0 gives you the eigenvalues, which are the squared natural frequencies, and the eigenvectors are your mode shapes.
Formulas For Natural Frequency And Mode Shape
I work with this stuff for buildings and mechanical structures, and the theoretical formulas break down fast when you hit real geometry. Let me give you the beam formulas since they show up everywhere in practice. For a simply supported Euler-Bernoulli beam, the natural frequencies are f_n = (n²/2L²)(EI/A), where n is the mode number, L is the length, E is Young's modulus, I is the area moment of inertia, is density, and A is the cross-sectional area. The mode shapes are sinusoidal: _n(x) = sin(nx/L). First mode is a half sine wave, second mode is a full sine wave, and so on. A cantilever beam is different. The frequencies follow f_n = (_n²/2L²)(EI/A), where _n are the roots of the transcendental equation cos(L)cosh(L) = -1. The first four L values are approximately 1.875, 4.694, 7.855, and 10.996. The mode shapes involve both sine and hyperbolic cosine terms. I still look these up because I can't derive them from memory on demand, and honestly, it doesn't matter for daily work.
Here's something most beginners miss. The formulas above assume linear elasticity and small deflections. They also assume the structure is perfectly elastic with no damping. In practice, joints have slip, connections aren't rigid, and damping changes the effective stiffness. I spent two weeks debugging a finite element model of a steel platform where the measured natural frequency was 18% lower than the analytical prediction. Turns out the bolted connections weren't fully torqued during testing, and the effective stiffness at those nodes dropped significantly. The analytical formulas assumed pinned-pinned boundary conditions that didn't exist. The workaround was running a sensitivity study varying the rotational spring stiffness at each connection until the model matched the test data within 5%.
Get the Full Details

Mode Shapes Are Vectors, Not Pictures
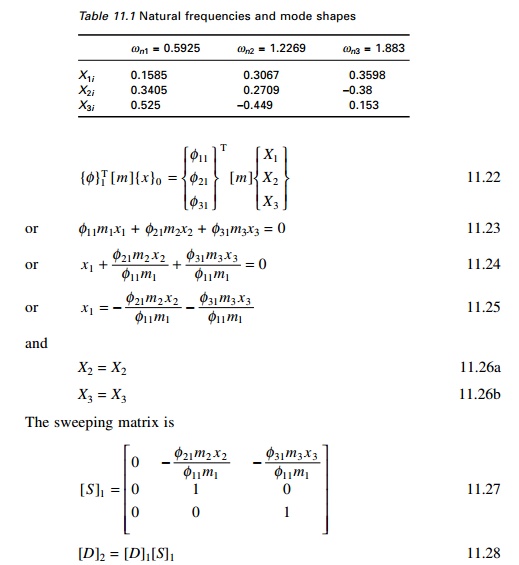
People treat mode shapes like they're illustrations of how something moves. They're not. A mode shape is an eigenvector, a direction in configuration space. The displacement at each point is relative to every other point. The absolute magnitude doesn't matter for the shape itself, only the ratios between coordinates. When you run a modal analysis in any FEA software, you'll get normalized mode shapes. Some programs use mass normalization where {}^T[M]{} = 1. Others scale to unit displacement at a reference degree of freedom. The physics is the same either way, but the numbers change, and this trips people up when they compare results between different software packages. I had a project where the modal frequencies matched between ANSYS and Abaqus perfectly, but the mode shape vectors looked completely different because the normalization was different. The relative displacement patterns were identical. Another thing that causes confusion. Mode shapes only have physical meaning at the natural frequency of that mode. If you excite a structure at the first natural frequency, the response will approximately follow the first mode shape. Excite it at the second natural frequency and you get the second mode shape. But mix frequencies and the response is a superposition of multiple mode shapes weighted by their participation factors. This is why modal superposition works for linear response analysis.
What The Formulas Don't Tell You
The analytical formulas work for simple geometries with simple boundary conditions. A uniform beam, a taut string, a simple frame. Once you have variable cross-section, non-uniform material properties, or complex boundary conditions, you're into numerical territory. The formulas still describe the physics, but you can't solve them by hand. Damping is the big omission. The formulas give undamped natural frequencies. With damping, the frequency shifts slightly lower. For most structural applications with light damping (less than 5% critical), the shift is negligible. For highly damped systems or systems with significant viscoelastic materials, you need to solve the complex eigenvalue problem and the natural frequencies become complex-valued. The real part is the damped oscillation frequency, and the imaginary part relates to the decay rate. Buckling changes everything. When a structure is under compressive load, the effective stiffness decreases. The natural frequency drops as the load approaches the critical buckling load. At buckling, the lowest natural frequency goes to zero. I've seen this matter in tall crane booms and deep foundations where the self-weight stress field noticeably lowered the natural frequency compared to an unloaded model. If you're modeling structures under significant axial load, include the geometric stiffness matrix. The modified equation becomes [K + K_G]{} = ²[M]{}, where K_G is the geometric or initial stress stiffness matrix.
Also worth noting that coupling between modes is invisible in the standard formulas. In a 3D structure, lateral and torsional modes can couple strongly if the center of stiffness and center of mass don't align. The analytical formulas for simple beams don't capture this. You need a full 3D model. I once saw a steel mezzanine where the first two natural frequencies were within 2% of each other, and the mode shapes showed significant torsional coupling because the staircase was offset from the building's center of stiffness. The analytical beam formulas for individual members would have missed this entirely.

Practical Workflow
Start with the analytical formulas for simple elements to build intuition and check your models. A simply supported beam model in FEA should give you frequencies within a few percent of the Euler-Bernoulli formula. If it doesn't, something is wrong with your model setup. Then move to numerical methods for everything that isn't a textbook problem. Use the analytical results as validation checkpoints, not as your final answer. When extracting mode shapes from a numerical solution, verify that the orthogonality conditions hold. The mass-orthogonality condition states that {_i}^T[M]{_j} = 0 for i j. If your eigenvectors from the solver don't satisfy this within numerical tolerance, something went wrong. Most modern solvers handle this correctly, but if you're writing your own code or using older software, check it. The formulas I've laid out are the foundation. Real engineering work involves building models that approximate reality well enough for the design decision at hand, validating those models against known solutions, and understanding where the approximations introduce error. The math doesn't change, but the judgment about what matters in the model does.