Why Your Gear Train Design Keeps Failing In Production
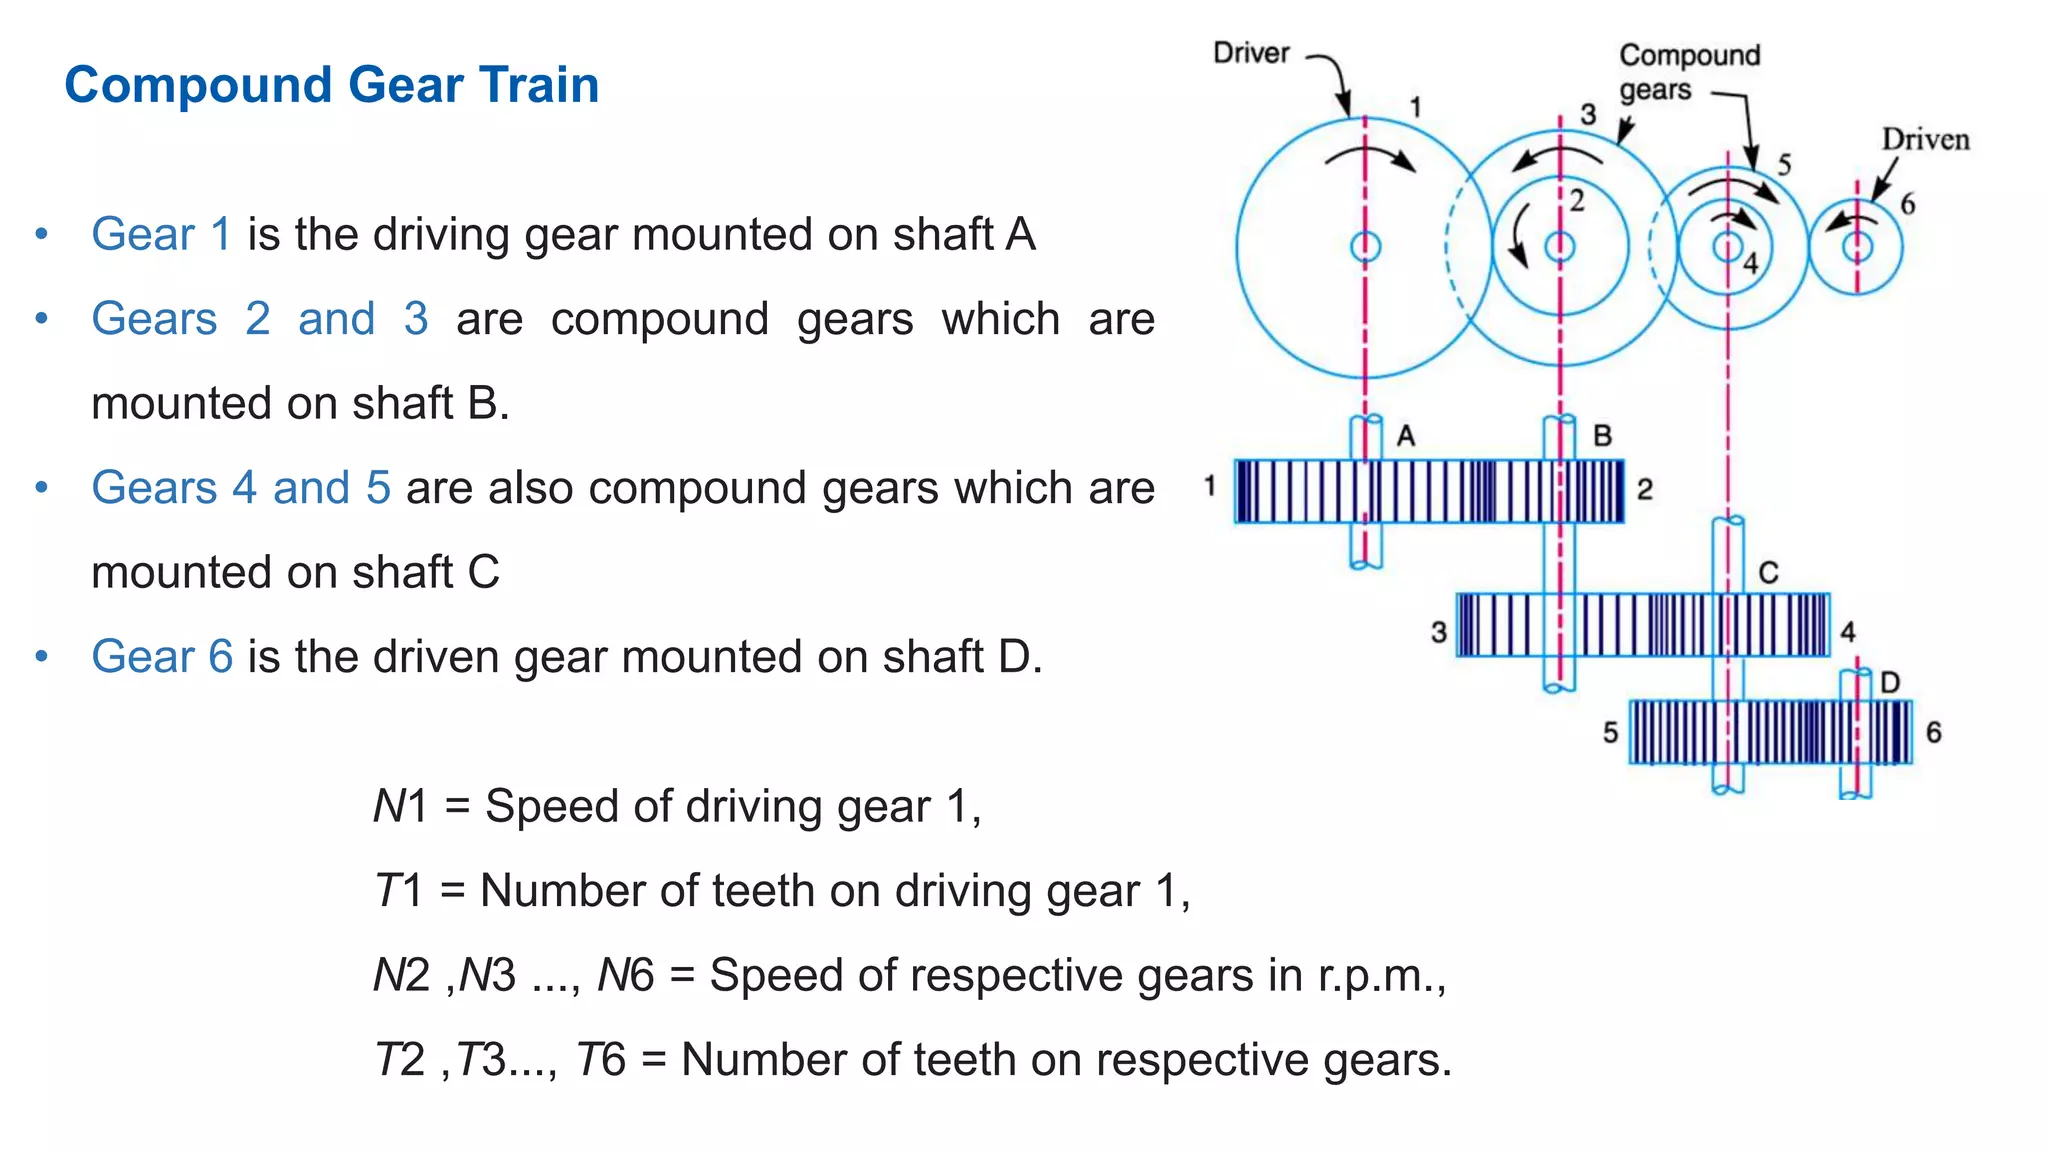
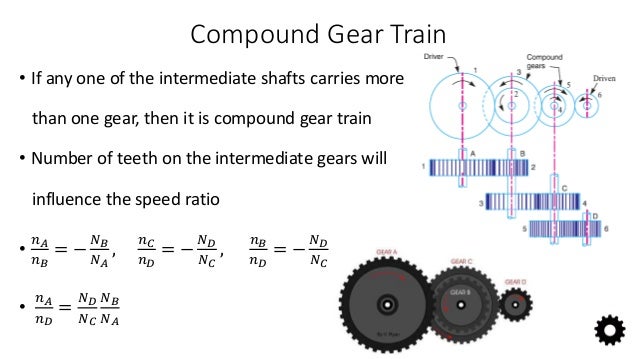
I spent three days last month re-engineering a gearbox because the theoretical calculations were fine but the actual units kept vibrating themselves apart. The problem wasn't the gear ratio or the tooth profile. It was that I didn't account for thermal expansion between the steel shaft and the aluminum housing at operating temperature. By the time everything warmed up to normal working conditions, the bearing preload had shifted enough to cause premature failure. This happens constantly when people design gears on paper without simulating real-world conditions. Gears And Gear Trains are fundamentally about transferring rotational motion and torque between shafts. That sounds simple enough, but the devil is entirely in the details of how those teeth actually interact under load. A spur gear pair might look straightforward, but once you introduce helical gears, the axial thrust component changes everything about your bearing selection and housing design. I learned this the hard way on a project where I overlooked the thrust load from helical gears and used angular contact bearings rated for radial loads only. The bearings lasted six hours before they disintegrated. The gear ratio itself is calculated by dividing the number of teeth on the driven gear by the number of teeth on the driving gear. A 20-tooth pinion driving an 80-tooth gear gives you a 4:1 reduction ratio. That part is elementary. What most people miss is that the ratio alone tells you nothing about the torque capacity, the contact ratio, or whether you will get undercutting on the pinion. A 4:1 ratio with a 12-tooth pinion and standard 20-degree pressure angle will almost certainly have undercut teeth that are significantly weaker than you would expect from basic calculations.
The Real Work: Selecting Parameters Before You Draw Anything
Before you touch any CAD software, you need to establish the torque, speed, service factor, and expected life. These four values determine almost everything else. I have seen designers skip straight to geometry because they want quick results, and then spend weeks iterating because the first prototype failed. The AGMA standards give you the framework for this, but they also assume ideal conditions. Your actual application rarely matches those assumptions perfectly. Here is a practical workflow that has saved me considerable time. Start by determining the pitch diameter based on your torque requirement and the material you plan to use. For a typical hardened steel pinion transmitting 500 inch-pounds of torque at a pressure angle of 20 degrees with a diametral pitch of 10, your minimum pitch diameter comes out to approximately 2.2 inches after accounting for the Lewis bending equation and a reasonable safety factor of 1.5 to 2.0 for intermittent service. Once you have that diameter, select the number of teeth that gives you a pitch closest to your calculated value while maintaining adequate tooth strength and avoiding undercutting. The face width is where people typically overspecify. A common rule of thumb is to make the face width approximately equal to 10 divided by the diametral pitch, but this is a starting point, not a rule. I once designed a gear train with face widths set to that guideline and found that the misalignment between shafts caused uneven load distribution across the face. The teeth near the edges were carrying far more load than the center, which led to premature pitting. The fix was to add slight crowning to the tooth profile, removing about 0.002 inches of material at the center of the face width. This allowed the gear to accommodate minor shaft misalignment without concentrating stress at the edges.
Common Pitfalls That Will Waste Your Time
One of the most frequent mistakes I see is ignoring the center distance tolerance. When you specify a center distance, even a deviation of 0.005 inches can significantly alter the backlash and contact pattern. Backlash is necessary to prevent binding and to allow for lubrication, but too little backlash causes heating and seizure, while too much backlash introduces impact loads and noise. For precision applications, I typically aim for a backlash of 0.002 to 0.004 inches measured at the pitch circle. This range works well for most general industrial applications where moderate precision is required. Another overlooked issue is the selection of the correct gear tooth profile modification. Modern gear design often benefits from tip and root relief, which reduces the load concentration at the beginning and end of engagement. Without this modification, the gears experience impact loading as each pair of teeth comes into and out of contact. This is particularly important for high-speed applications where the dynamic loads can be several times the static transmitted load. I use a simple rule of thumb for tip relief: reduce the addendum by about 5 to 10 percent of the module. This small adjustment can extend gear life by a factor of two or more in demanding applications. Lubrication is another area where theoretical designs often fall short of practical requirements. The recommended lubrication method depends heavily on the pitch line velocity. For velocities below 2000 feet per minute, splash lubrication is usually adequate. Above that threshold, you need pressure circulation or oil mist systems to ensure the teeth are properly lubricated and cooled. I discovered this on a high-speed reducer where the original design used splash lubrication, and the gears overheated within the first hour of operation. Switching to a forced circulation system with an oil cooler brought the operating temperature down to a safe range and eliminated the thermal expansion issues I mentioned earlier.
Get the Full Details
Materials And Heat Treatment Considerations
Material selection is critical and it is not as simple as picking the hardest steel available. Hardness improves wear resistance, but it also reduces toughness. For gears that experience shock loads or impact, a through-hardened medium carbon steel like 4140 or 4340 tempered to a hardness of 28 to 32 Rockwell C often provides better overall performance than a case-hardened gear that is too brittle. Case hardening is excellent for surface wear resistance, but if the core is not properly matched, the case can spall off under heavy loads. When I need a quick reference for material suitability, I use the following guidelines. For light to moderate loads with good alignment, AISI 1045 normalized works adequately and is inexpensive. For heavier loads and better fatigue resistance, AISI 4140 quenched and tempered is the standard choice. For extreme conditions involving high temperatures or corrosive environments, 17-4PH stainless steel or nitrided case hardening steels like 4320 are worth the additional cost. The nitriding process, in particular, provides a very hard surface layer without the distortion that can come from conventional case hardening, which is advantageous for finished gears that require precise tooth geometry.
Analysis Tools And Methods
You do not need expensive finite element analysis software to do competent gear design. The AGMA standards provide formulas and procedures that are sufficient for most practical applications. The key formulas cover bending stress using the Lewis equation modified for dynamic loads, and contact stress using the Hertzian contact formula. Software like KISSsoft or even basic spreadsheet calculations based on these formulas can get you 90 percent of the way there. The remaining 10 percent comes from experience and understanding the assumptions built into those formulas. For a quick check on your gear design, calculate the bending stress using the modified Lewis equation: sigma = Wt * Pd / (F * Y) * Km * Kv * KS. Here Wt is the tangential load, Pd is the diametral pitch, F is the face width, Y is the Lewis form factor, Km is the load distribution factor, Kv is the dynamic factor, and KS is the size factor. If your calculated stress is below the allowable bending strength for your chosen material, you are in the clear for bending. Then check the contact stress using sigma_c = Cp * sqrt(Wt * Pd / (F * d * I). If this contact stress is below the allowable contact strength, your design is acceptable for both bending and wear. I typically run these calculations in a spreadsheet that I have configured with the AGMA coefficients and material properties for common gear steels. This allows me to iterate quickly and see the effect of changing parameters like diametral pitch, number of teeth, and face width. The whole process takes about 15 to 20 minutes for a basic two-stage gear reduction, compared to the several hours it would take to model the same thing in a full CAD package.
Gears And Gear Trains In Modern Applications
The principles remain the same whether you are designing a gearbox for a wind turbine or a small precision reducer for robotics. What changes is the scale and the specific requirements. In robotics, where space and weight are critical constraints, you often see planetary gear trains because they offer high reduction ratios in a compact package. A single stage planetary can achieve a ratio of about 3:1 to 10:1, and multiple stages can be stacked to achieve much higher reductions without significantly increasing the footprint. For high-precision applications like CNC machines and measuring instruments, the focus shifts from power transmission to accuracy and repeatability. Here, gear tooth errors of a few microns matter, and you need to consider manufacturing methods like grinding and honing to achieve the required surface finish and tooth accuracy. Involute splines and harmonic drives are alternatives that avoid some of the backlash issues inherent in traditional gear trains, but they come with their own trade-offs in terms of torque capacity and rotational stiffness. The fundamental physics has not changed in decades. Gears still mesh, torque still transfers, and stresses still accumulate. What has improved is our ability to predict failure, select materials, and optimize designs before we commit to manufacturing. Using the right analytical tools and learning from practical experience rather than relying solely on textbook formulas will save you from the kinds of surprises that cost time and money. Design thoroughly on paper, validate with calculations, and only then move to prototyping. That sequence alone will prevent the majority of the problems that show up in production.