How to Actually Use the General 90 Series Manual Without Losing Your Mind
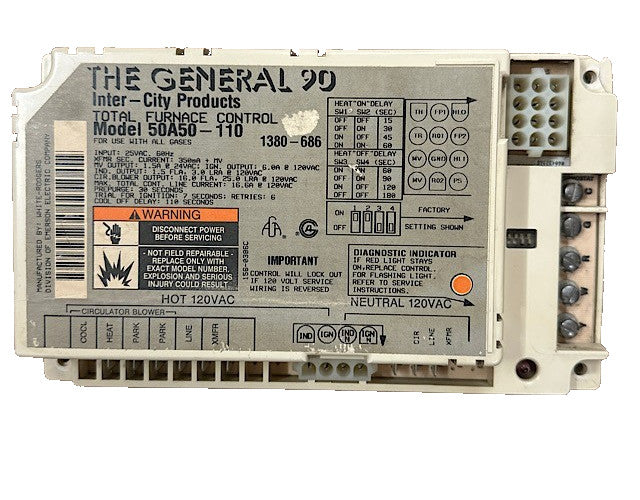
The General 90 Model 50a50 110 Manual is the reference document for a line of industrial servo drives that most technicians end up using because their boss told them to, not because they wanted to. The drive itself is a decent unit for the price, but the manual is where things get rough. It covers motor tuning, parameter configuration, fault code resolution, and wiring diagrams across multiple voltage configurations. I've worked with these units on and off for years, and the manual has its share of problems. The 50a50 110 designation refers to a specific frame size and power rating within the General 90 series. It's a medium-duty servo drive commonly found in CNC retrofits, packaging machines, and conveyor systems. The manual runs roughly 180 pages and includes parameter tables that are organized by group rather than alphabetically, which is fine if you know what you're looking for and terrible if you don't. The parameter groups are numbered 00 through 99. Group 00 handles basic setup like motor type selection and rated current. Group 01 covers speed loop tuning. Group 02 is position control. Group 03 deals with torque limits. Groups 04 through 10 handle input and output configurations. The rest gets into advanced features like electronic gear ratios, vibration suppression filters, and communication settings. The manual tells you what each parameter does, but it doesn't always tell you what a sensible starting value is. That part is left to experience.
Getting the Drive Running for the First Time
Wiring this drive is straightforward if you read the diagram before you touch anything. The power inputs are L1, L2, L3 on the AC side and P, PB, N on the DC bus. The motor outputs are U, V, W. Ground everything. Skip ground and you'll chase phantom faults for three days. The control inputs are 1 through 10 and the common terminal. These are all opto-isolated 24V inputs. You can wire in start/stop commands, forward/reverse, jog, alarm reset, and zero pulse depending on how you configure the parameters. If you're using an existing controller, make sure the logic levels match. A few units on the market run at 12V logic and the manual mentions this in passing on page 47, buried in a footnote. Miss that and your PLC outputs will be underdriving the input circuits. After wiring, power up with the motor disconnected. Check the DC bus voltage. It should read approximately 1.35 times the AC line voltage. For a 110V single-phase supply, expect around 150V DC. For 220V three-phase, expect around 310V DC. Anything outside that range means you have a rectifier problem or you're feeding the wrong voltage into the drive.
Tuning the Speed Loop
This is where people mess up. The manual describes a two-step tuning process: first set the proportional gain and integral time for the speed loop, then adjust the position loop if you're running in position mode. Step one alone takes 20 to 30 minutes on a real machine, not the two minutes the documentation implies. Start with parameter 01-02 (speed loop proportional gain) at 50 percent of the default. Run the motor empty shaft. Slowly increase the gain until you see oscillation at low speed, then back it off by 20 to 30 percent. Next, adjust parameter 01-03 (integral time) until the response settles without overshoot. The manual doesn't mention that on motors with high inertia loads, you may need to engage the inertia ratio estimator first. Parameter 01-15 runs an auto-tune that measures the load-to-motor inertia ratio. Run it before touching the manual gains. It saves you half the trial and error. One thing the manual gets wrong is the damping filter description. It says the notch filter can eliminate resonance up to 2000Hz. That's true in simulation. On a real belt-driven axis with a loose coupling, the resonance peak moves when the belt tension changes. I spent two weeks trying to tune out a vibration on a packaging machine, swapping filter frequencies and gains, before I realized the coupling was worn and the resonance was mechanical, not electrical. Tightened the coupling and the problem disappeared. The manual assumes the mechanical system is perfect. It never is.
Get the Full Details
Common Fault Codes and What They Actually Mean
Fault code E001 is overcurrent. Everyone assumes this means a short circuit or a bad motor. Half the time it's a deceleration ramp that's too aggressive for the load inertia. If the drive trips on E001 during stopping, increase the deceleration time in parameter 00-03 by 50 percent and try again before touching the motor. Fault code E003 is DC bus overvoltage. This happens when the regeneration energy has nowhere to go. If you're braking frequently or the DC bus braking resistor isn't connected, the voltage climbs past the threshold. The manual tells you to check the braking resistor, but it doesn't mention that some installations omit the resistor entirely and rely on the internal dynamic brake. If your unit doesn't have the resistor option installed, parameter 02-20 disables the overvoltage trip, which is a workaround, not a fix. I've seen this done in the field. It works until the capacitor degrades prematurely from thermal stress. Fault code E007 is encoder error. This is almost always a wiring issue, not an encoder failure. Check the shield connection, verify the differential signal integrity with an oscilloscope if you have one, and confirm that the encoder cable isn't running parallel to the power cables. I had a unit throw E007 intermittently for a week before I traced it to a grounded shield at both ends creating a ground loop. One-end grounding fixed it.
Parameter Backups and Firmware Updates
The manual says you can save parameters to EEPROM using parameter 00-17. Do this after every successful tuning session. The drive can lose its settings if the battery backup fails, and the replacement battery is a 3V lithium cell that's not easily accessible. You'll need to open the front cover and locate the holder on the main board. Takes about five minutes if you know where it is. Firmware updates require the USB communication cable and the manufacturer's programming software. The current firmware version for the 50a50 110 is 3.2.1. Earlier versions had a bug where the electronic gear ratio wouldn't apply correctly if you changed it while the drive was in run mode. The drive would accept the new value but continue using the old ratio until a power cycle. Update to 3.2.1 or later if you're doing live tuning adjustments. You can find firmware on the manufacturer's support site. Download the file, connect the drive via USB, launch the software, and flash. The process takes about four minutes. Don't interrupt it.
What the Manual Doesn't Cover
The biggest gap in the documentation is multi-drive synchronization. If you're running two or more 50a50 110 units on the same axis and expecting them to coordinate, the manual barely mentions it. The hardware supports master-slave configuration through the digital input terminals, but getting it to work requires setting parameter group 09 correctly and matching the communication timing between drives. I've seen integrators try to parallel these drives without proper synchronization and end up with mechanical binding and burned windings. If you need coordinated motion, consider a dedicated motion controller instead of relying on the drives to handle it. Another gap is thermal derating. The 50a50 110 is rated for continuous operation at ambient temperatures up to 50 degrees Celsius. Above that, the current output drops. The manual has a derating curve on page 62, but it's easy to miss if you're scanning quickly. In a poorly ventilated enclosure in a hot factory environment, you might only be able to draw 70 percent of the rated current without triggering a thermal fault. Size your drive accordingly. The drive is competent for basic positioning and speed control tasks. The manual will get you 80 percent of the way there. The other 20 percent comes from knowing where the gaps are and having a workaround ready. If you run into something the documentation doesn't address, check the parameter list first. Most undocumented behaviors can be controlled through a parameter you haven't touched yet.