The Long Road to Self-Driving Vehicles
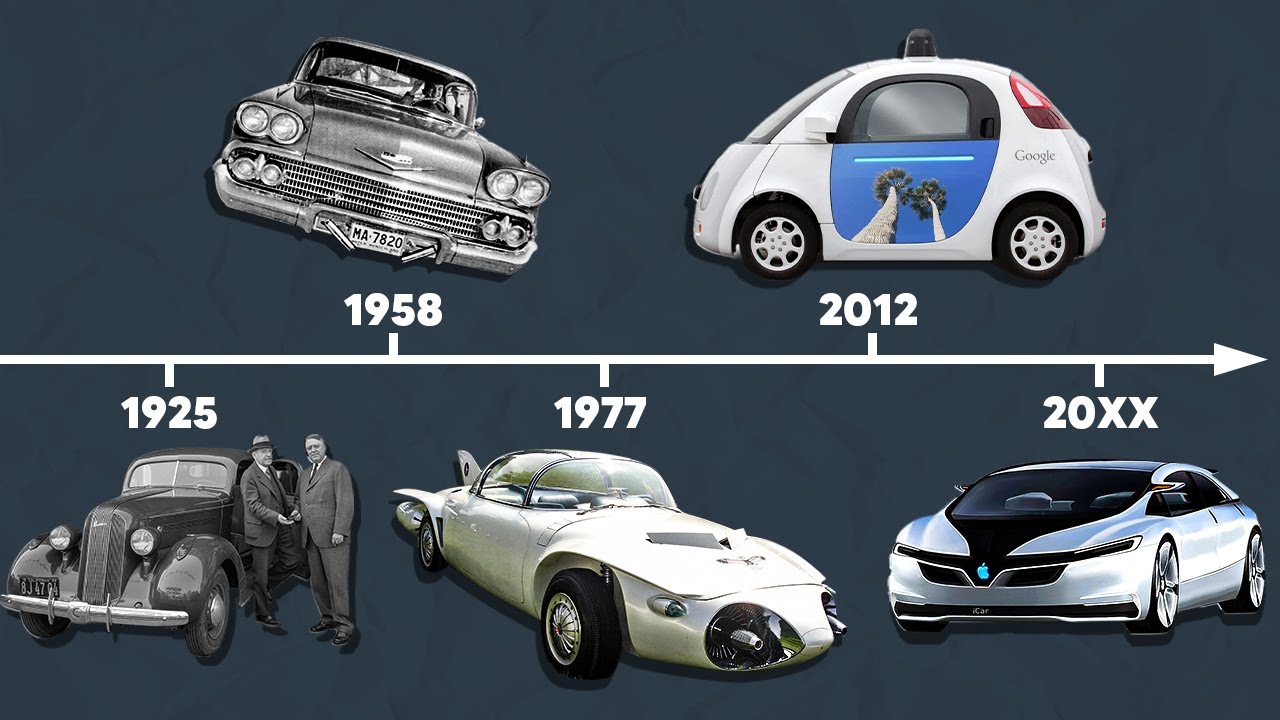
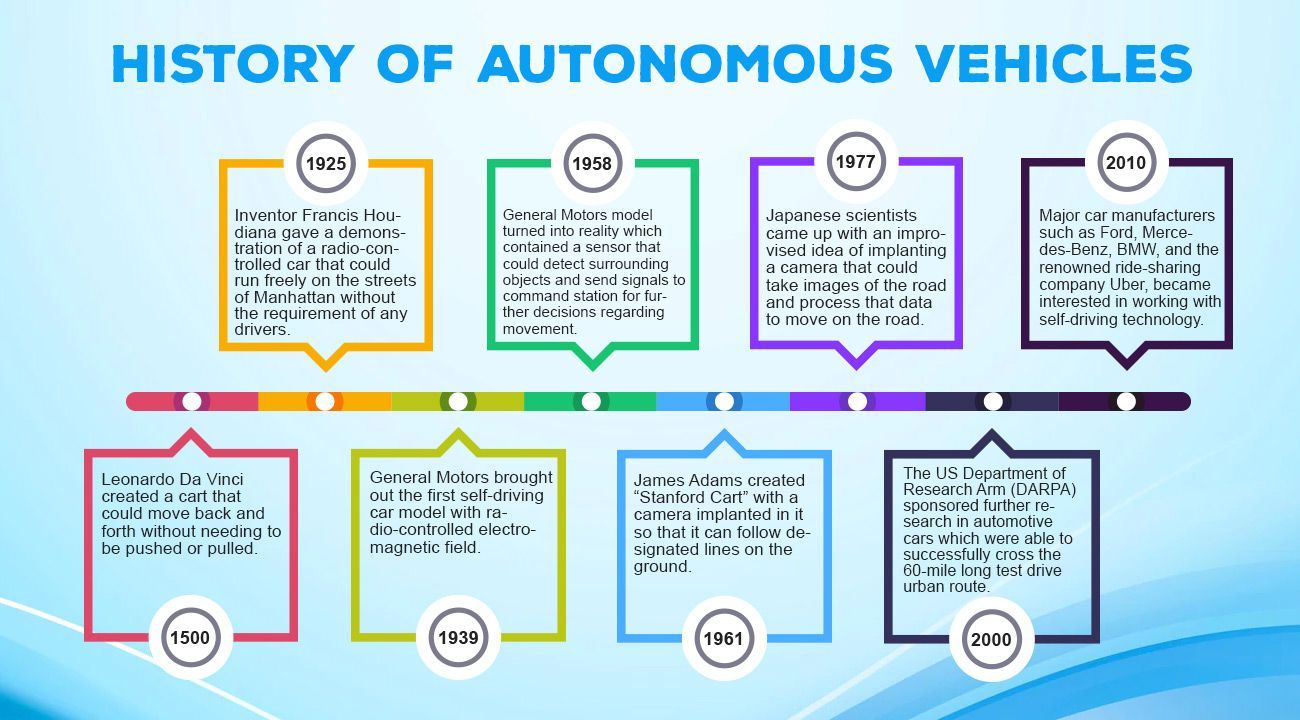
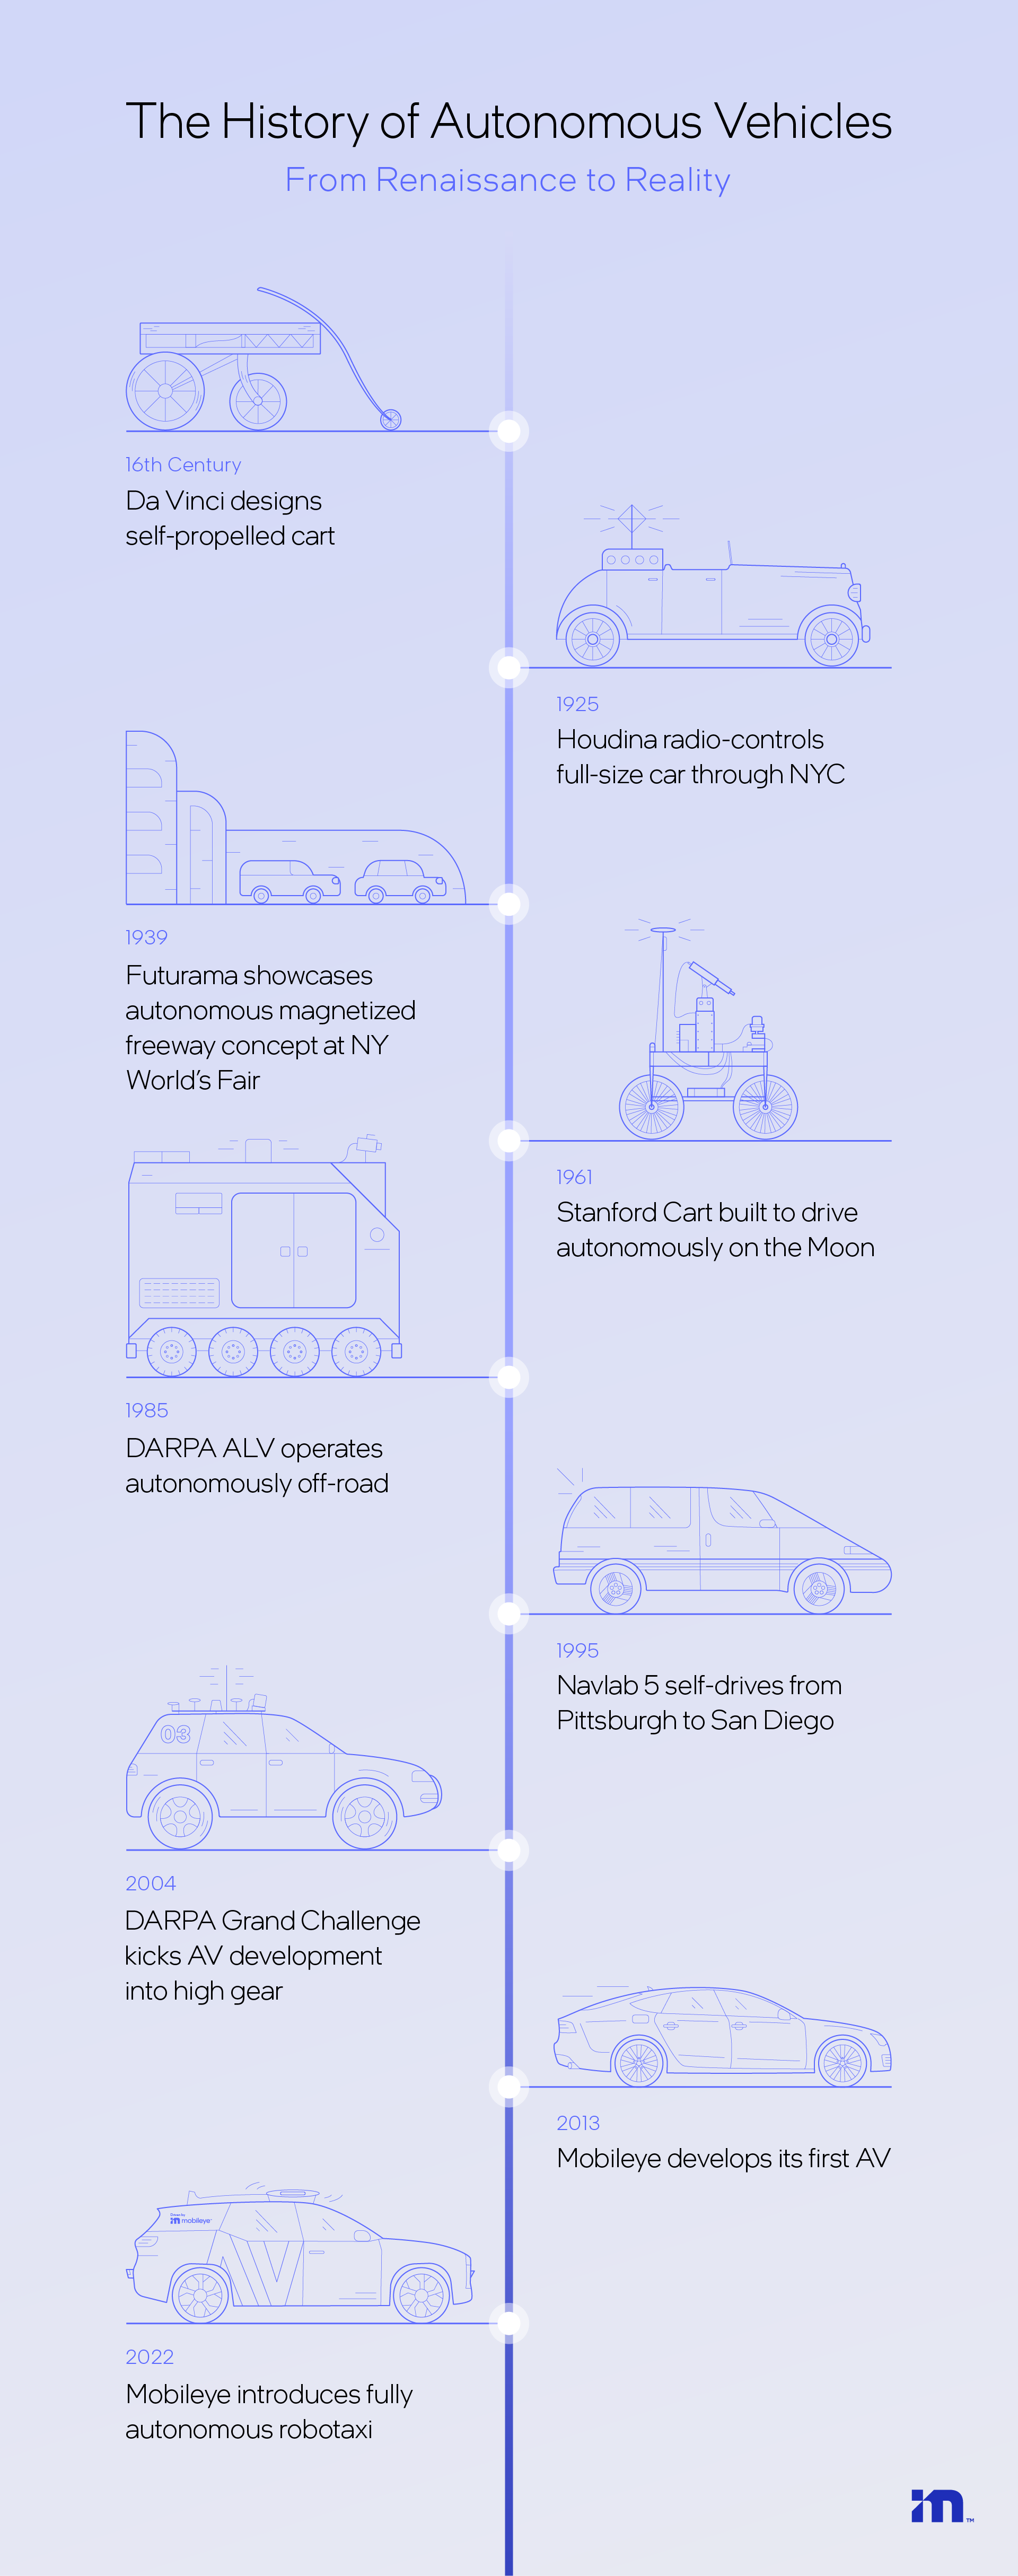
Most people think autonomy started with Tesla's autopilot or Waymo's robotaxis, but the actual timeline is messier and stretches back decades. The first meaningful work happened in the 1980s at Stanford and BMW's EADS project in Europe, both experimenting with camera-guided cars on unpaved roads. Carla Behringer's Navlab and Ernst Dickmanns' Valet system were running at under 60 kilometers per hour on marked highways, which sounds laughable now, but getting a car to follow lane lines using analog video processing was genuinely hard at the time.
Understanding the History Of Autonomous Cars
I've spent years working in this space, and the thing most people miss about the history is that the funding winters were just as important as the breakthroughs. DARPA funded the Grand Challenge in 2004 because they wanted to prove autonomous navigation for military logistics. Eighty-seven teams entered. Nobody finished. That single event shifted the entire industry's approach from academic research to engineering-heavy competition. Two years later, the 2005 challenge had seven finishers, includingStanley from Stanford, which used a multi-layered perception stack with LIDAR, radar, and vision fused together.The real pivot point came around 2010 when Google's Sebastian Thrun left to start what became Waymo. That's when silicon valley money flooded in, not government grants. The problem with this era of funding is that it created an expectation of timelines that never materialized. Every company around 2016 to 2019 was claiming Level 5 autonomy within two years. That didn't happen. The reason is simpler than most articles admit: long-tail edge cases. A self-driving system might handle 99.5 percent of driving scenarios correctly, but the remaining half percent includes things like a construction worker holding a strange-shaped sign, or a child chasing a ball into traffic from behind an opaque truck, or rain so heavy the LIDAR point cloud becomes noise. I remember working on a test route near Phoenix where we kept getting false positives from the perception stack. Turns out the asphalt in that area had a slightly different mineral composition, and the thermal signature was throwing off the distance estimation on certain stationary objects. The fix wasn't software. We had to recalibrate the sensor fusion weights specifically for that geographic region. That's the kind of detail that never makes it into press releases about autonomous vehicles.
Key Milestones That Actually Mattered
The 2016 NHTSA guidelines were a turning point, even though they were non-binding. They forced every manufacturer to define what levels meant in practice, which created a common language that still exists today. Before that, "self-driving" meant whatever a marketing team wanted it to mean. The SAE J3016 standard, published in 2014 and updated several times since, is the document everyone argues about in meetings. Mobileye's EyeQ chip architecture, introduced around 2014, changed the economics of perception. Instead of relying on expensive LIDAR arrays, Mobileye demonstrated that stereo cameras plus a custom SoC could handle a significant portion of the perception workload at a fraction of the cost. This pushed the entire industry toward camera-first architectures, though LIDAR never fully went away. Tesla went all-in on vision, which has been controversial but technically defensible if you accept their assumption that human drivers don't use LIDAR and therefore don't need it. Mercedes-Benz got the first Level 3 certification in 2021 for their Drive Pilot system, limited to 60 km/h in heavy traffic on specific highways. This is functionally different from everything that came before because it shifts legal responsibility to the manufacturer when the system is engaged. Previous levels put the burden on the driver to remain attentive and ready to take over. Level 3 says the car is responsible under defined conditions. That legal distinction matters more than the technical one.
Get the Full Details
Where Things Stand Now and Where They're Stuck
Waymo operates fully driverless robotaxi services in Phoenix, San Francisco, Los Angeles, and a few other cities. They've accumulated millions of autonomous miles, but their operational design domain is tightly constrained to mapped urban areas with clear lane markings and moderate weather. Expand that domain and the failure rate climbs faster than most people expect. Tesla's Full Self-Driving beta has been distributed to hundreds of thousands of consumers since 2022, which is both a blessing and a liability. The sheer volume of real-world data is unmatched, but consumer misuse and the lack of geofencing means the system encounters scenarios Waymo deliberately avoids. The regulatory scrutiny this has attracted is real and ongoing.Chinese manufacturers have taken a different approach. Baidu's Apollo, Pony.ai, and NIO have integrated autonomous driving into vehicle sales at scale, often leveraging V2X infrastructure that American cities largely lack. In Wuhan, Baidu operates driverless ride-hailing services across a city-wide area that would be considered massive by any American metric. The infrastructure advantage they have is significant and probably untappable in most Western markets. The biggest bottleneck right now isn't perception or planning. It's validation. Proving that a system is safer than a human driver requires either billions of miles of real-world testing, which is prohibitively expensive, or sophisticated simulation, which has its own accuracy problems. We don't have a reliable way to generate synthetic edge cases that faithfully represent the distribution of real-world anomalies. This is why progress has slowed to a crawl since the hype peaks of 2016 to 2019. If you're looking to study this topic further, the Society of Automotive Engineers publishes the J3016 standard, and the IIHS and NHTSA maintain detailed crash and incident databases. Academic papers from conferences like IV Symposium and ITSC cover the technical evolution in more depth than any popular article will. The history here is still being written, and the next chapter will probably depend on regulation catching up to what the technology can actually do reliably.